

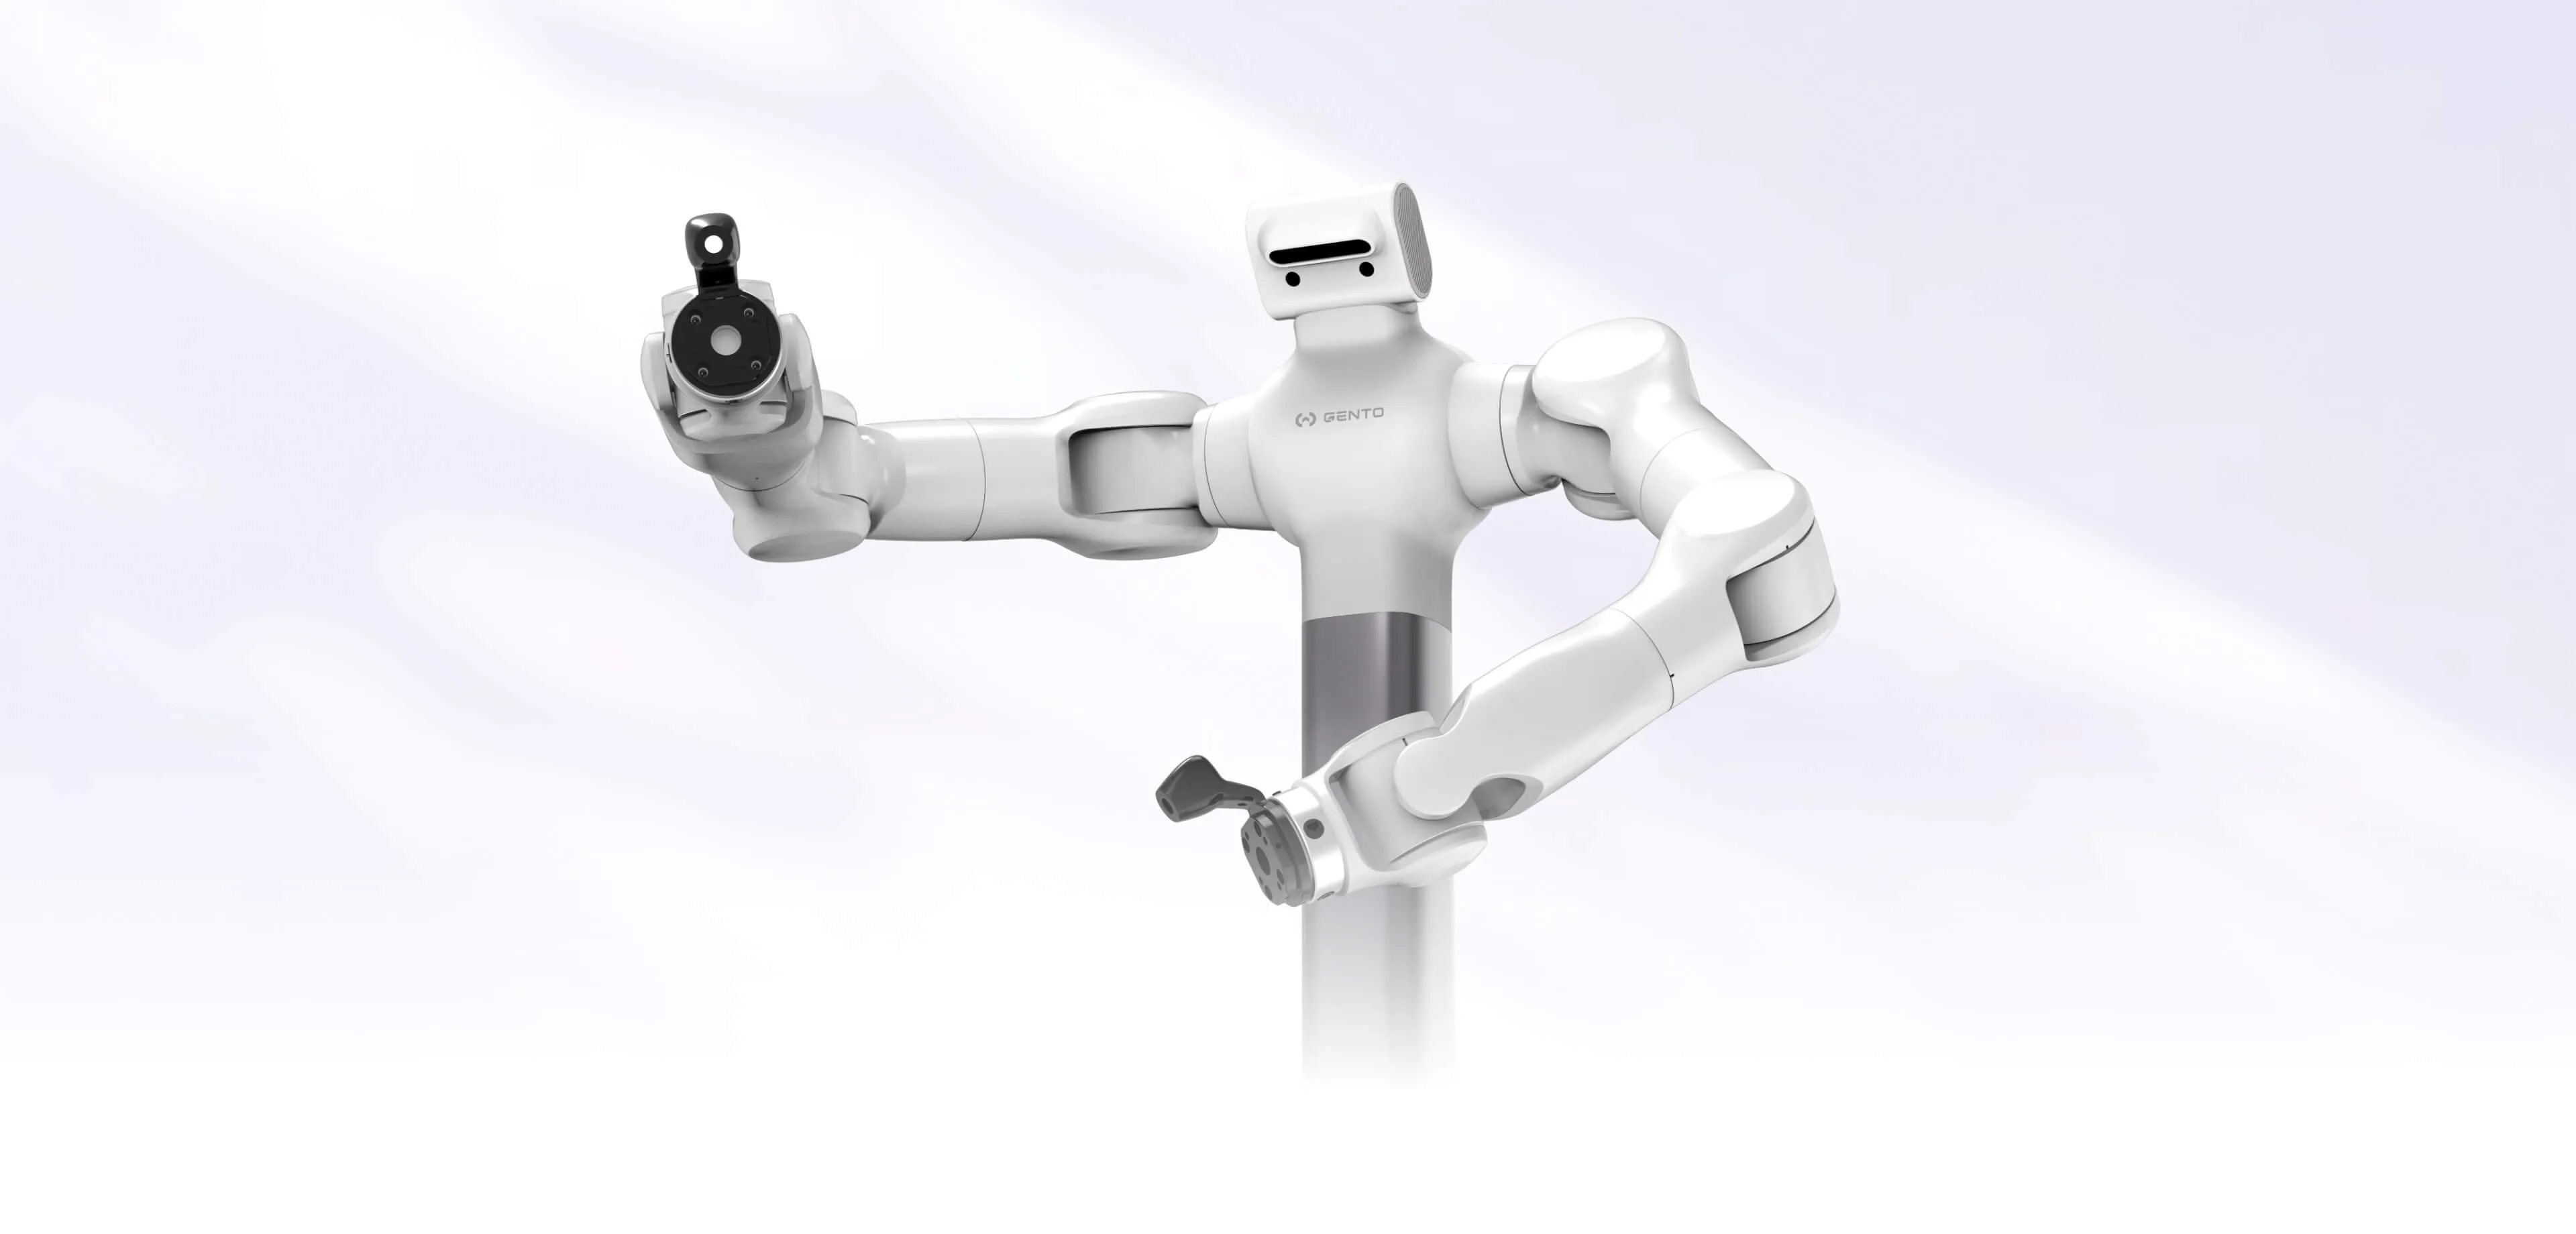
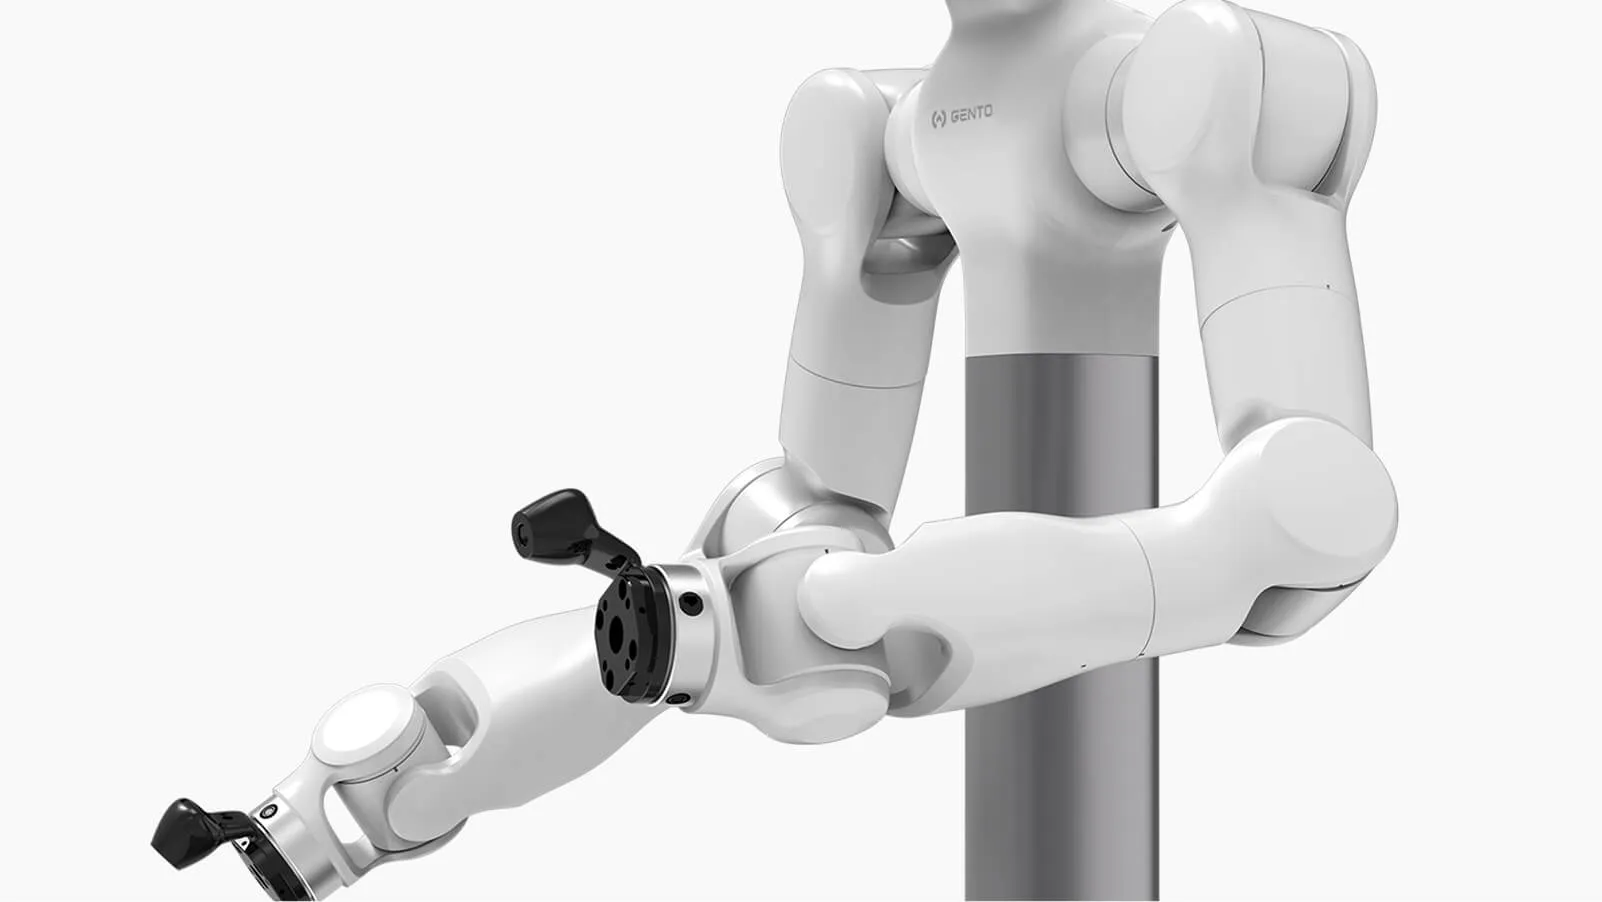
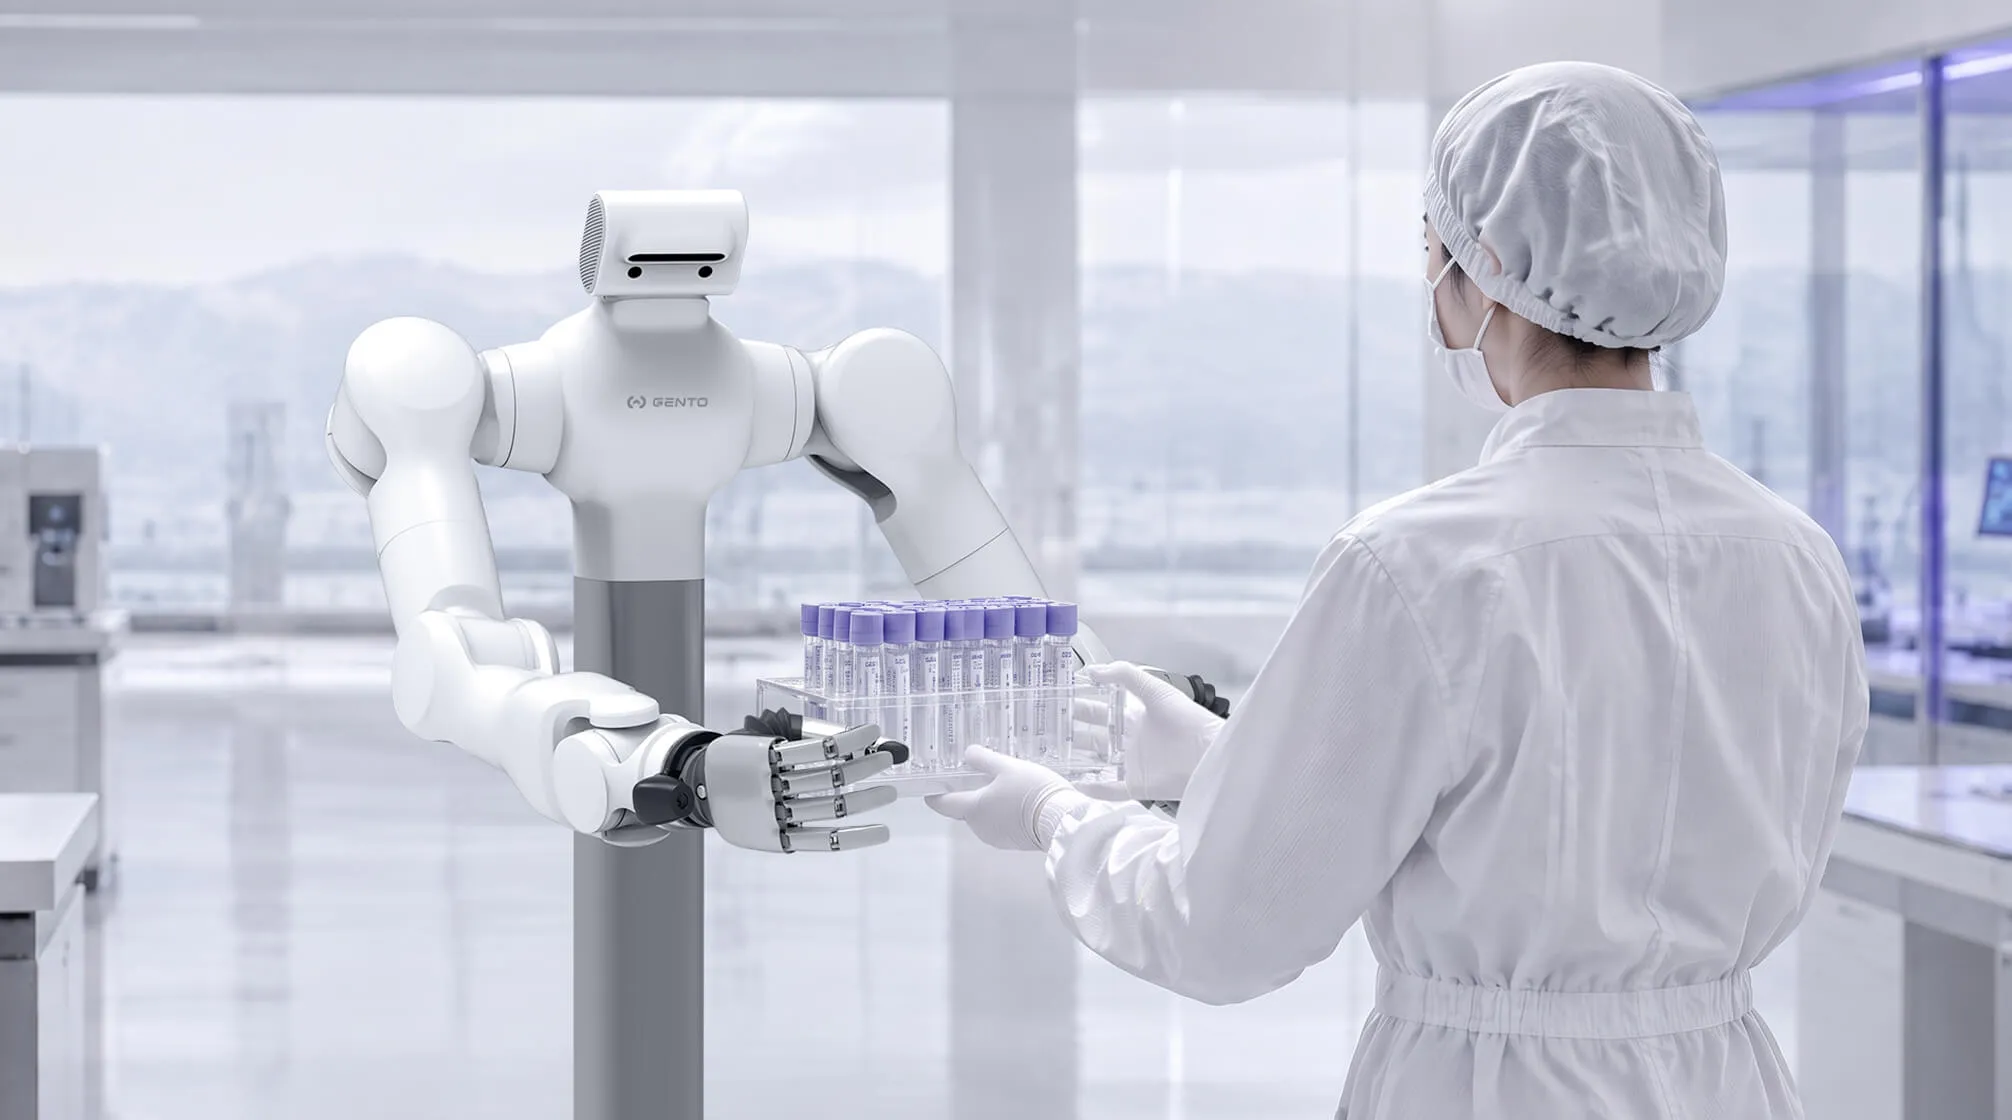
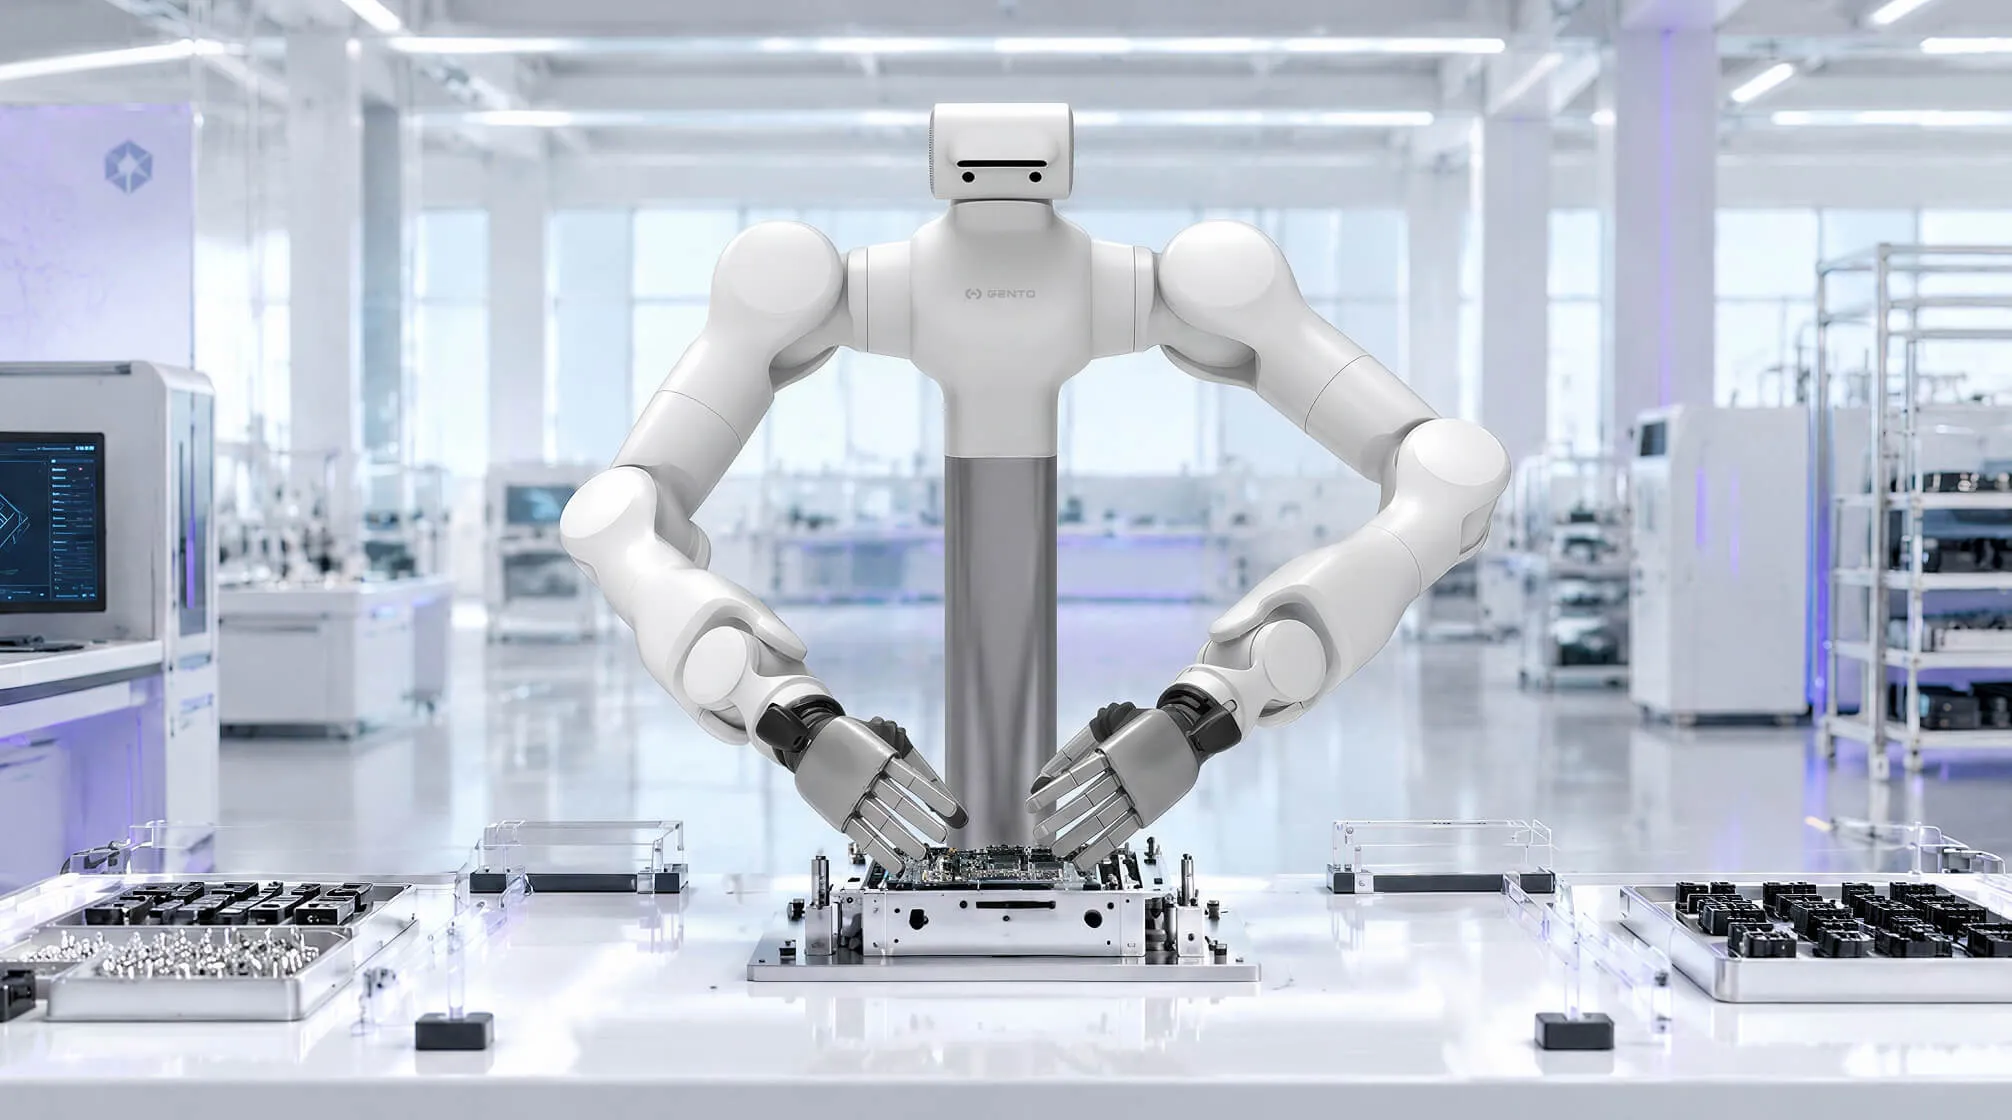
Marvin Pro is a stationary dual-arm robot with strong manipulation, high computing power, and a minimalist structure, featuring a simplified fixed base and stationary head to cut costs and deployment difficulty. Equipped with a 5-view panoramic vision system and 7DoF force-controlled arms, it perfectly suits industrial assembly, research experiments, and high-precision data collection.
-
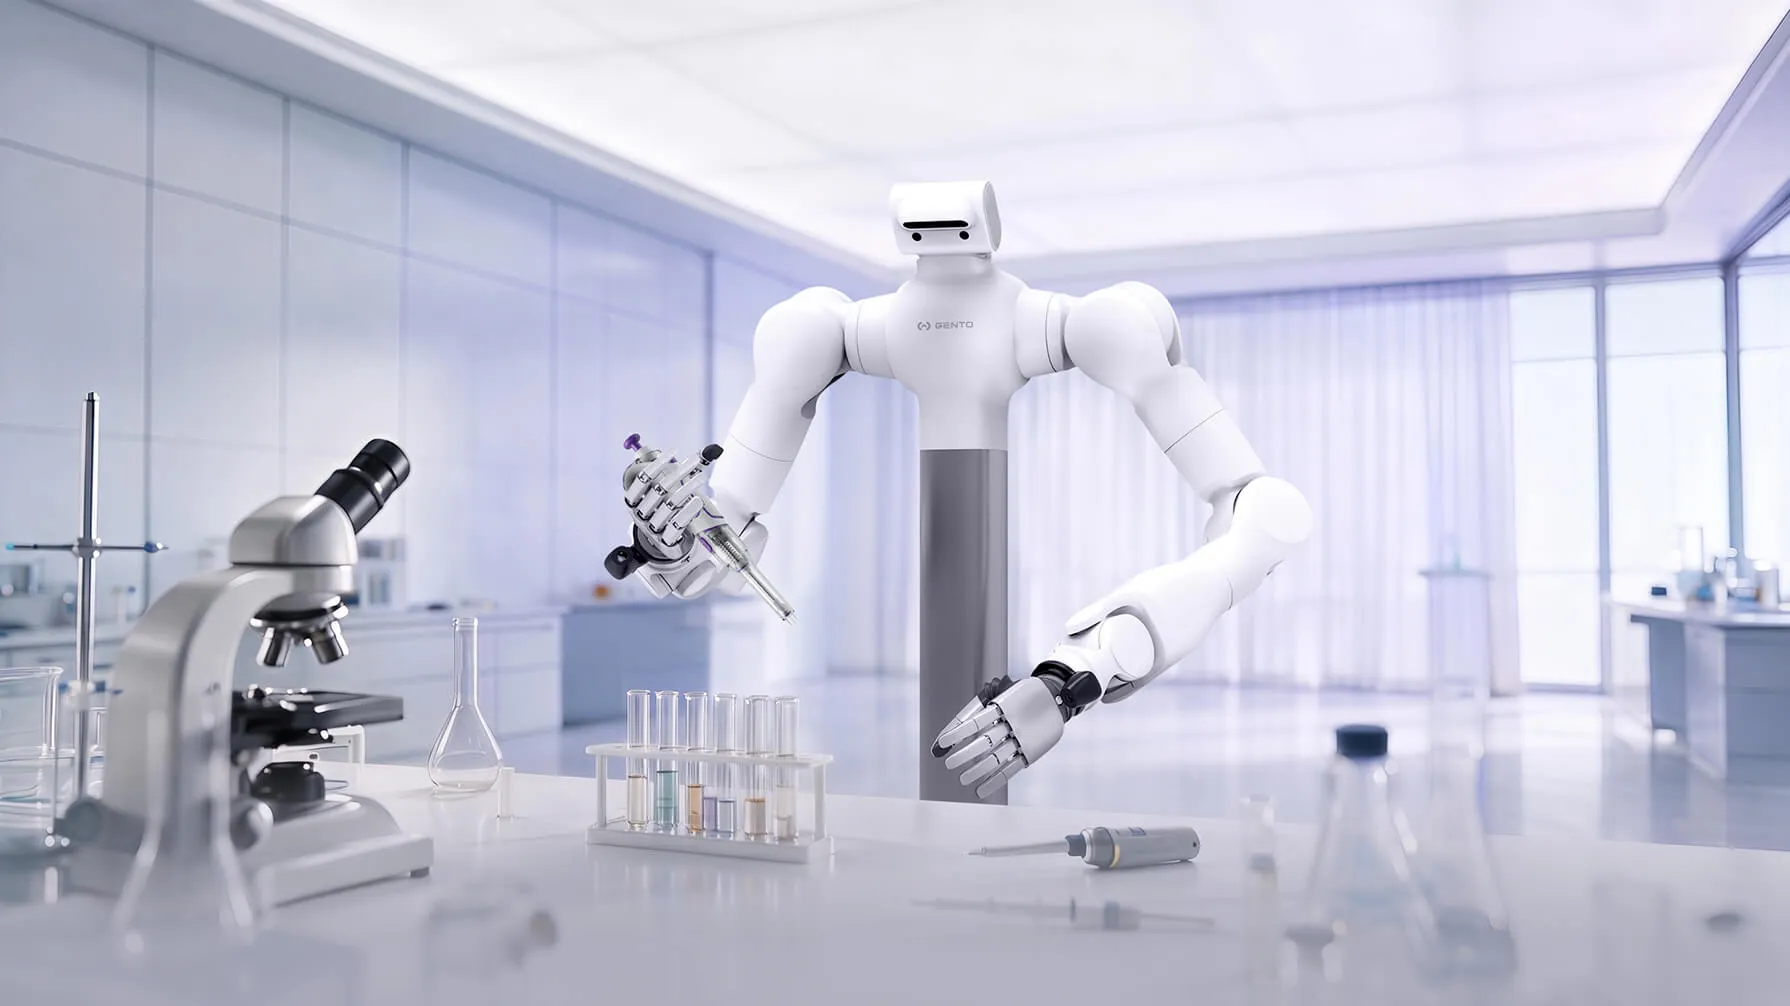 · Fixed Base
· High-Precision Stable Operation -
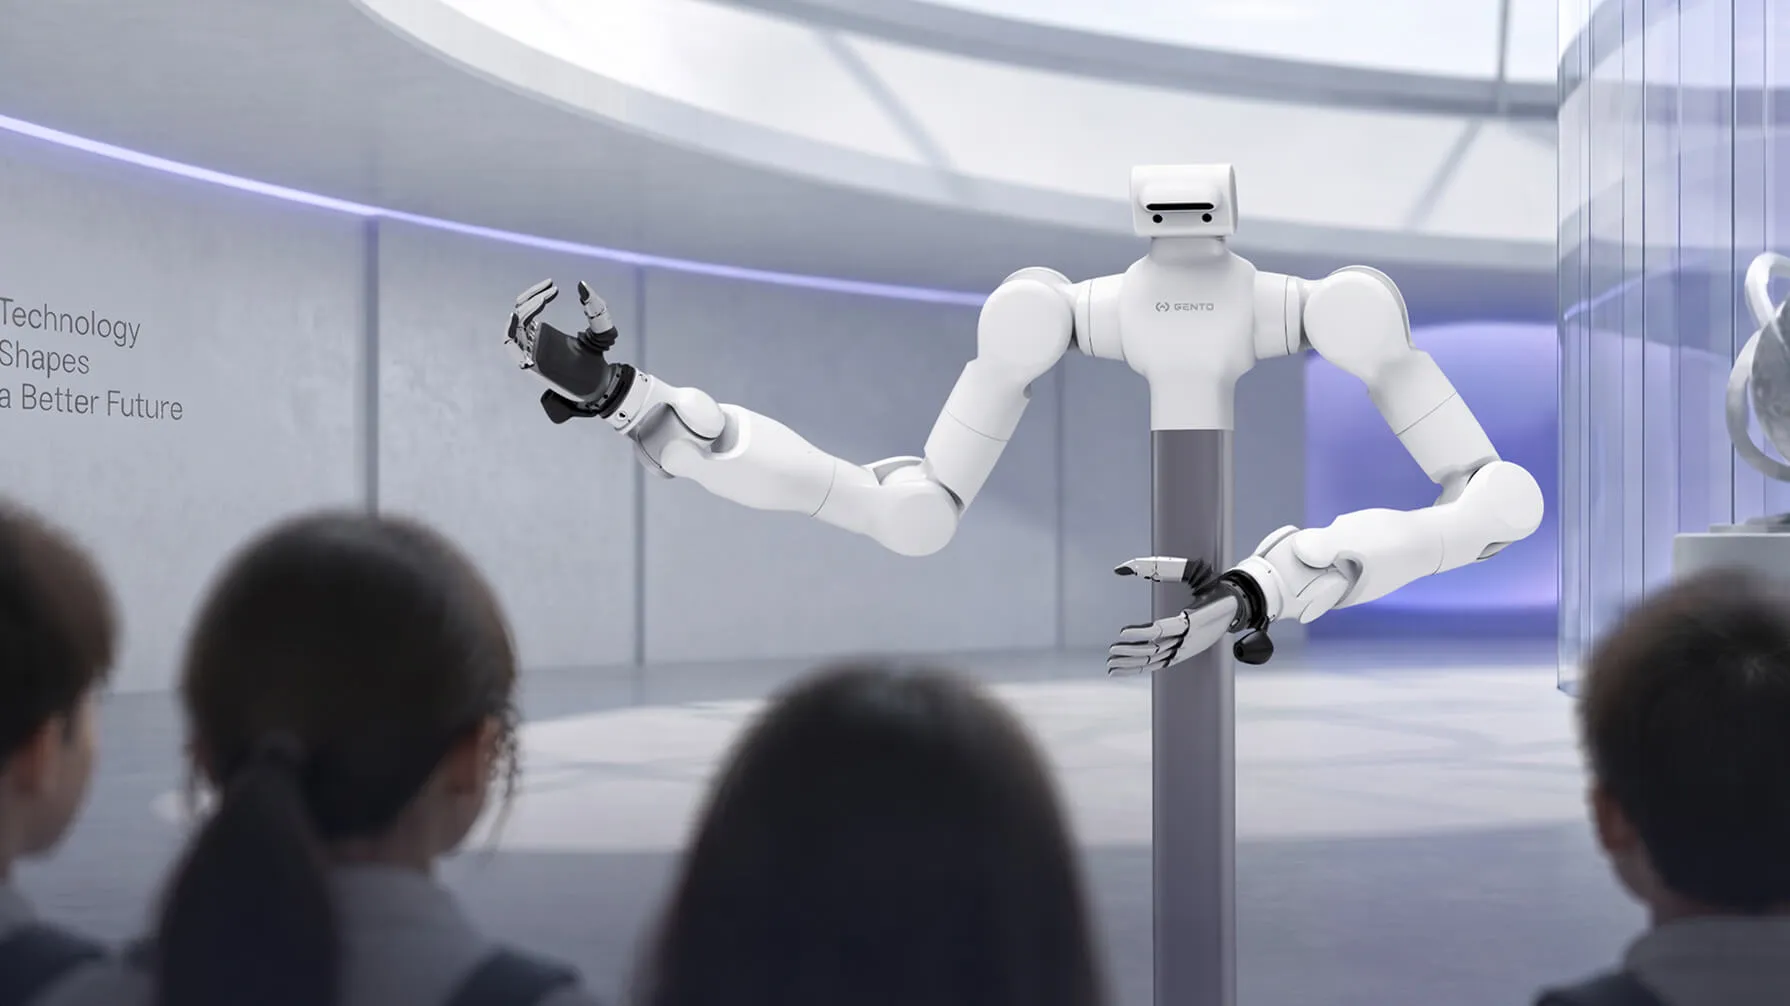 · Whole-Body Dual-Arm Force Control
· Safe Human-Robot Interaction -
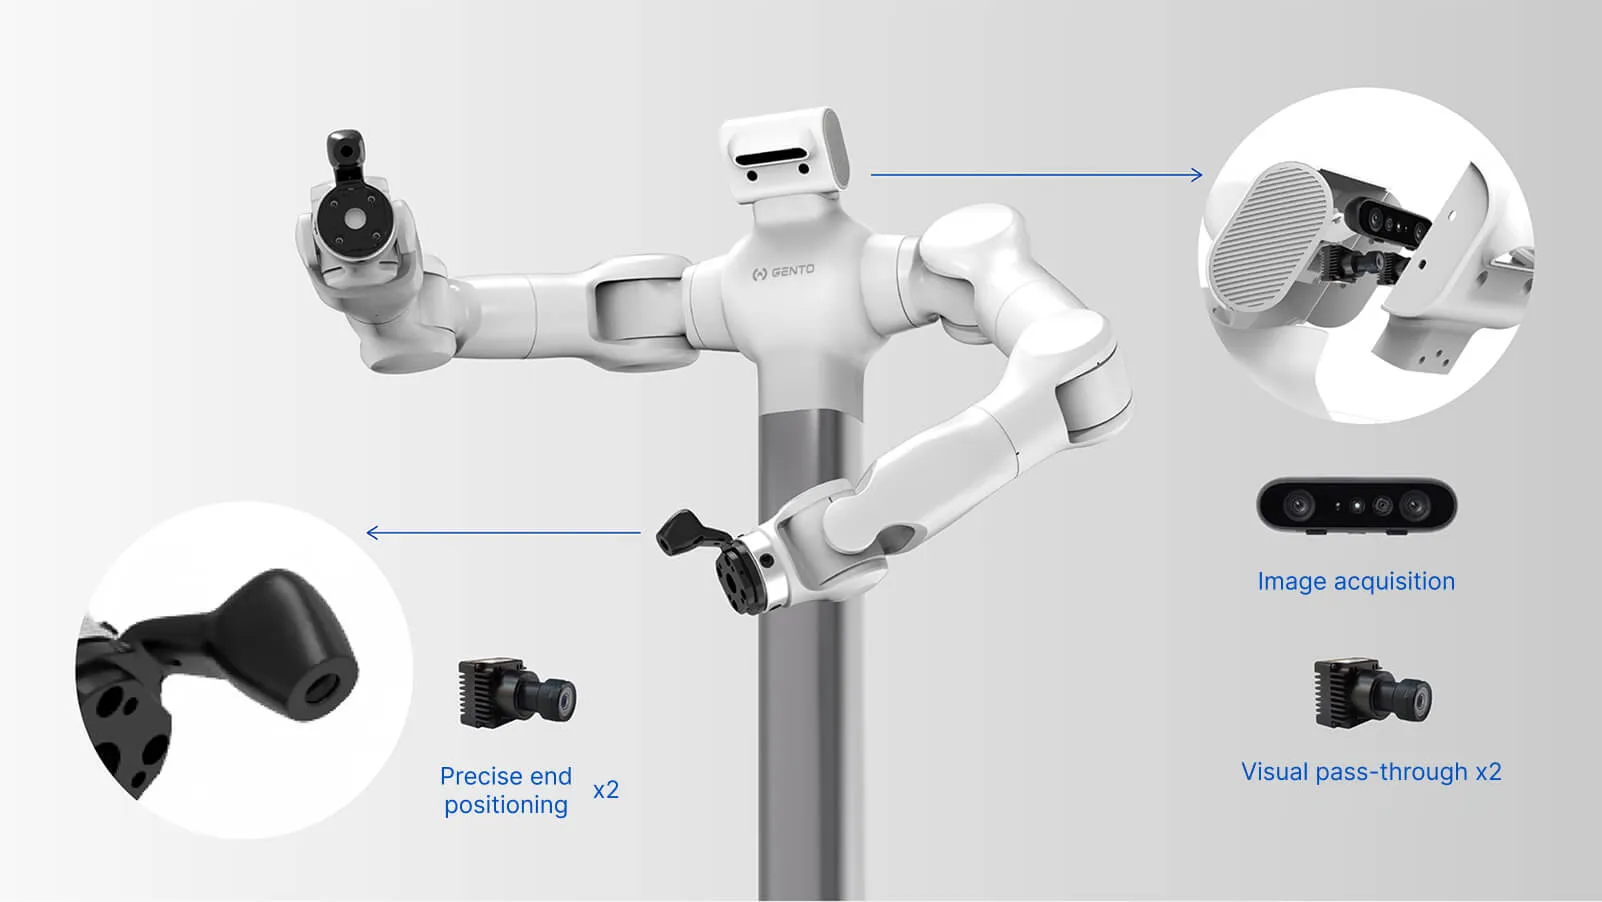
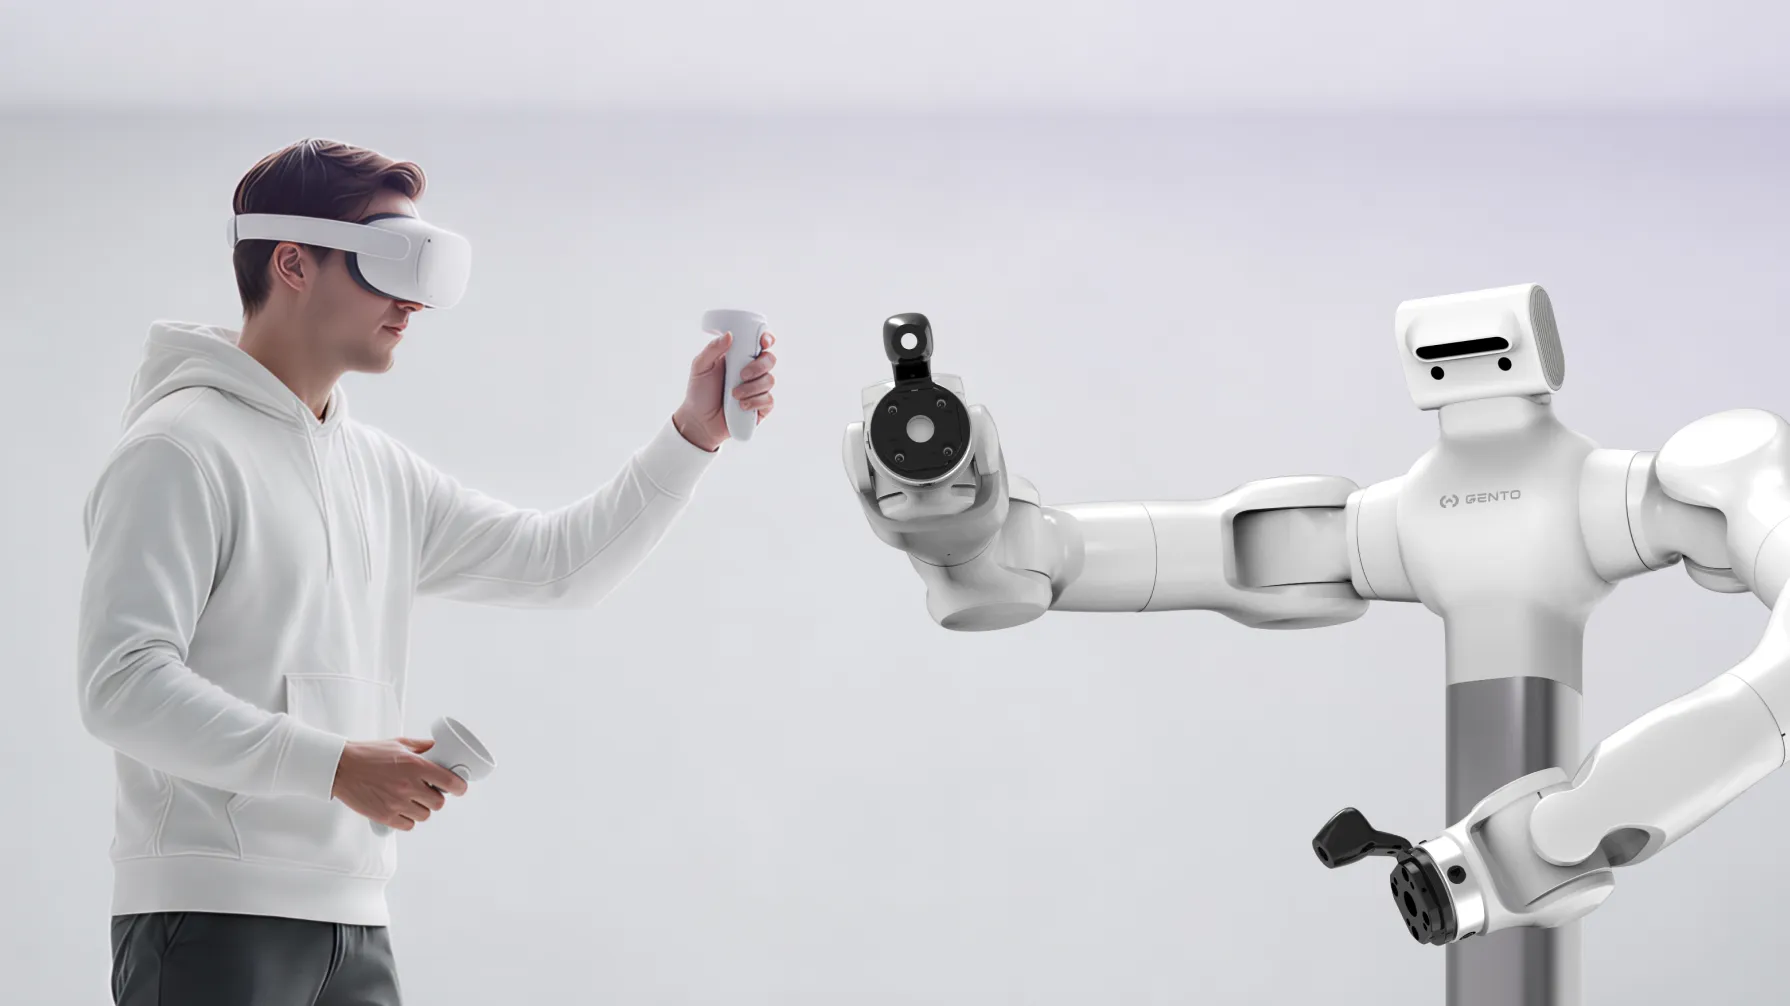 · 5-Camera Panoramic Vision
· Strong Perception -
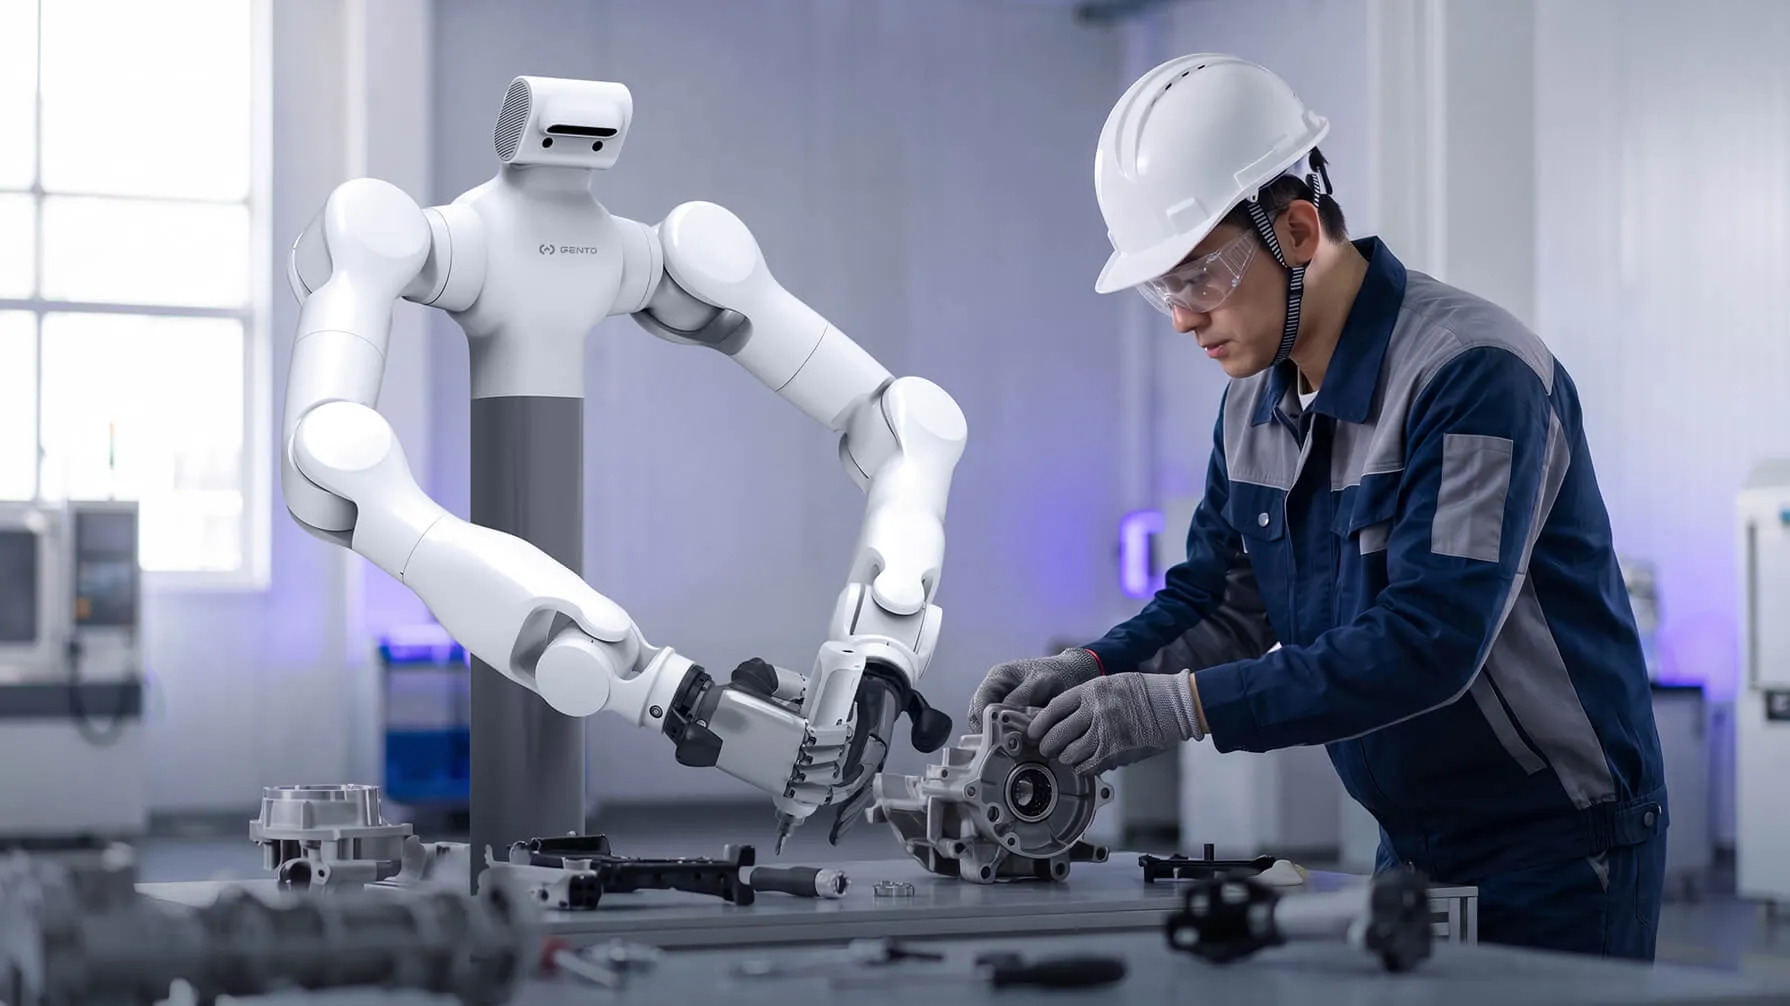 · High Computing Power
· Long-Duration Operation
Our Advantages
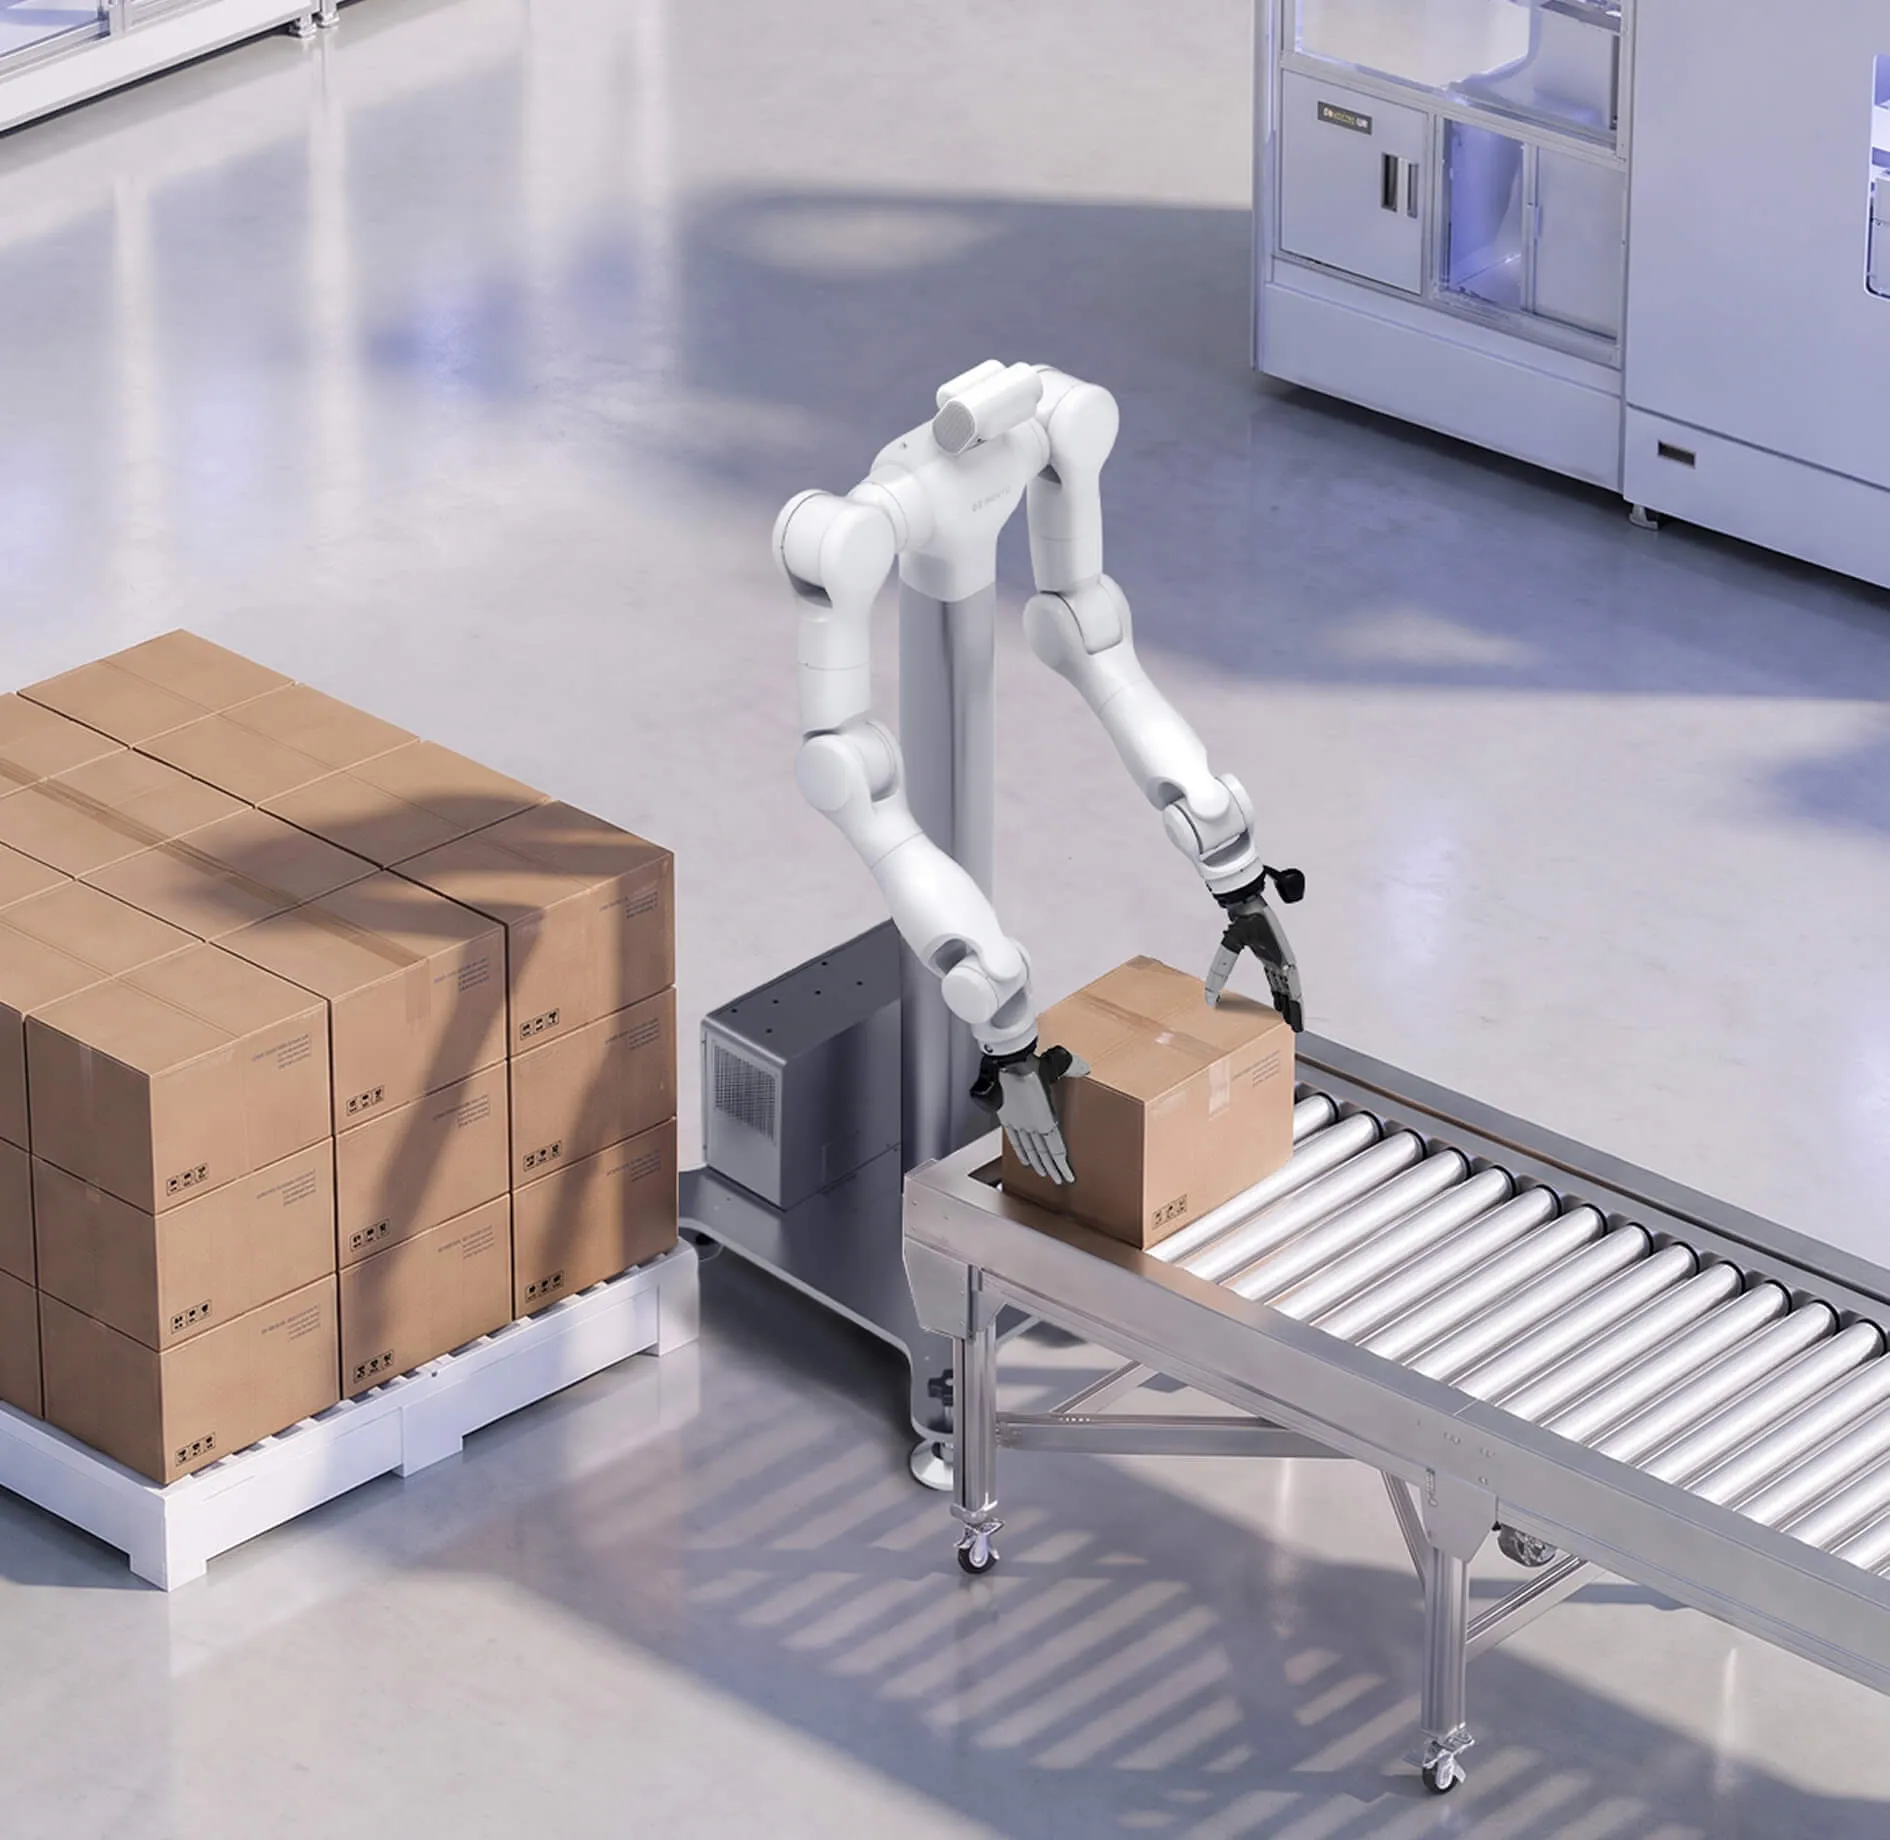
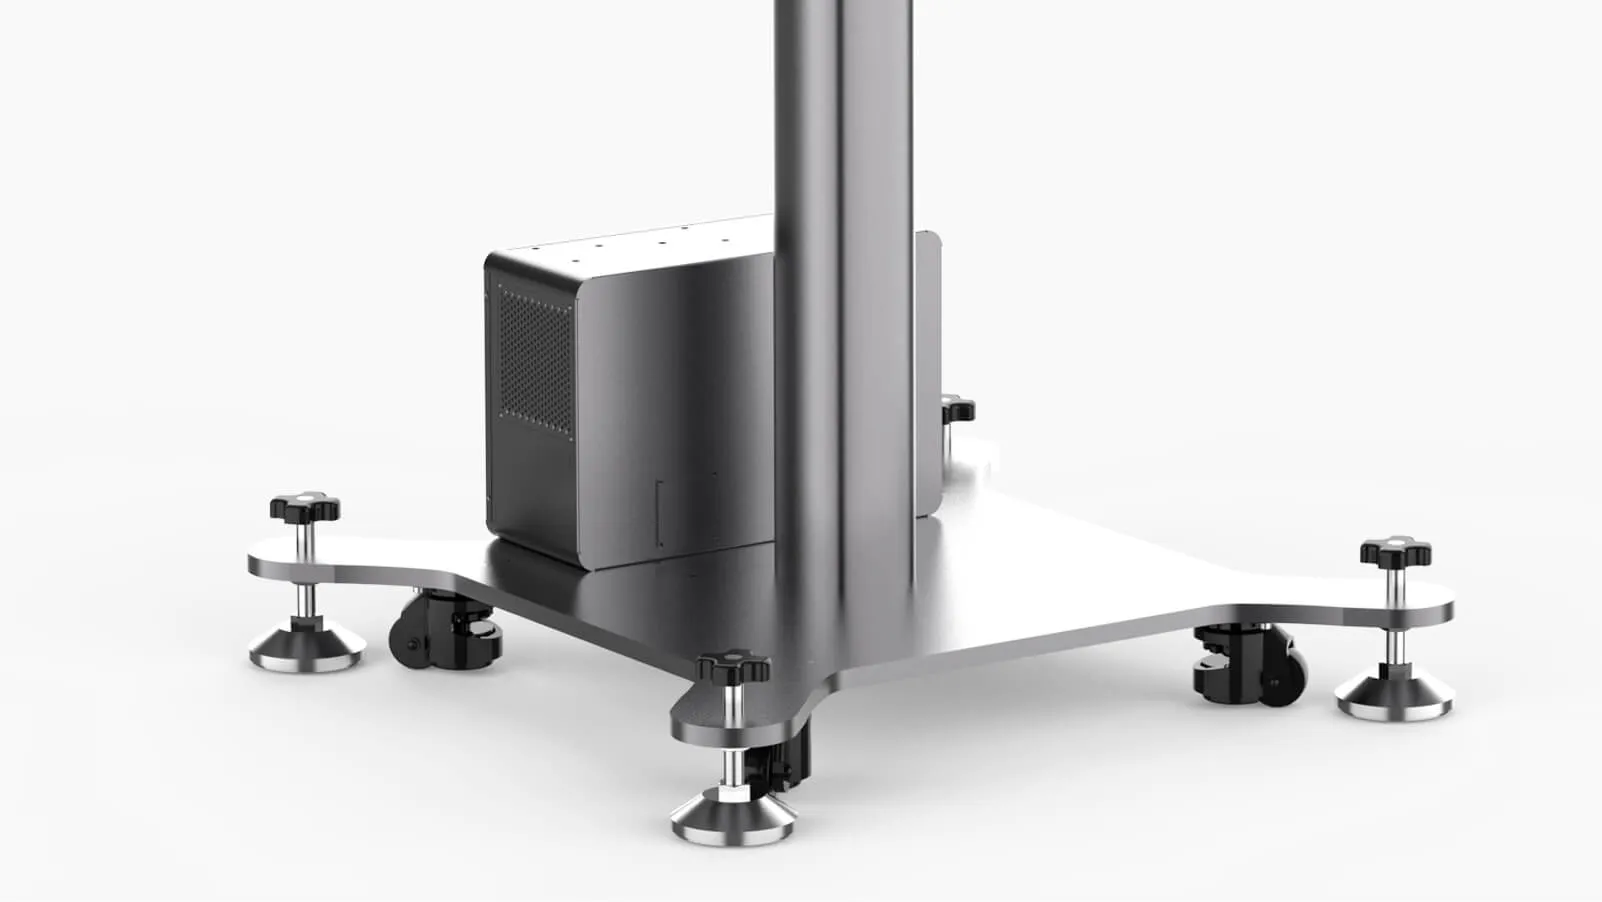
Fixed Base · High-Precision, Stable Operation
Fixed Base · High-Precision Stable Operation
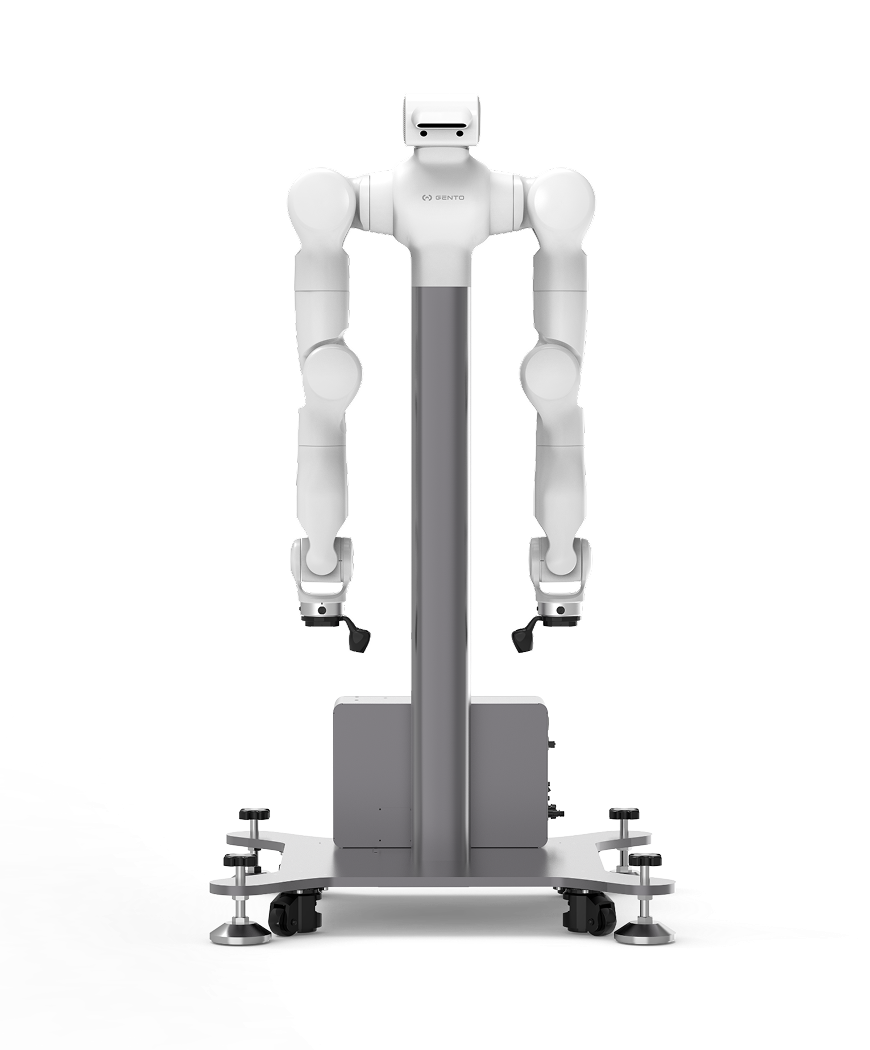
14 DoF (excluding dexterous hands) + fixed rigid stand, focused on high-precision work at fixed stations.
Dual-Arm Force Control · Safe Human-Robot Interaction
dual arms with full force control, up to 6 kg per arm, ±0.03 mm repeatability, stiffness auto-reduced on collision.
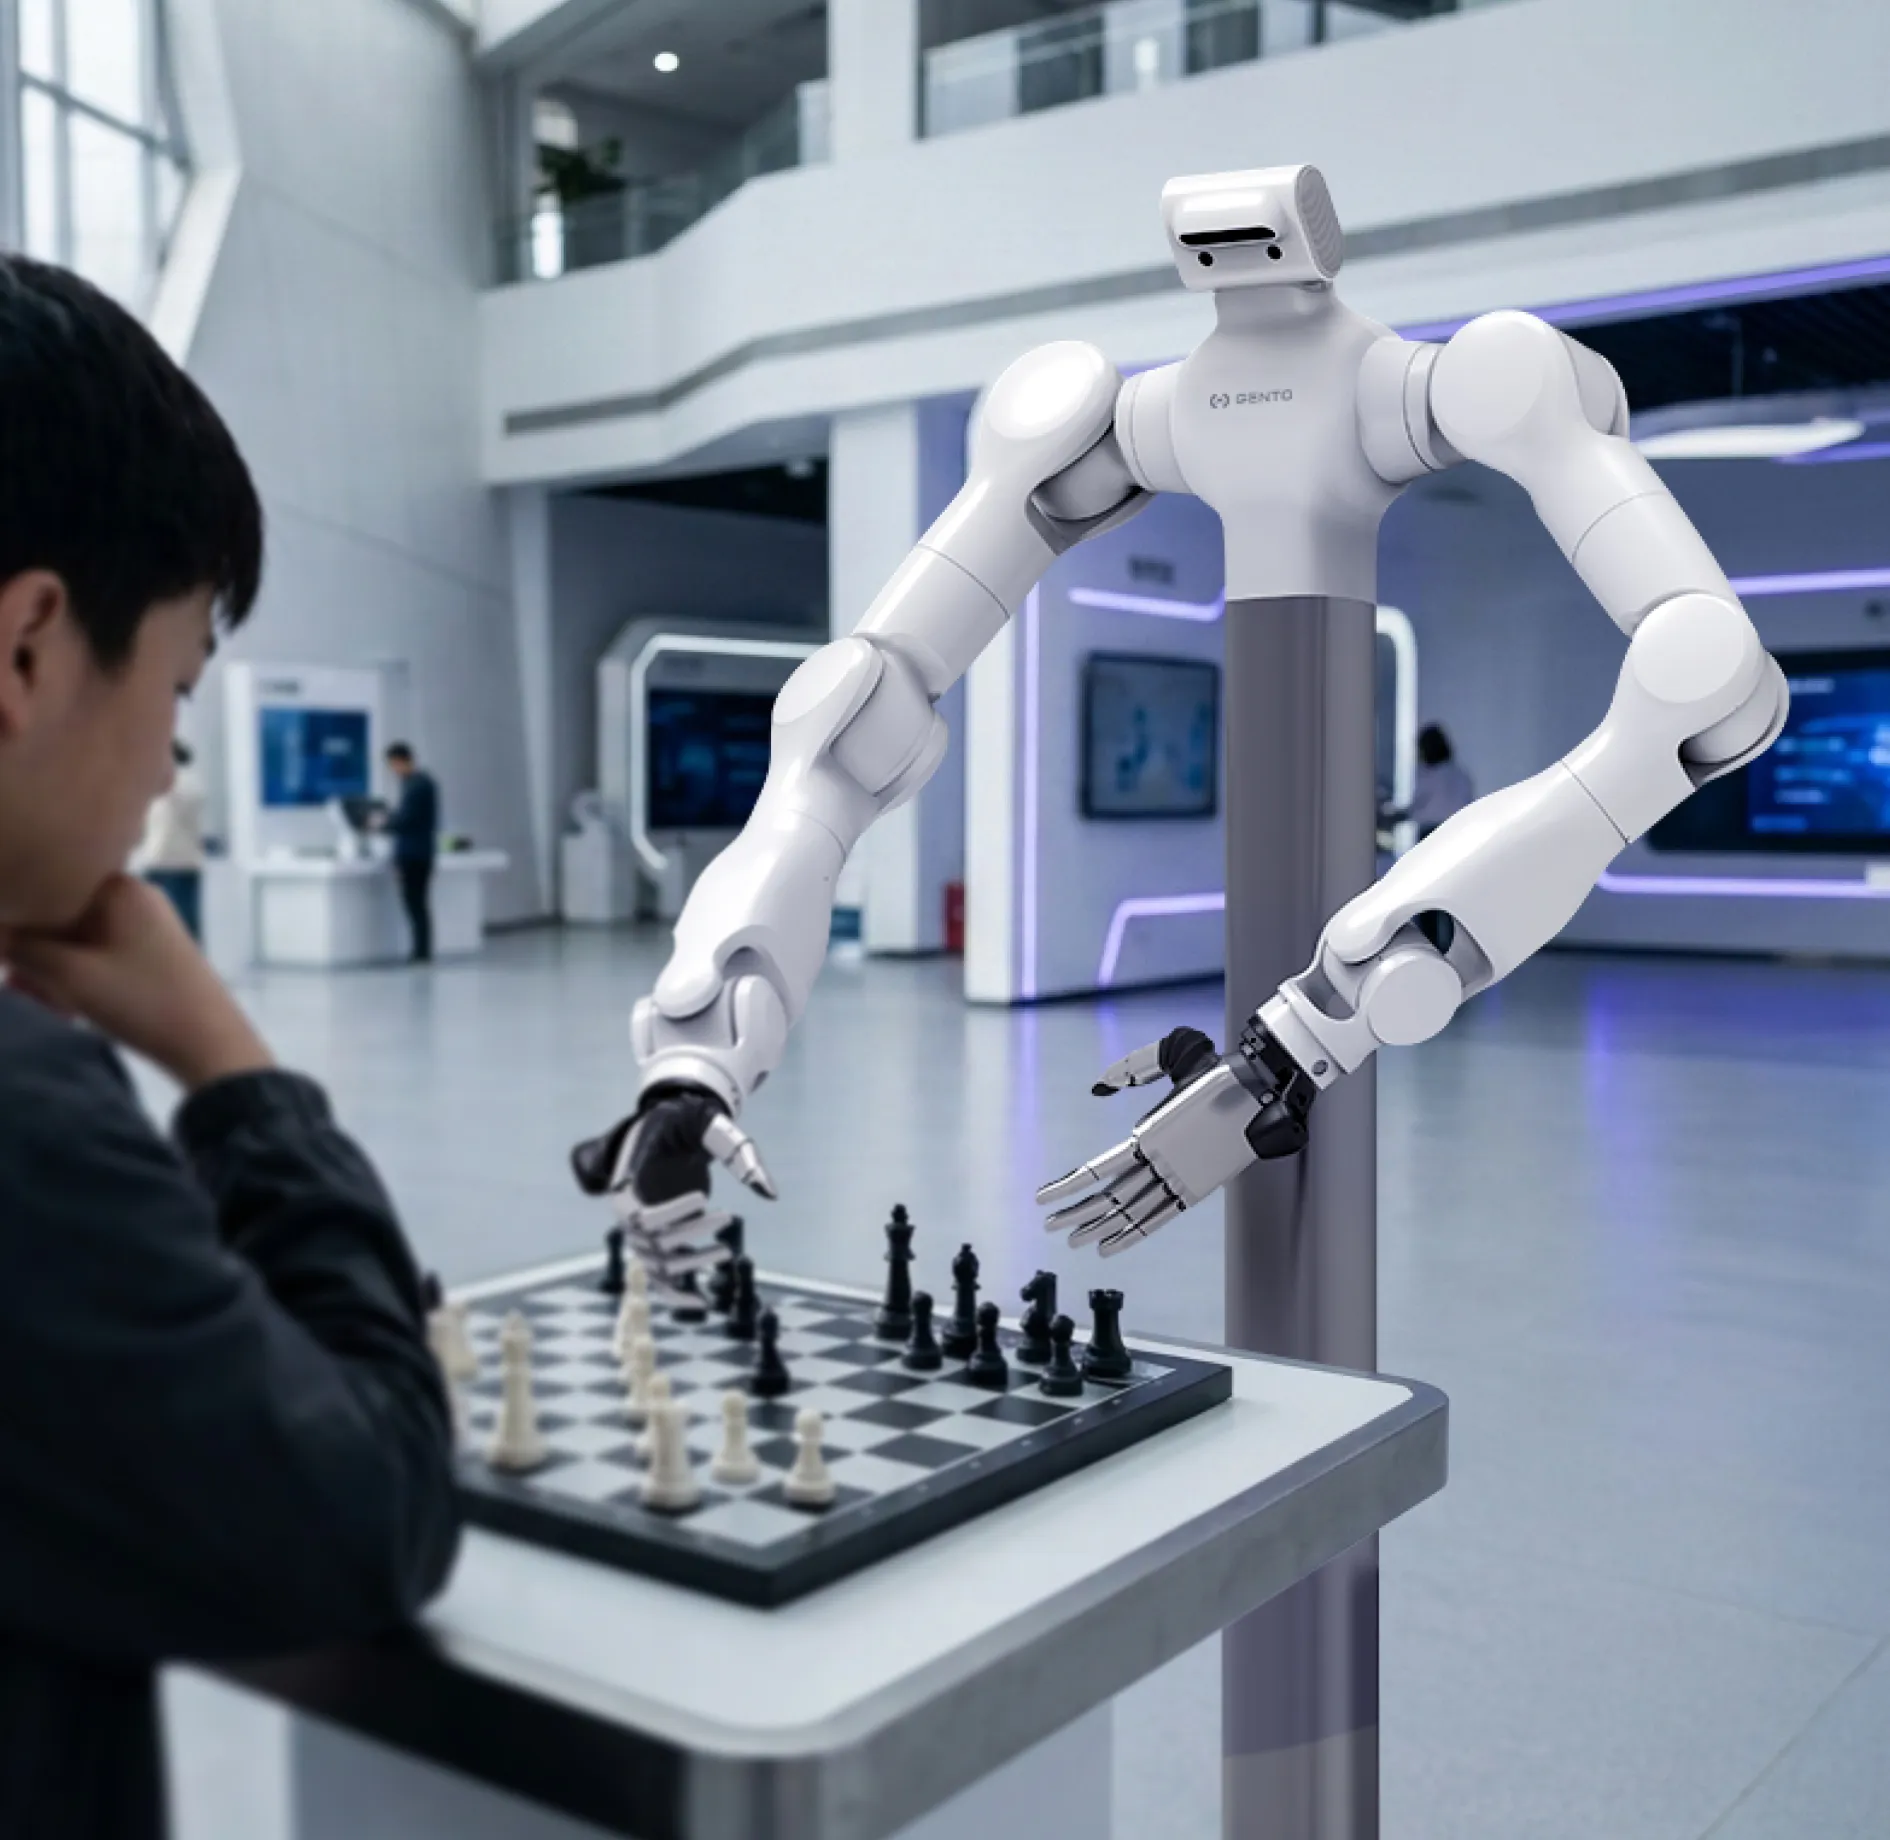
Whole-Body Dual-Arm Force Control · Safe Human-Robot Interaction
A paradigm shift from position control to force and impedance control
Dual arms come standard with full force control; single-arm rated payload up to 6 kg
Repeat positioning accuracy: ±0.03 mm
On collision, joint stiffness is automatically reduced to ensure safe human-robot collaboration
Human-like, compliant motion—no abrupt starts/stops or jitter
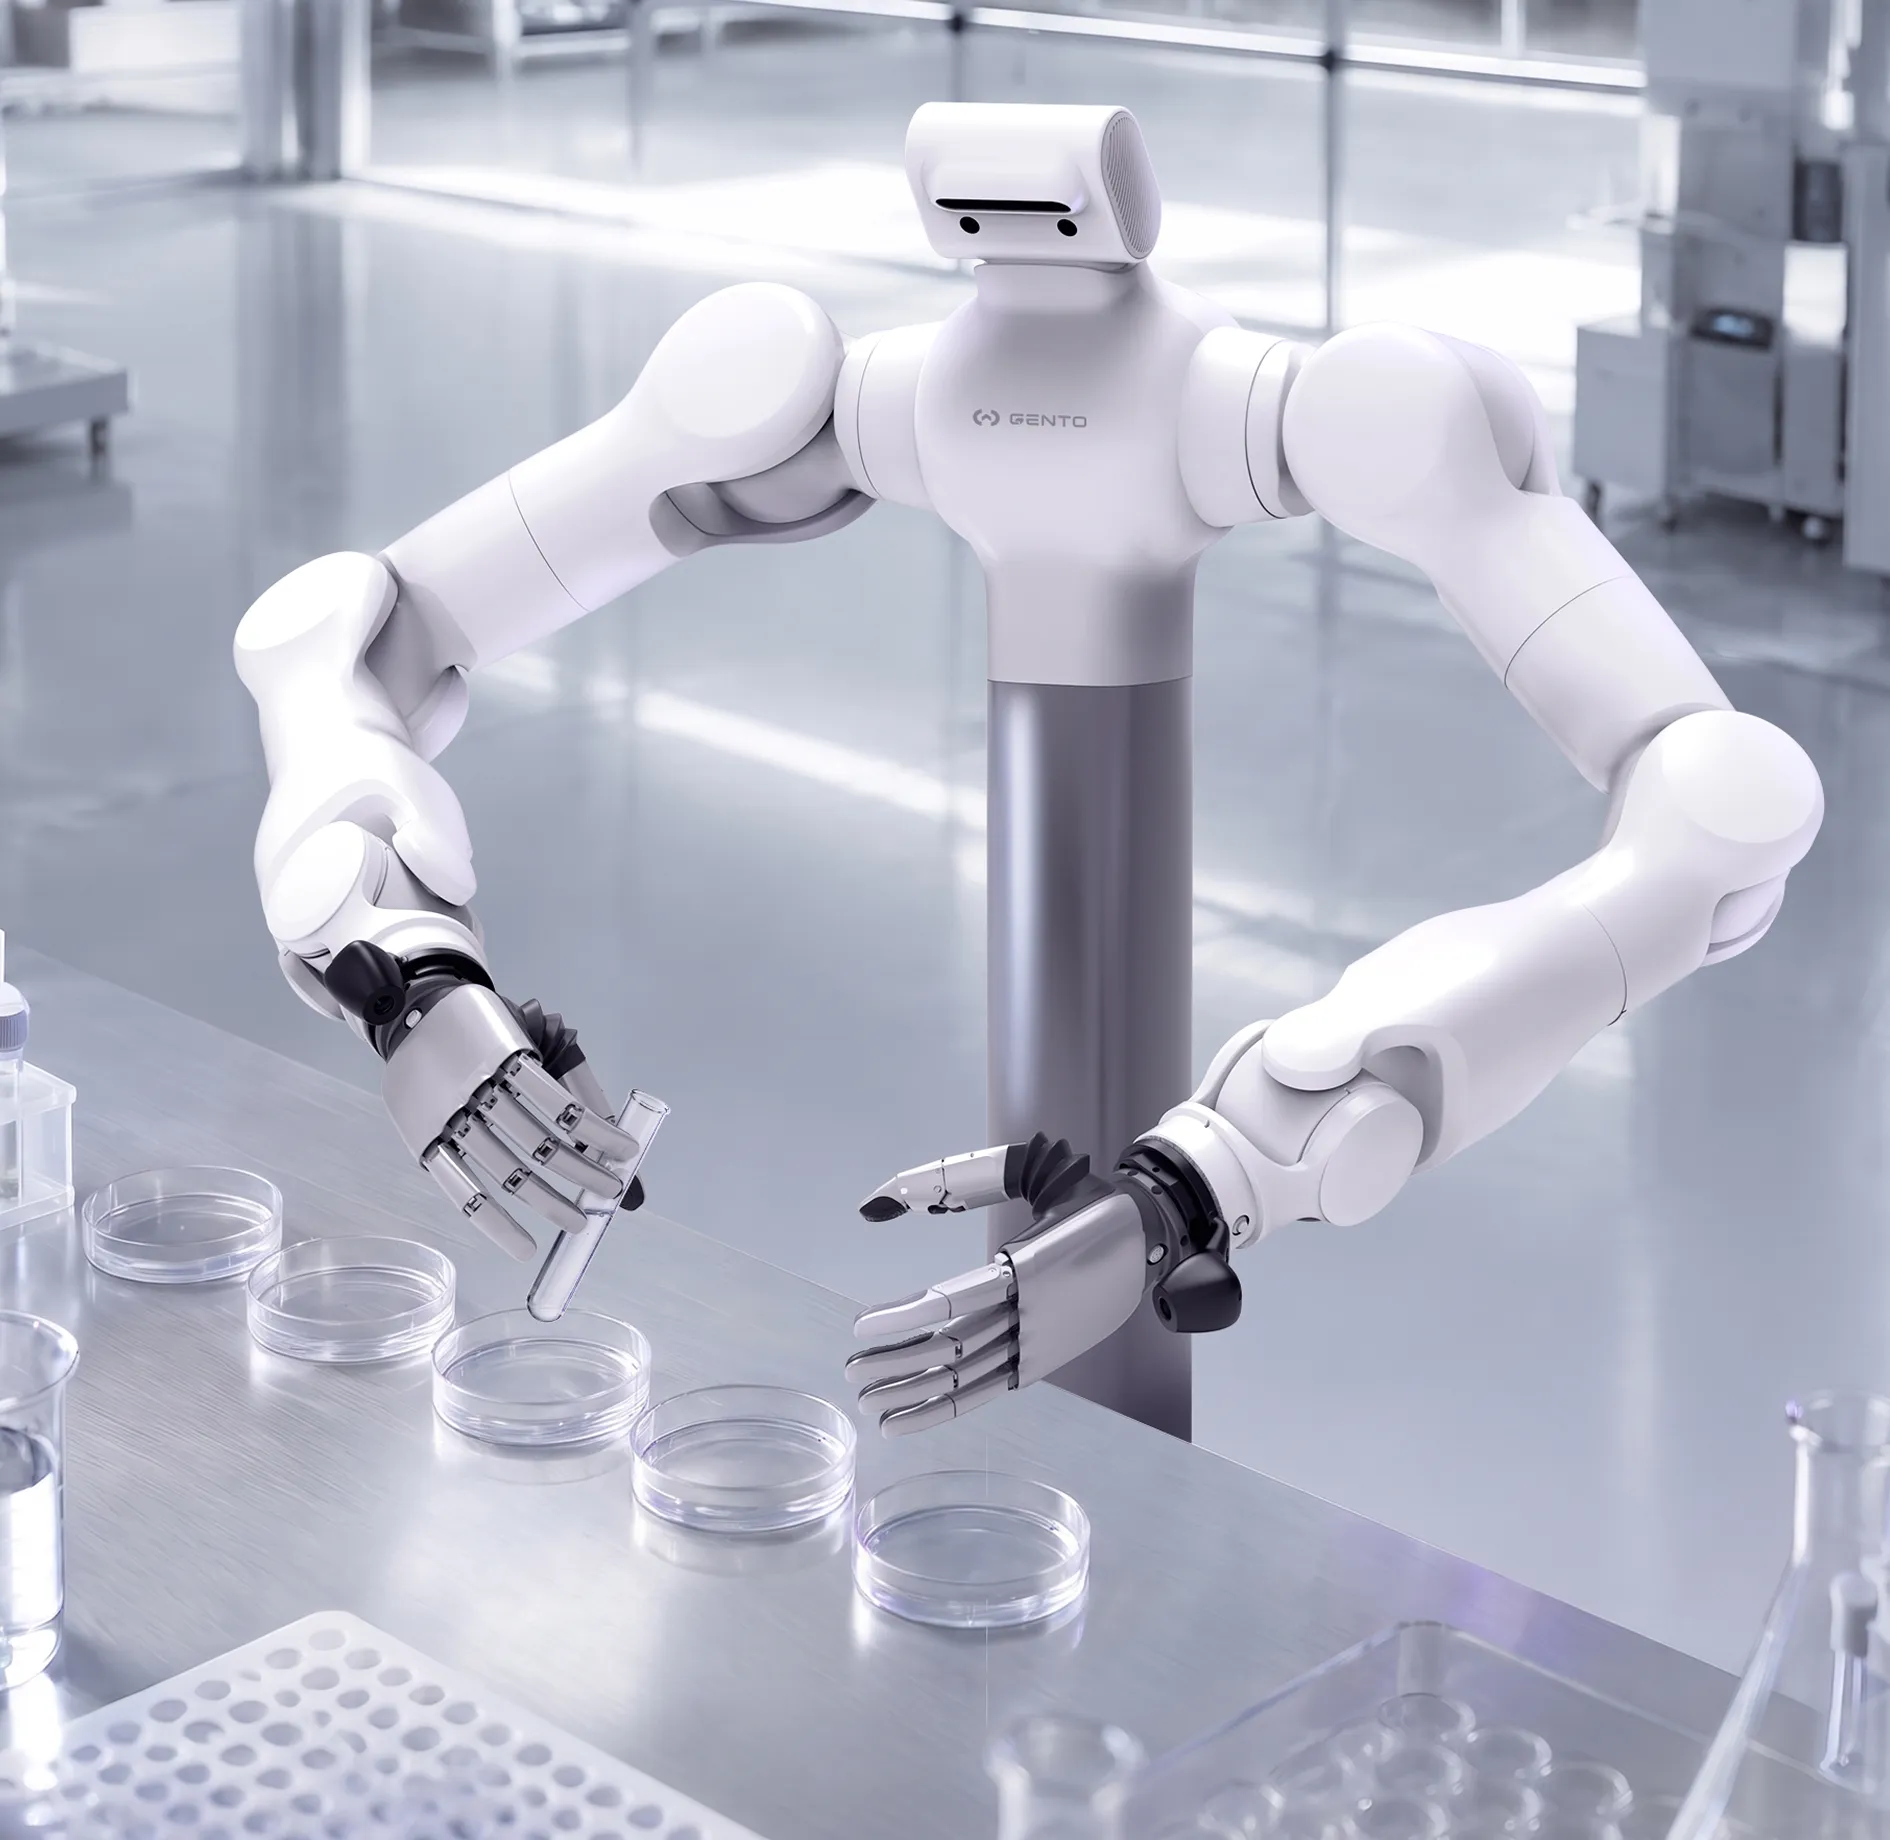
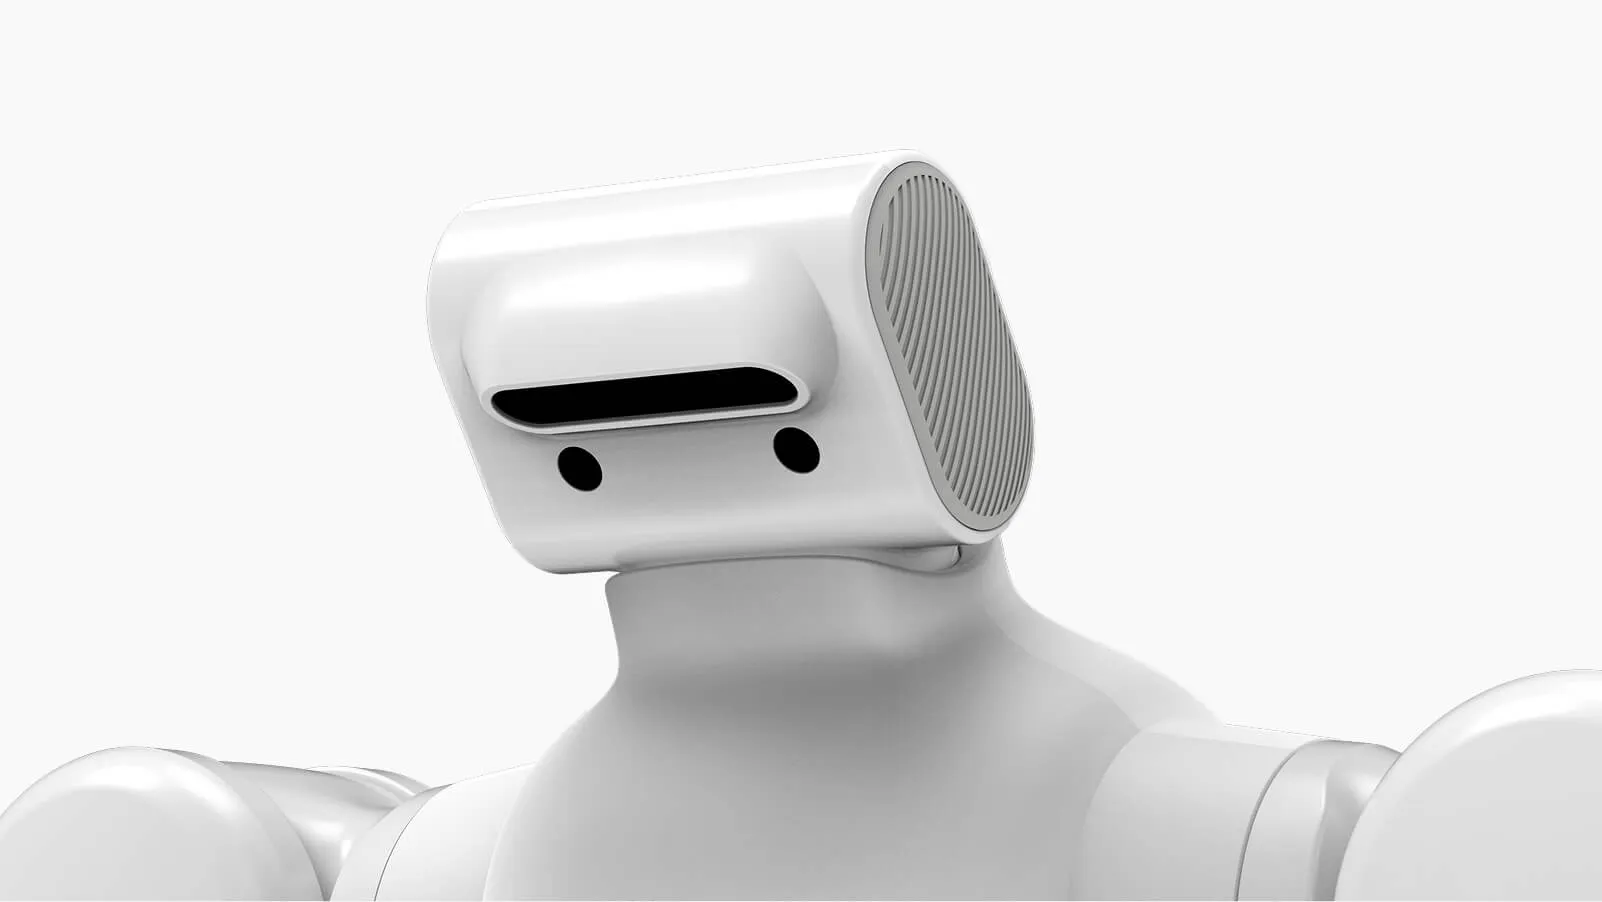
5-Camera Panoramic Vision
head D435 RGB-D ×1 + SH5WG RGB ×2; wrist SH5WG RGB or D405GA ×2 — standard on all units.
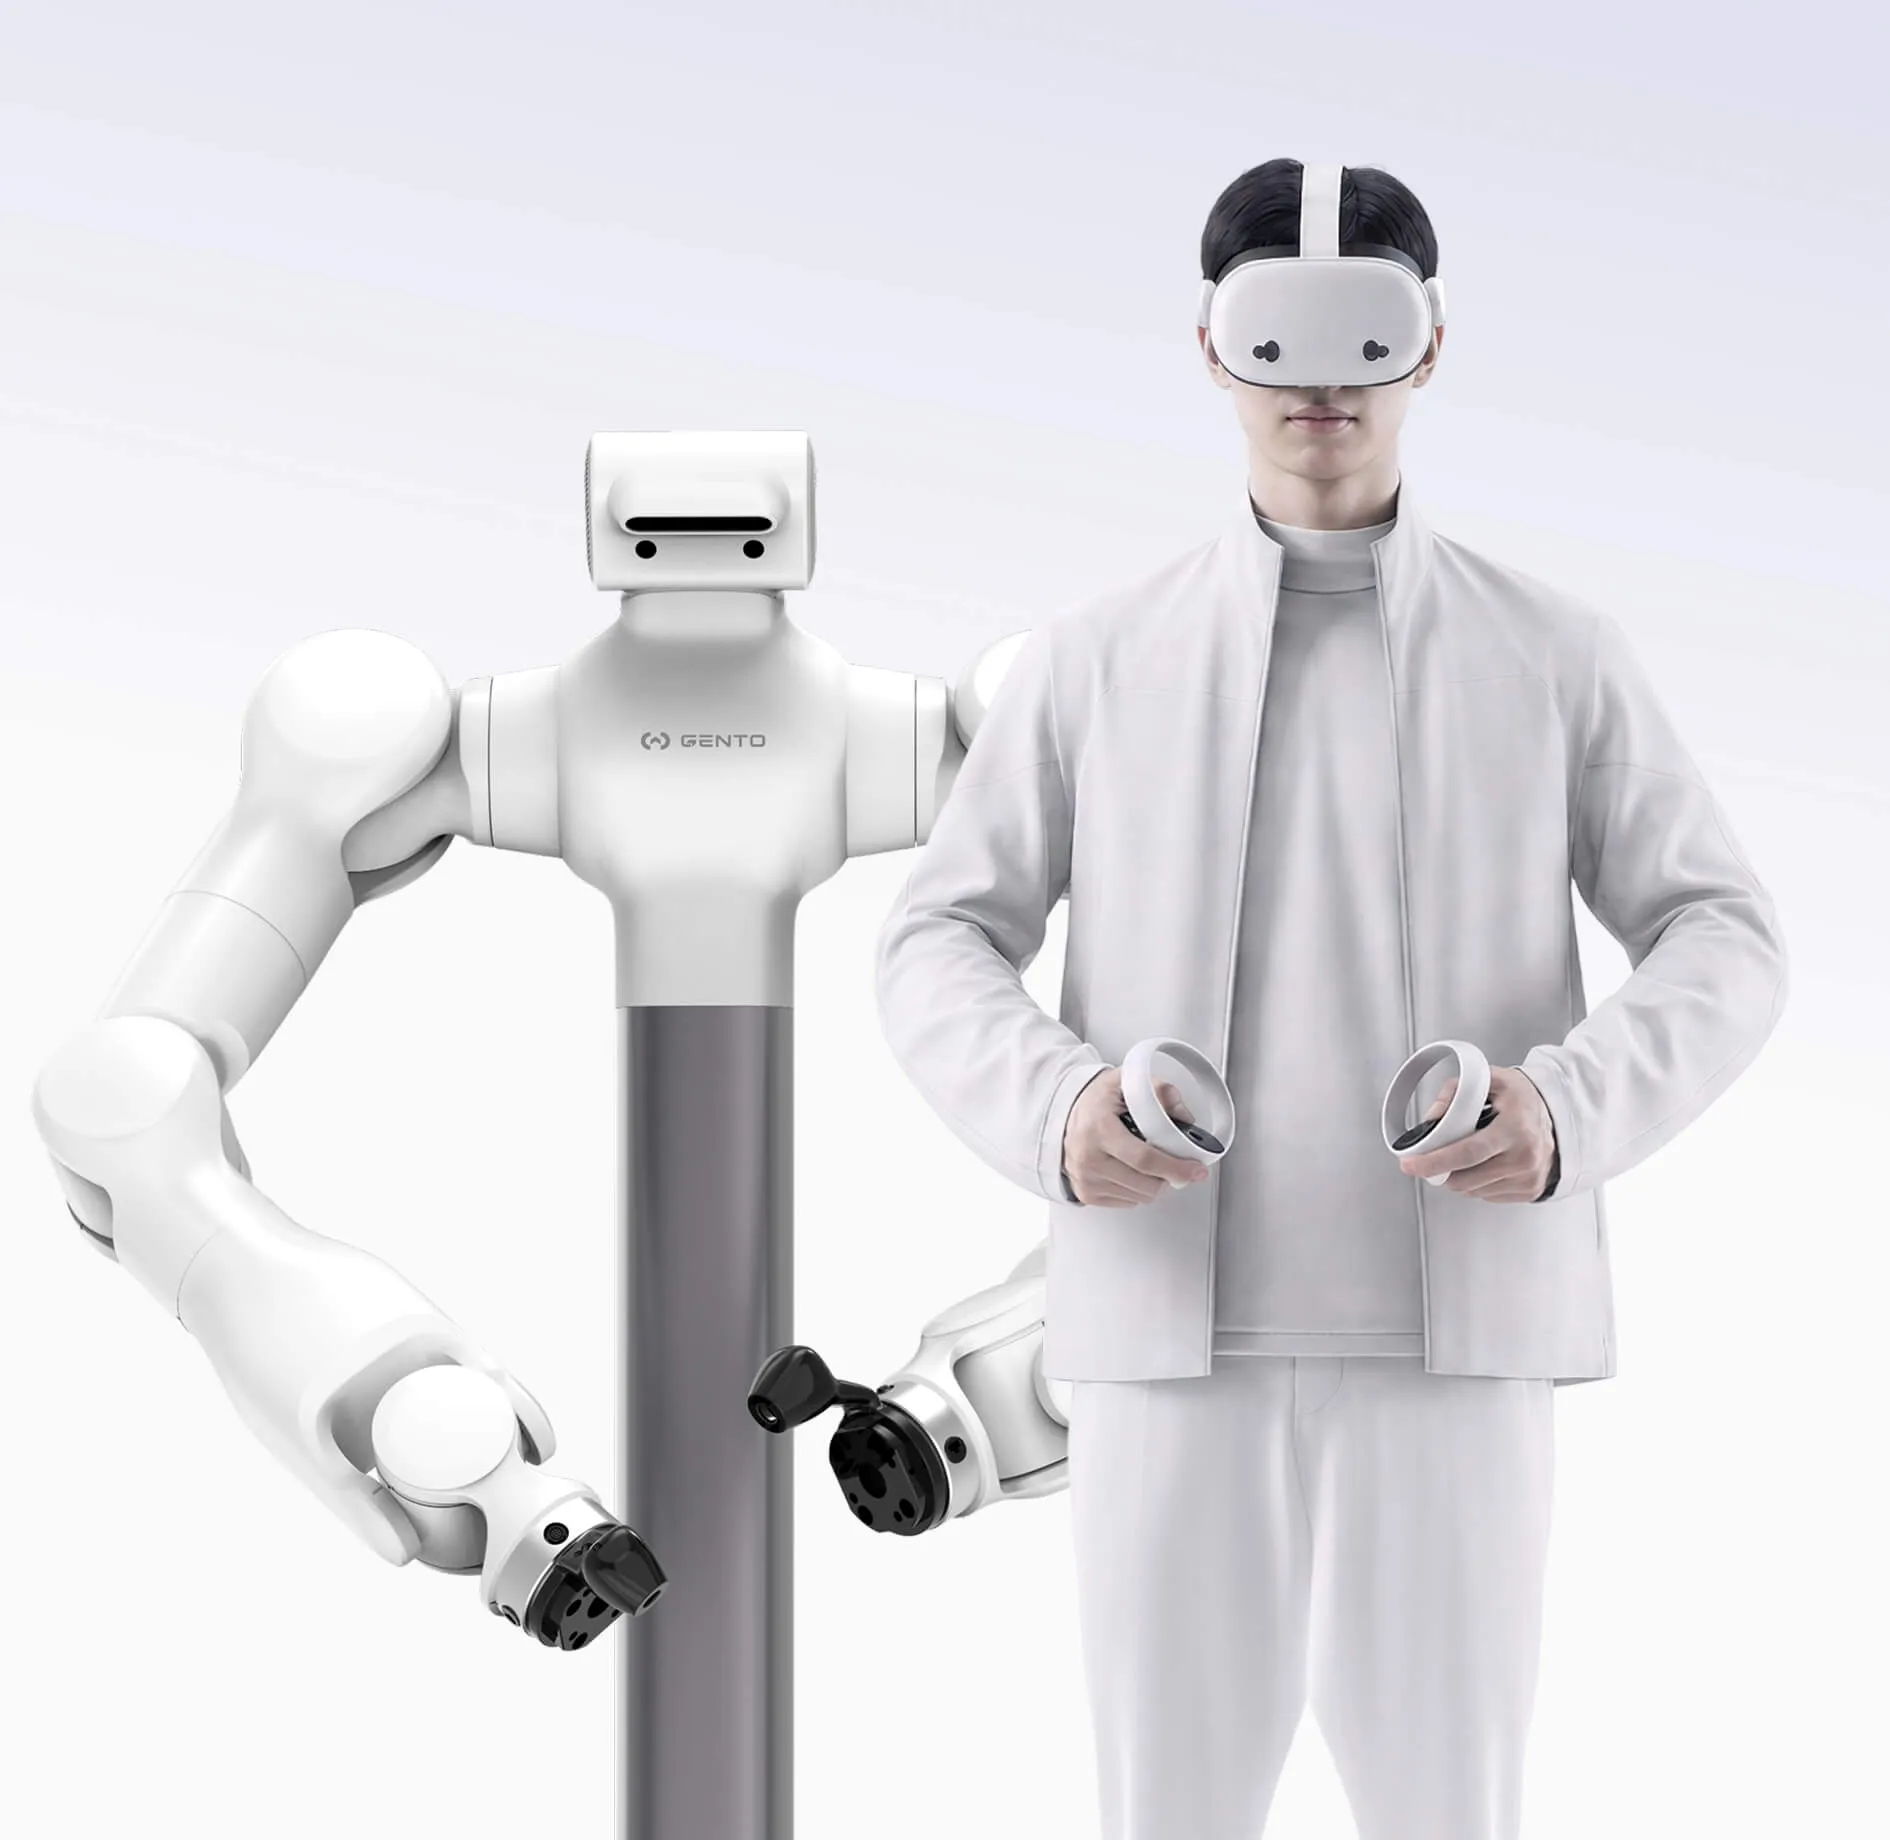
VR Teleoperation & Data Collection(KernalMind-Apex)
VR headset + data gloves; ROS2; GStreamer RTSP (8554/8555); MCAP alignment; LeRobot conversion; latency ≤100 ms.
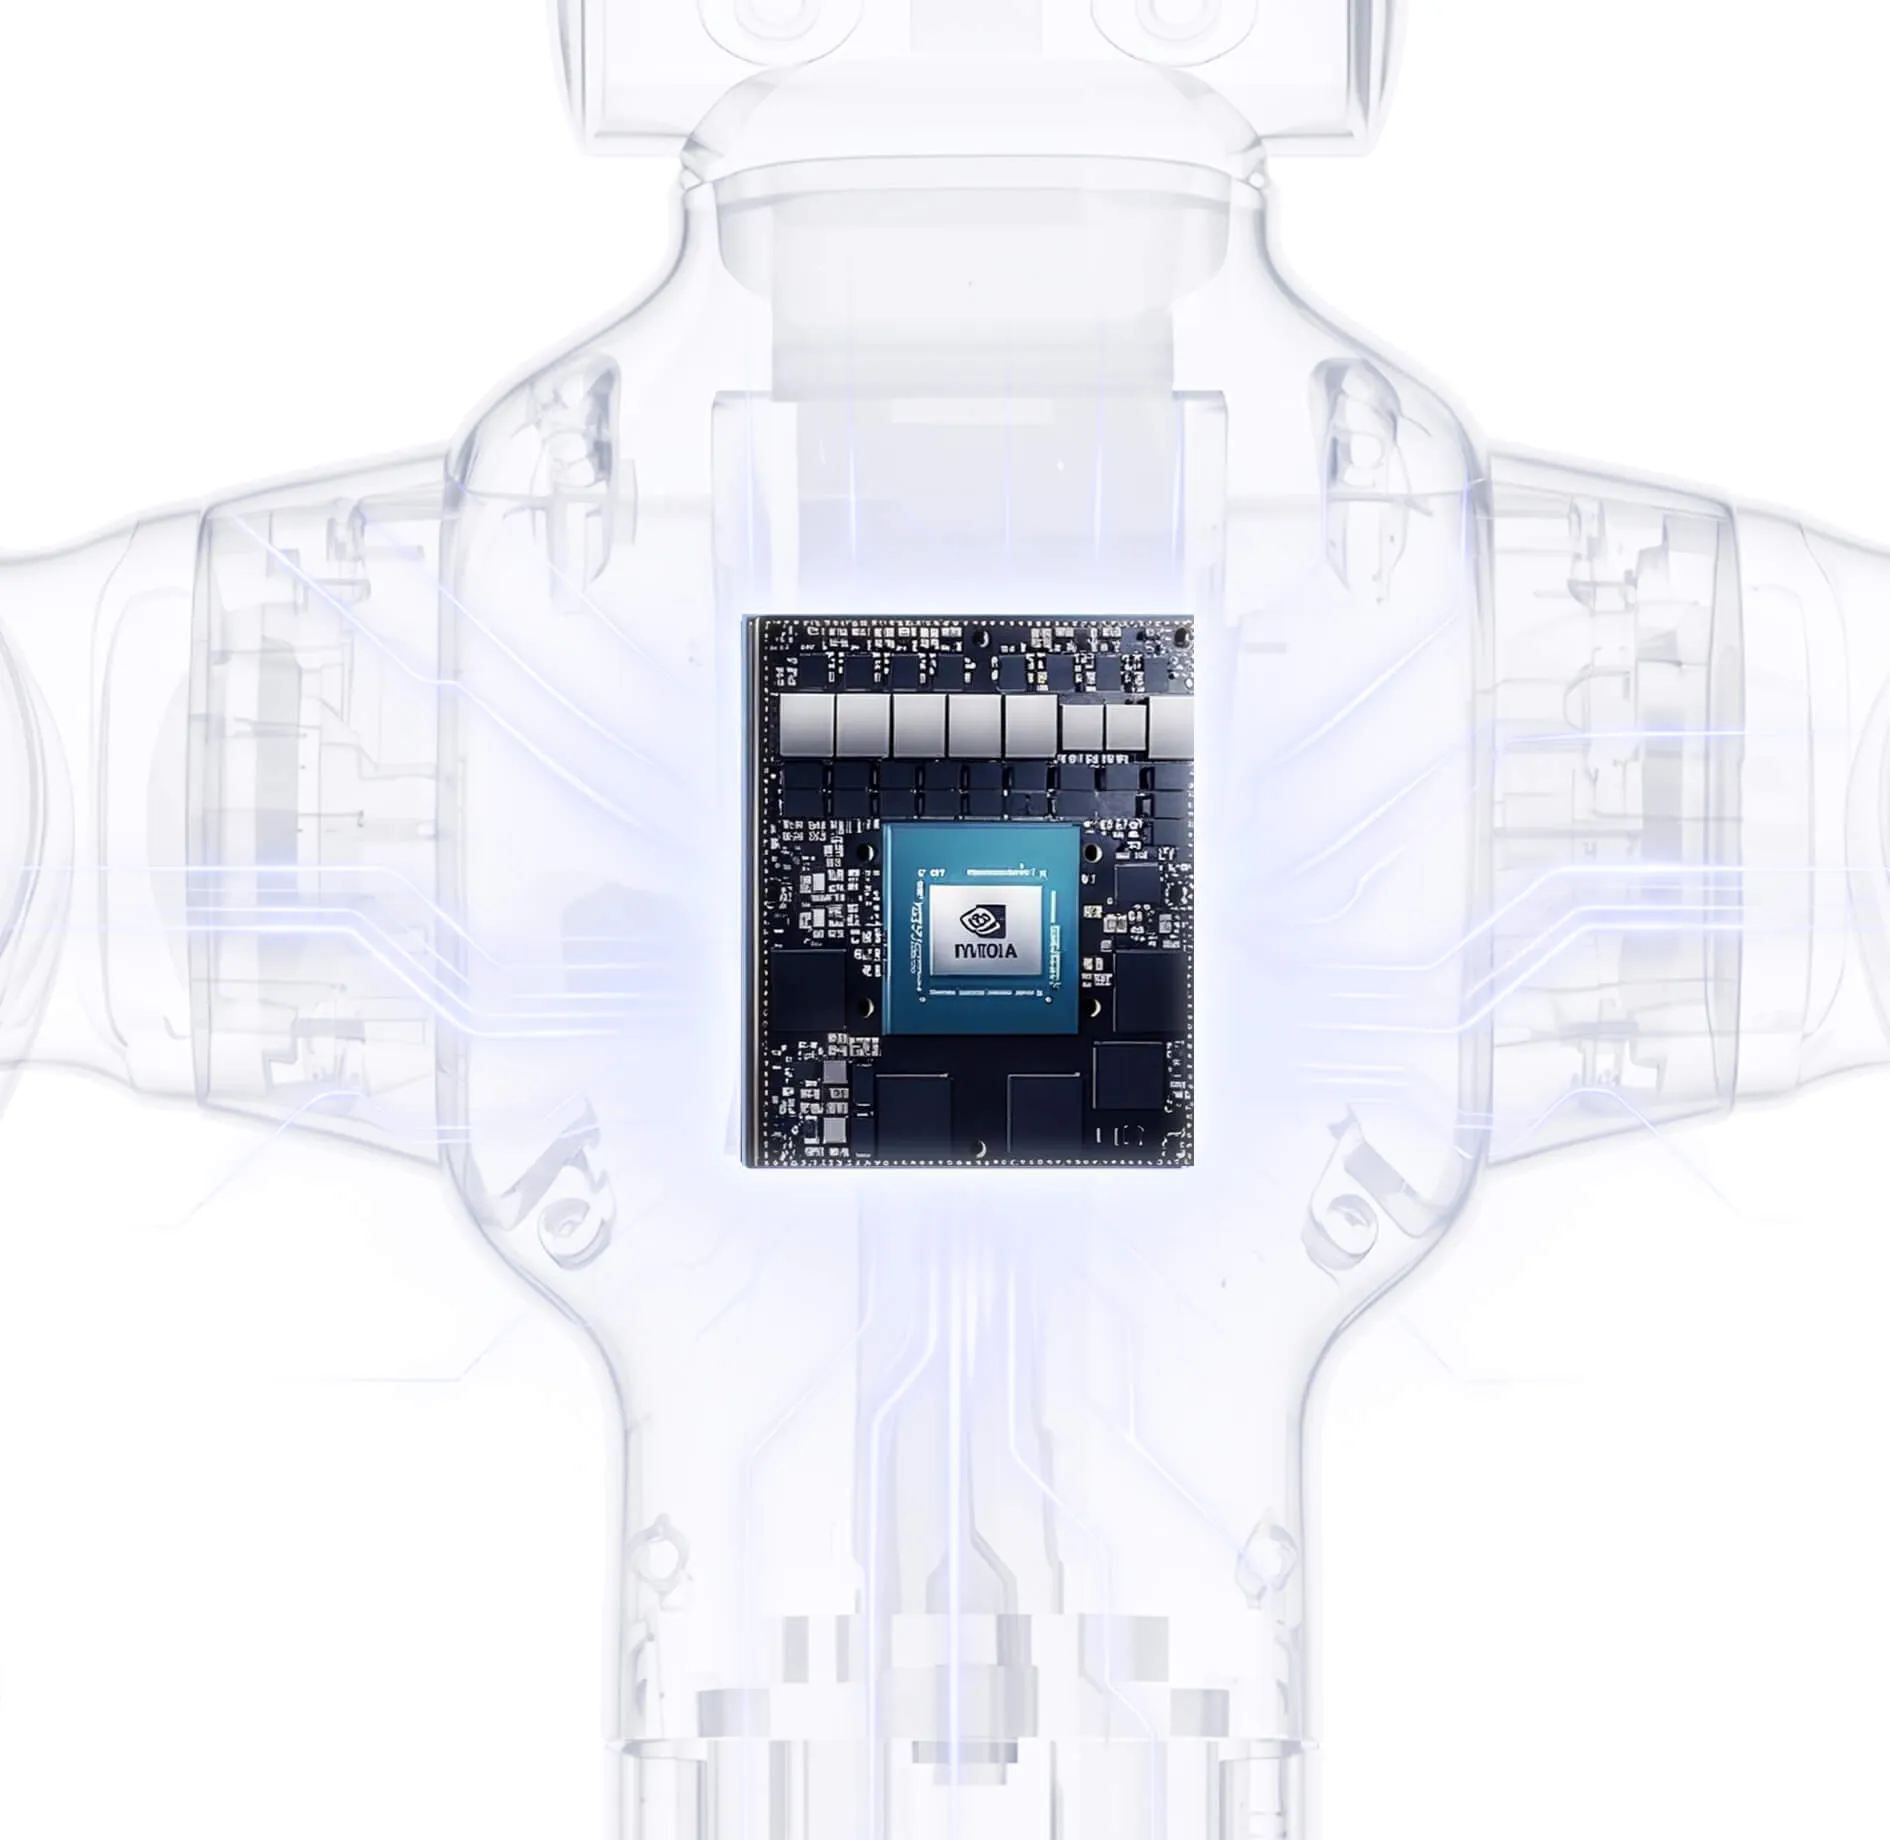
Compute Platform
NVIDIA Jetson Orin 64G (275 TOPS) (Standard)
NVIDIA Jetson Thor T5000 1TB (2070 TFLOPS) (Optional)
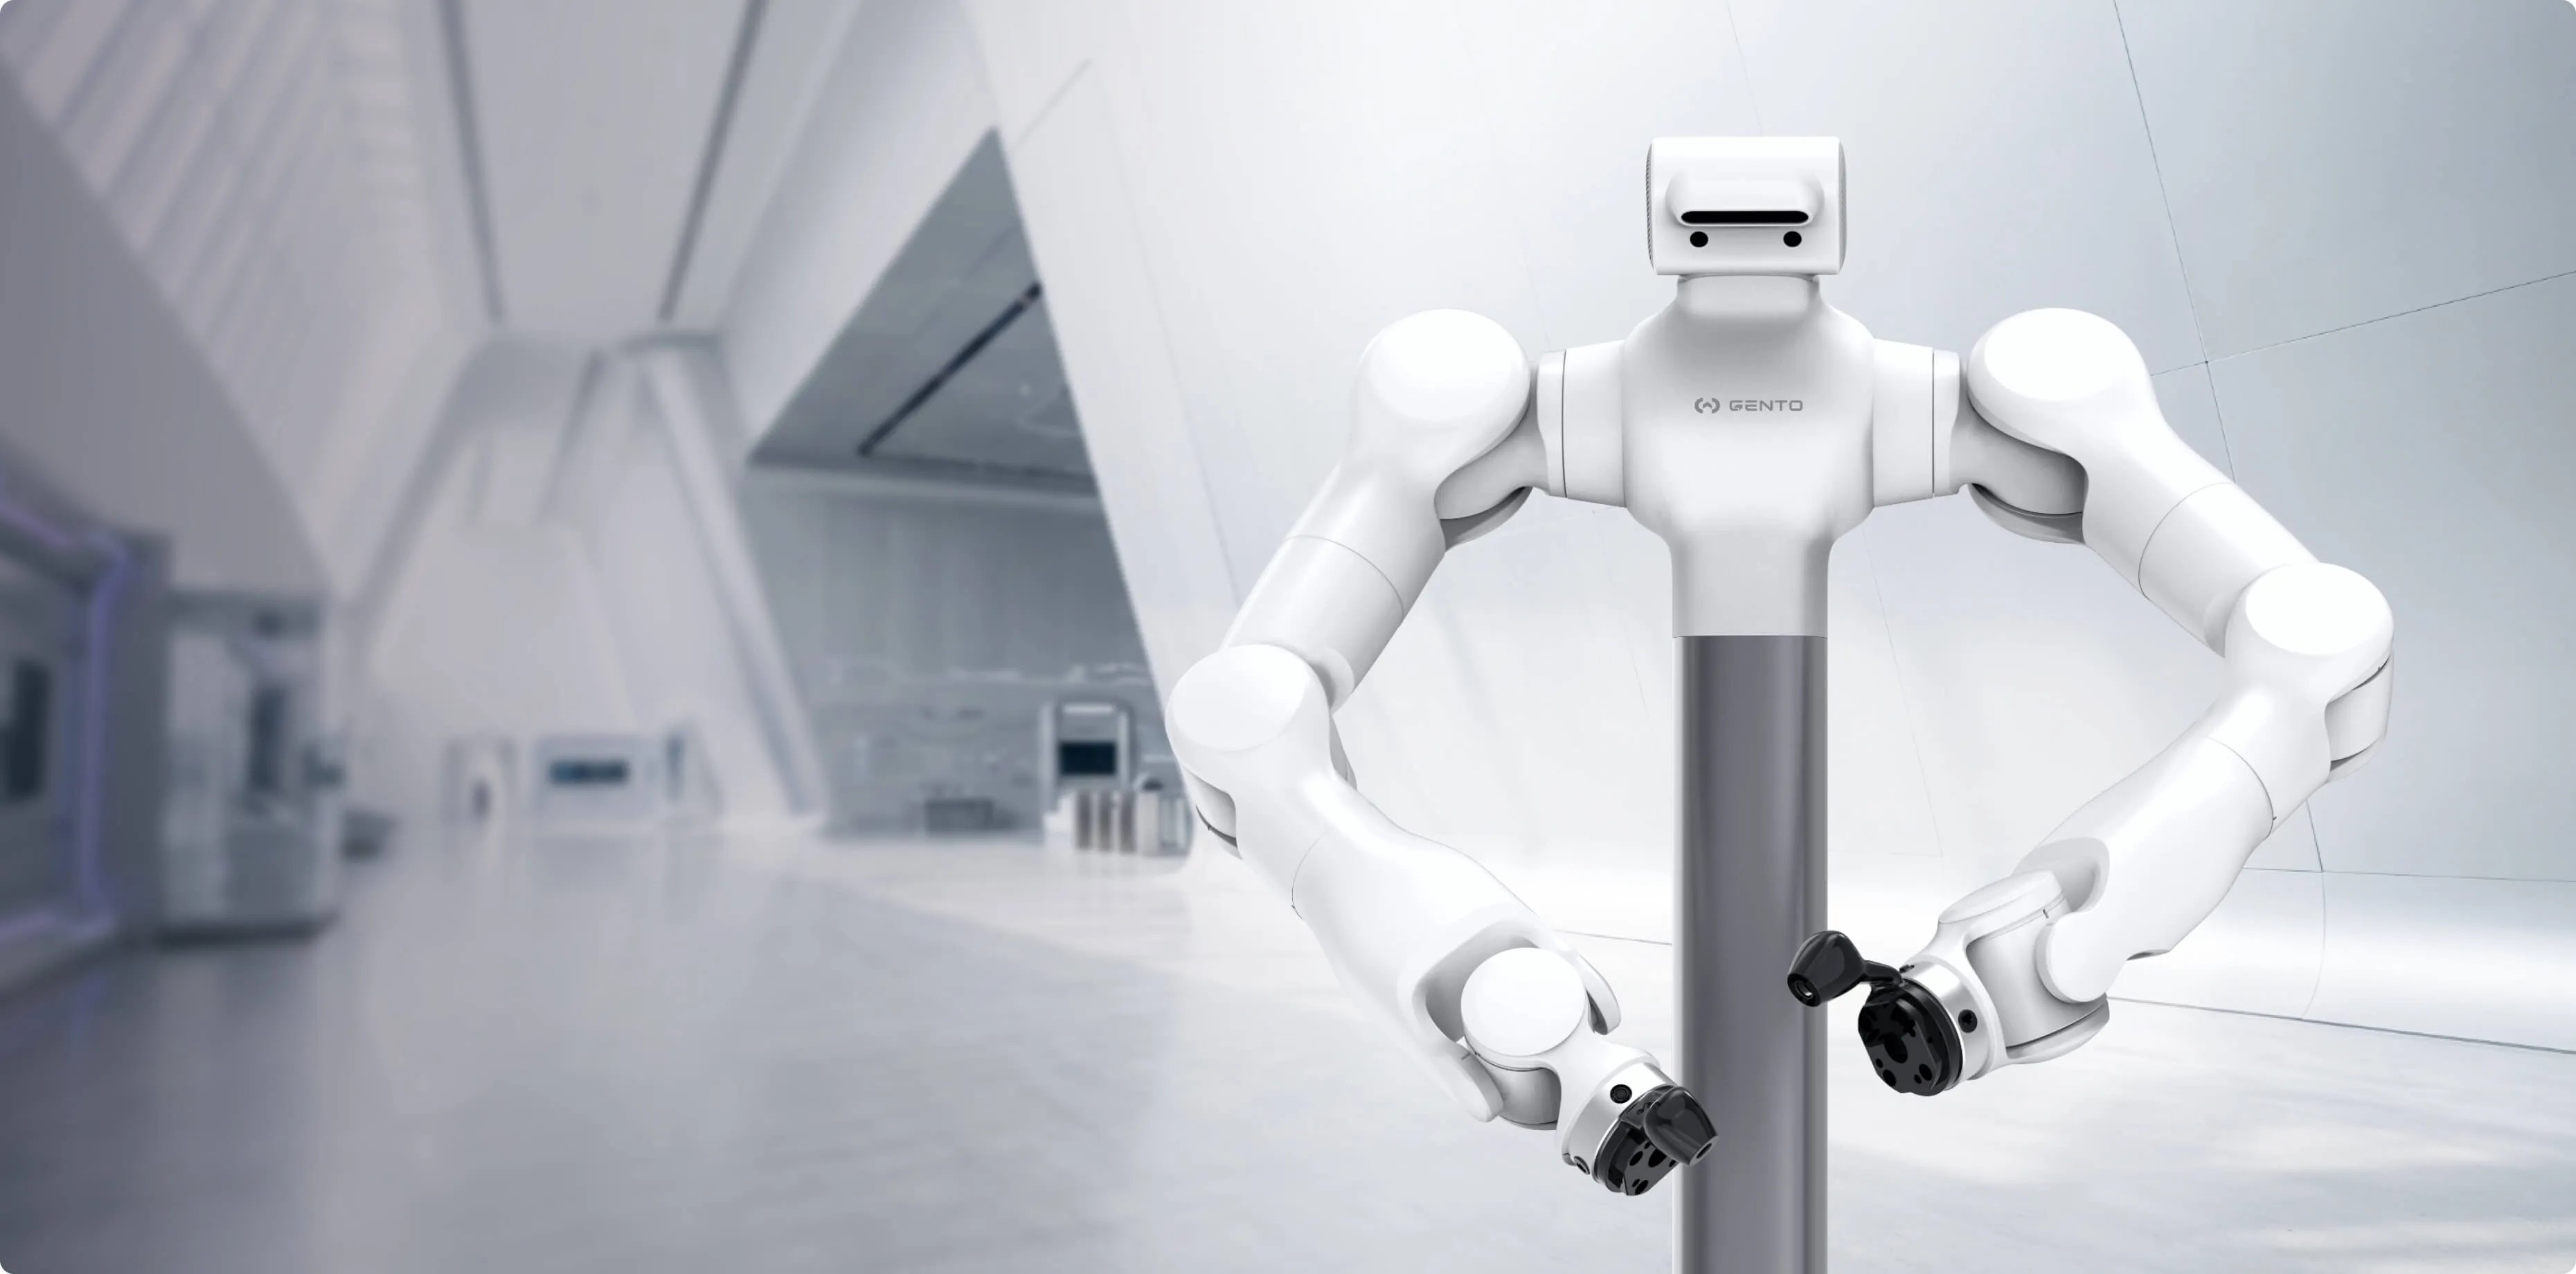
Full-Body Force Control, Safe Interaction, and Industrial-Grade Reliability
-
14degrees of freedom
-
7-DoFforce-controlled humanoid arms
-
0.6–1.8 mVertical workspace
-
24hIt runs continuously on mains power
Hardware Modules for All-Weather Robot Operation
Bringing precise power to every scenario
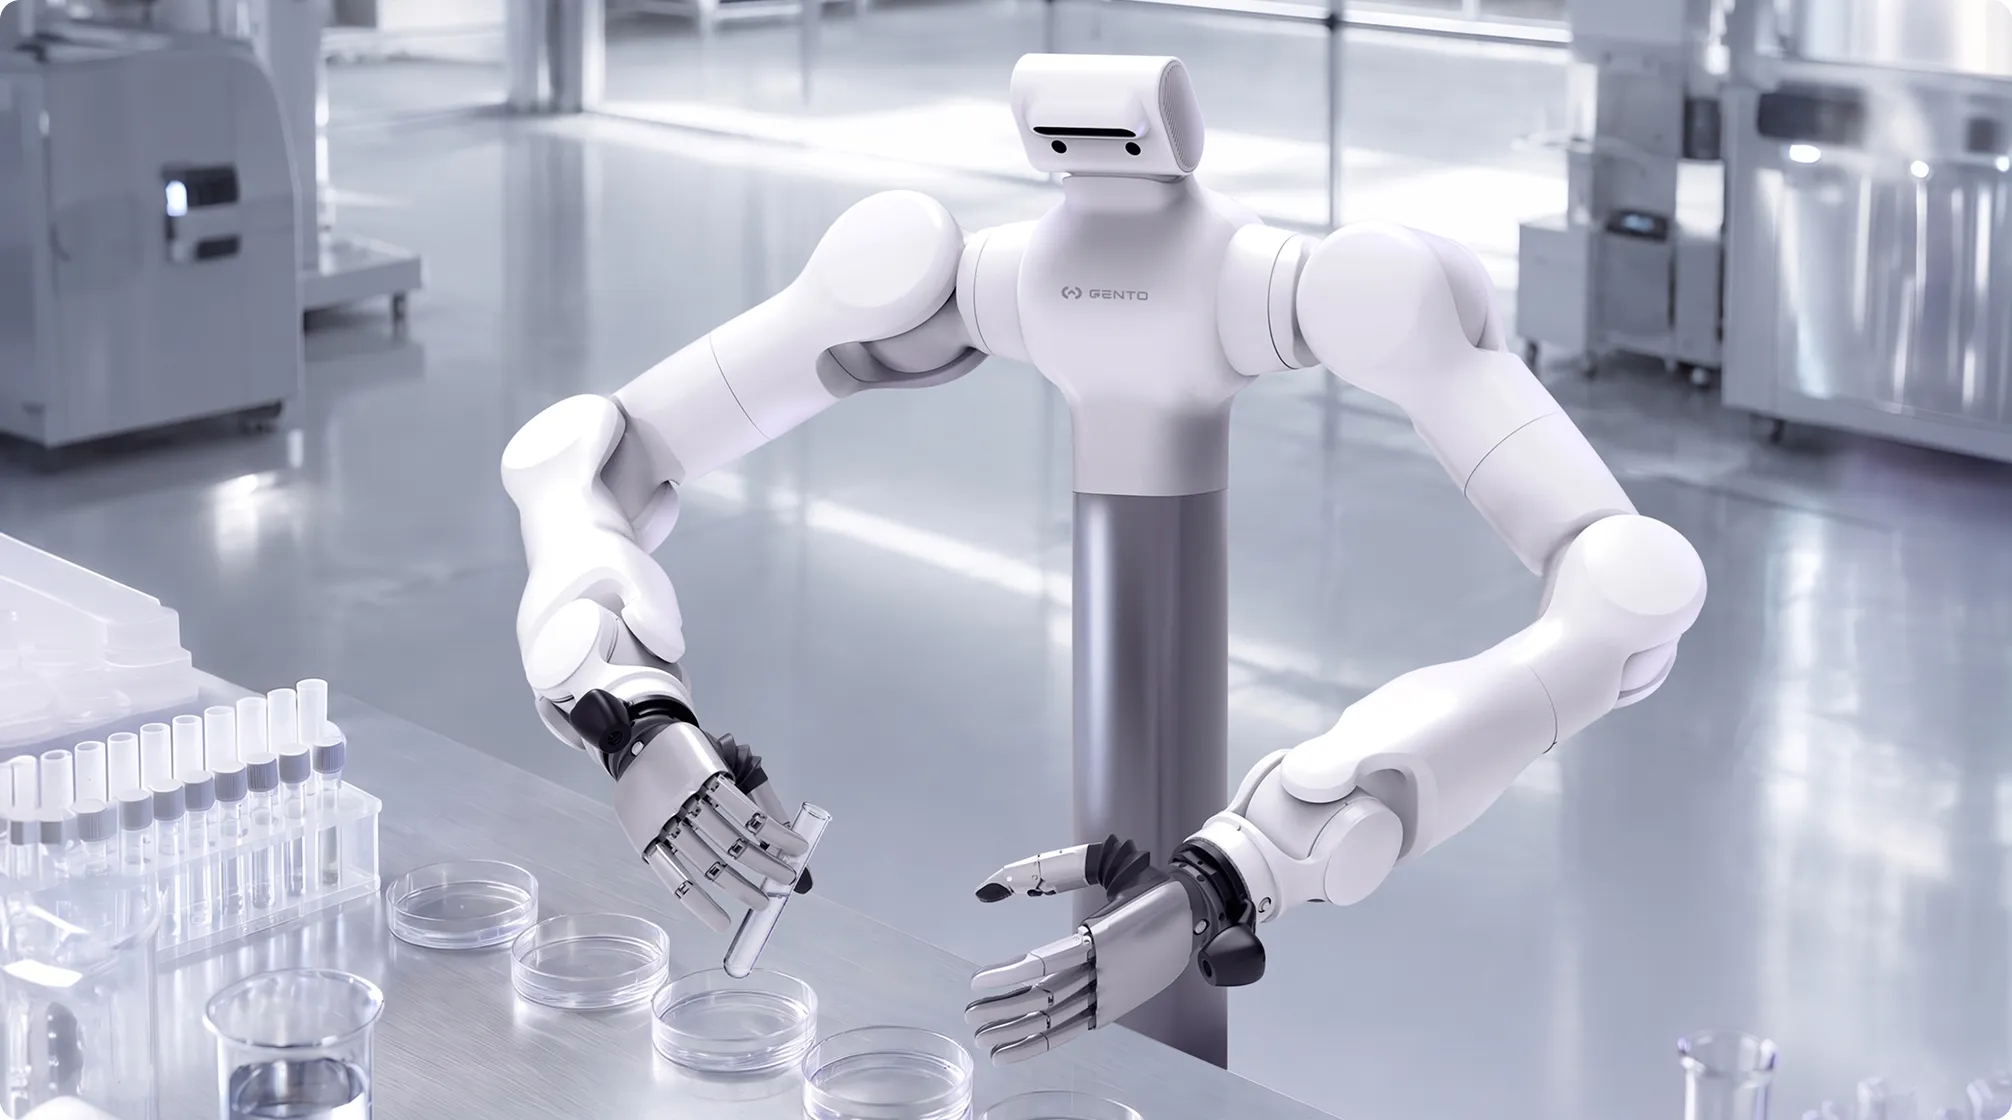
Marvin Pro Specifications
Machine
excluding dexterous hands
14 DoF(7 DoF × 2 dual arms)
base
fixed-height rigid support base
head
fixed (non-movable) head with no motion DoF
vertical workspace
0.6–1.8 m
total weight
≈ 80 kg
standard configuration
dual arms with full force control as standard (position / impedance / hybrid force-position control)
Dual-arm options
M6S-Lite-CCS
615: Load 5 kg / Weight 8.0 kg
680: Load 4 kg / Weight 8.7 kg
750: Load 3 kg / Weight 8.8 kg
Common: ±0.03 mm · 1.5 m/s · brakes on J1–J4
M6S-CCS
696: 6 kg, ±0.03 mm, 12.45 kg
809: 5 kg, ±0.04 mm, 12.7 kg
Common: 2 m/s, brakes on J1–J7
Perception
standard
5 cameras as standard — head D435 RGBD ×1 + SH5WG RGB ×2, wrist SH5WG or D405GA ×2
Optional
6-axis force/torque sensor at the end effector
Computing
Standard
NVIDlA Jetson Orin Jetson 64G (275 TOPS)
Optional
NVIDIA Jetson Thor T5000 1TB (2070 TFLOPS)
Electrical
Power Supply
AC 220 V mains-powered (overseas voltages supported)
Operation
24-hour non-stop
Battery
No battery module
Communication
Real-time Bus
1 kHz EtherCAT
Wired Interfaces
RS485 / CAN / EtherCAT
Network / Wireless
WiFi / EtherNet
Let "It" be your
good helper
More Products
-
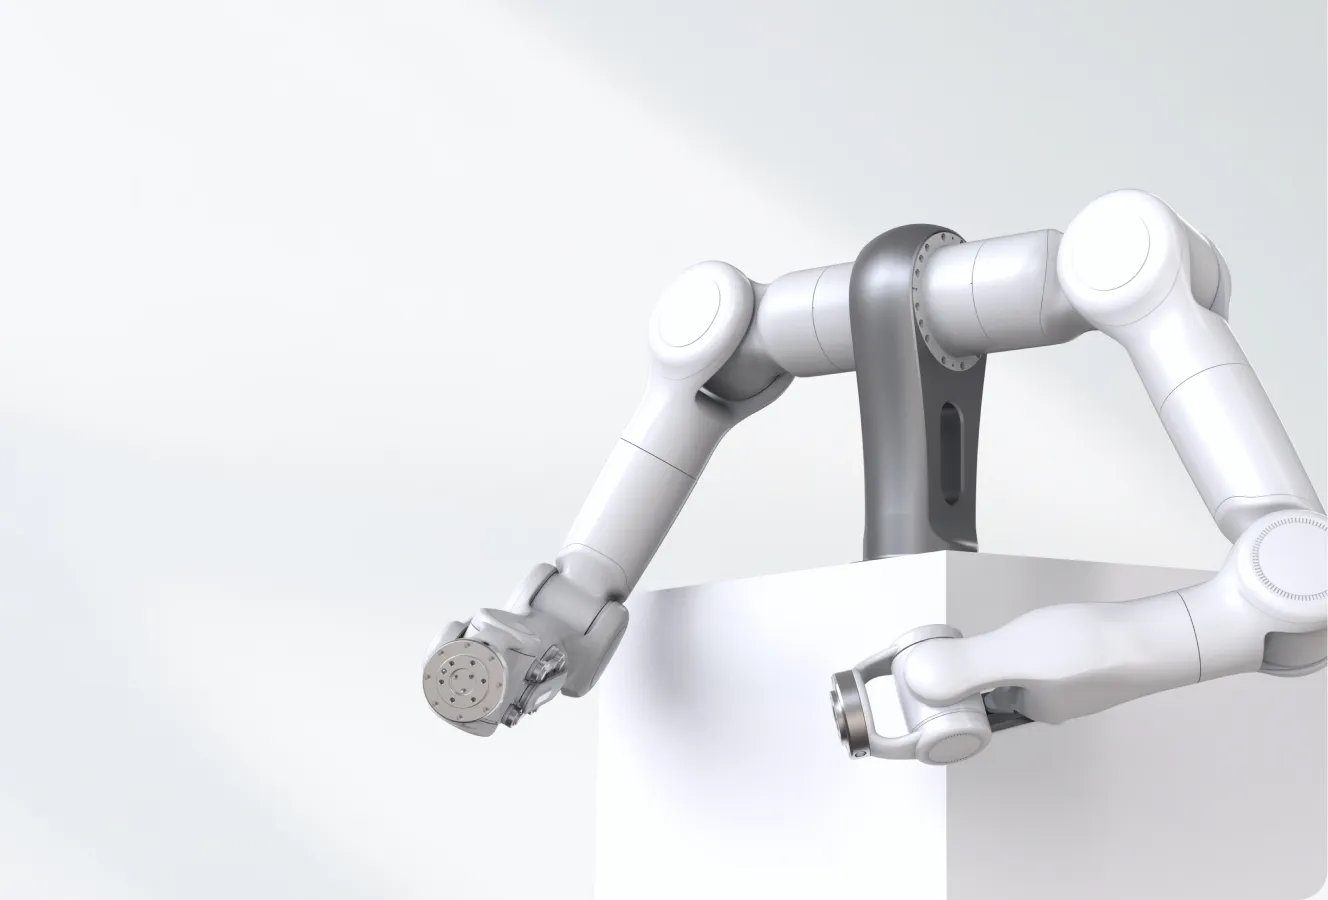
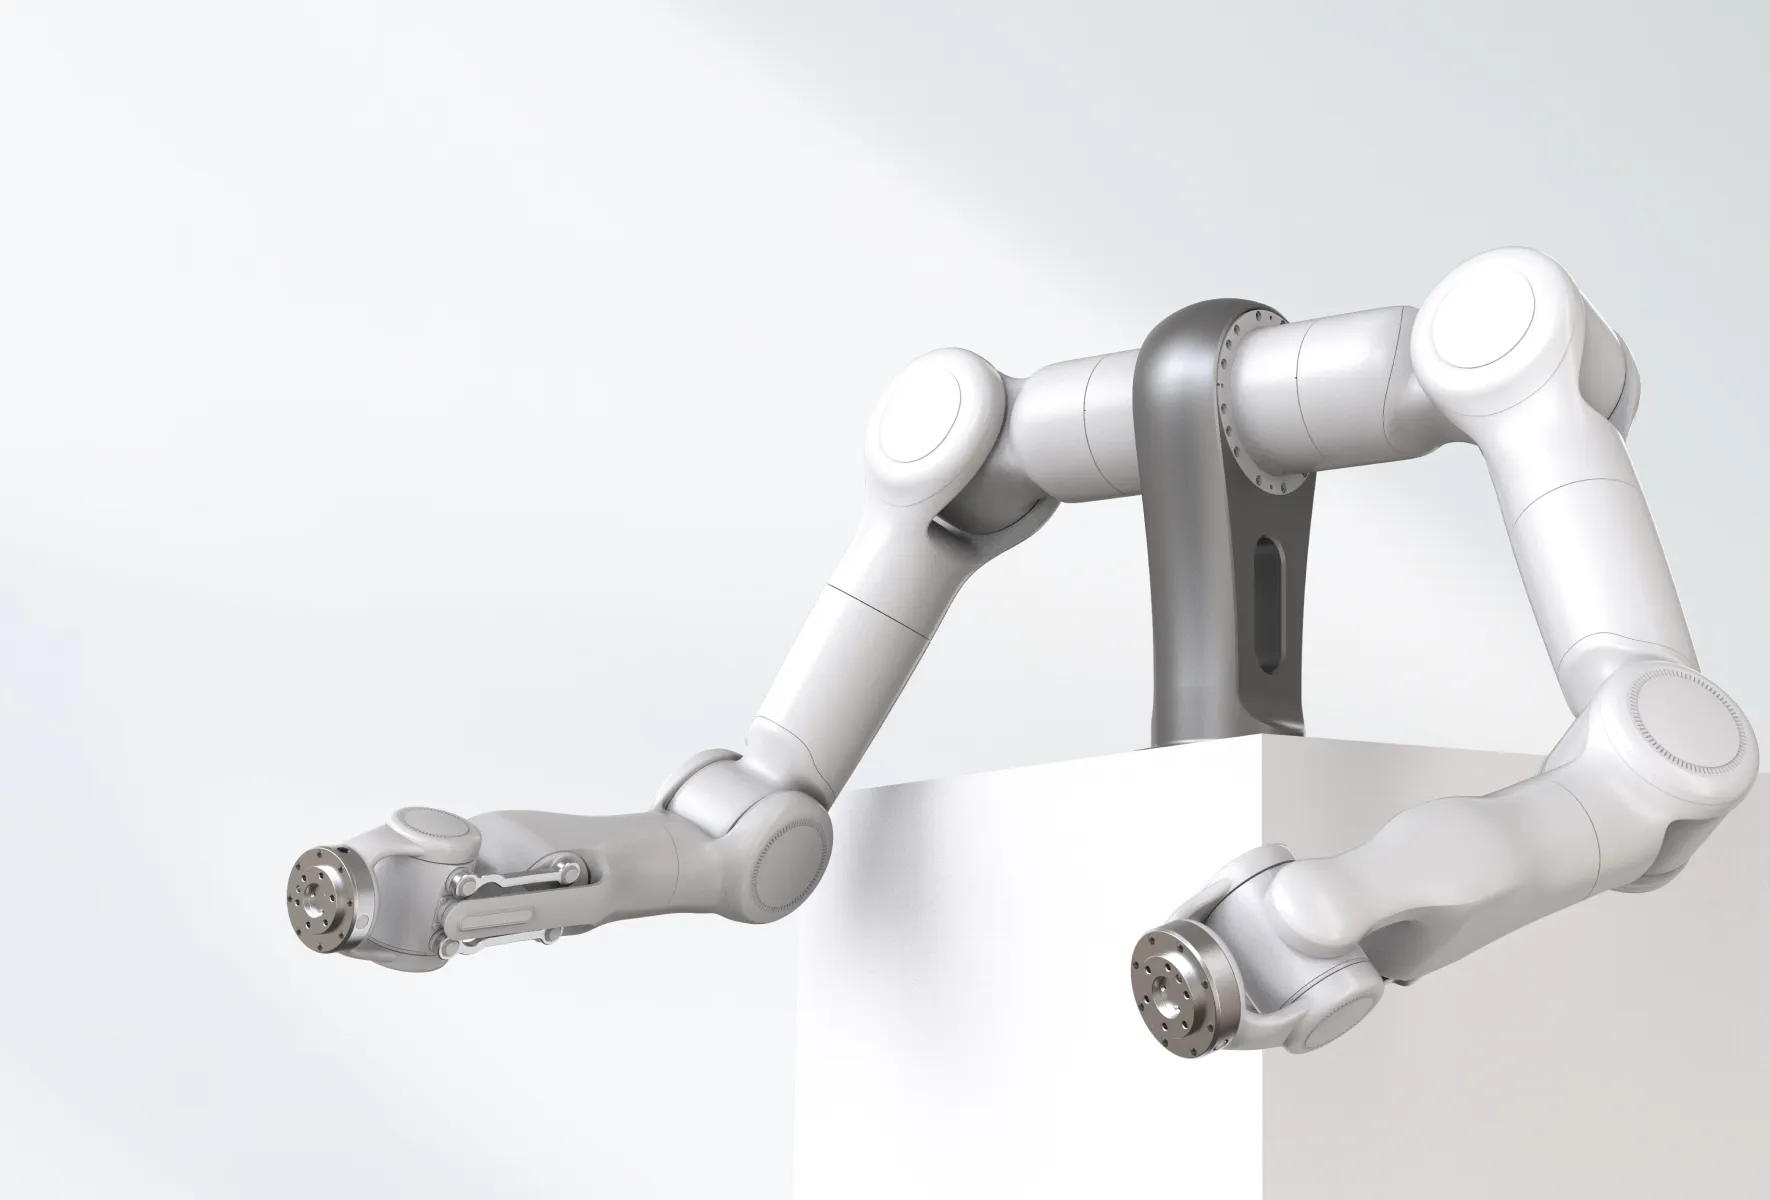 Force-Controlled Humanoid Dual Arms
Marvin
Full force-controlled humanoid arms — anthropomorphic configuration, lightweight, compliant force control, industrial reliability. -
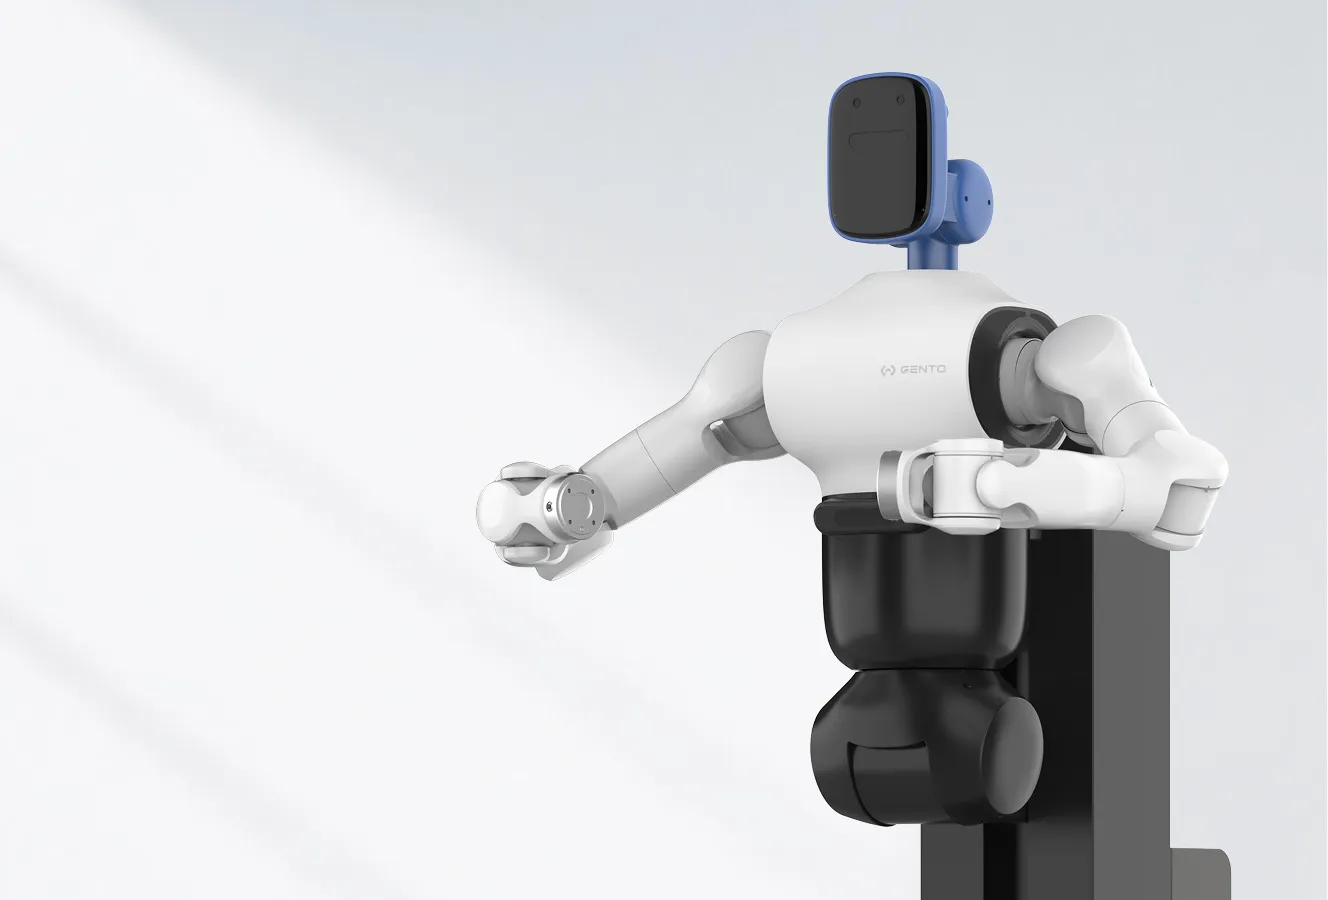
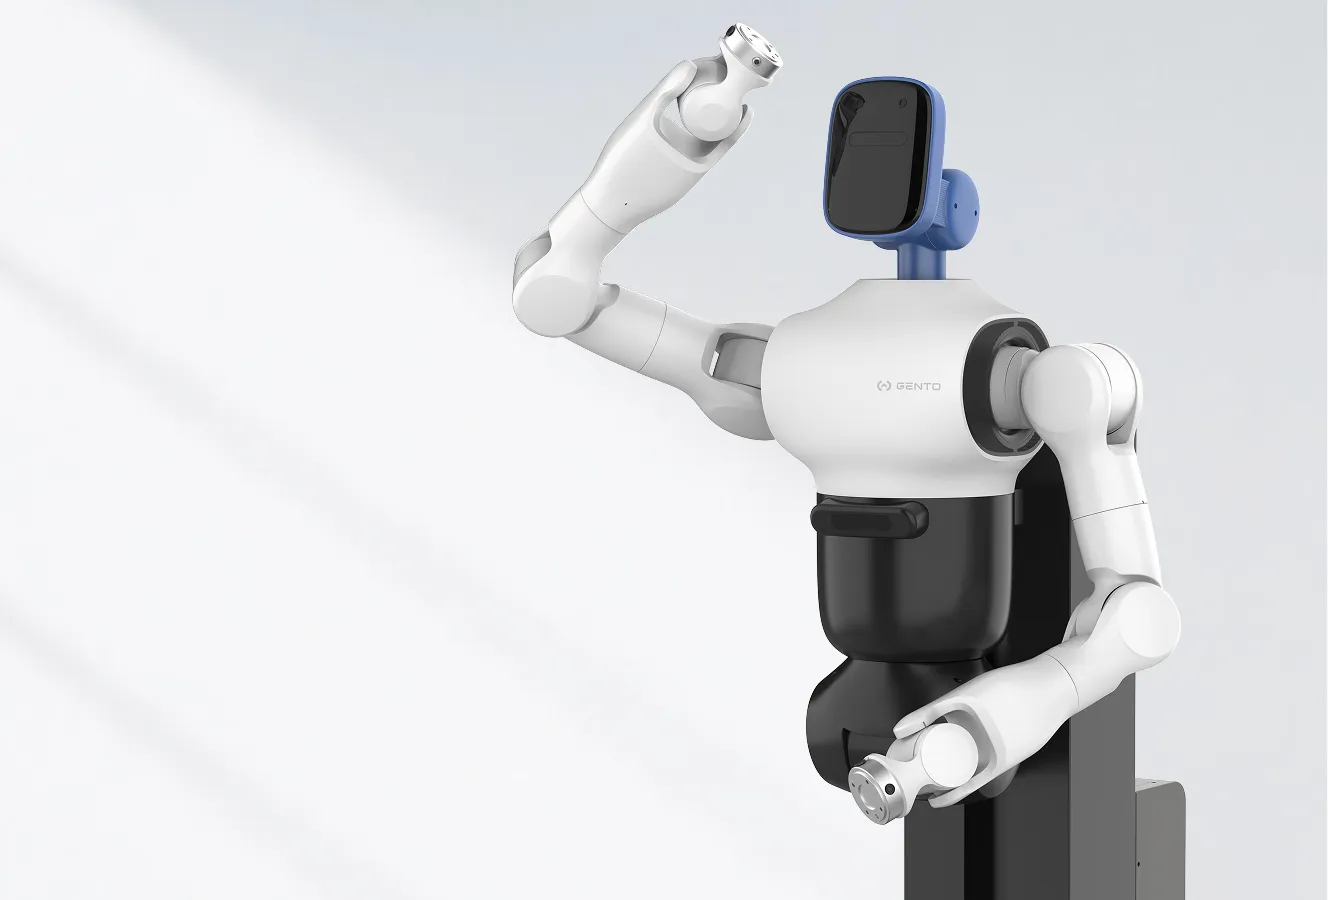 Wheeled Lifting Robot
Gento Skye
A humanoid development platform with whole-body force control and open control authority, built for embodied intelligence, reinforcement learning and real-world validation