

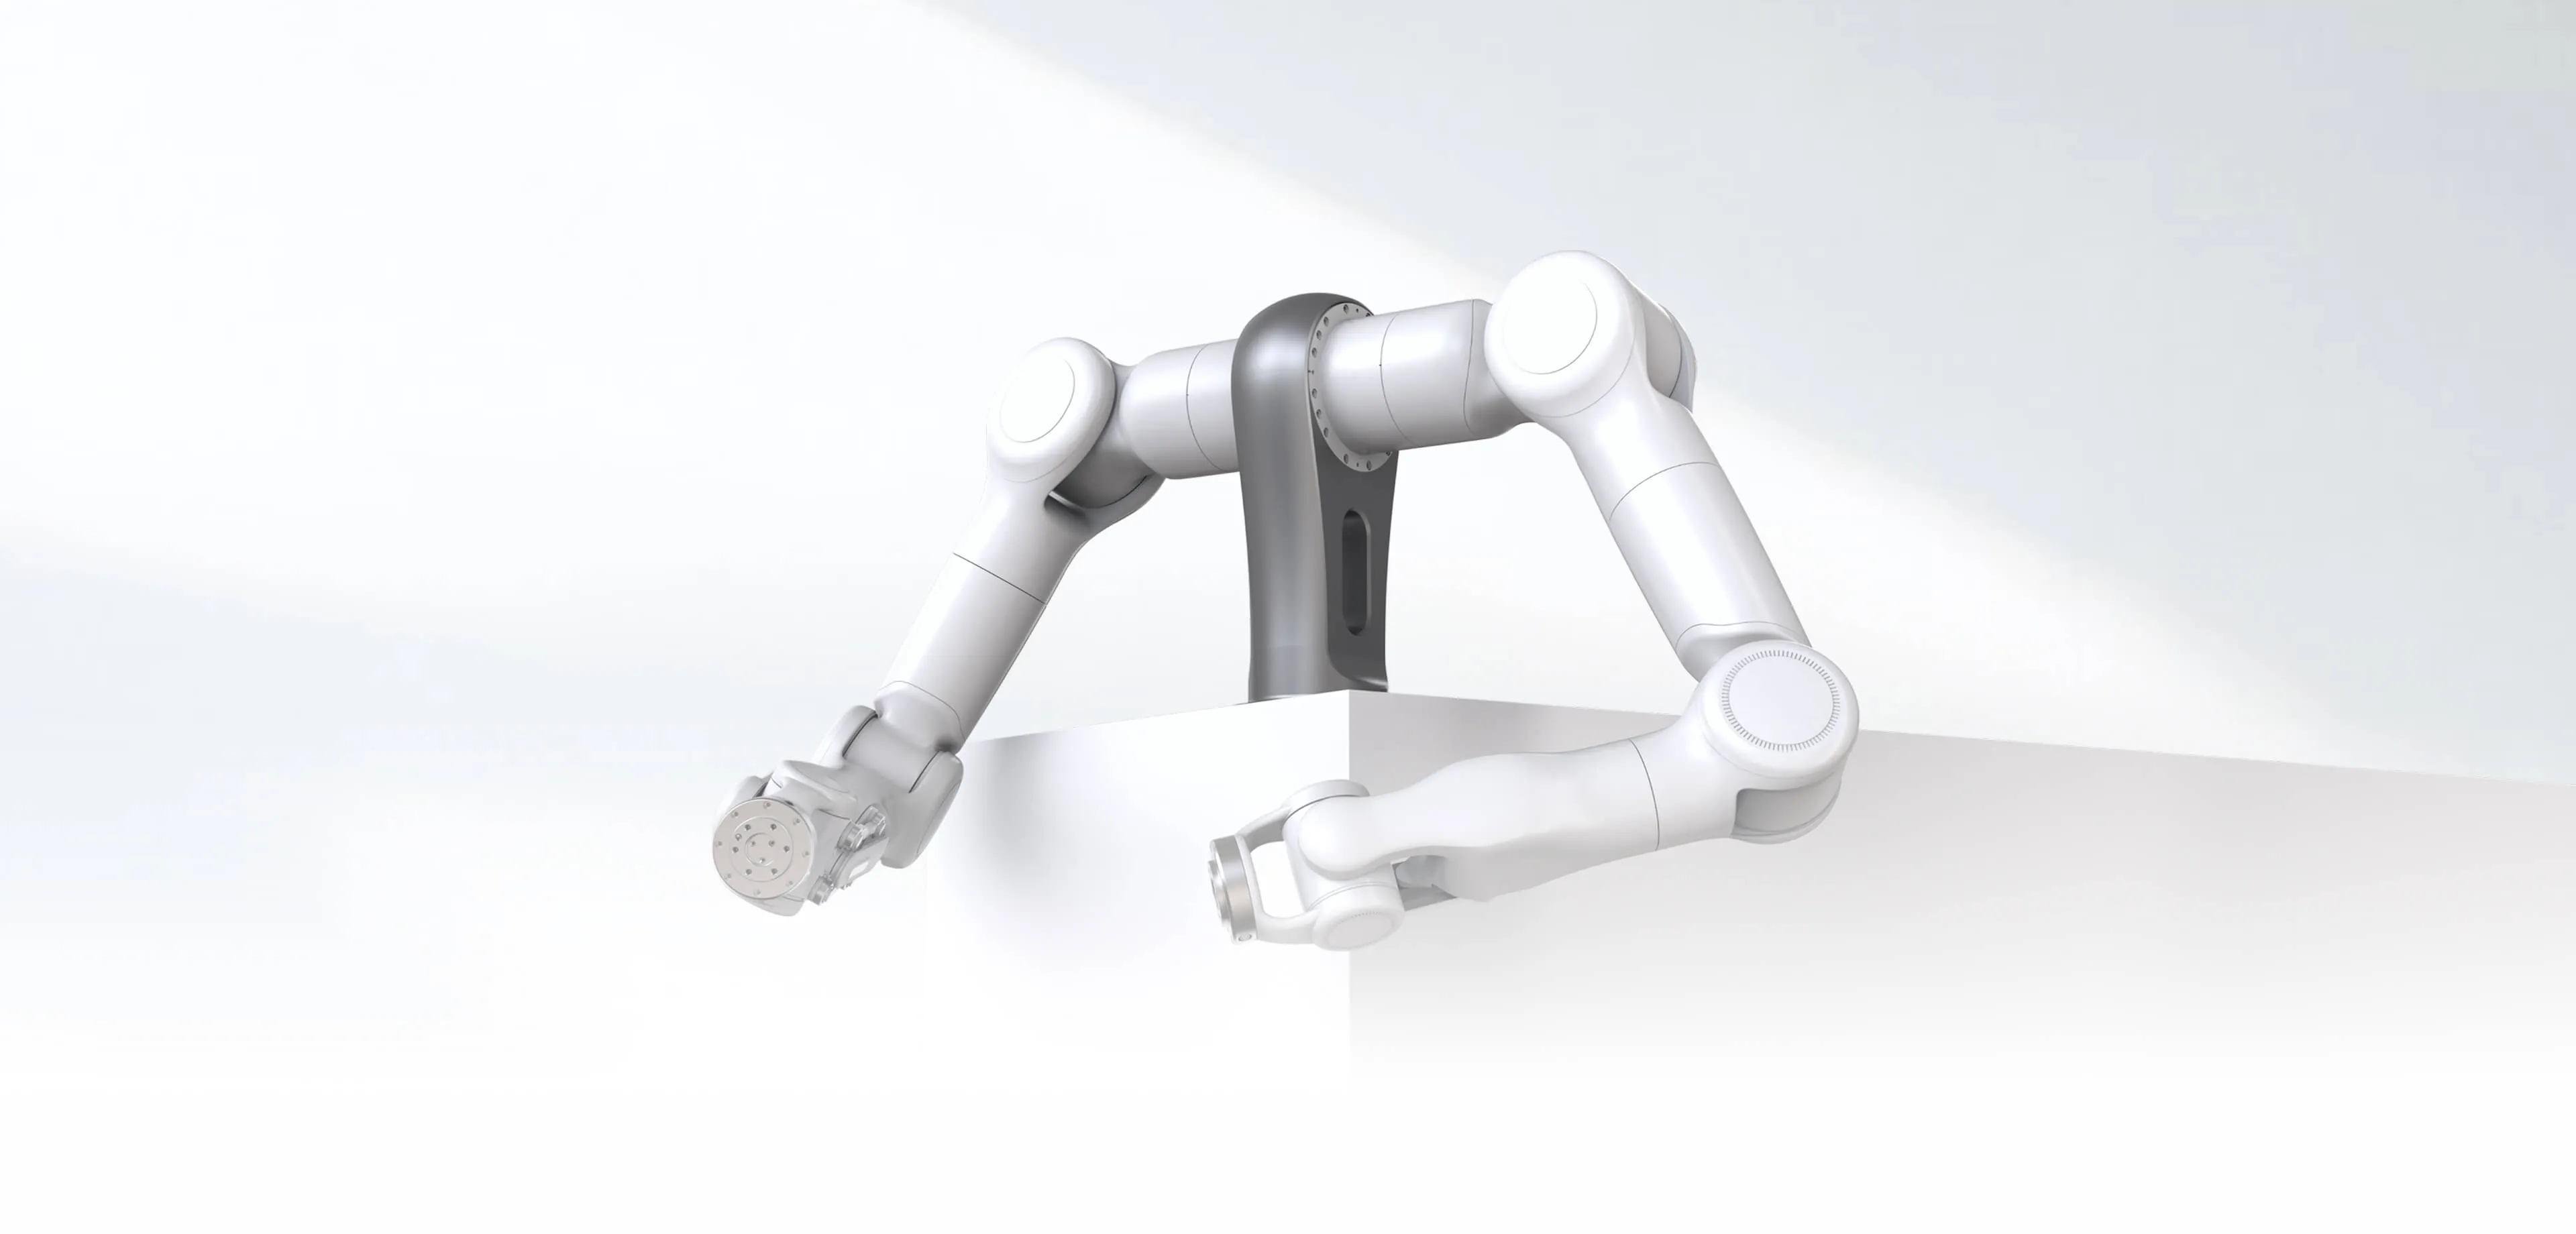
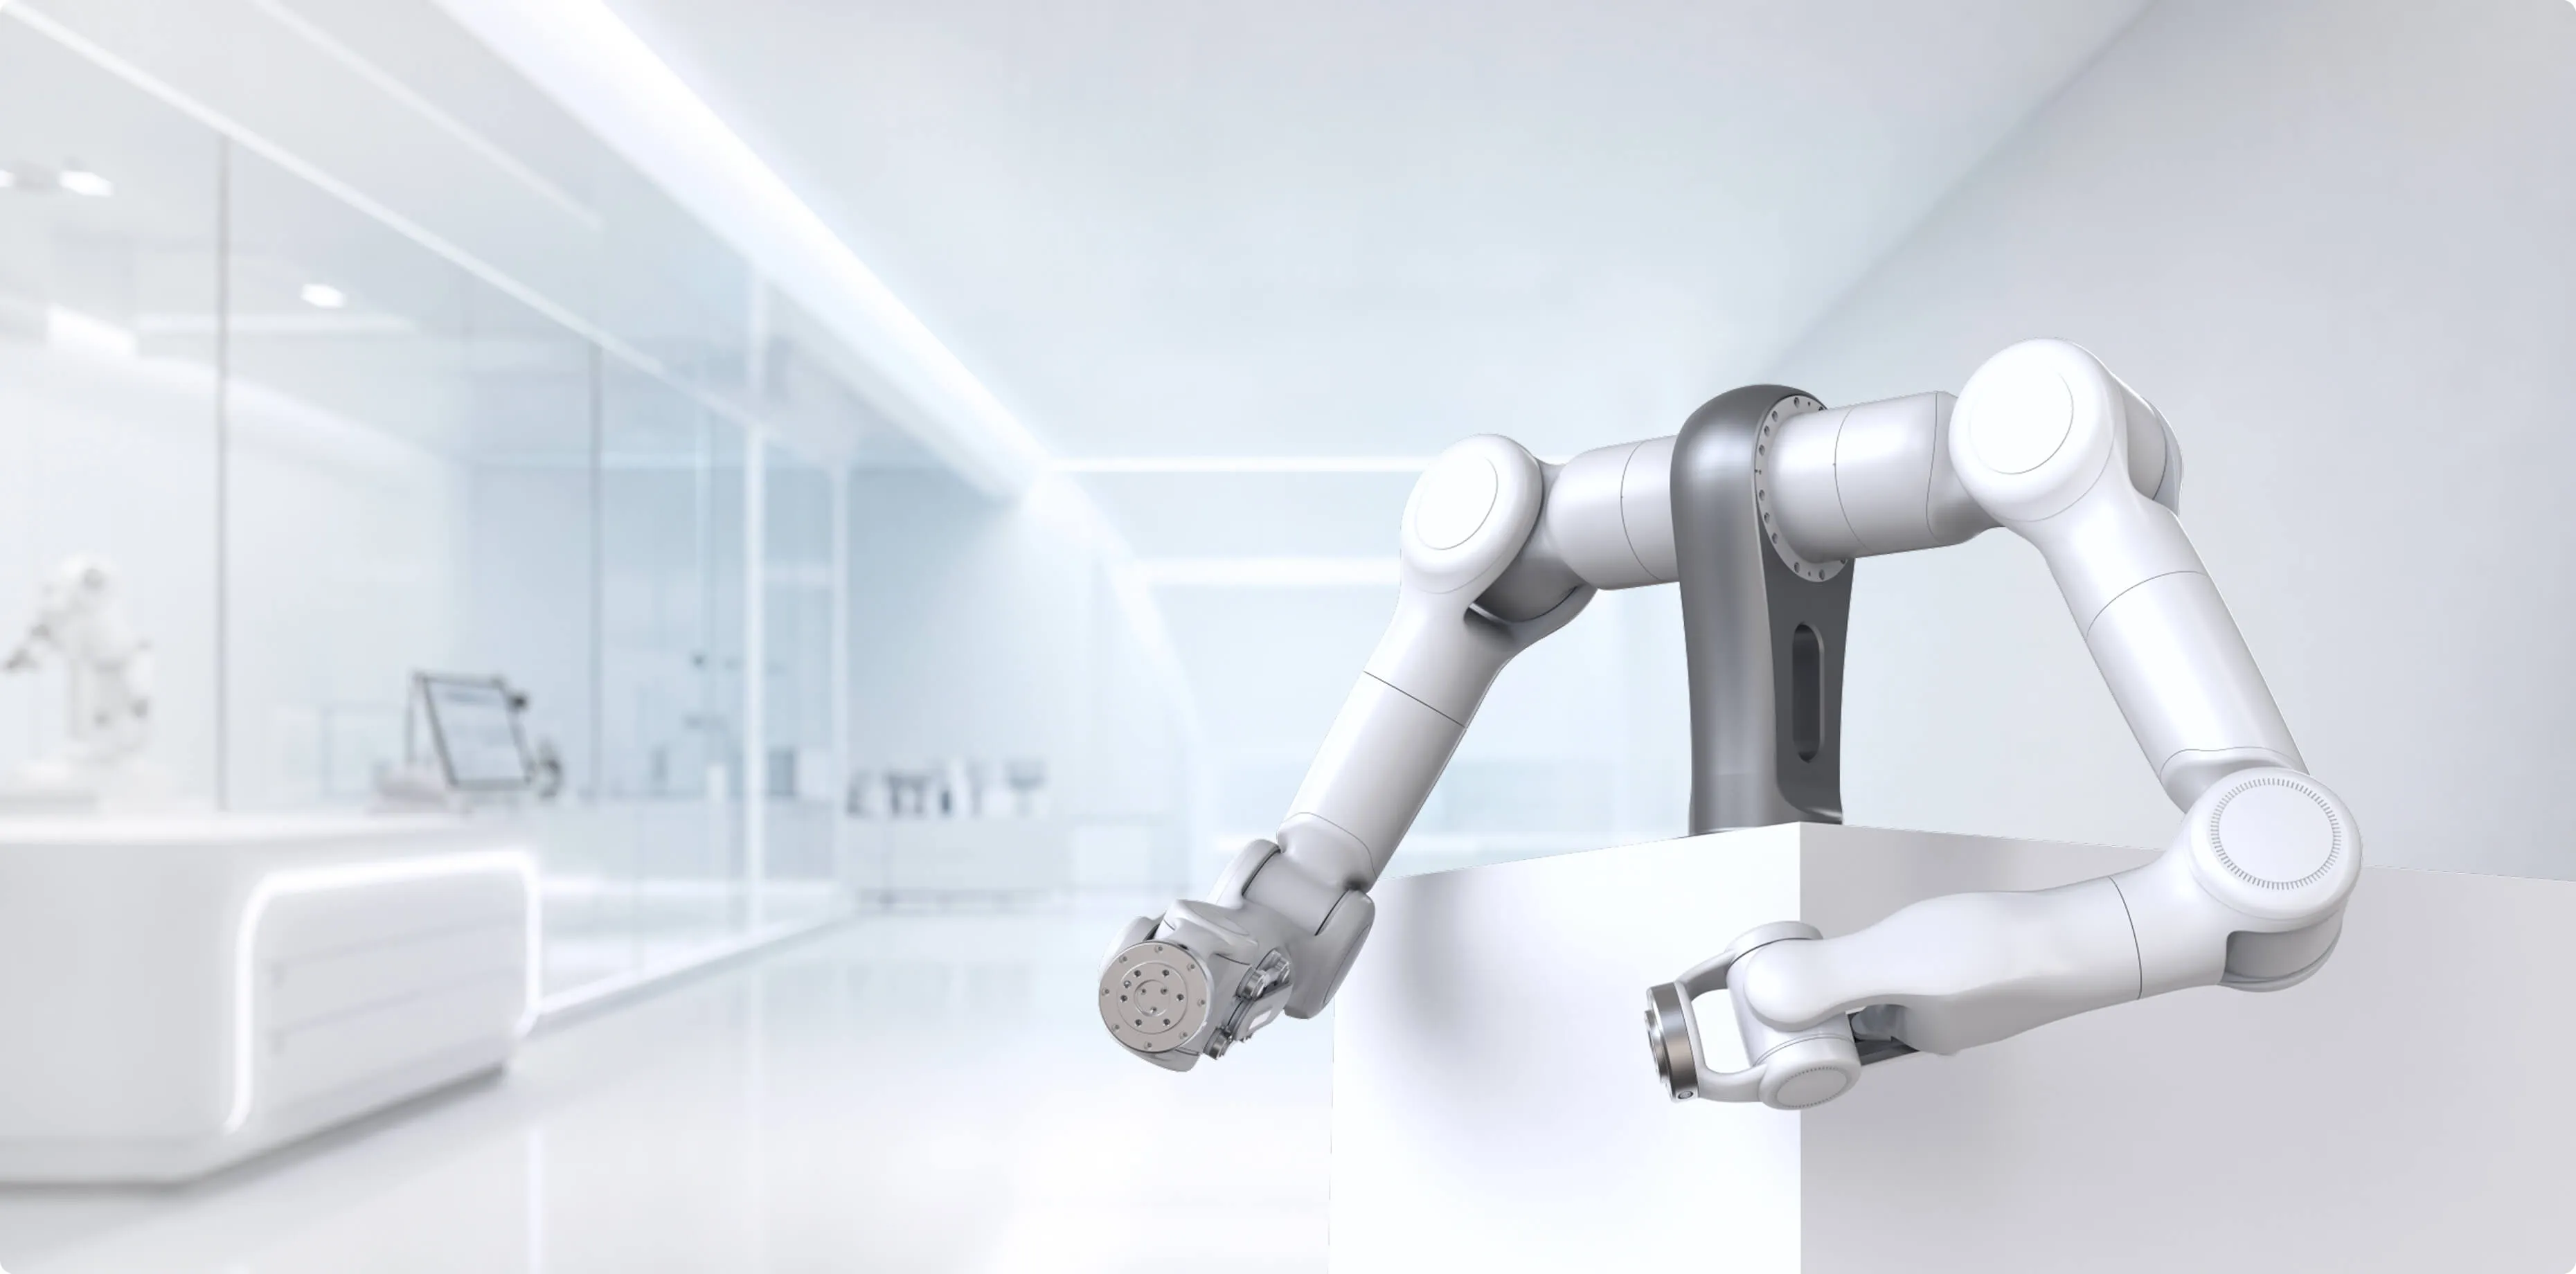
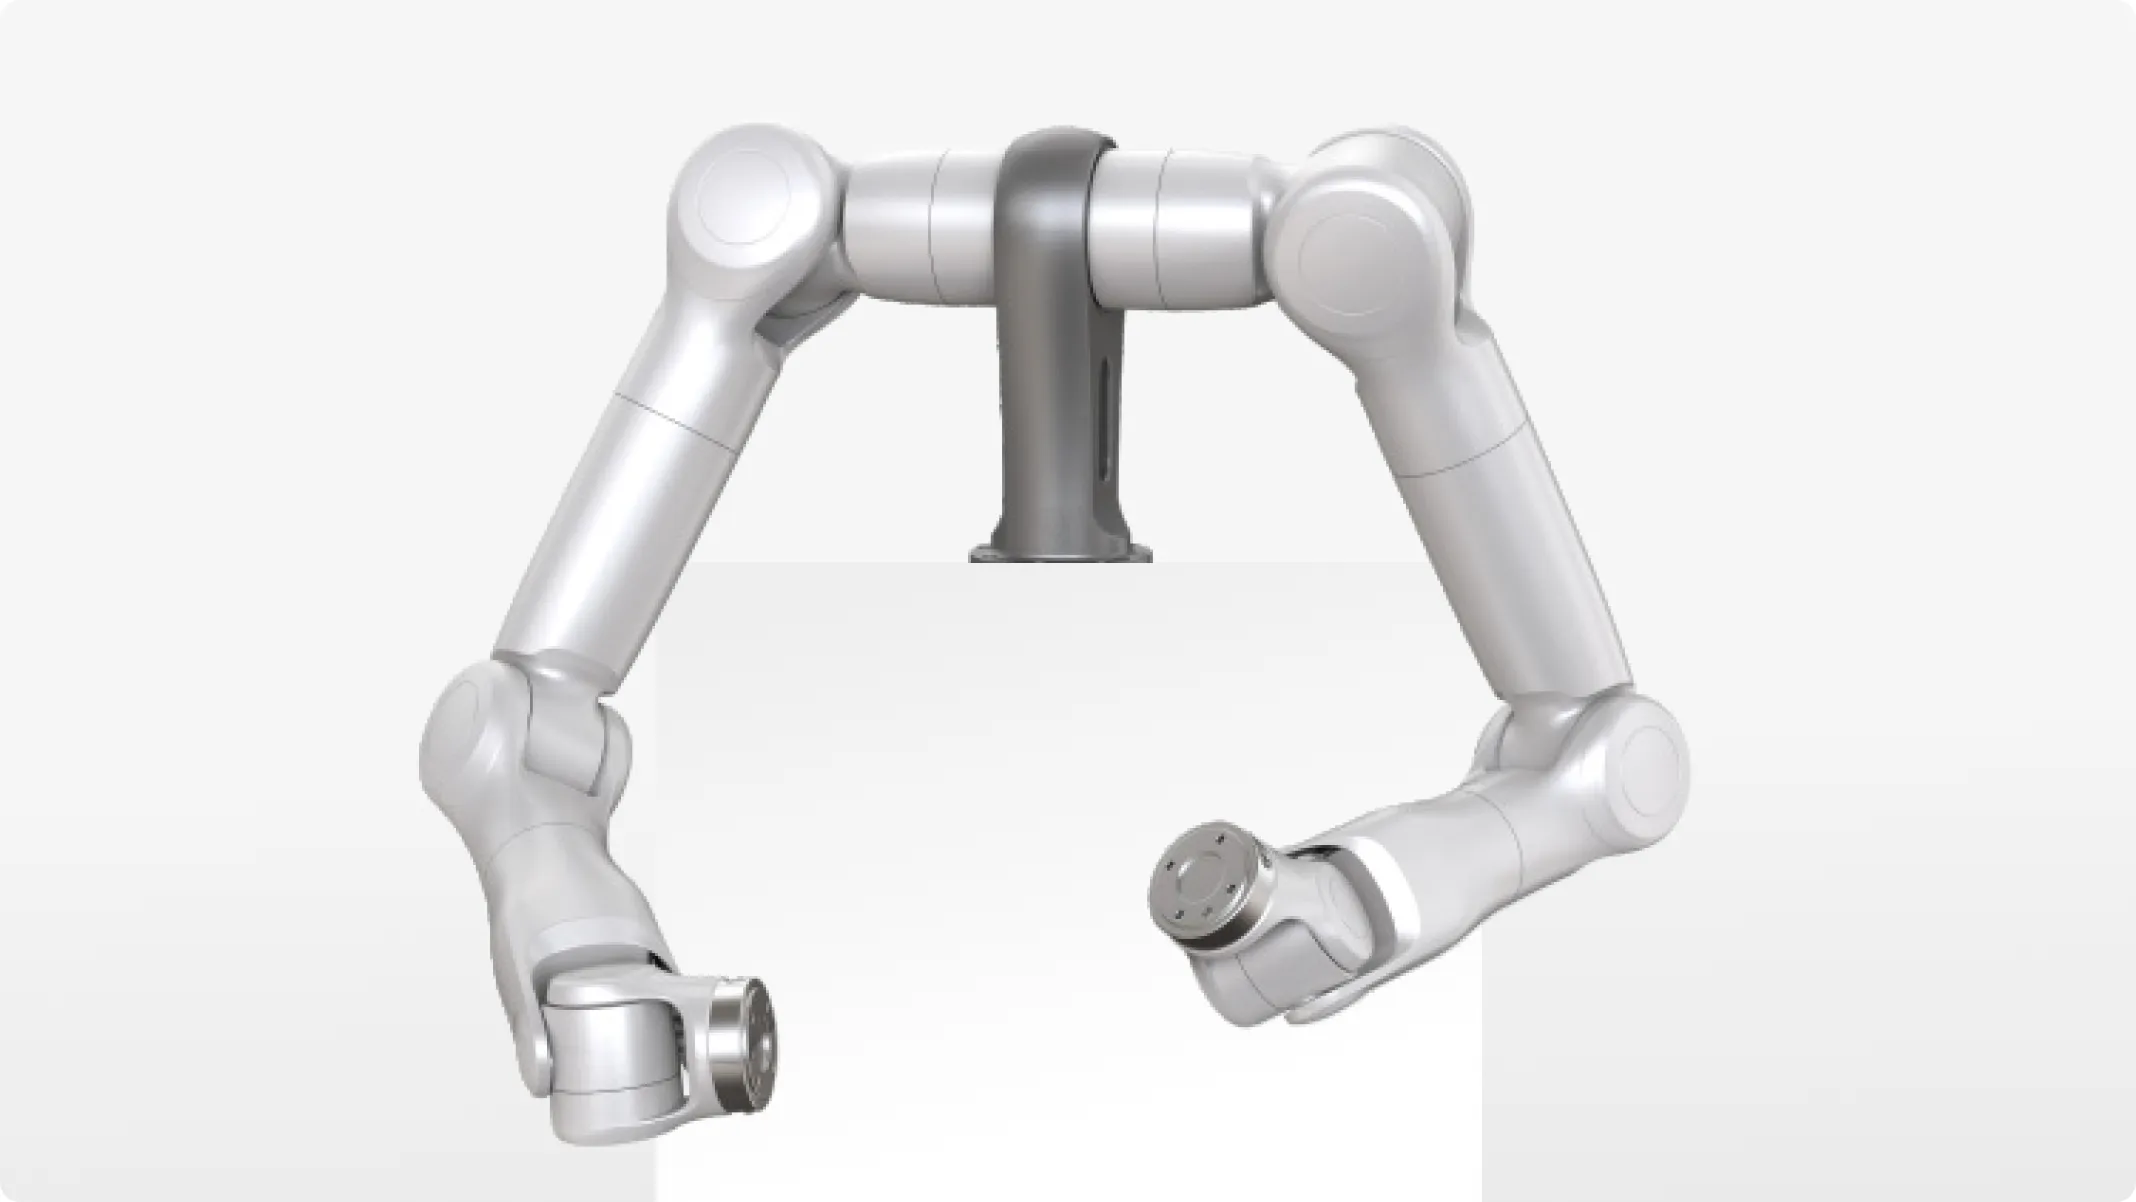
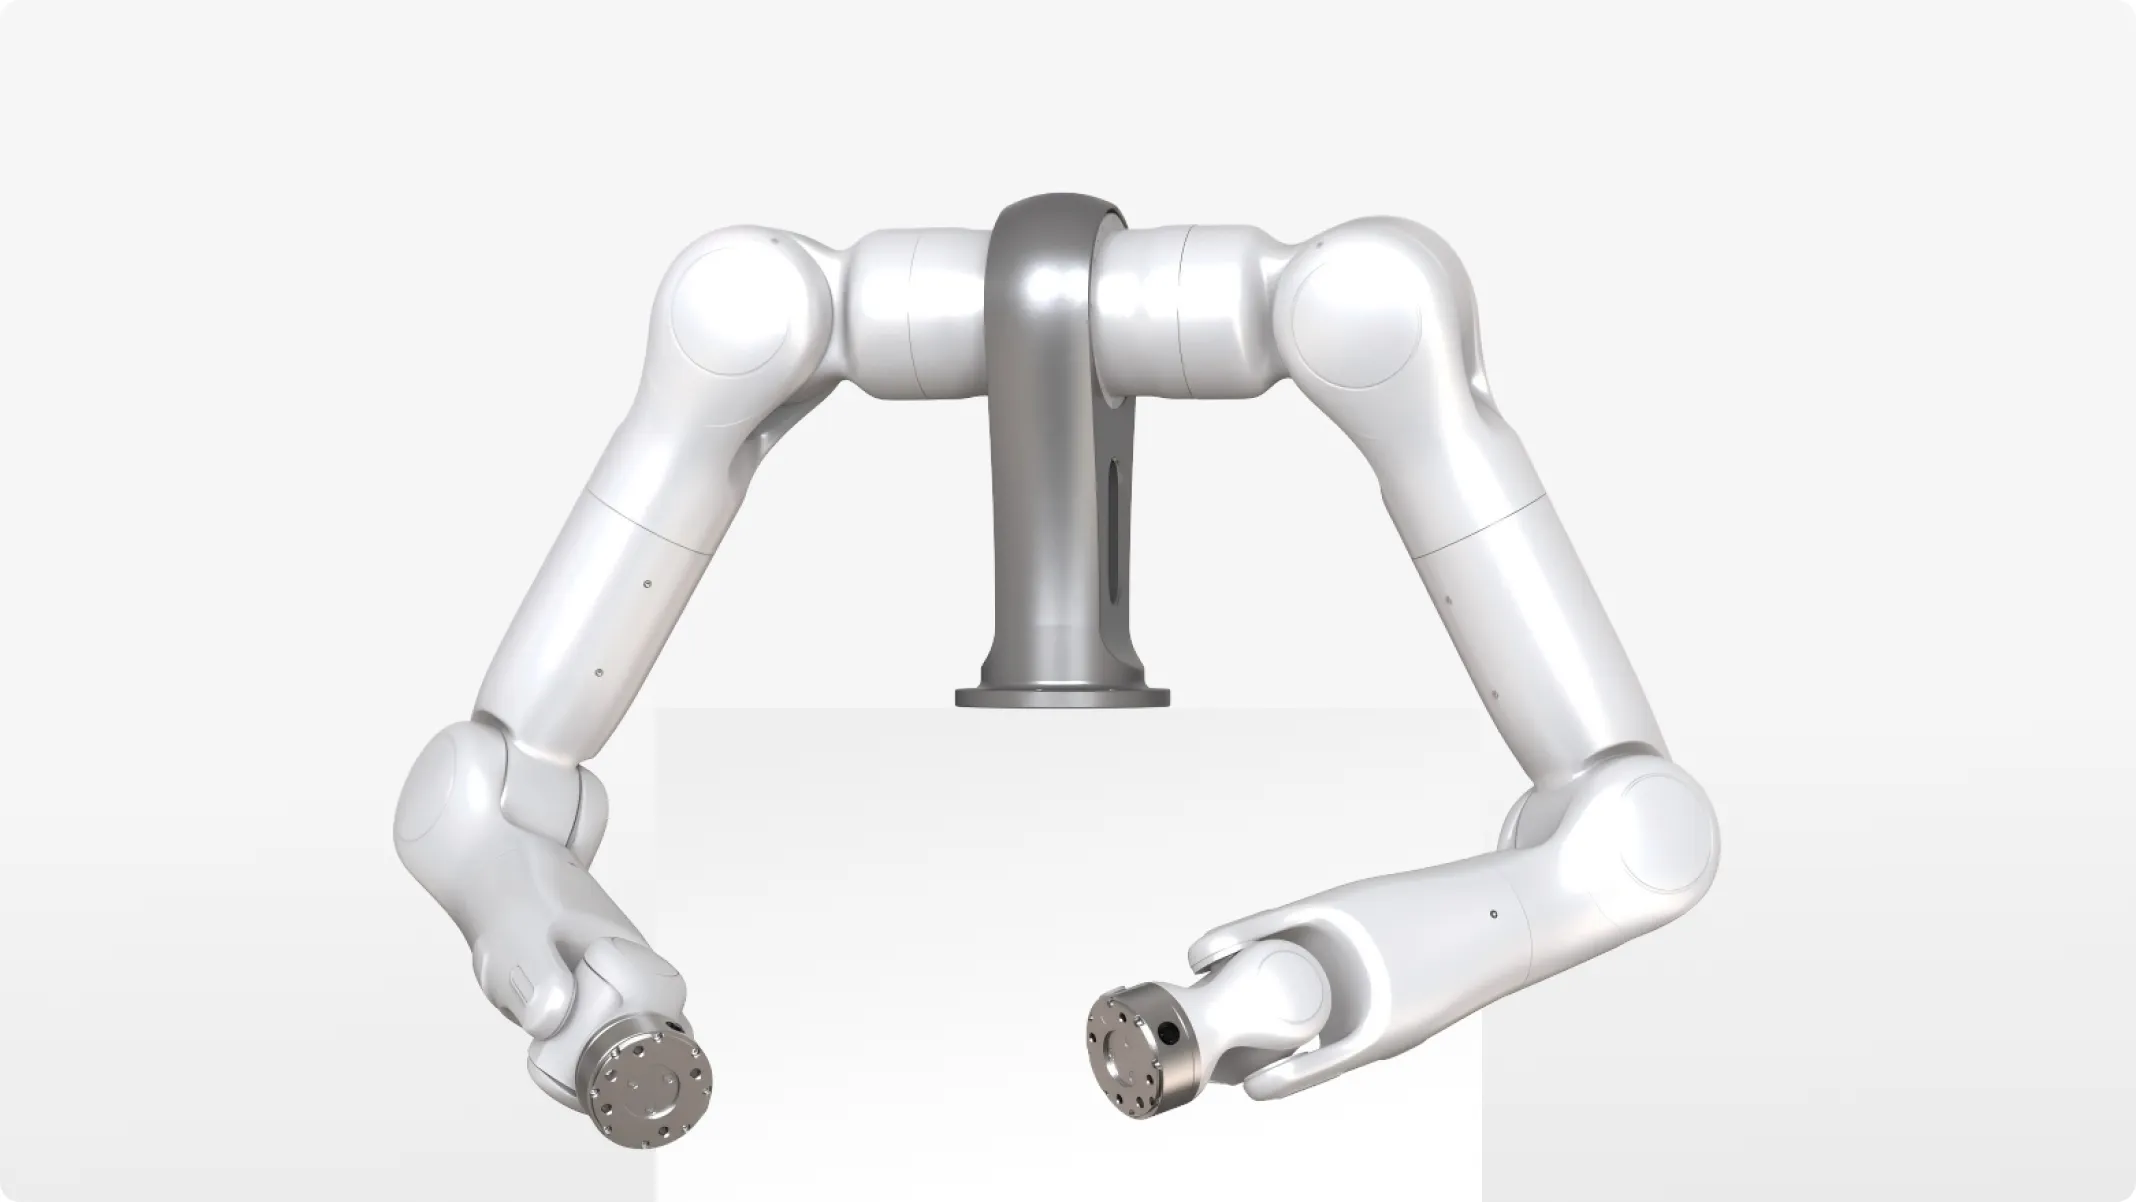
Manvin’s wrist uses a cross-axis design for human-like, highly flexible motion, avoiding DOF degradation and matching wrist biomechanics. Its smaller turning radius enables more natural grasping and improves teleoperation control and adaptability.
-
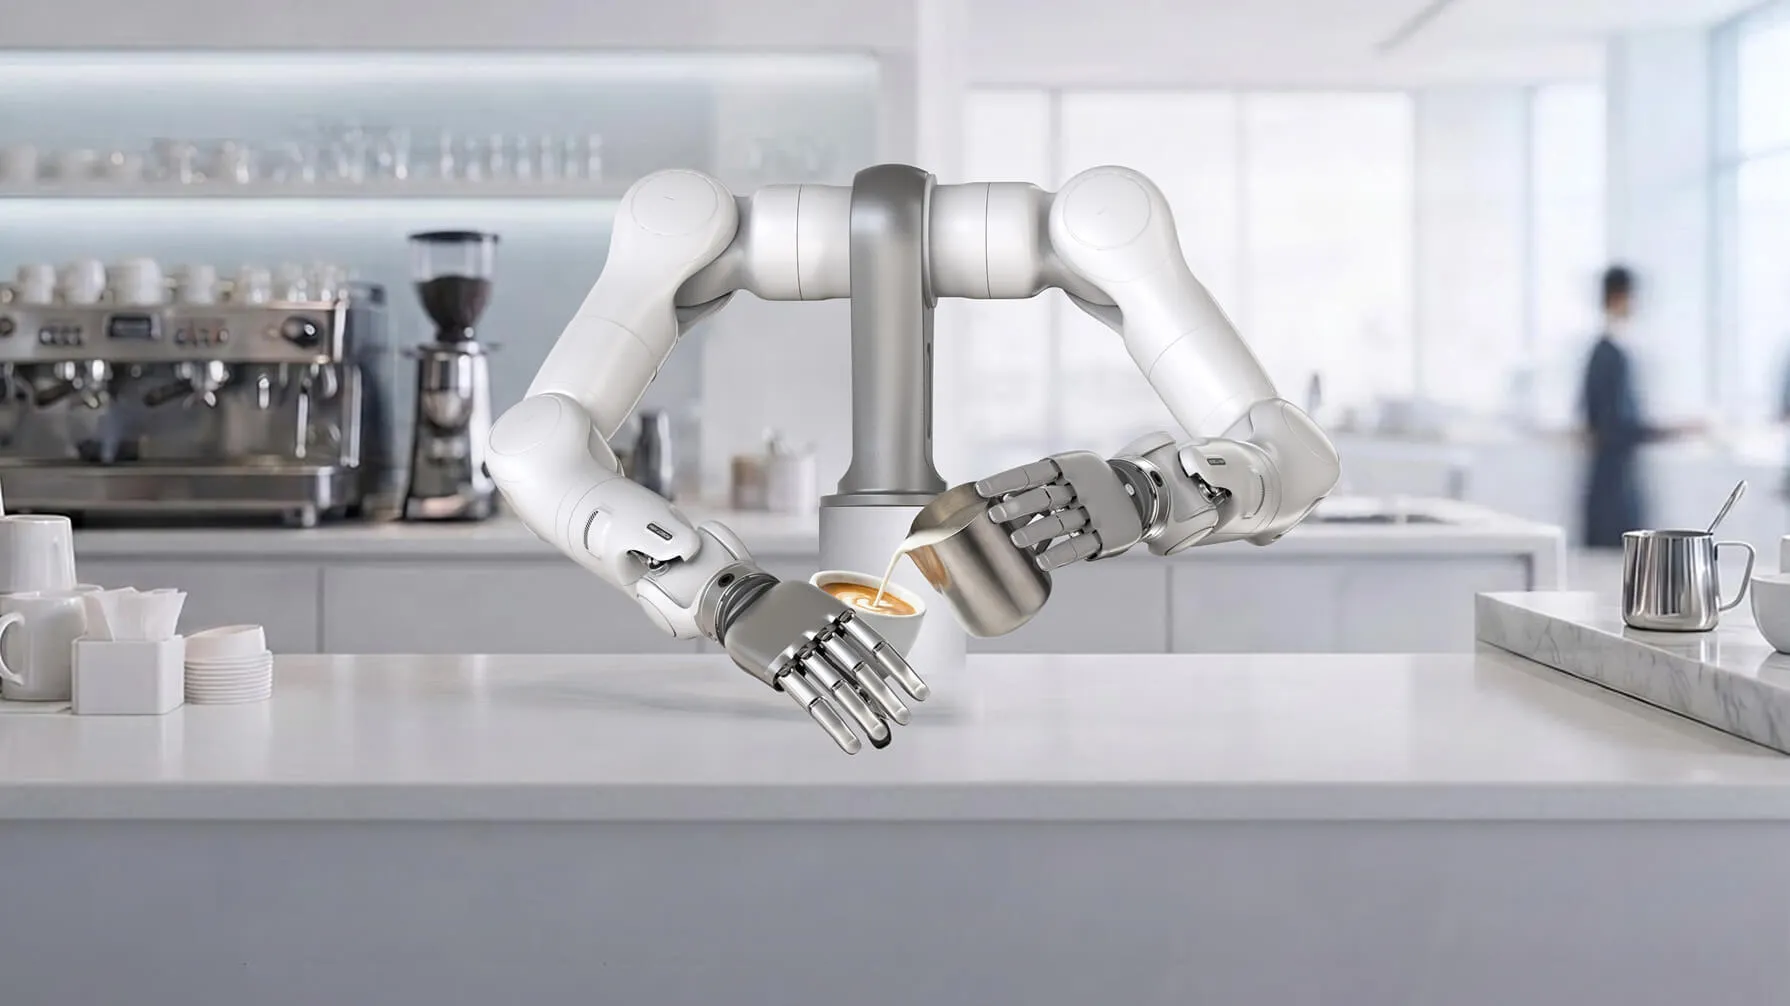 Anthropomorphic Configuration · Flexible as a Human Arm
-
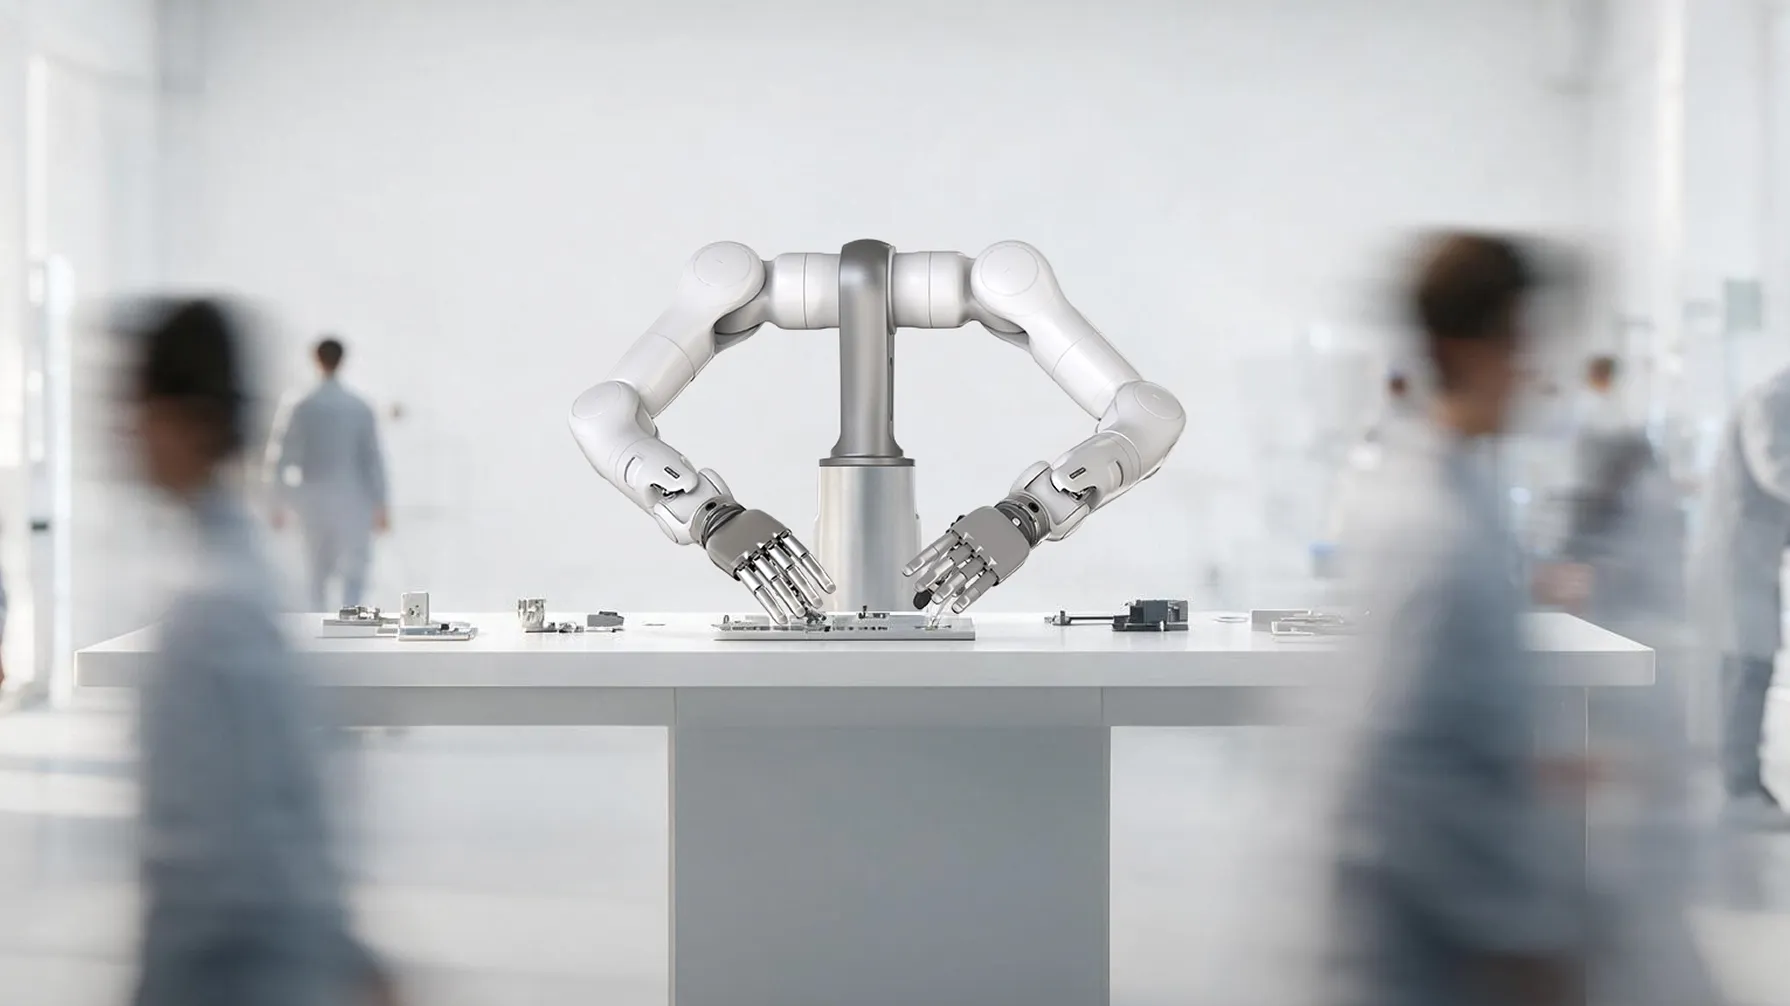 Compliant Force Control · Safe and Worry-Free
-
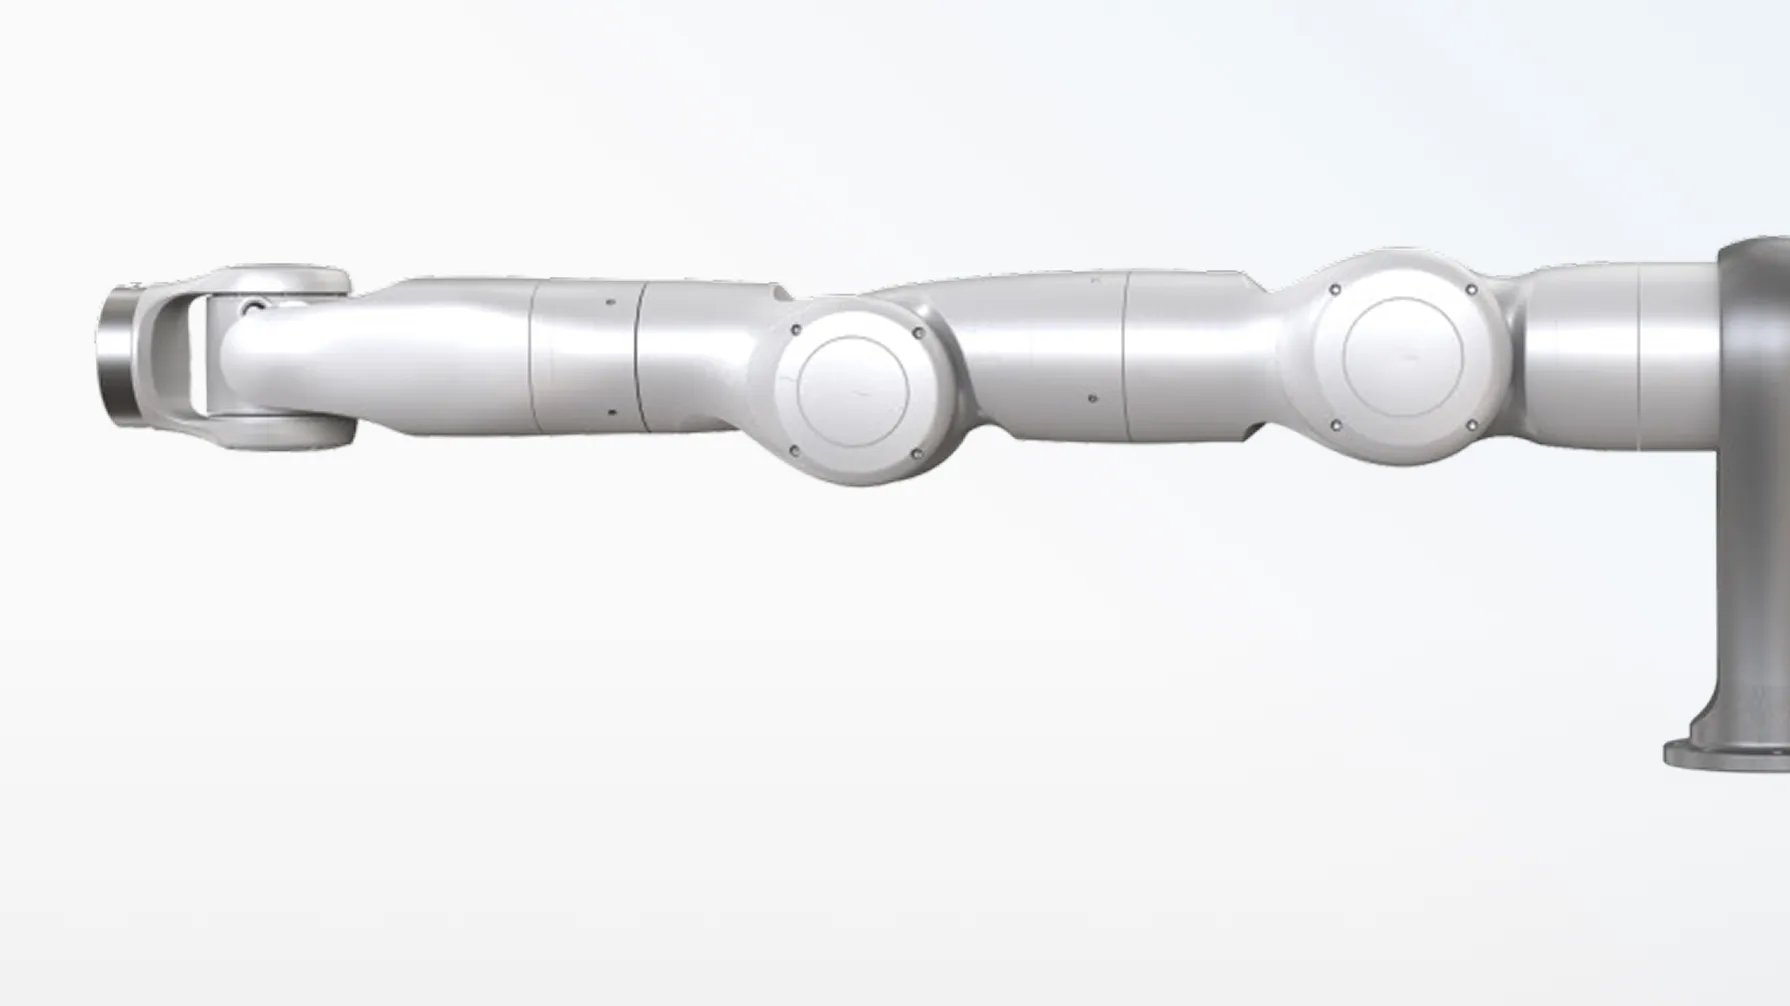 Industrial-Grade Performance · Reliable and Worry-Free
-
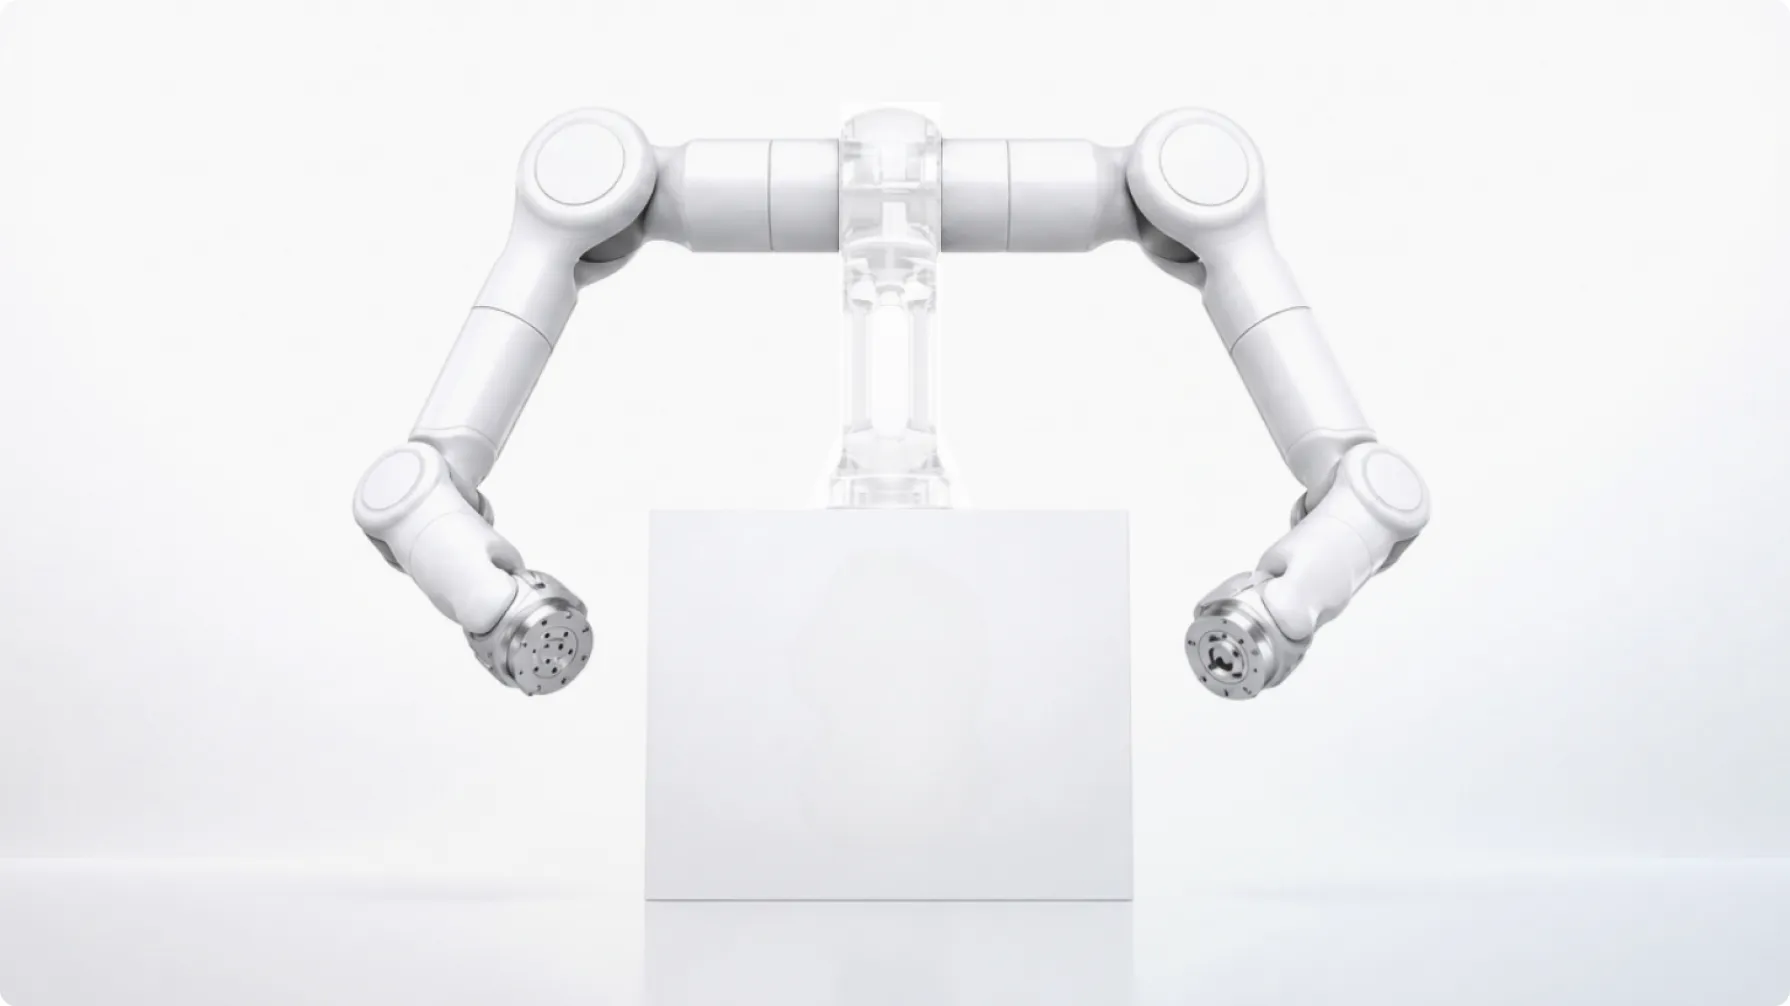 Simple and Easy to Use · Rapid Deployment
Our Advantages
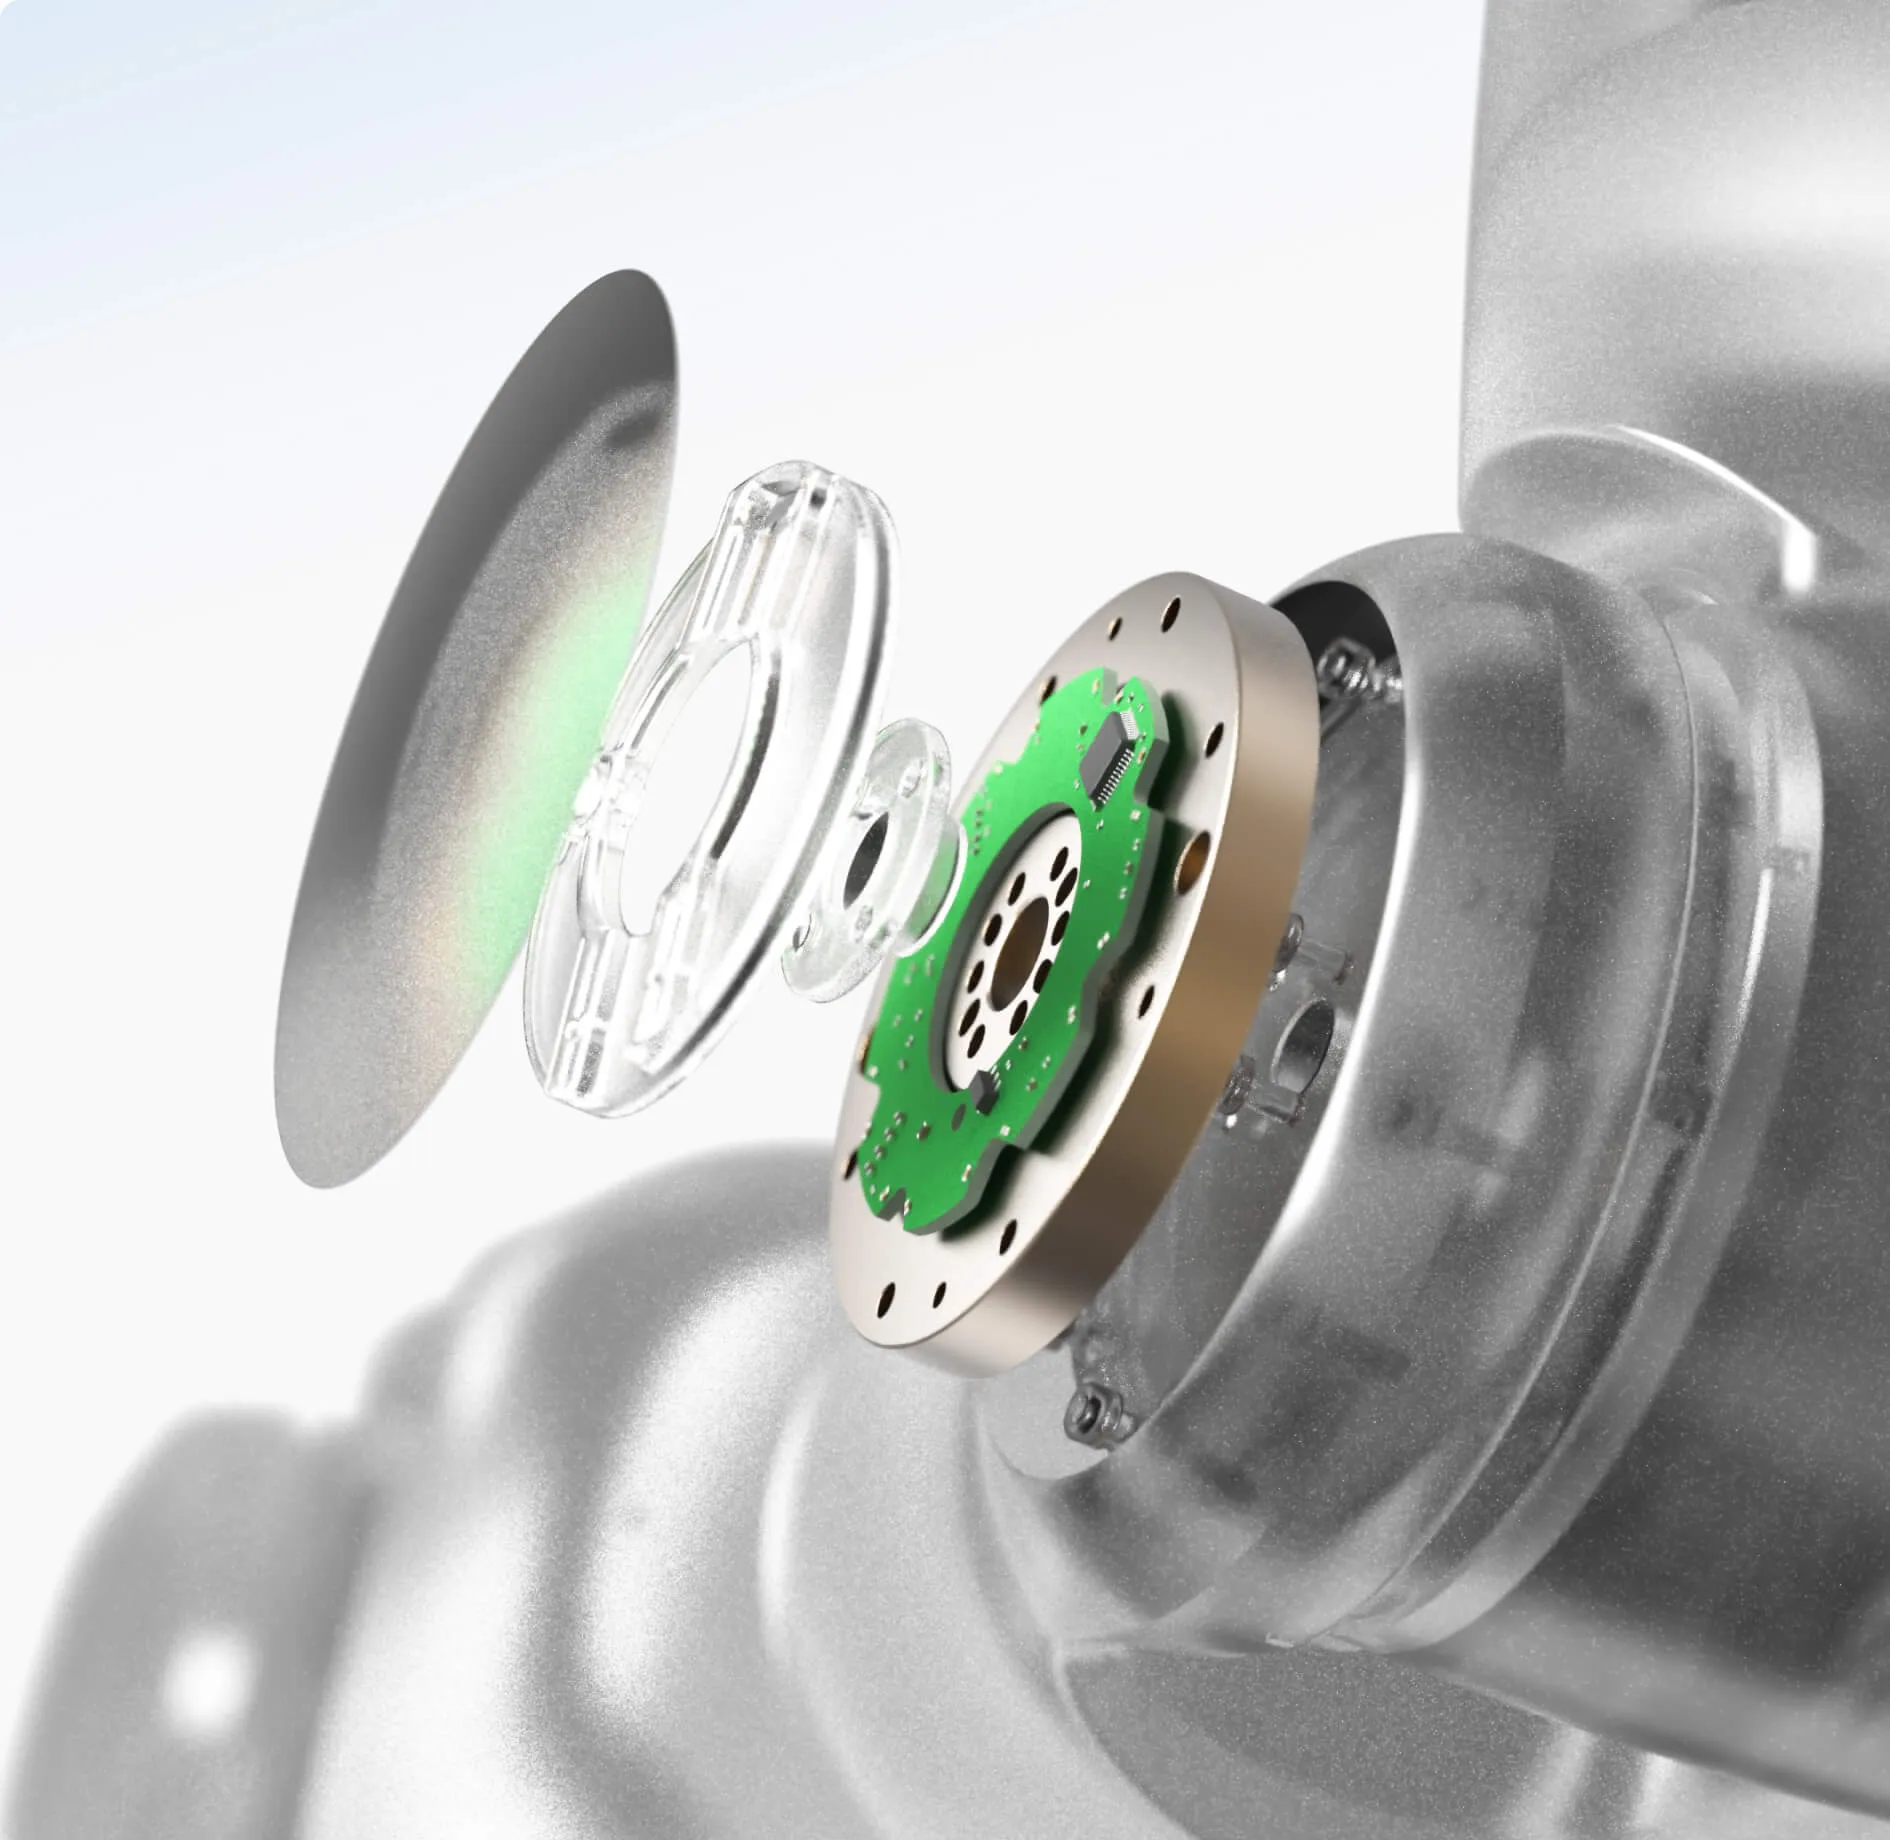
Core Technology: MEMS Joint Torque Sensor
Sensitivity is 10 times that of traditional solutions. Stability is 4 times that of traditional solutions due to the silicon-based technology. Rigidity is 2 times that of other technical approaches due to special material and mechanical design.
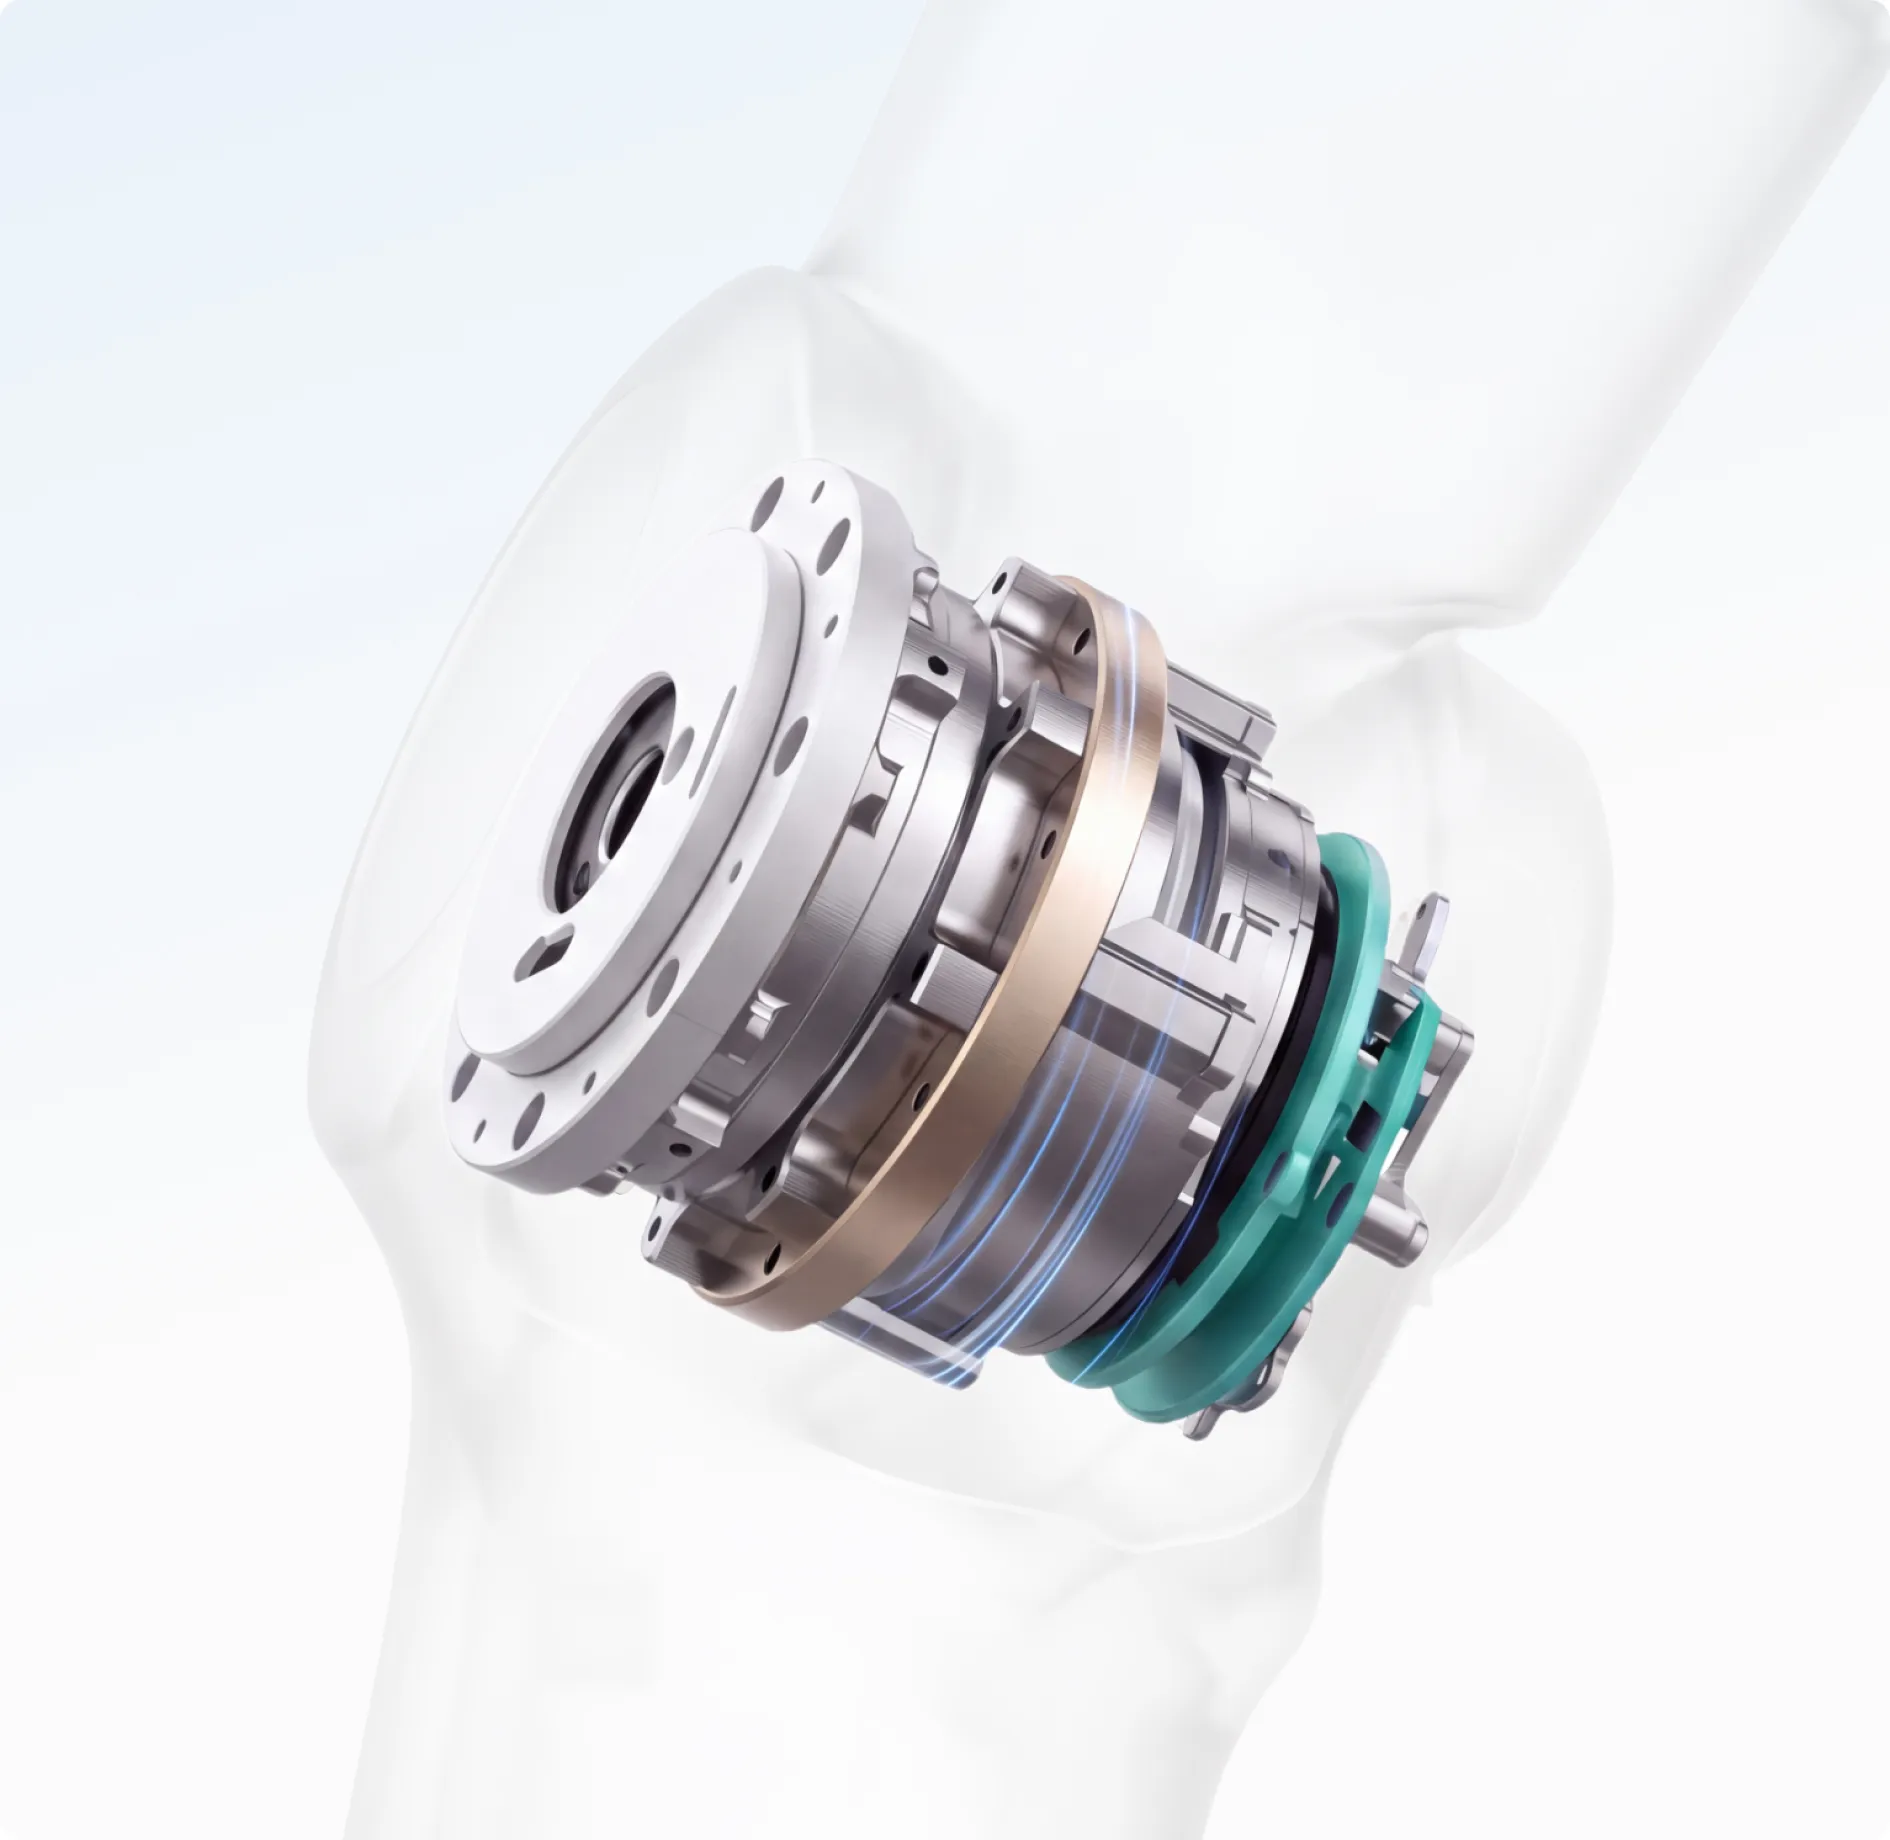
Lightweight Integrated Joint Module
Modular rapid arm assembly, simple and efficient.;
The lightest force-controlled module in its payload class.;
Built-in EtherCAT communication driver, four-loop control (position, velocity, torque, current);
Directly achieves 8k torque closed-loop control on the driver;
Built-in dual absolute encoders for full closed-loop control, no battery required for zero-position recording;
Built-in friction brake retainer, no drift when stopped, no jitter when started.
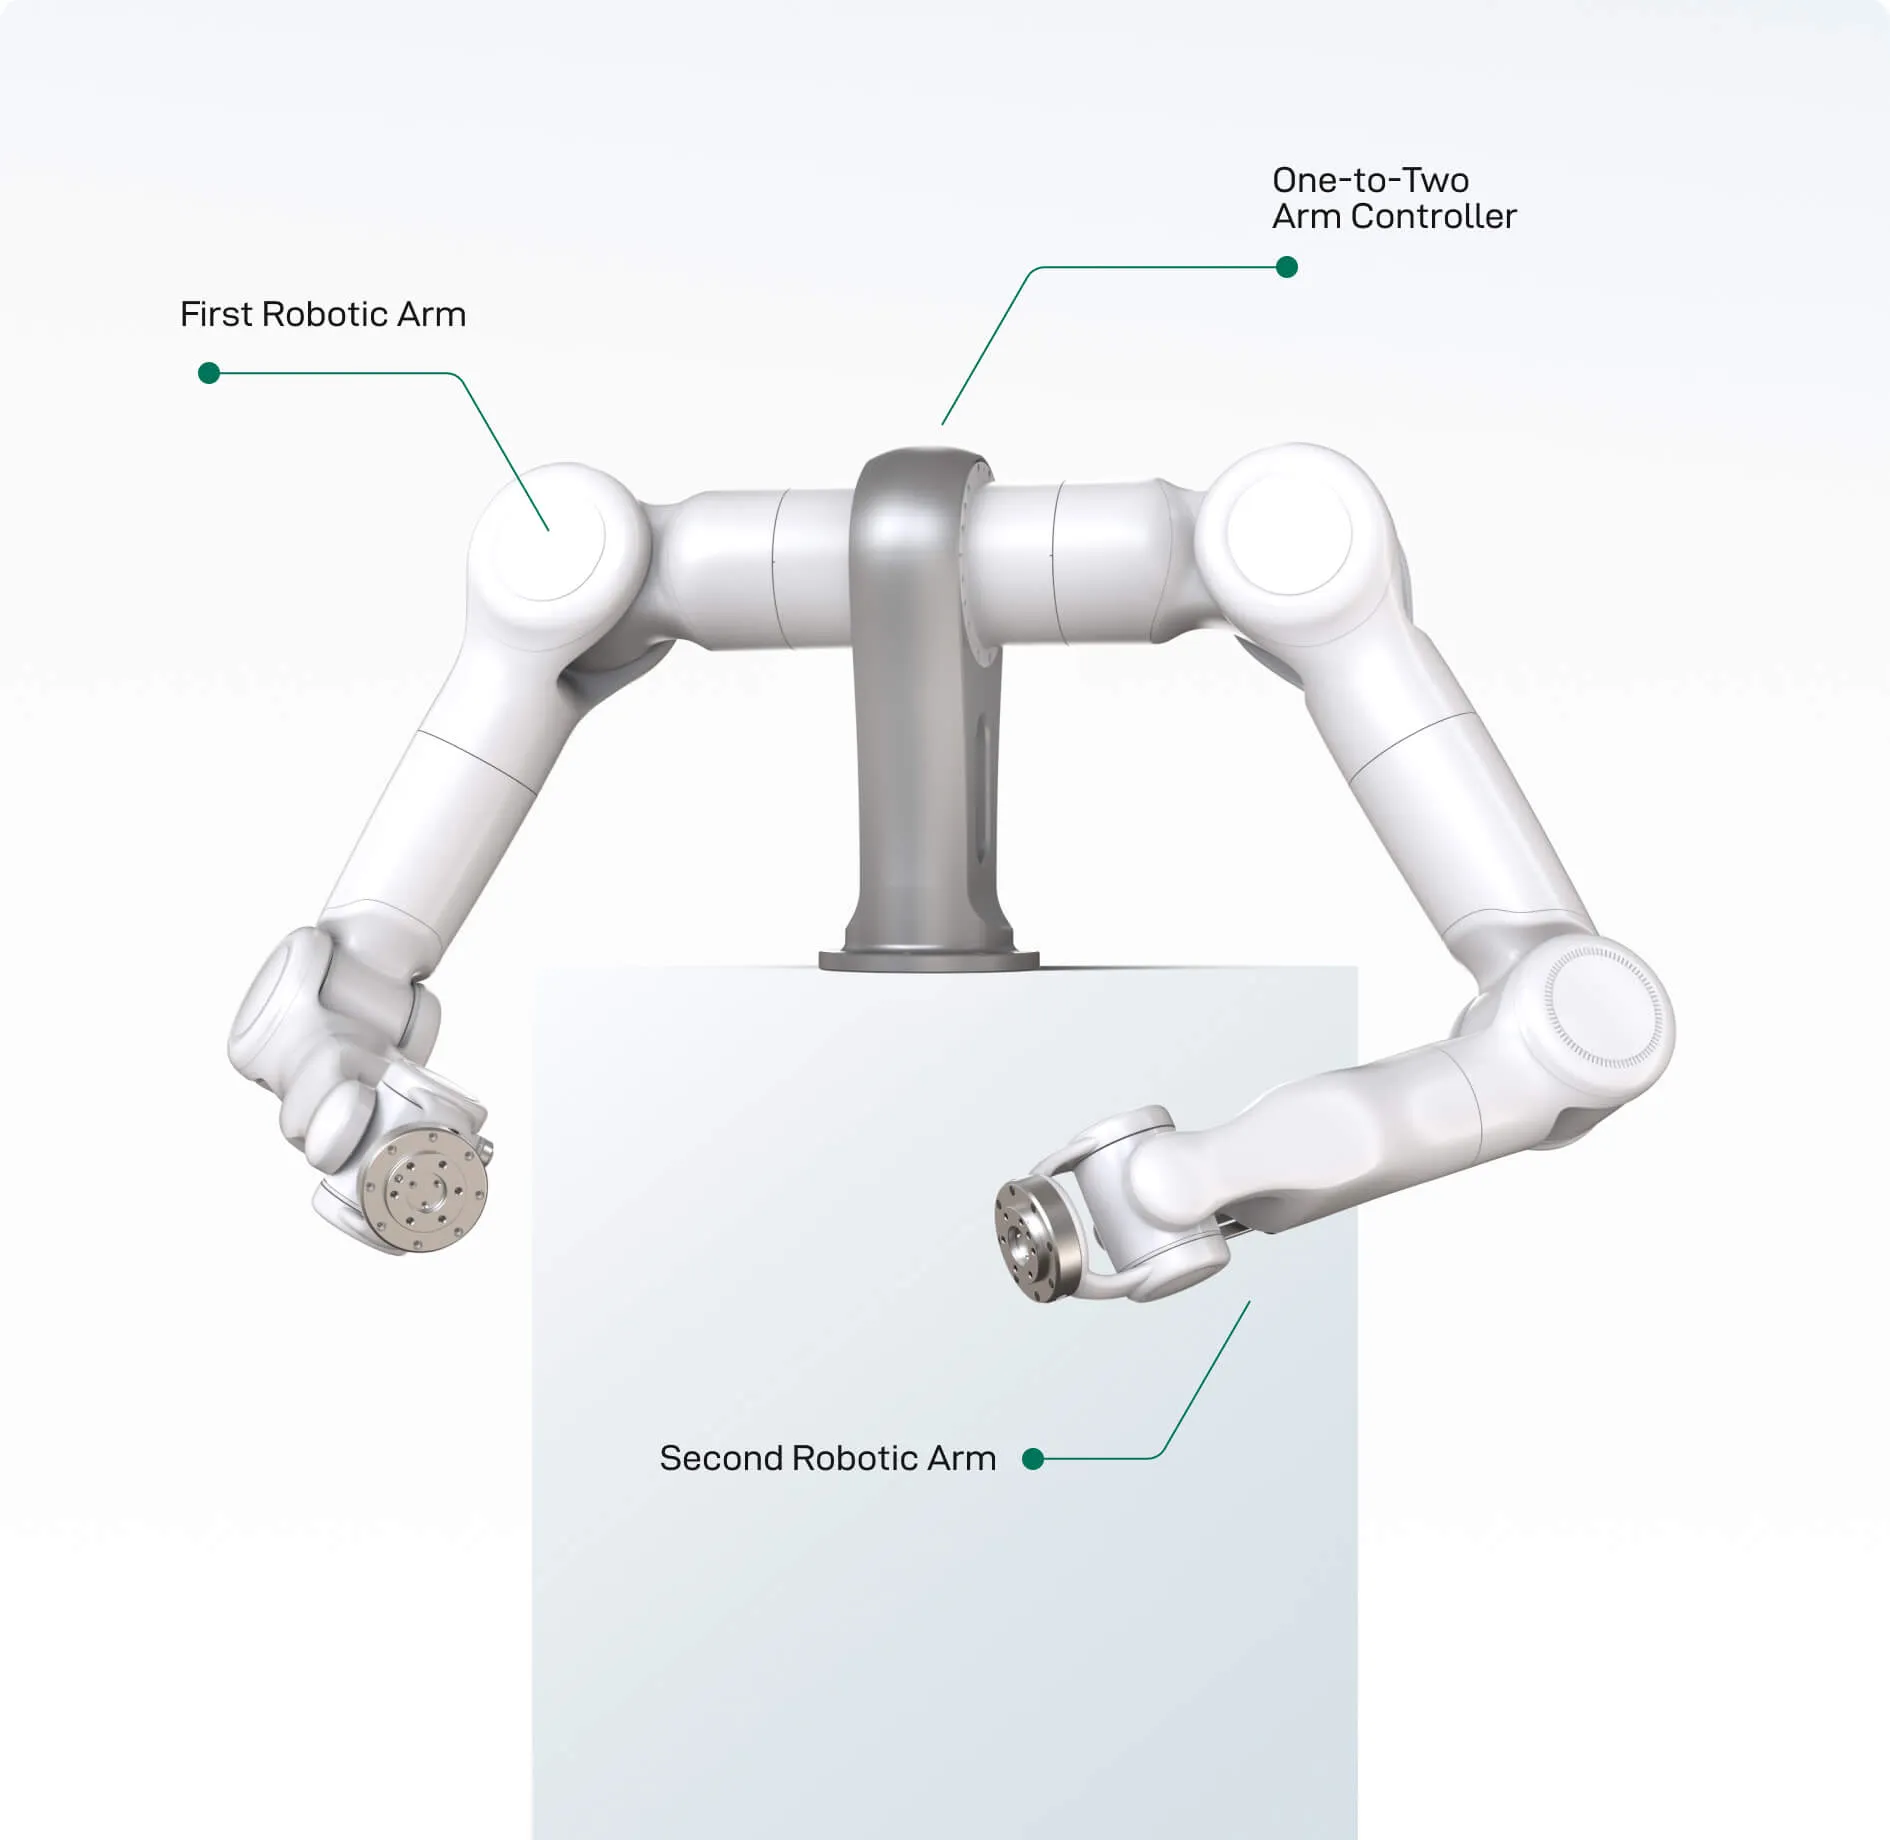
Tianji One-to-Two Controller
One controller controls two arms; compact size, easy to deploy;
Provides secondary development interfaces, encapsulating complex functions into interfaces to lower the development barrier;
Marvin.SDK provides typical application demo examples.
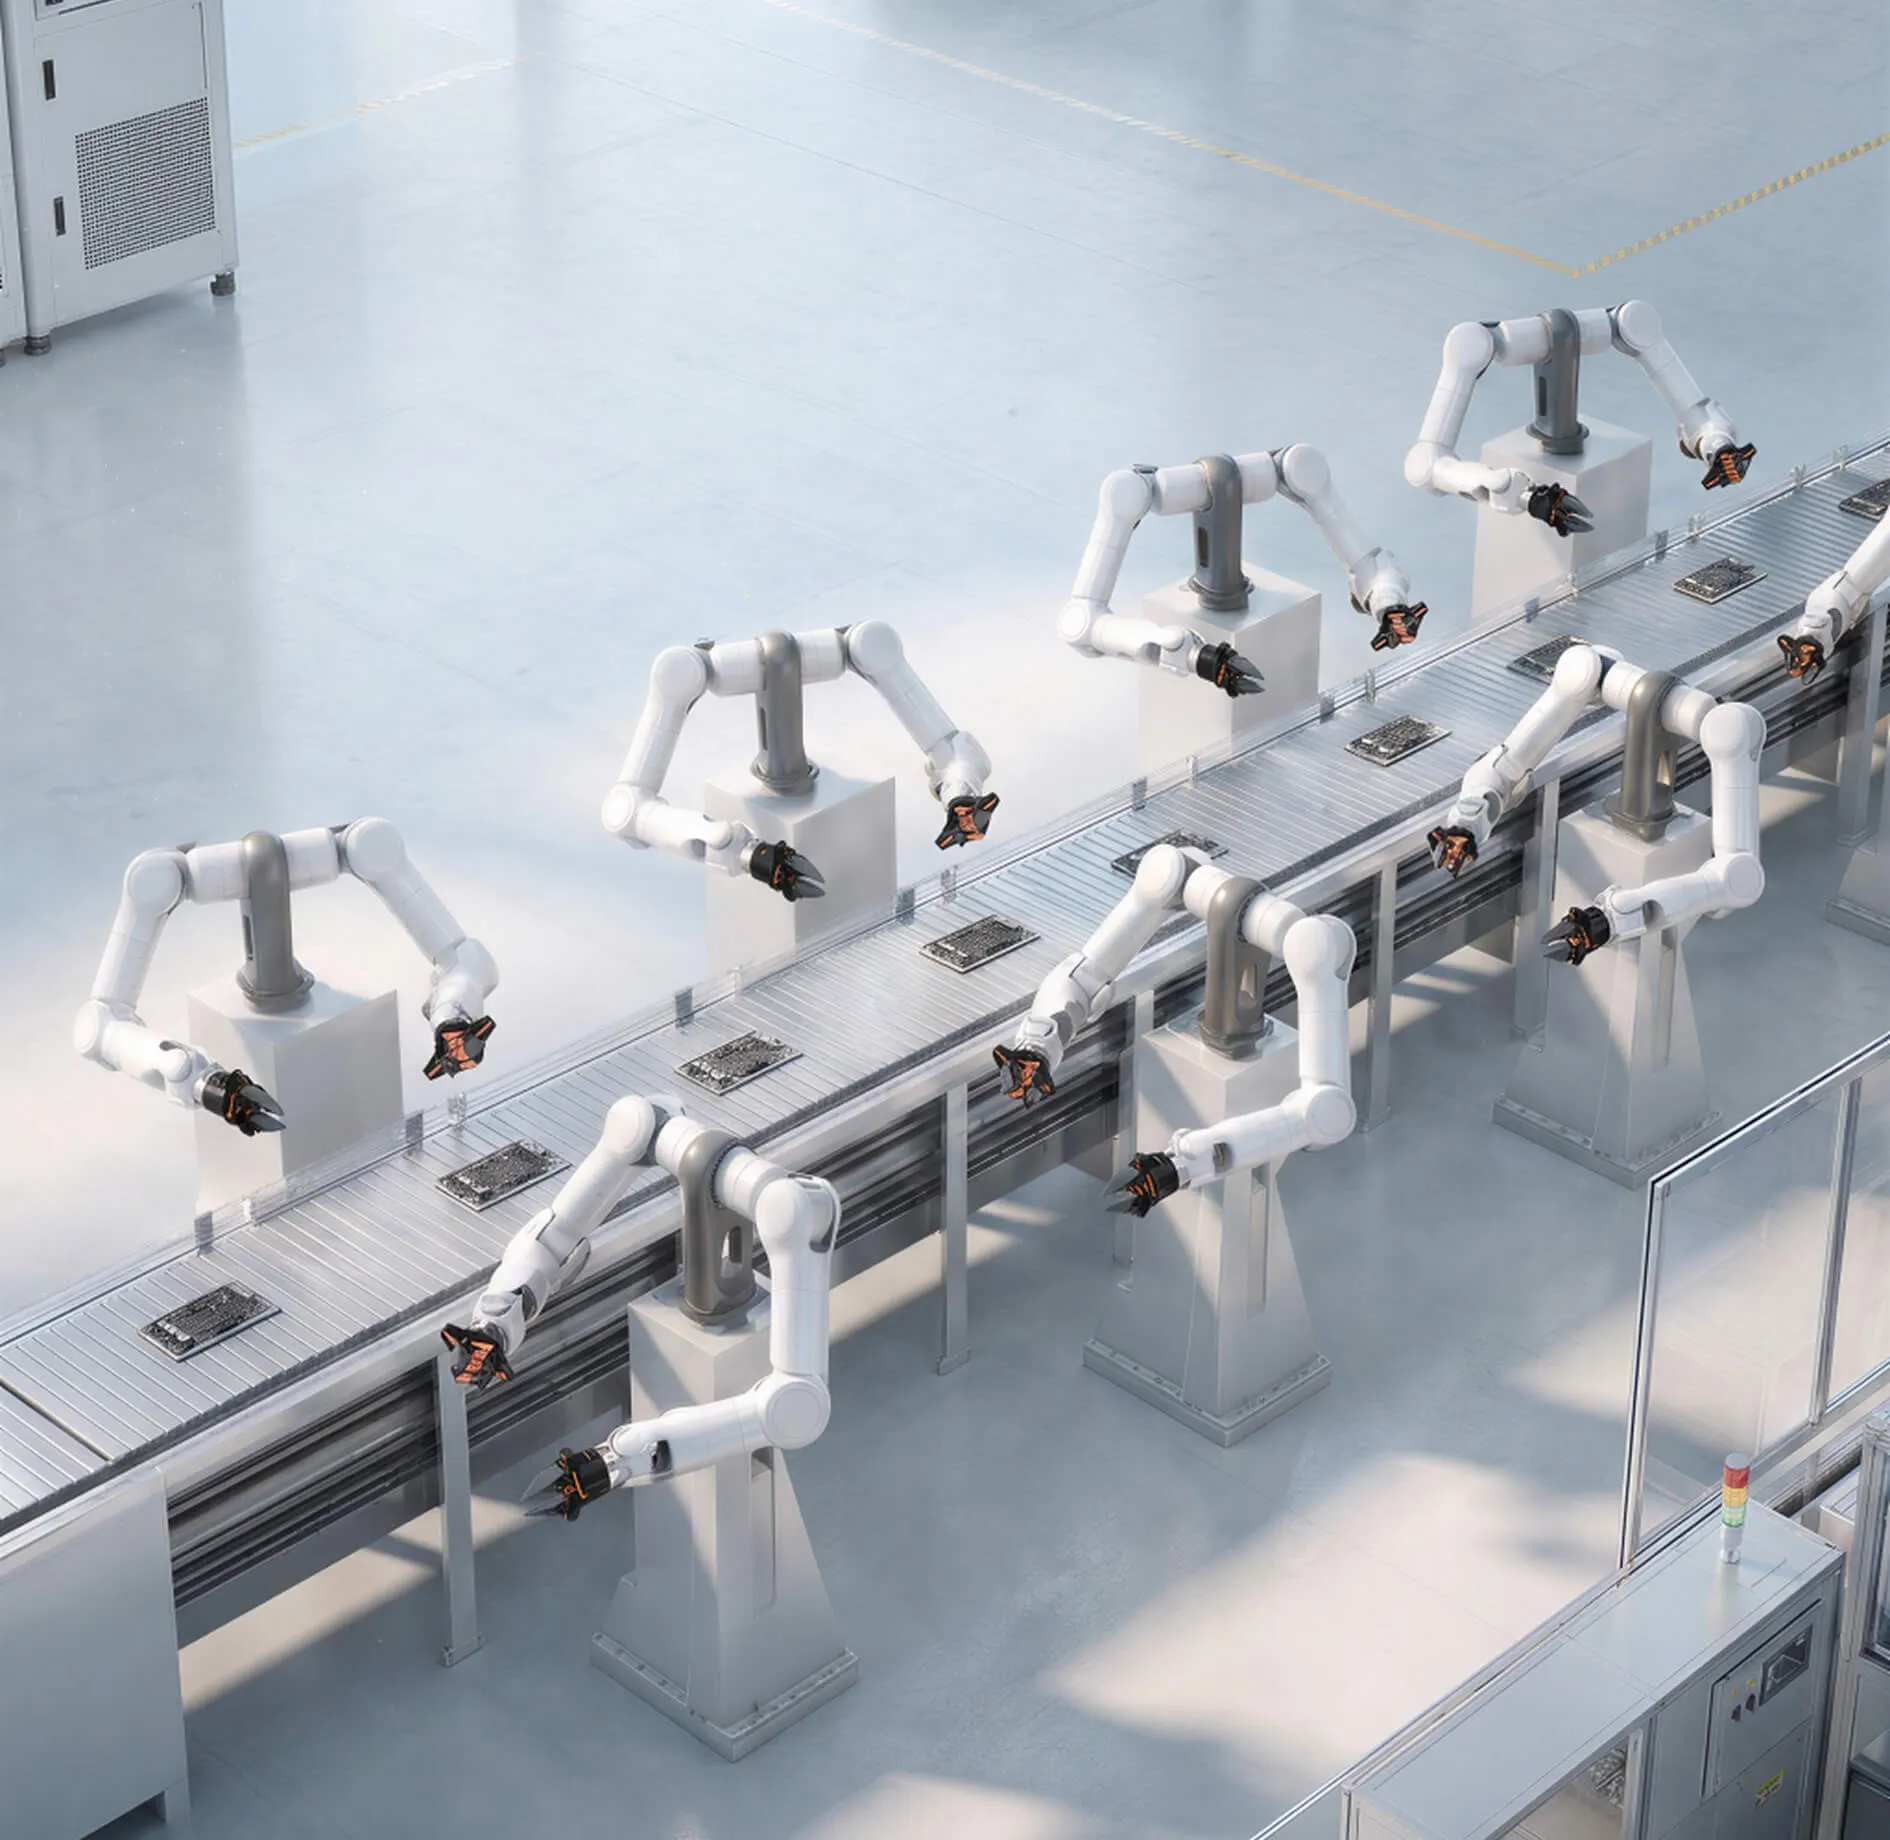
Impedance Control Dynamic Tracking Algorithm
Demonstrates natural compliance in human-robot interaction scenarios, reducing impact force.;
Adapts to external changes in unknown environments, improving task execution efficiency and reliability.;
In precision flexible assembly scenarios, flexible adjustment avoids damaging the objects being manipulated.
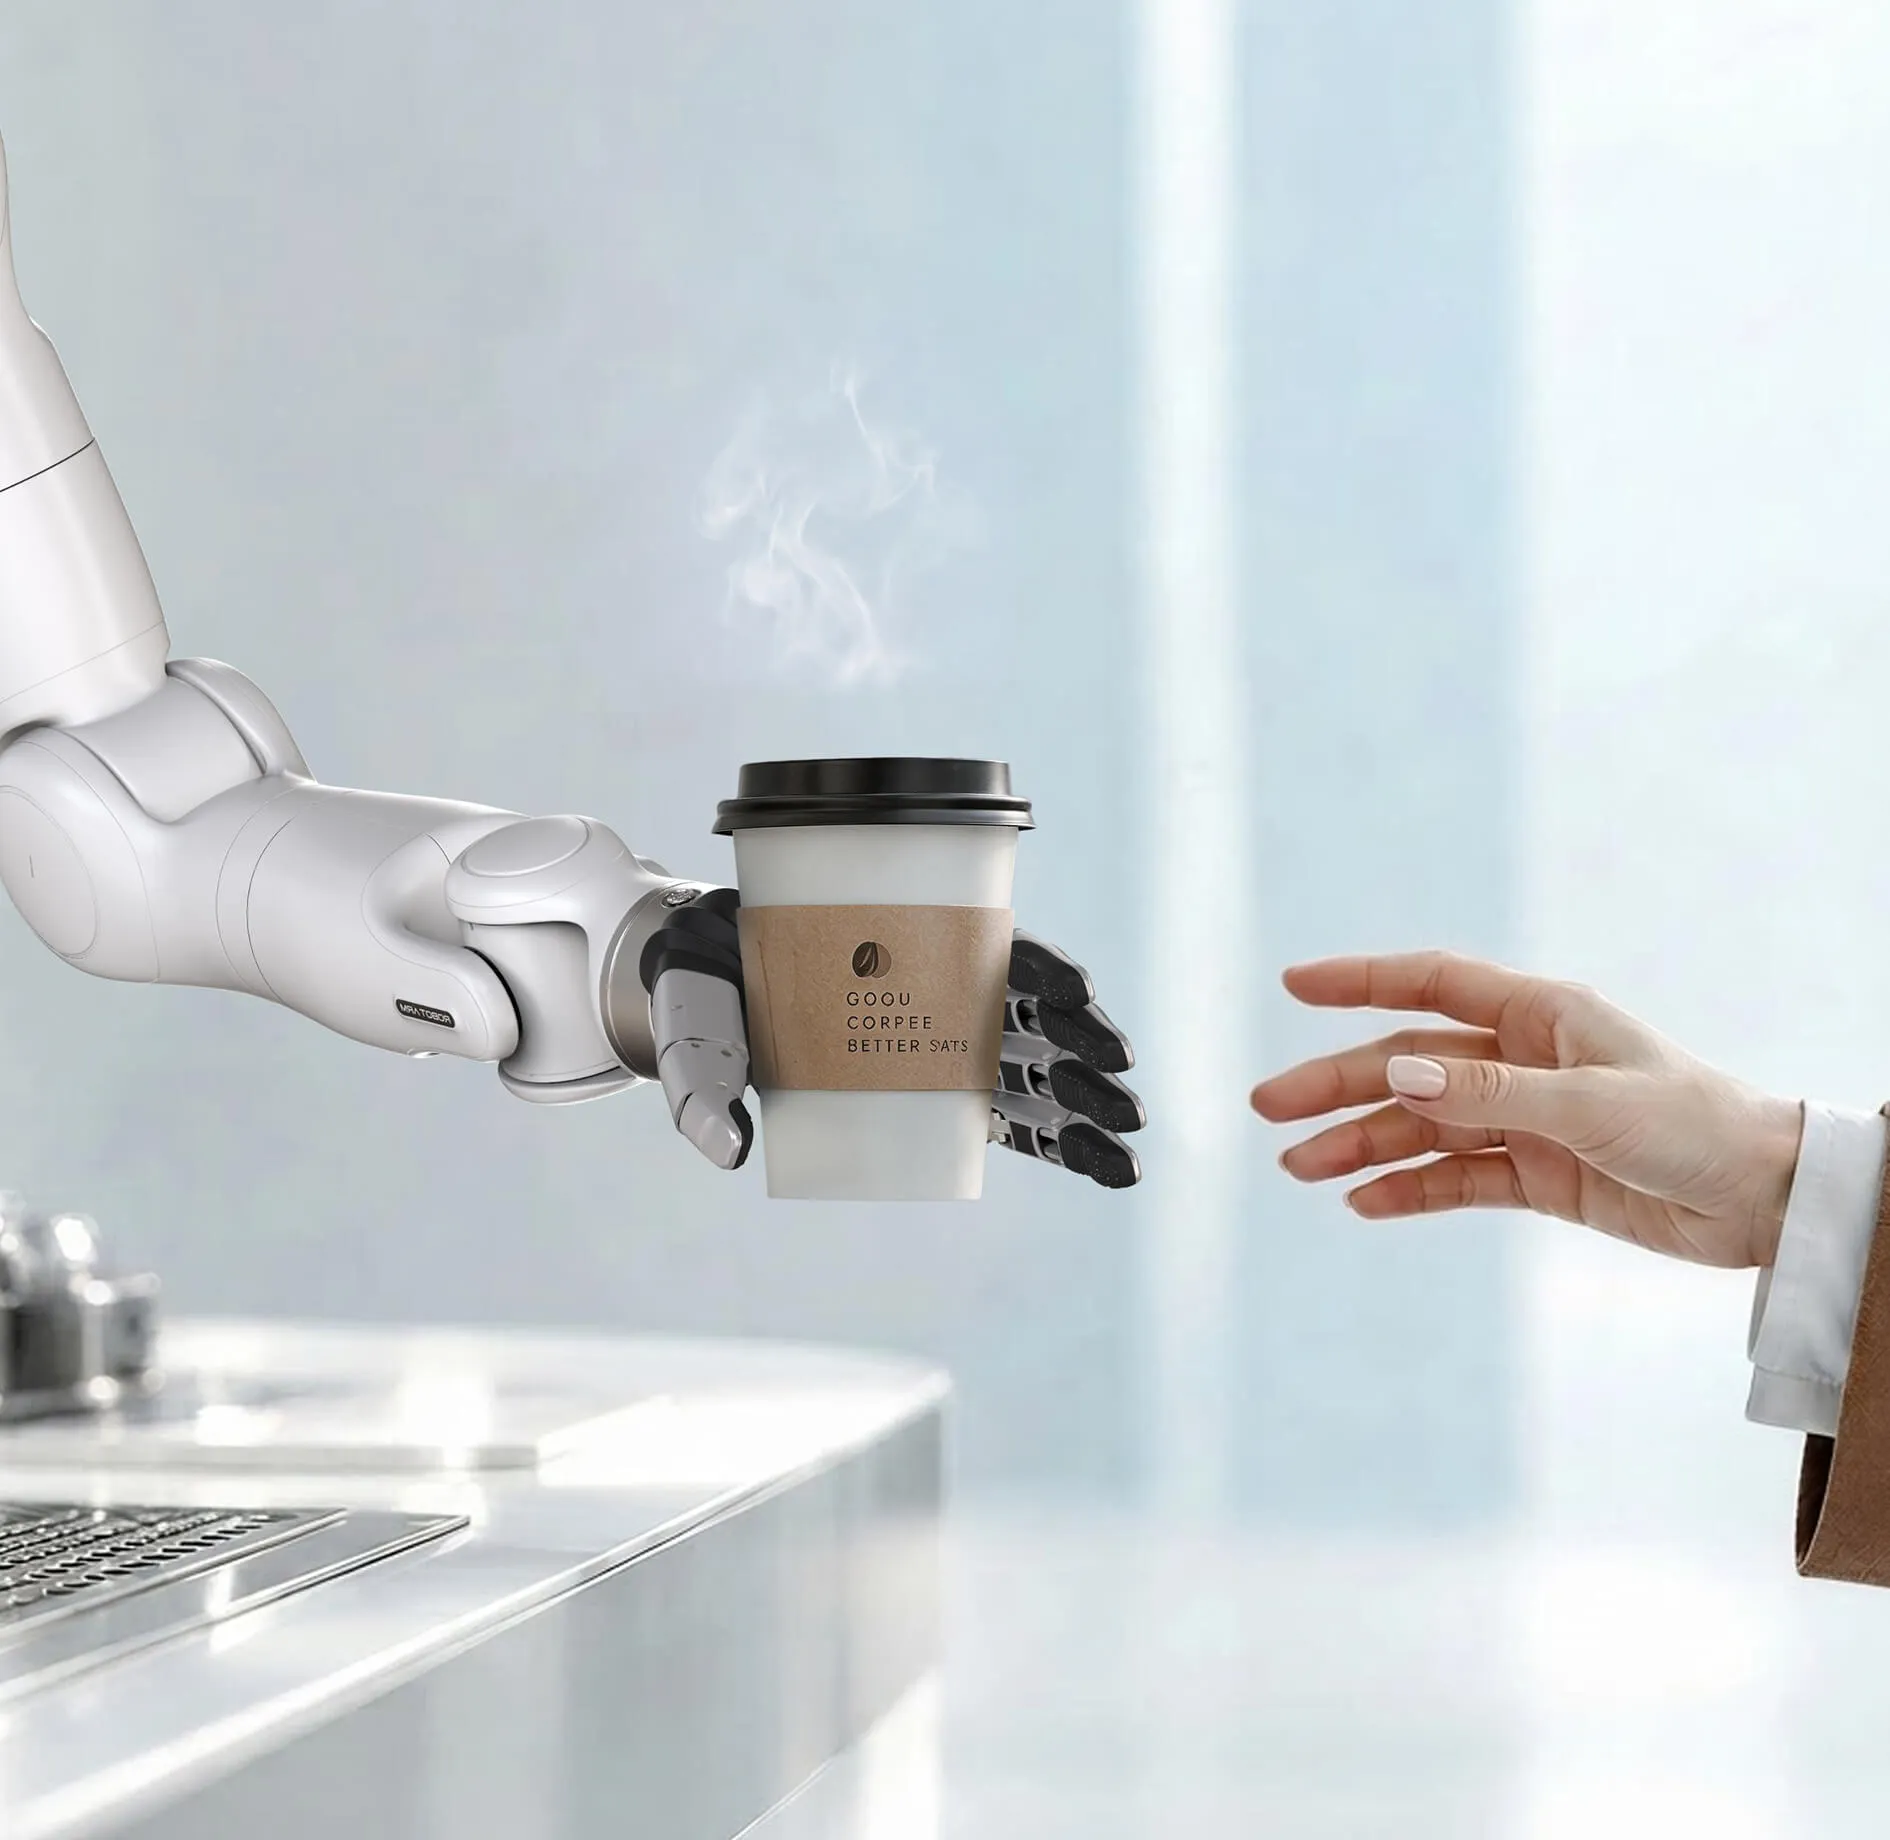
Crossed Wrist Design
Achieves fully anthropomorphic and highly flexible wrist movements.;
Avoids the degree-of-freedom degeneration problem of traditional designs; its motion characteristics match the biomechanical structure of the human wrist joint.;
Smaller turning radius; adjusting the grasping posture has less impact on the spatial position of the wrist joint.;
Significantly improves the naturalness of control and scenario adaptability during remote teleoperation.
All-Joint Force Control, Safe Interaction, and Industrial-Grade Reliability
-
7Number of joints per arm
-
6kgRated payload per arm
-
696 mmWorking radius
-
12.45 kgBody weight (single arm)
To suit different industries, we offer different models
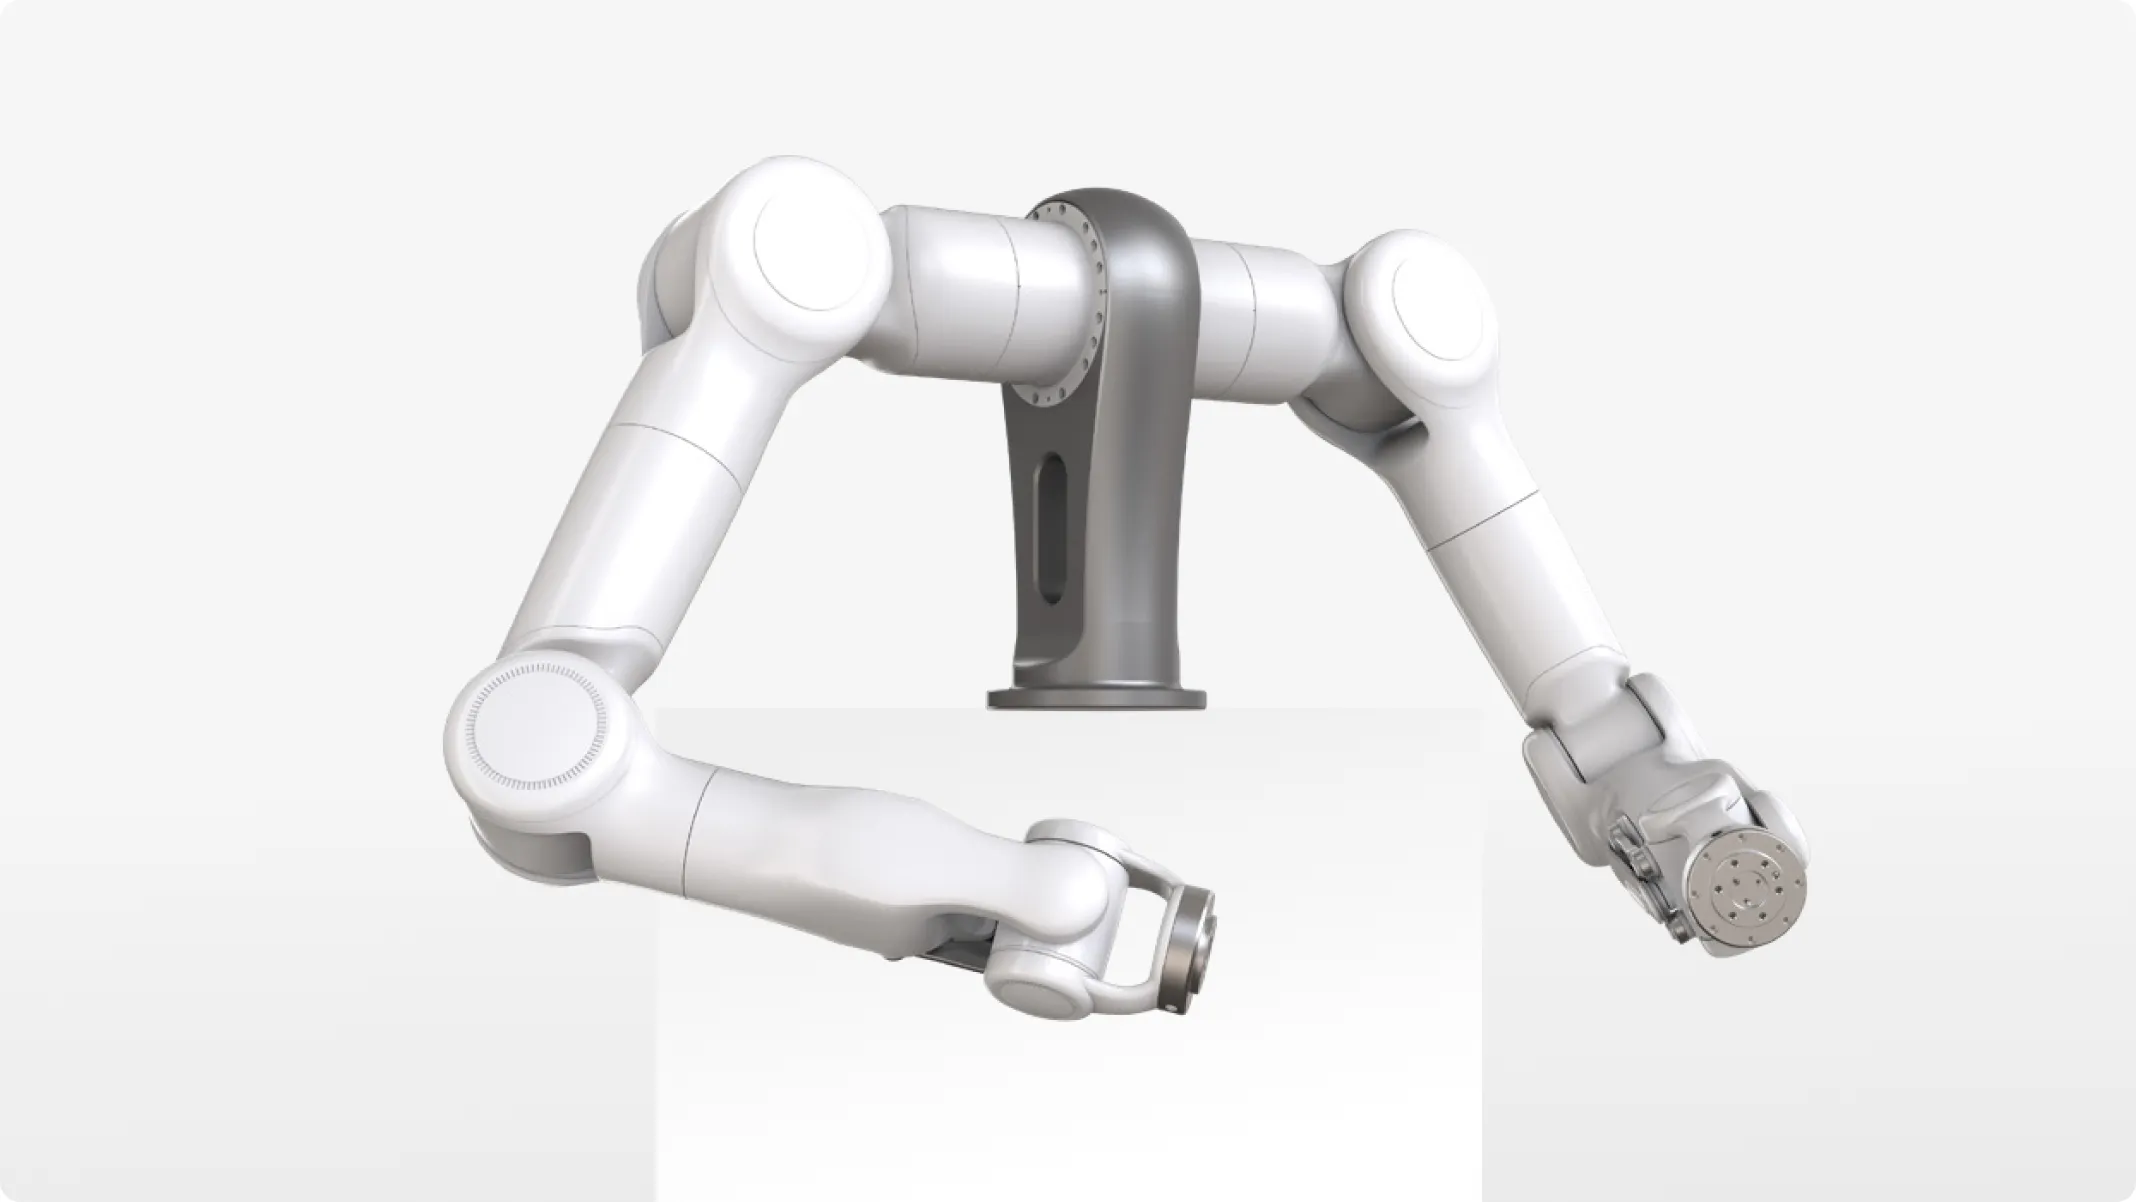
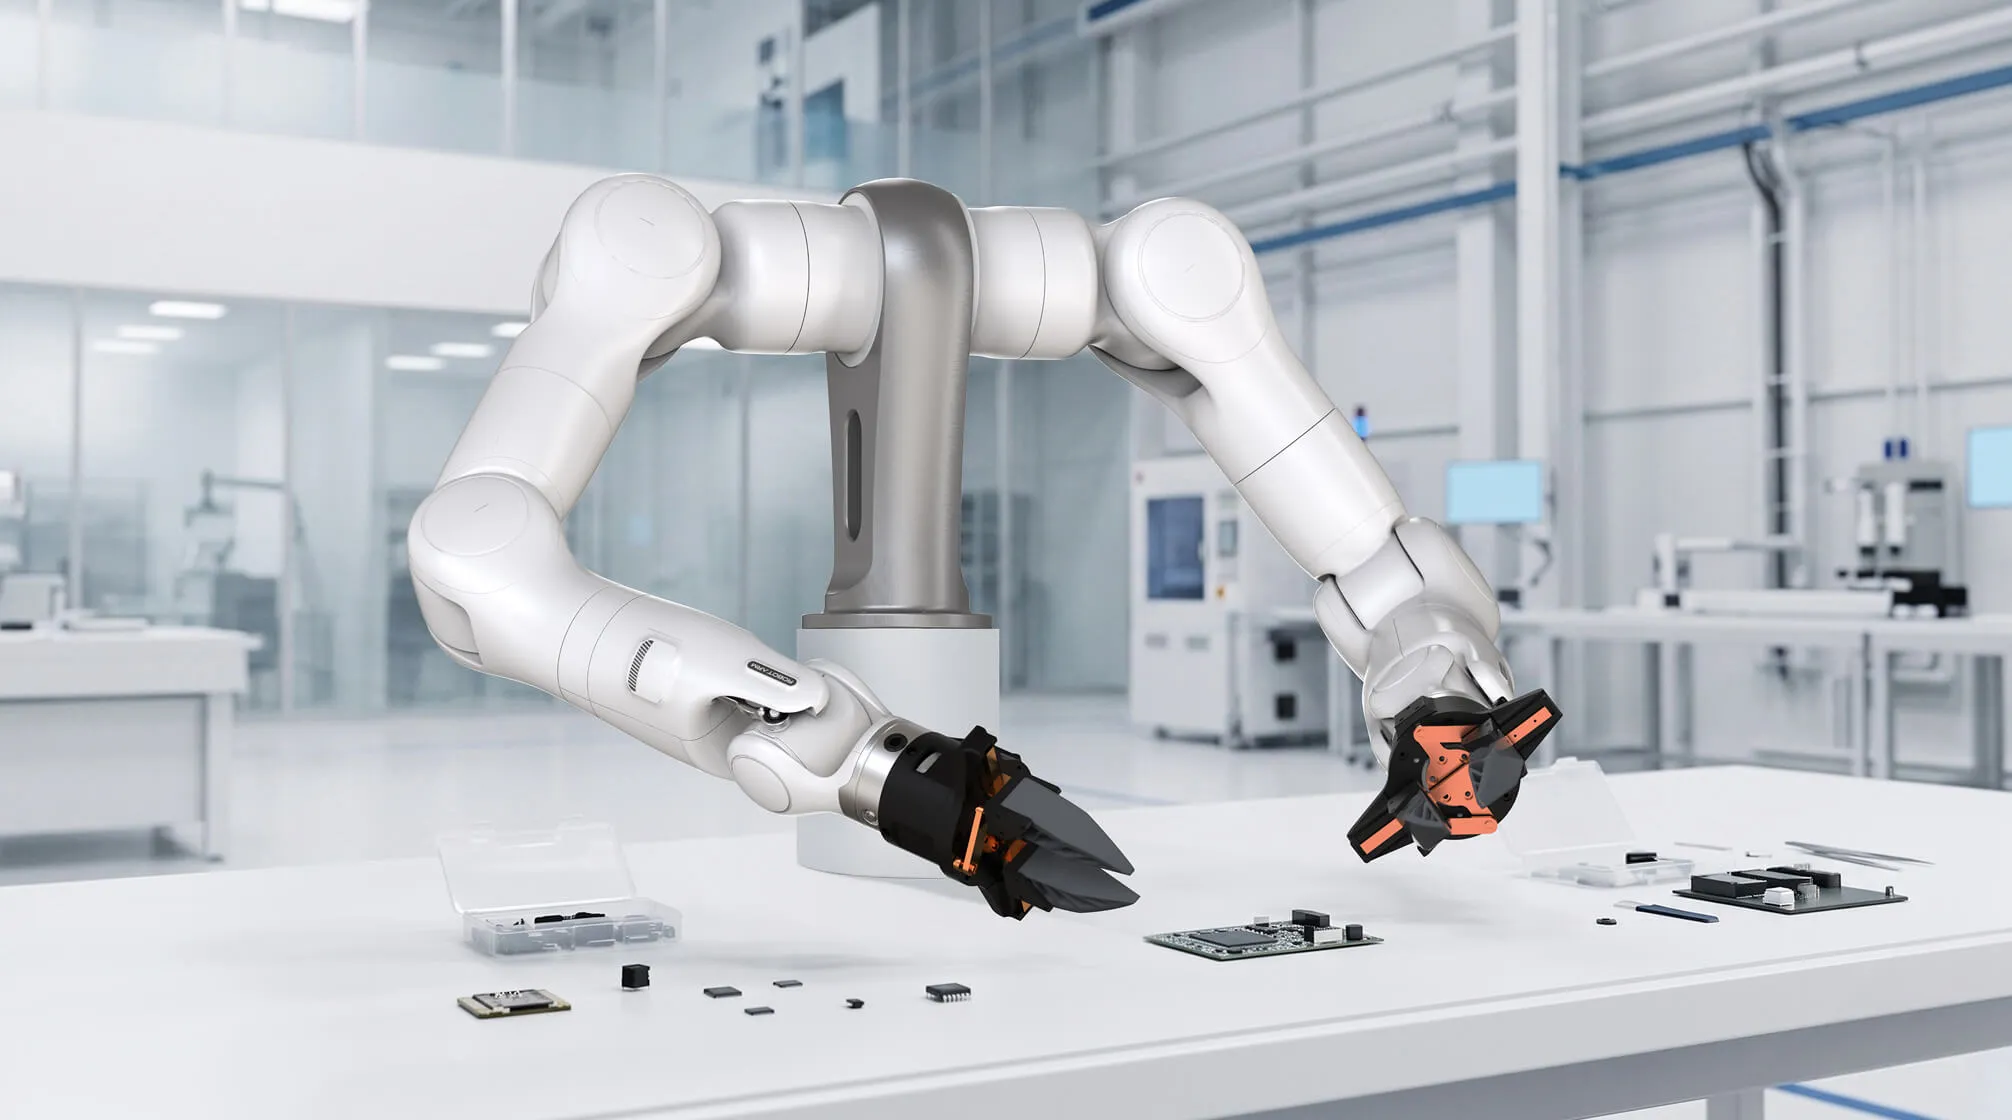
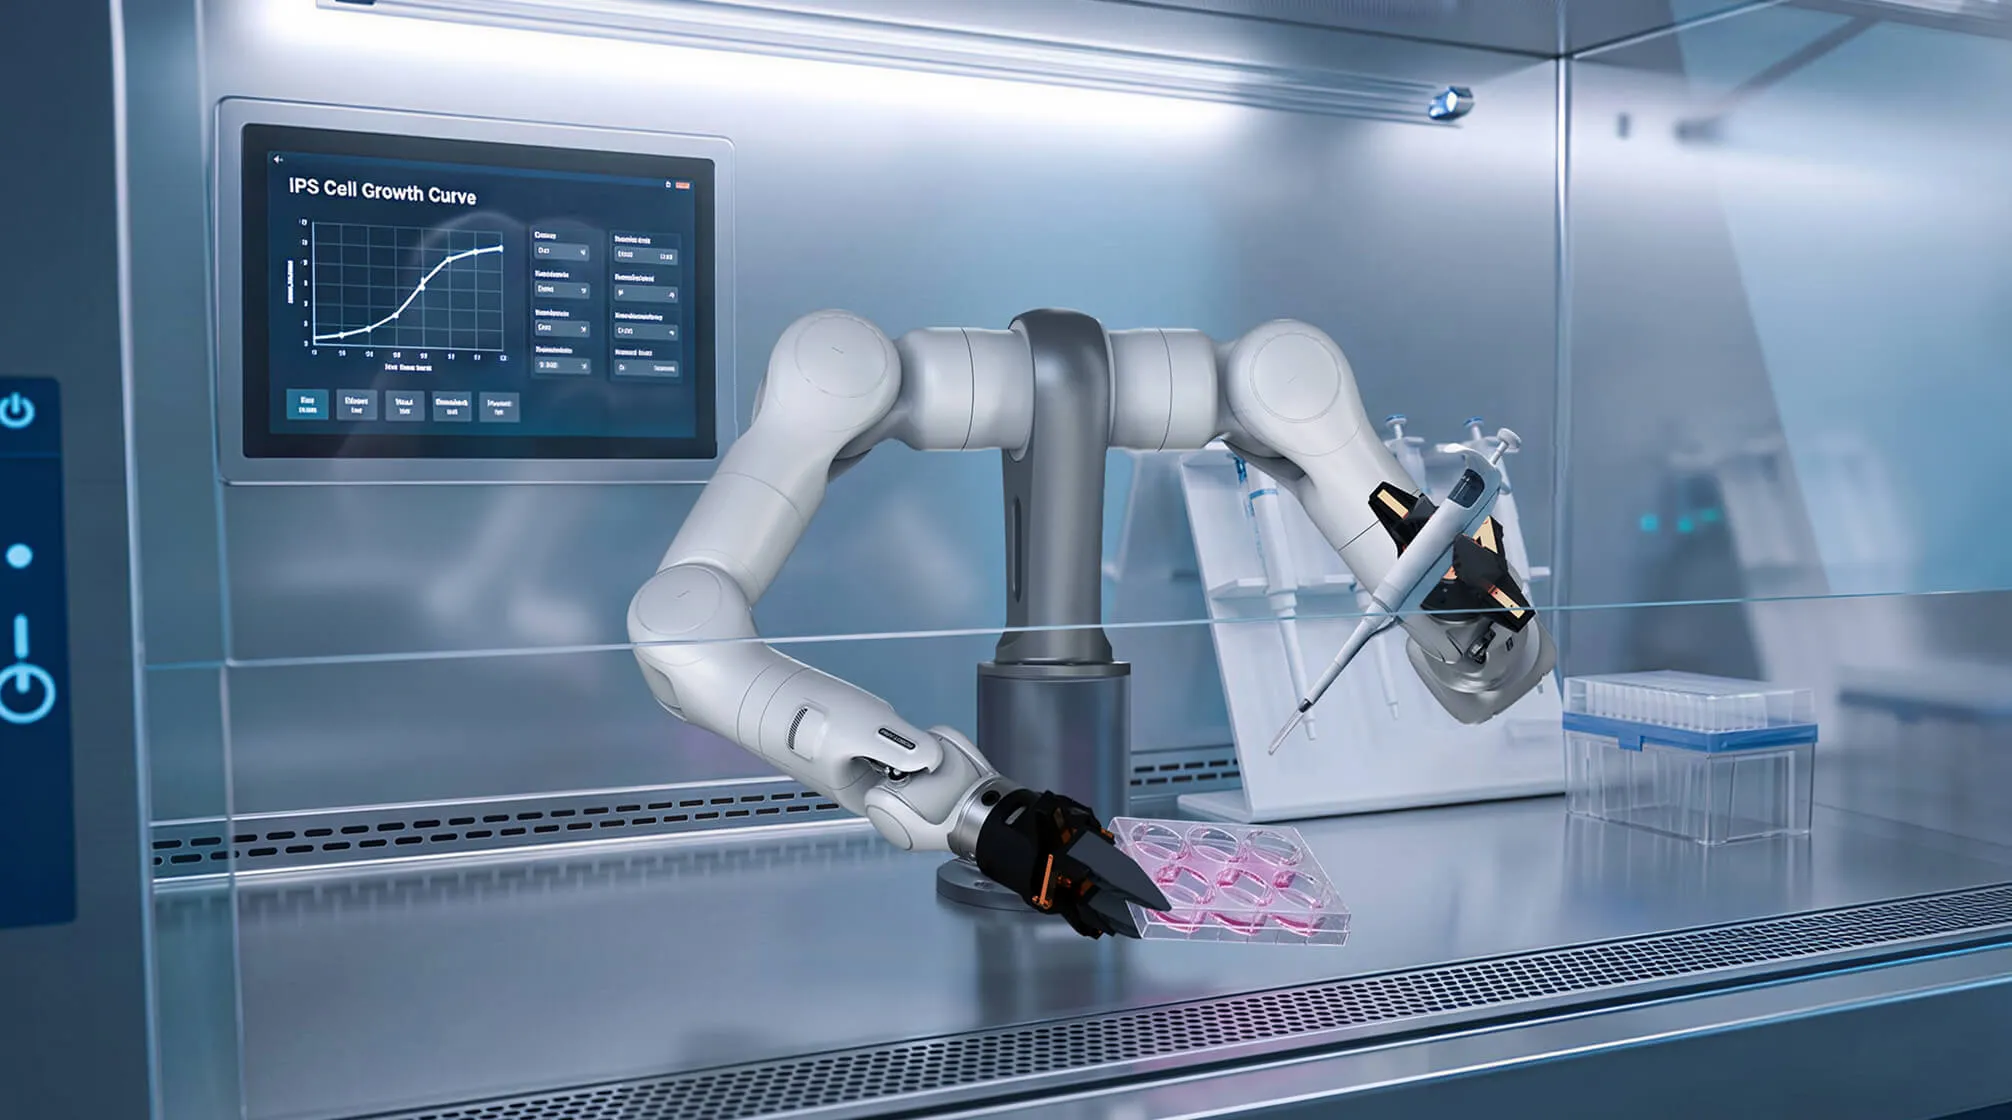
Bringing precise power to every scenario
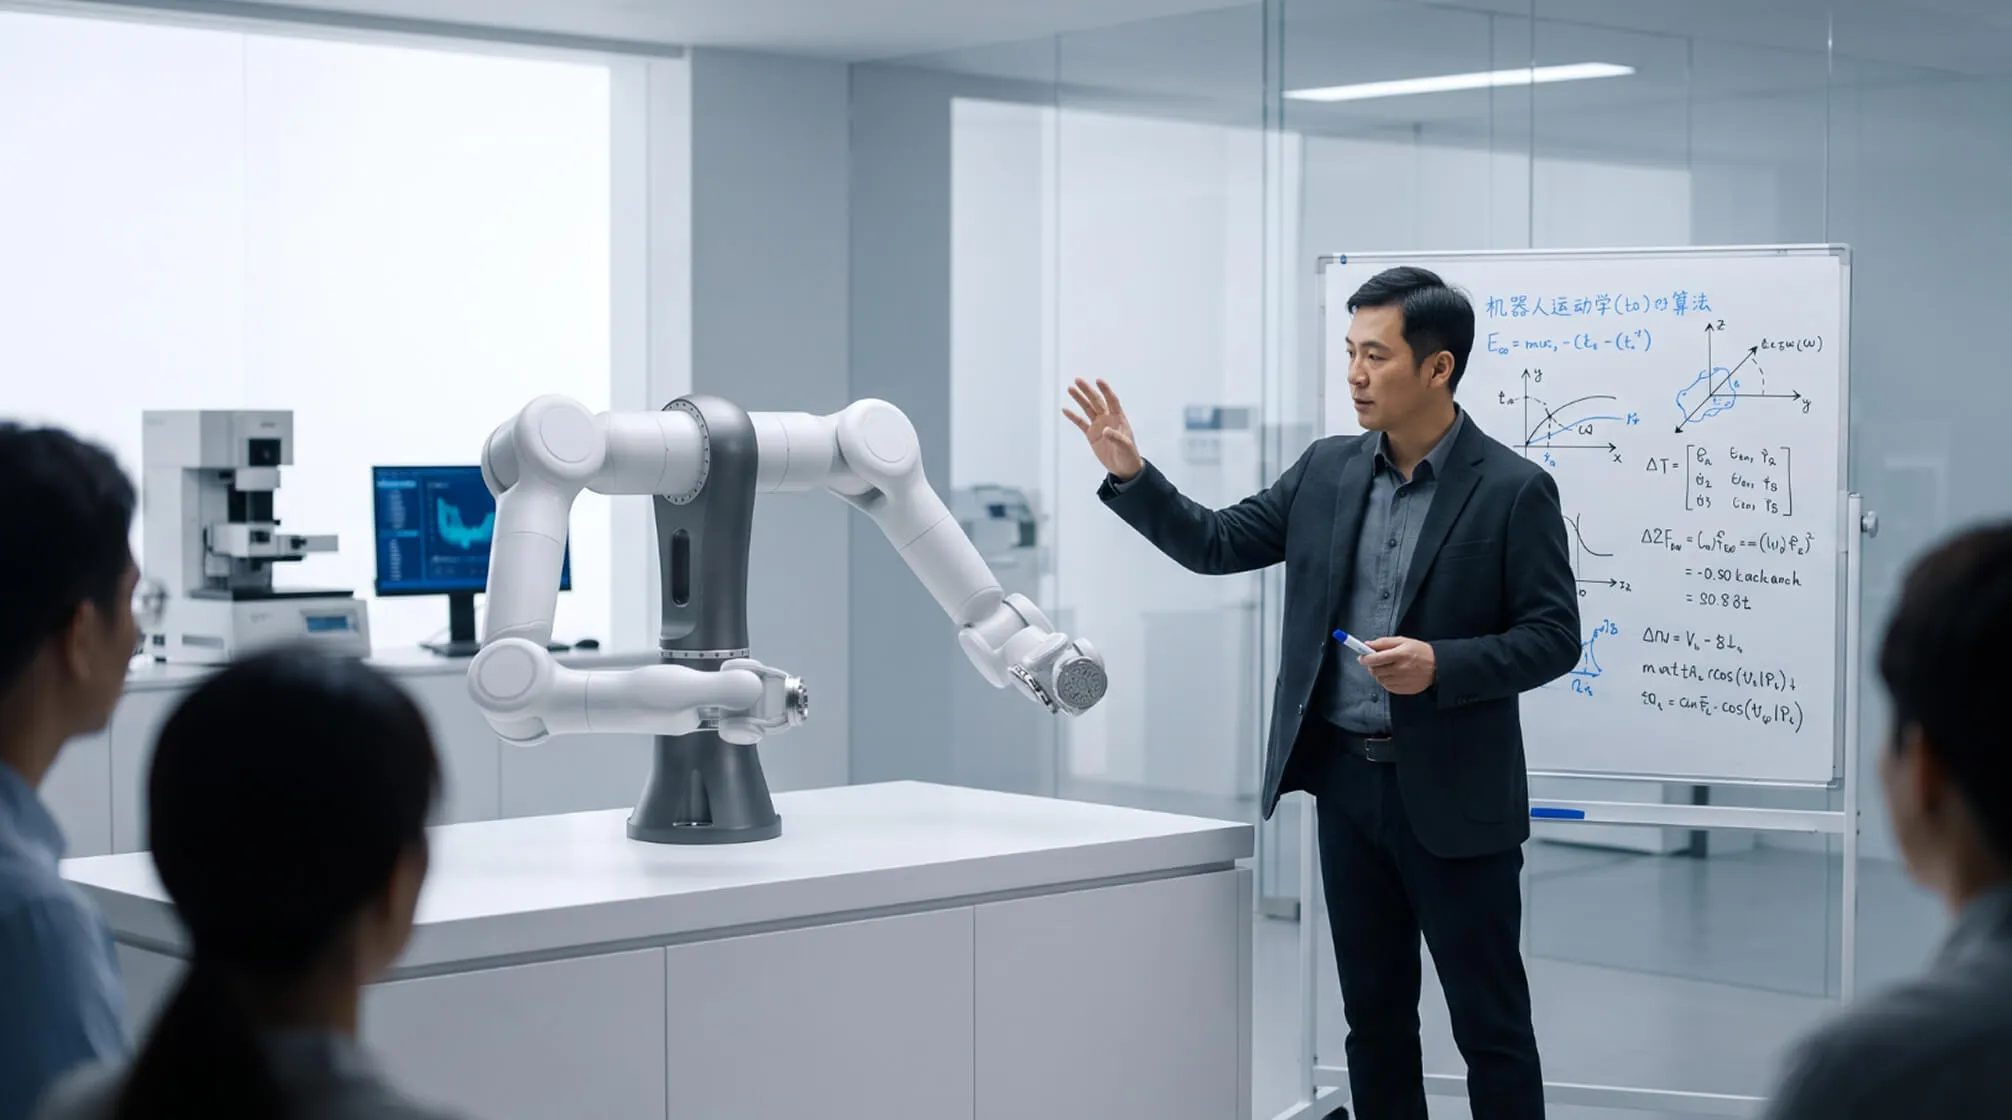
Marvin Series Specifications
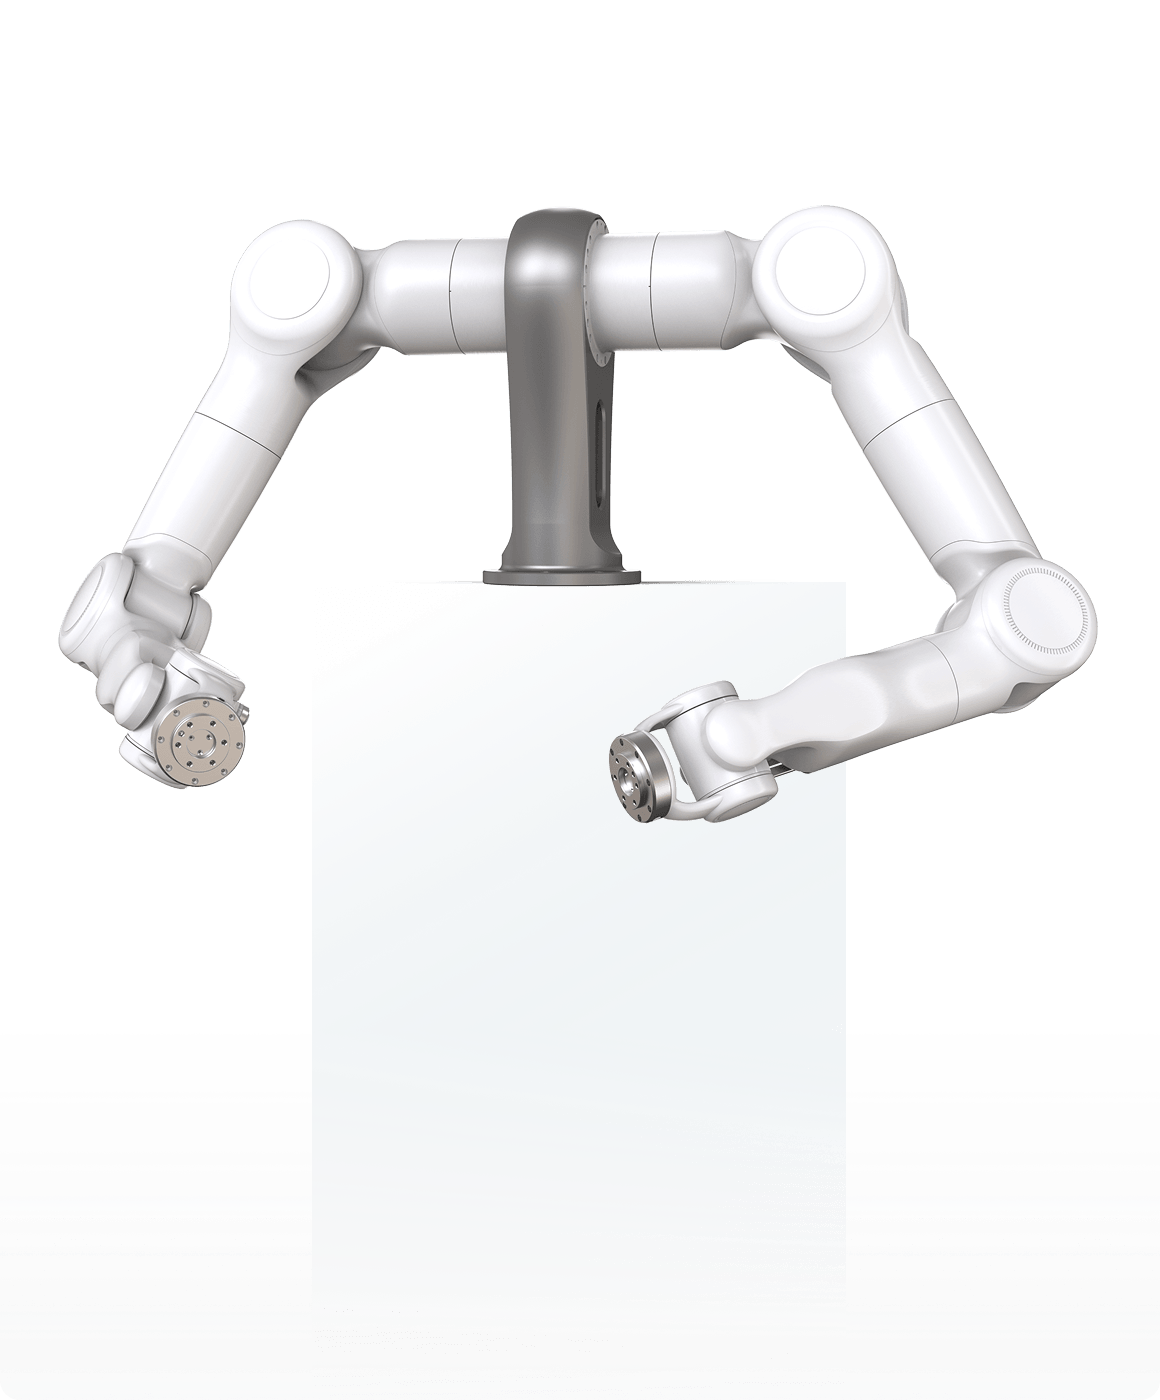
Rated payload
3 – 20 kg
Working radius
615 – 1050 mm
Repeatability
±0.03 – ±0.1 mm
Max TCP speed
1.5 – 2 m/s
Body weight (single arm)
8.45 – 35.6 kg
IP rating
IP50 / IP65
Let "It" be your good helper
More Products
-
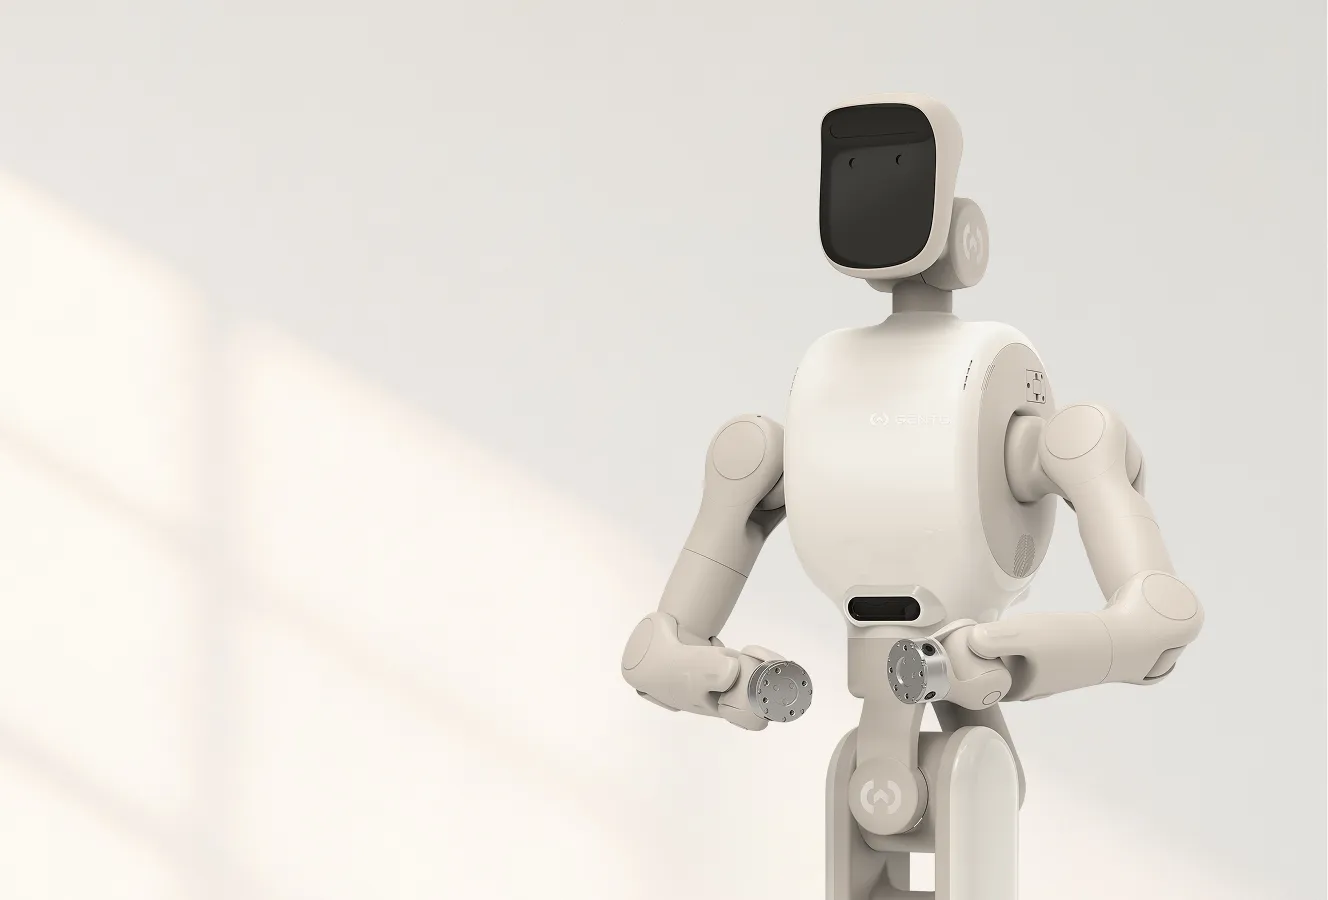
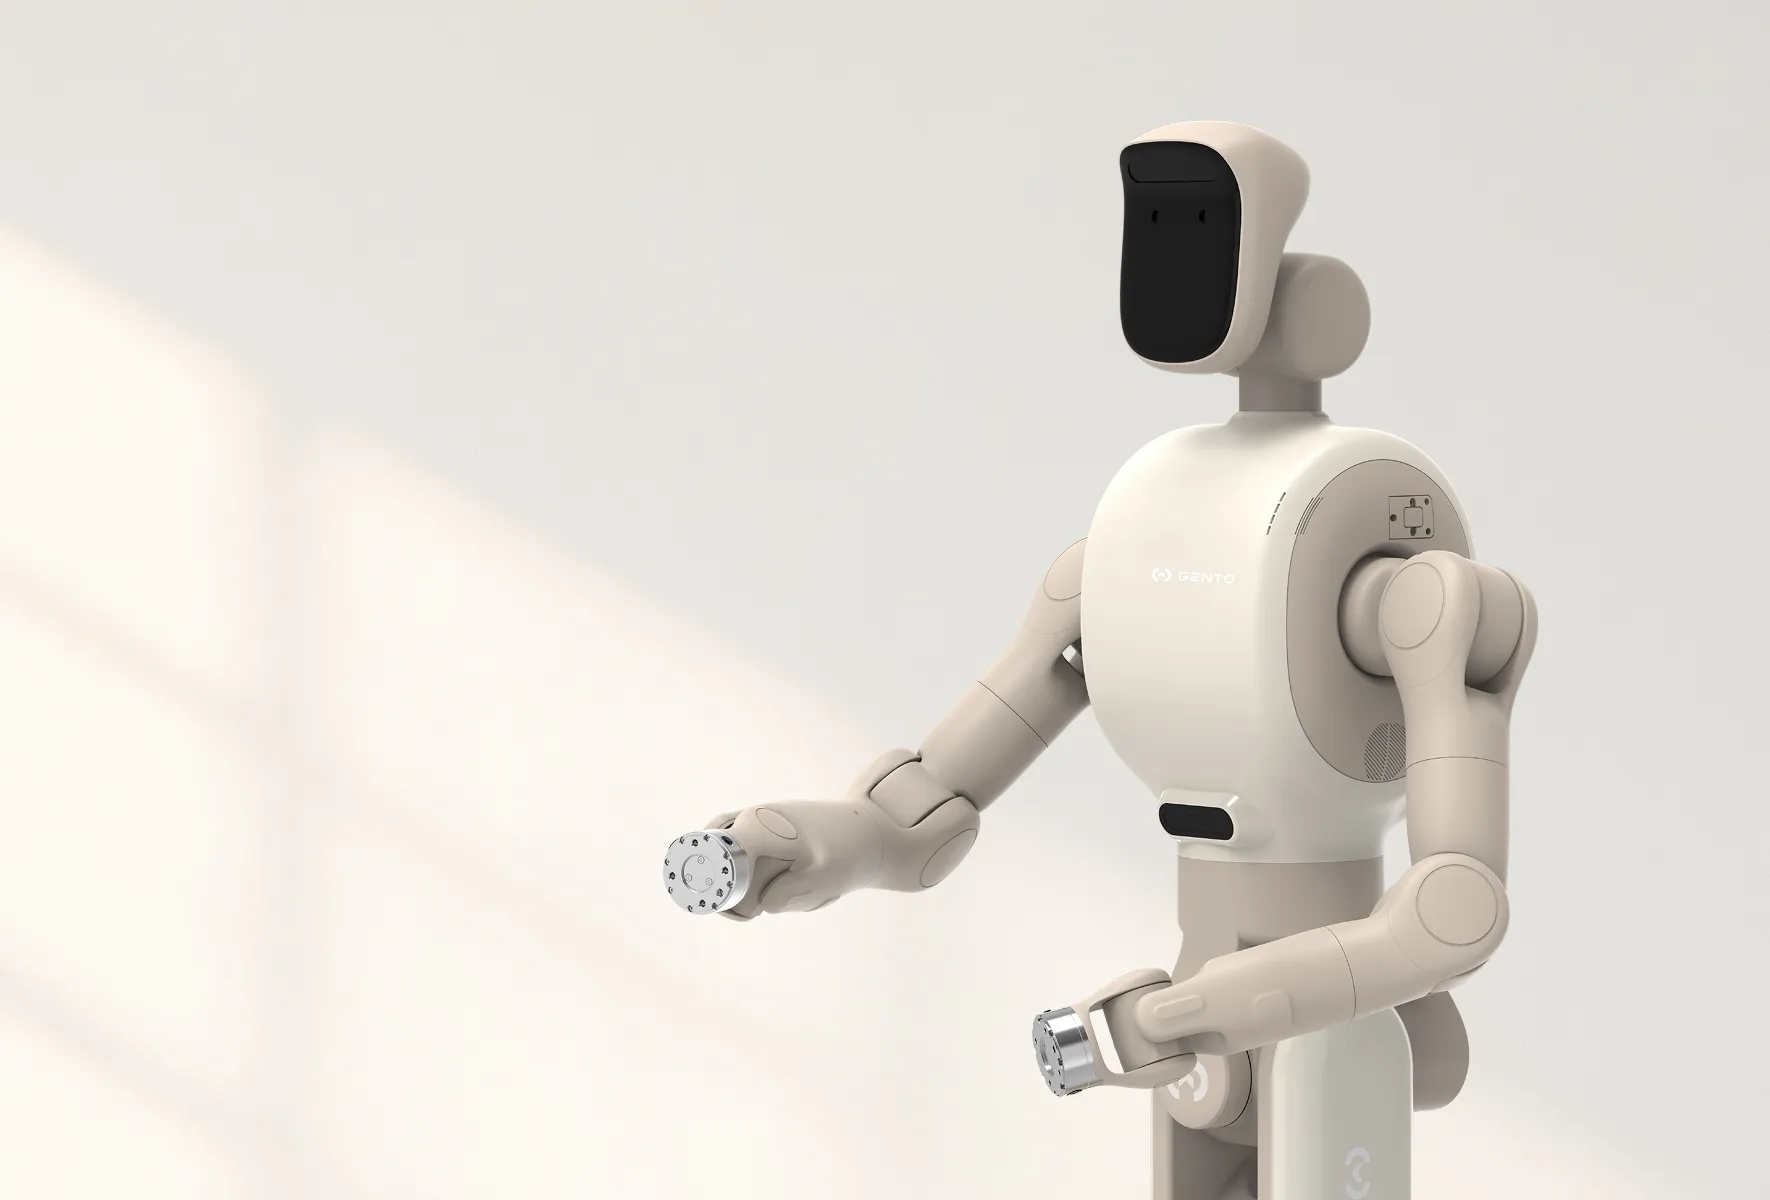 Wheeled Foldable Robot
Gento Luna
A wheeled foldable robot integrating high mobility, strong operability and high computing power -
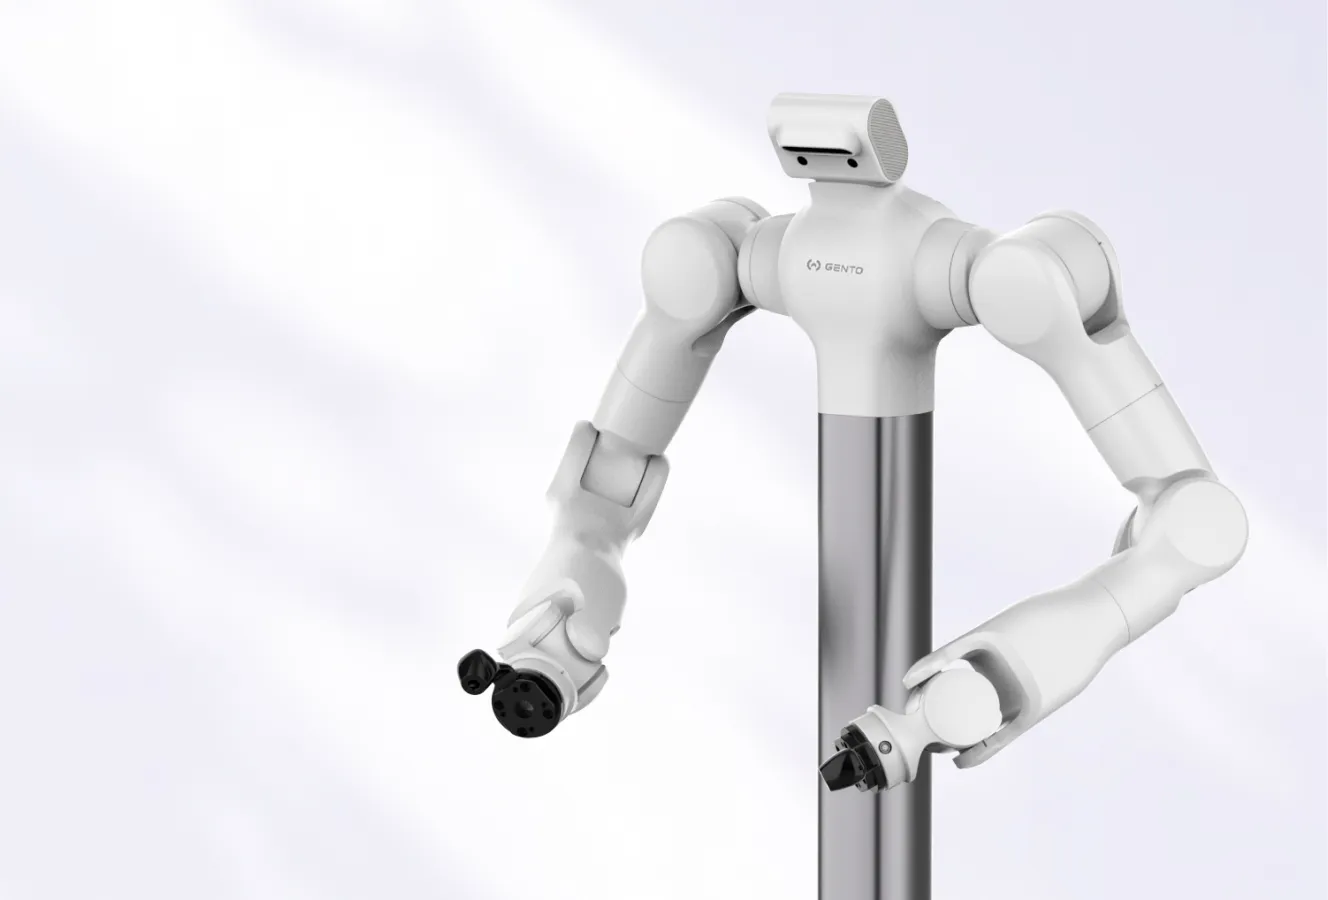
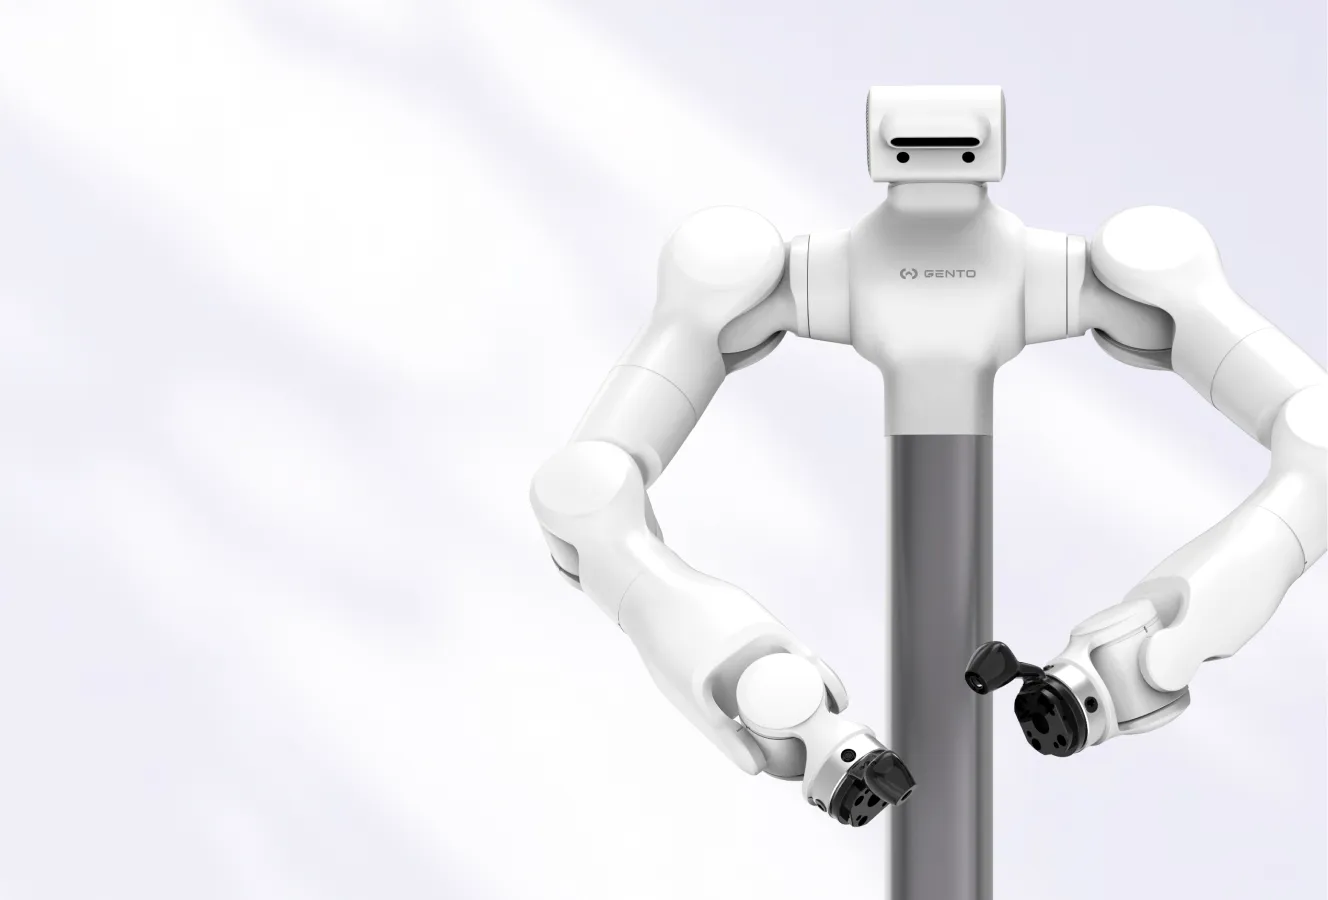 Fixed-Base Force-Controlled
Dual-Arm Humanoid PlatformMarvin Pro
A stationary dual-arm robot with 7-DoF fully force-controlled arms, 5-camera panoramic vision and high computing power for fixed-position precision work.