

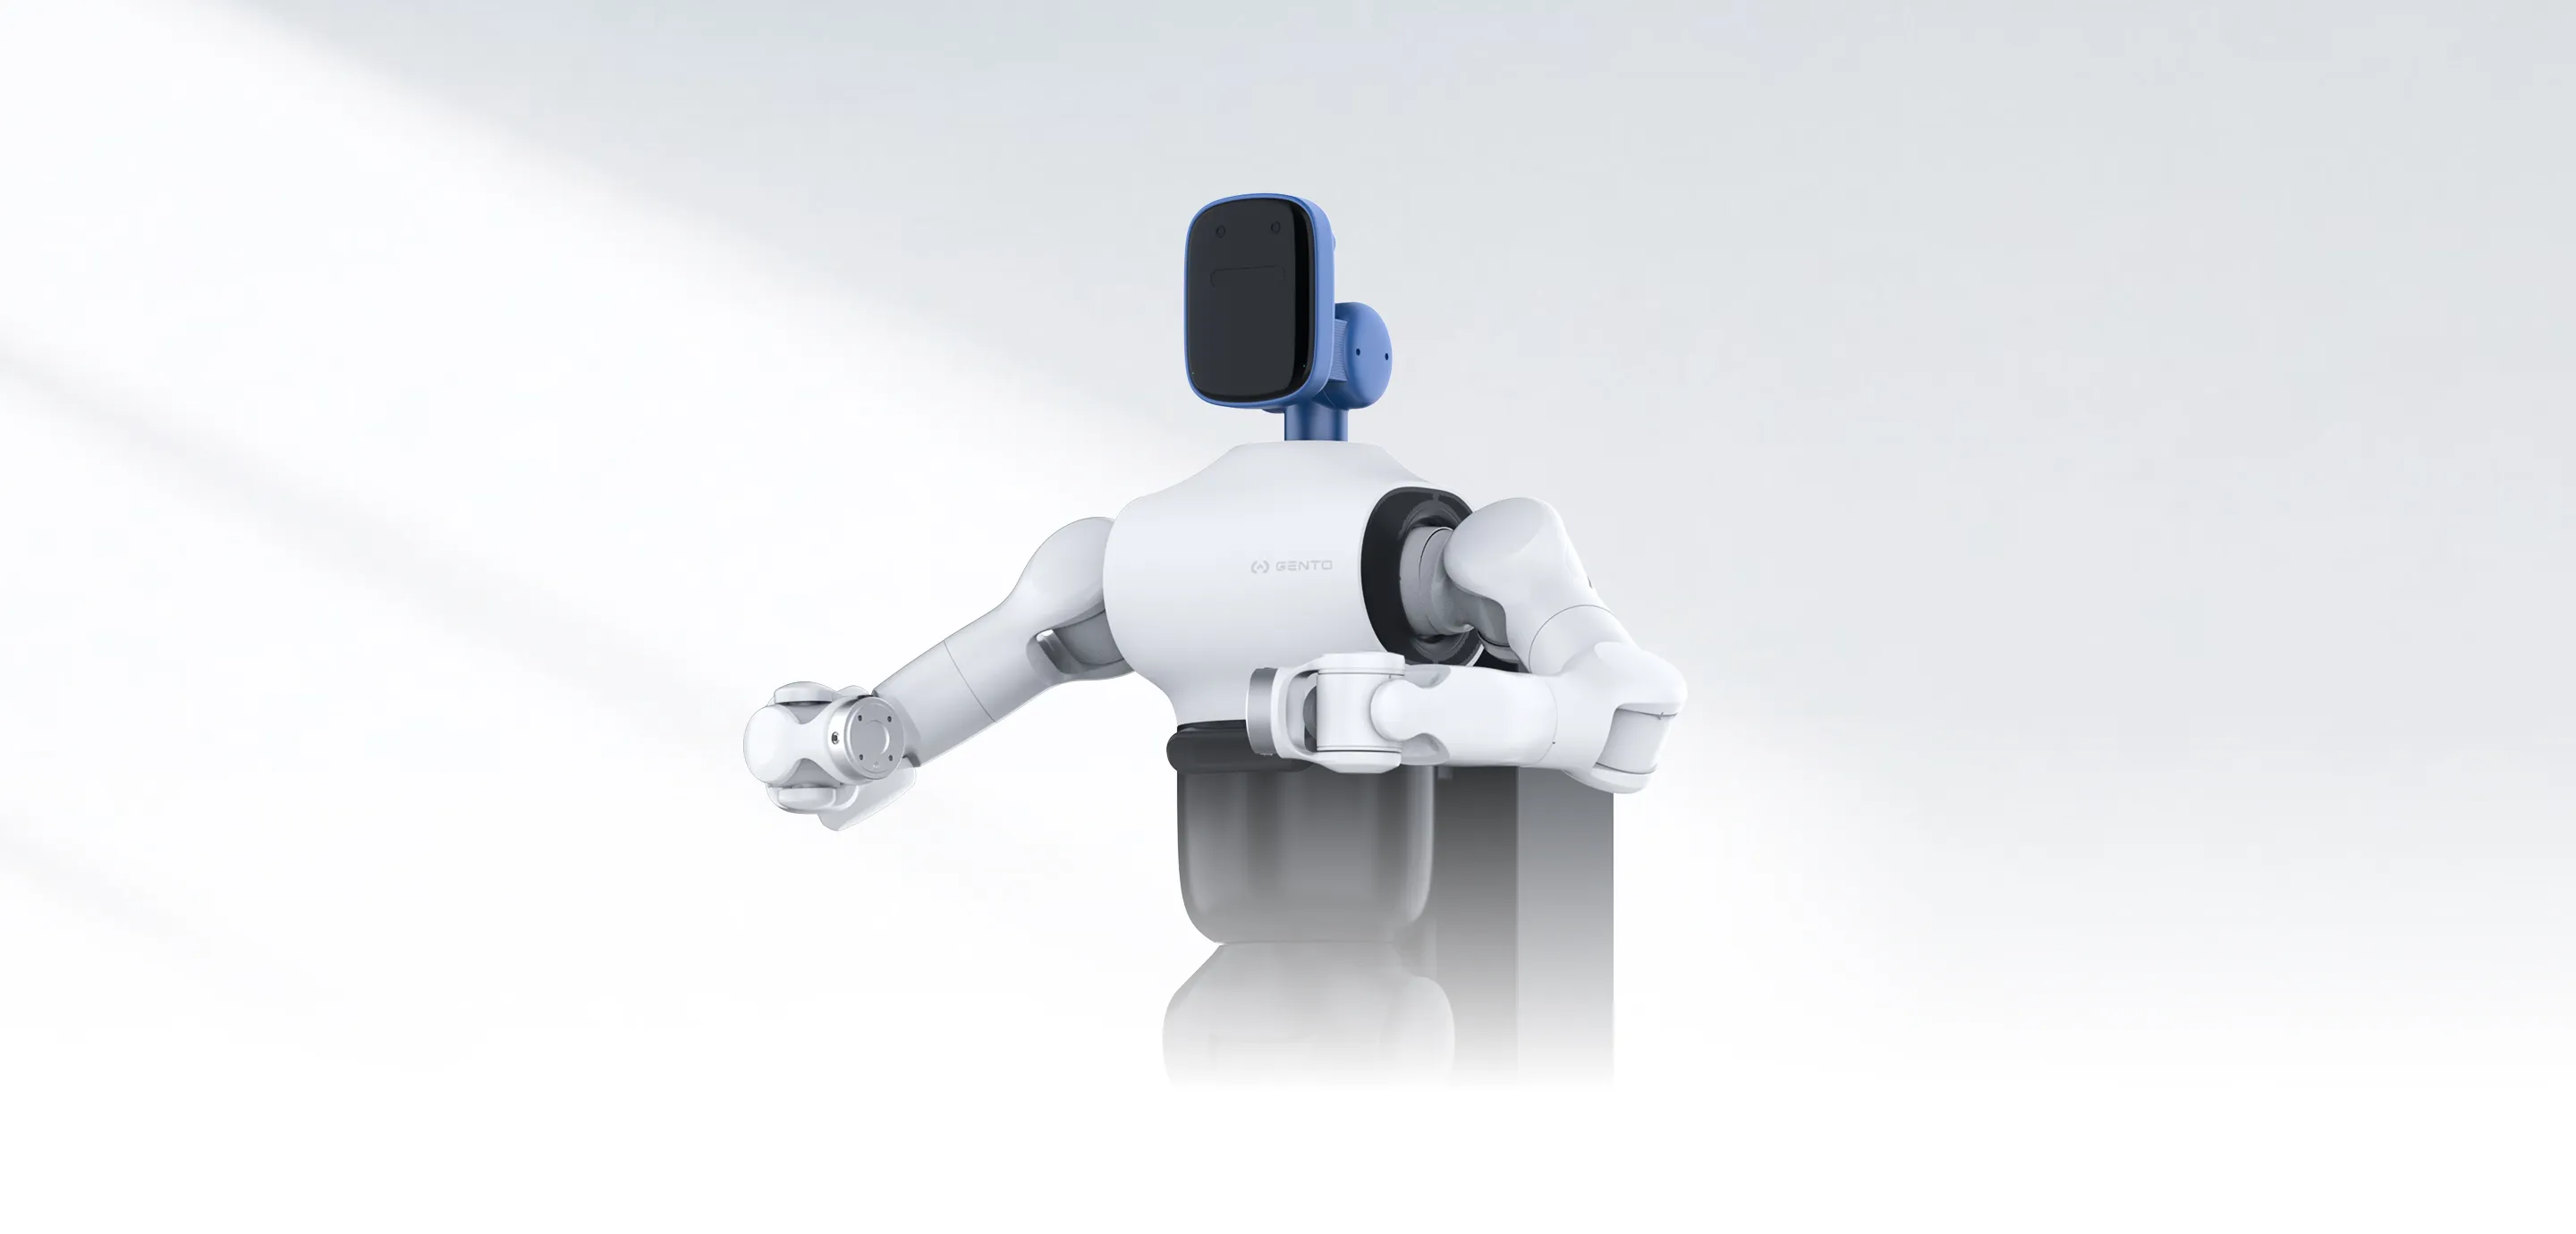
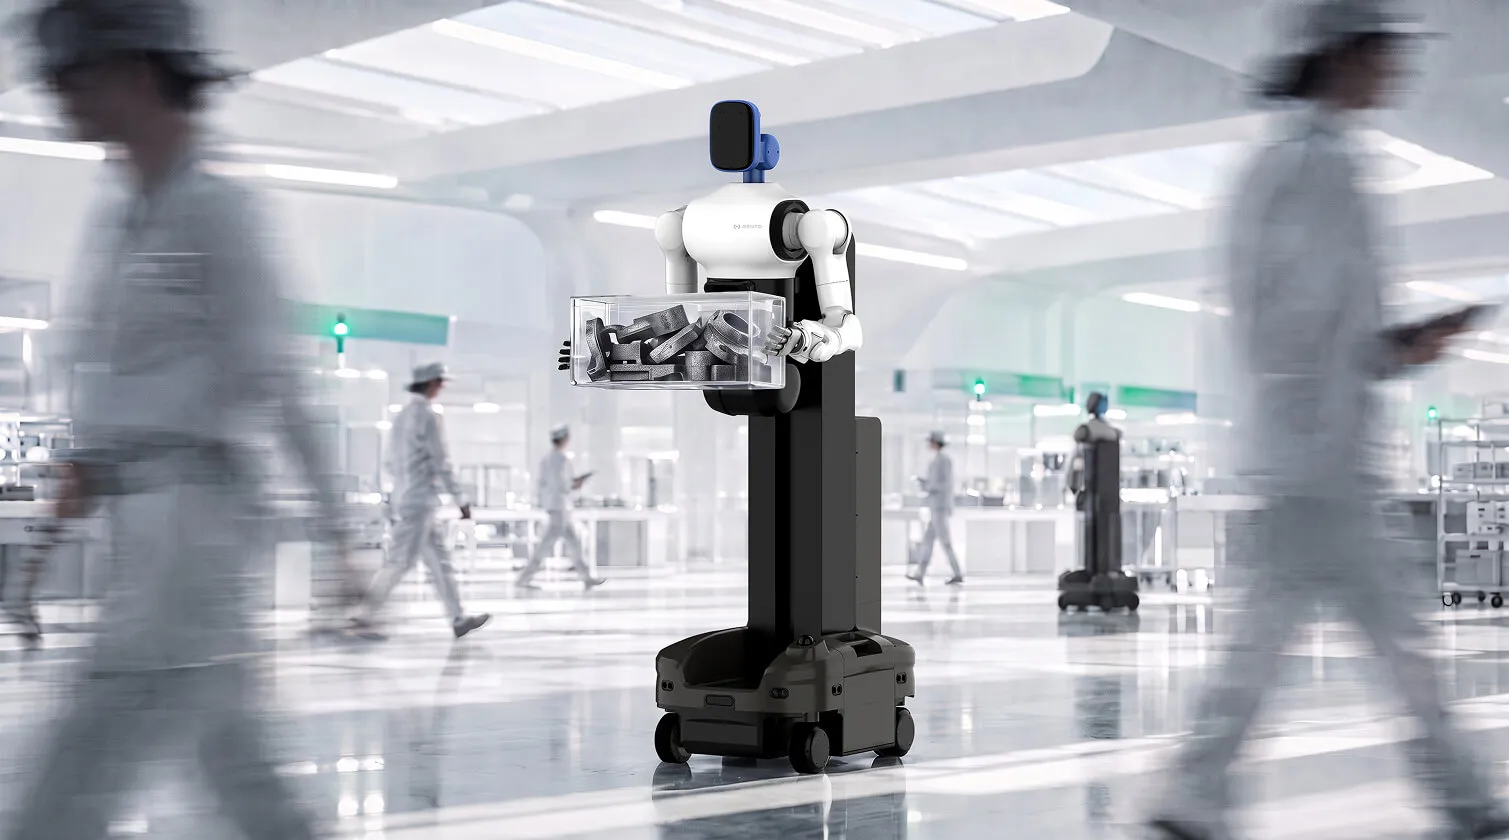
A humanoid robot development platform featuring whole-body force control and open control authority, targeting embodied intelligence, reinforcement learning, and real-world validation, providing a stable, controllable, and scalable physical carrier.
-
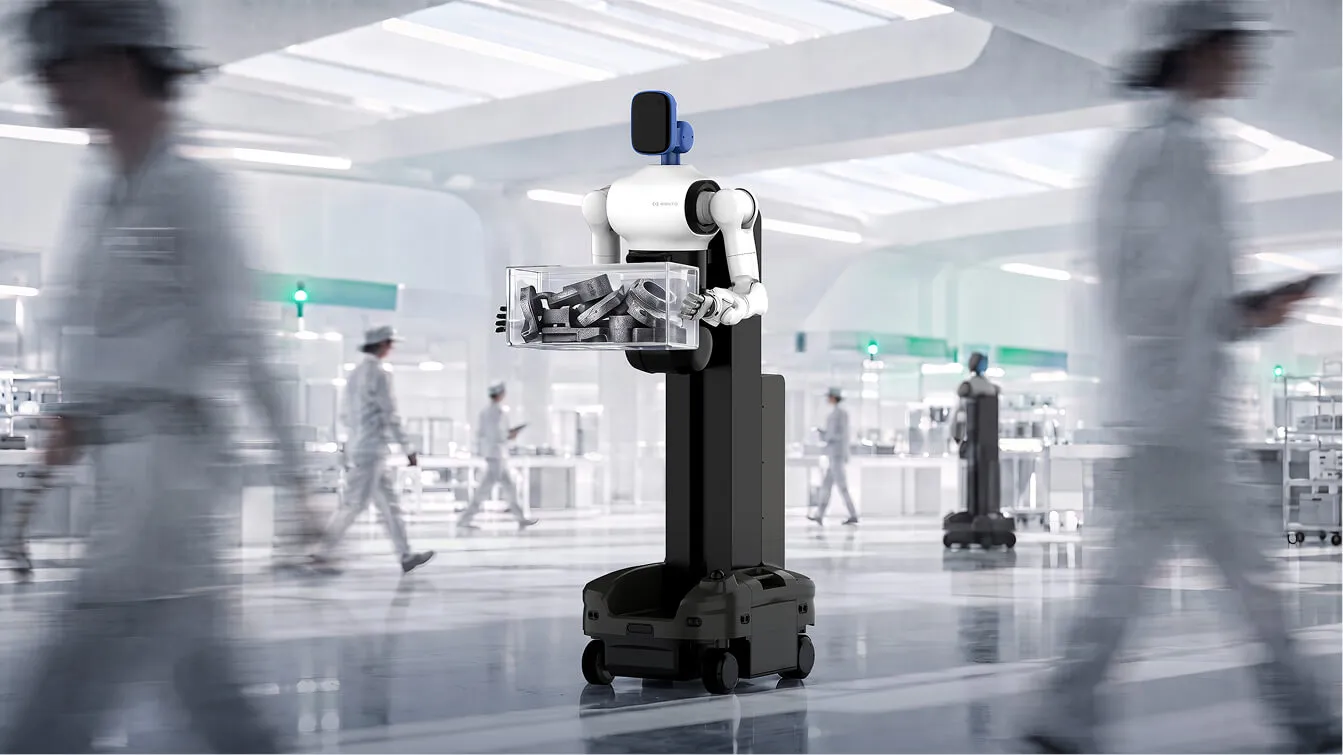 Whole-Body Force Control · Safe and Controllable
-
 Open Control Authority · Algorithm-Friendly
-
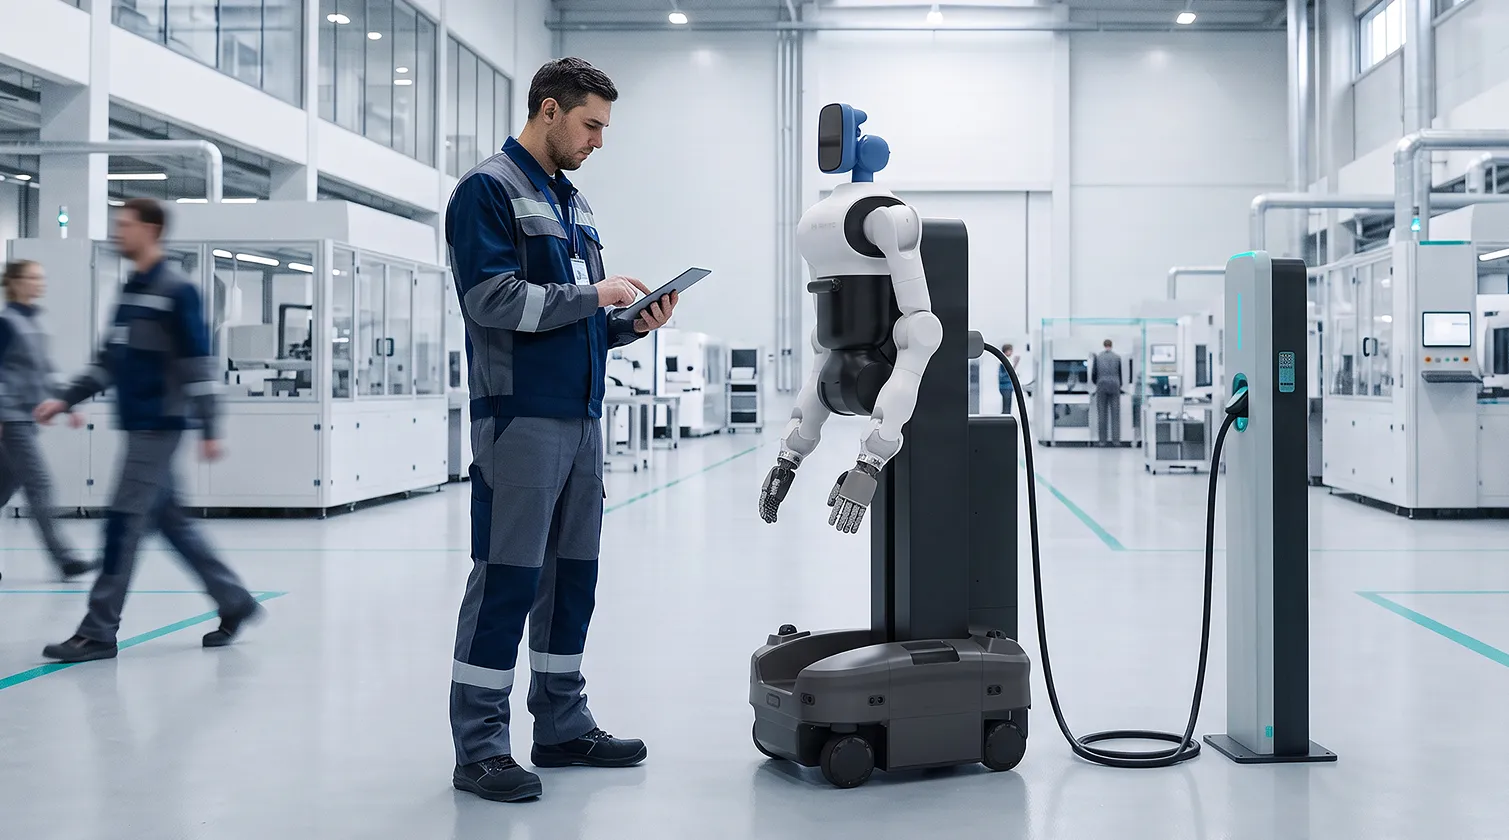
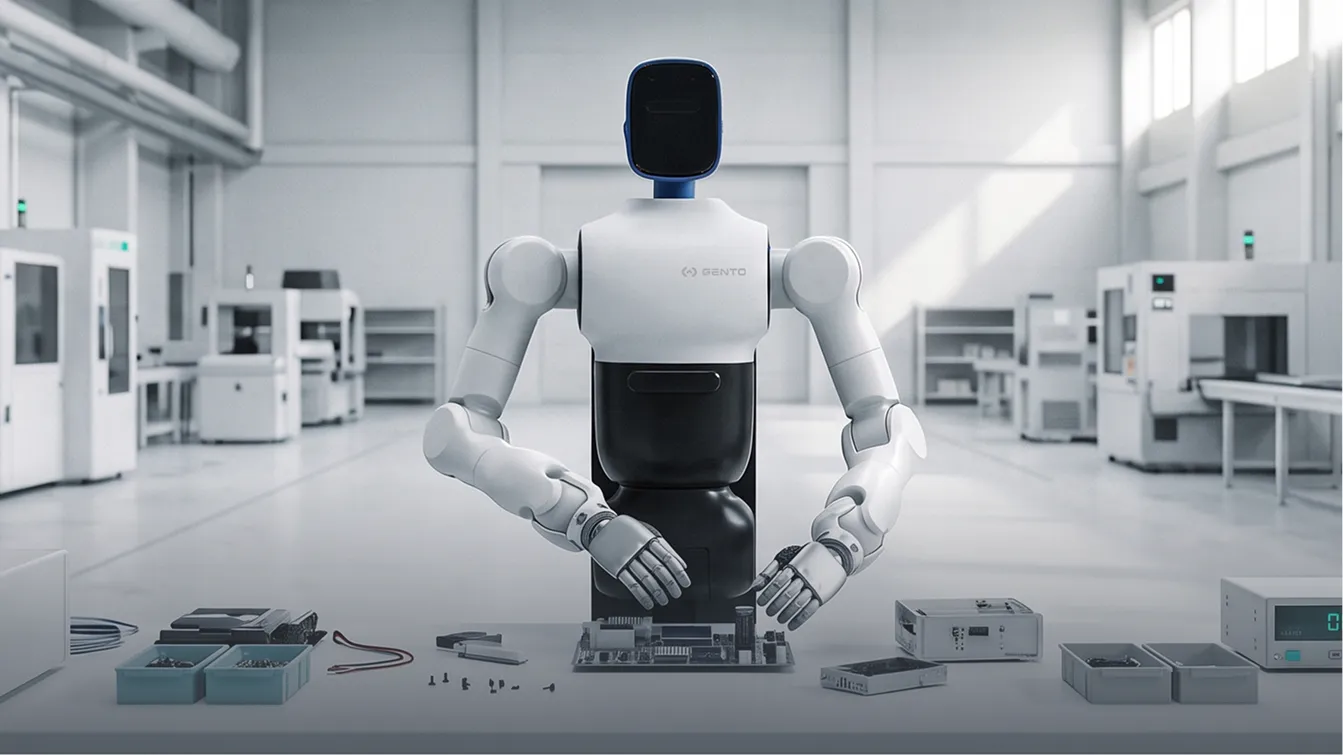 Industrial-Grade Reliability · 7×24 Stability
-
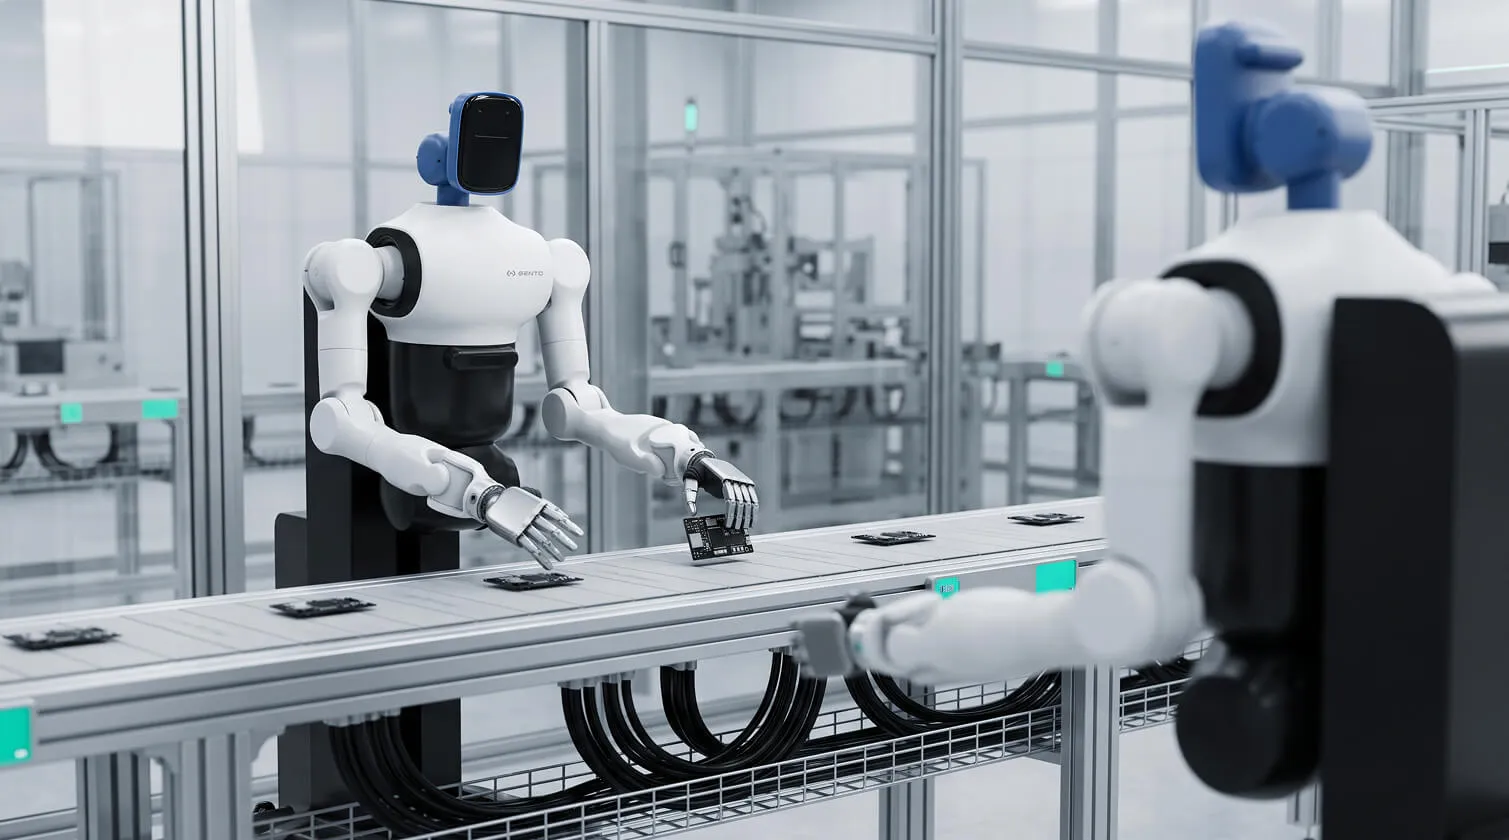
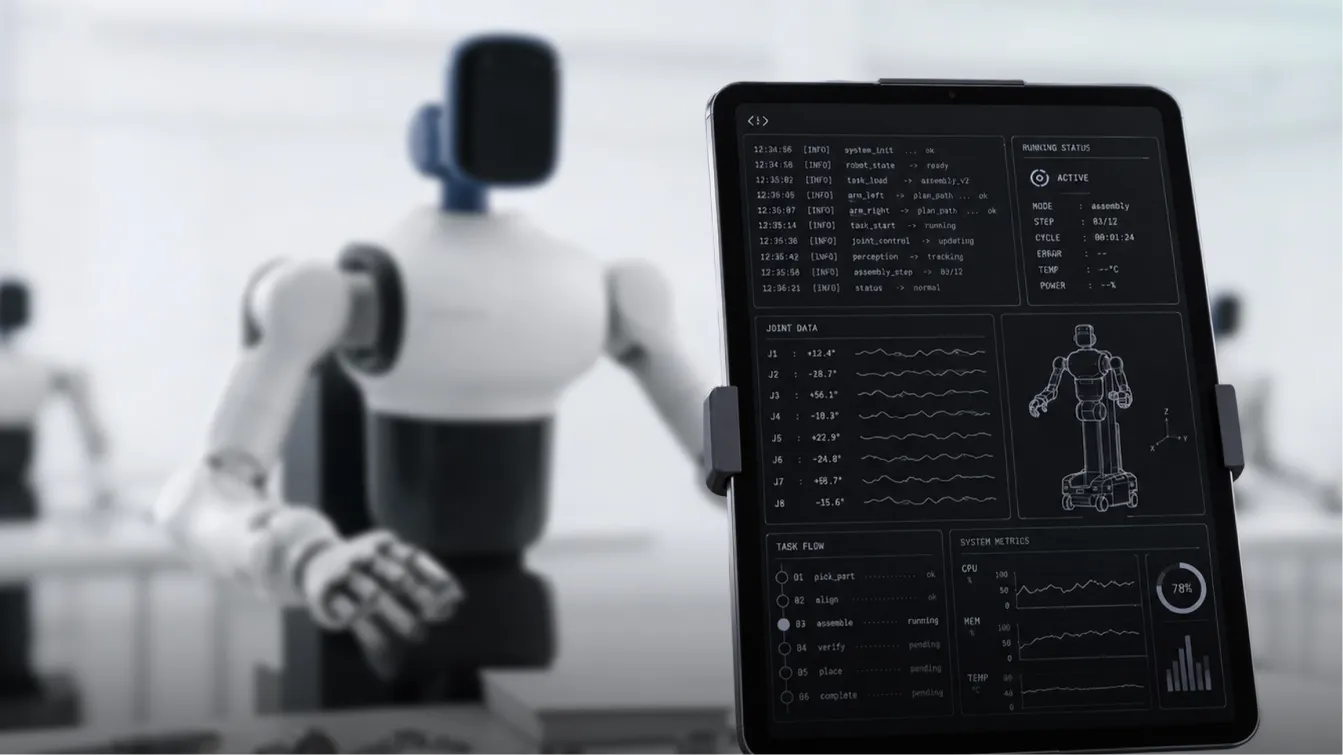 Data Collection · Real-World Assets
Our Advantages
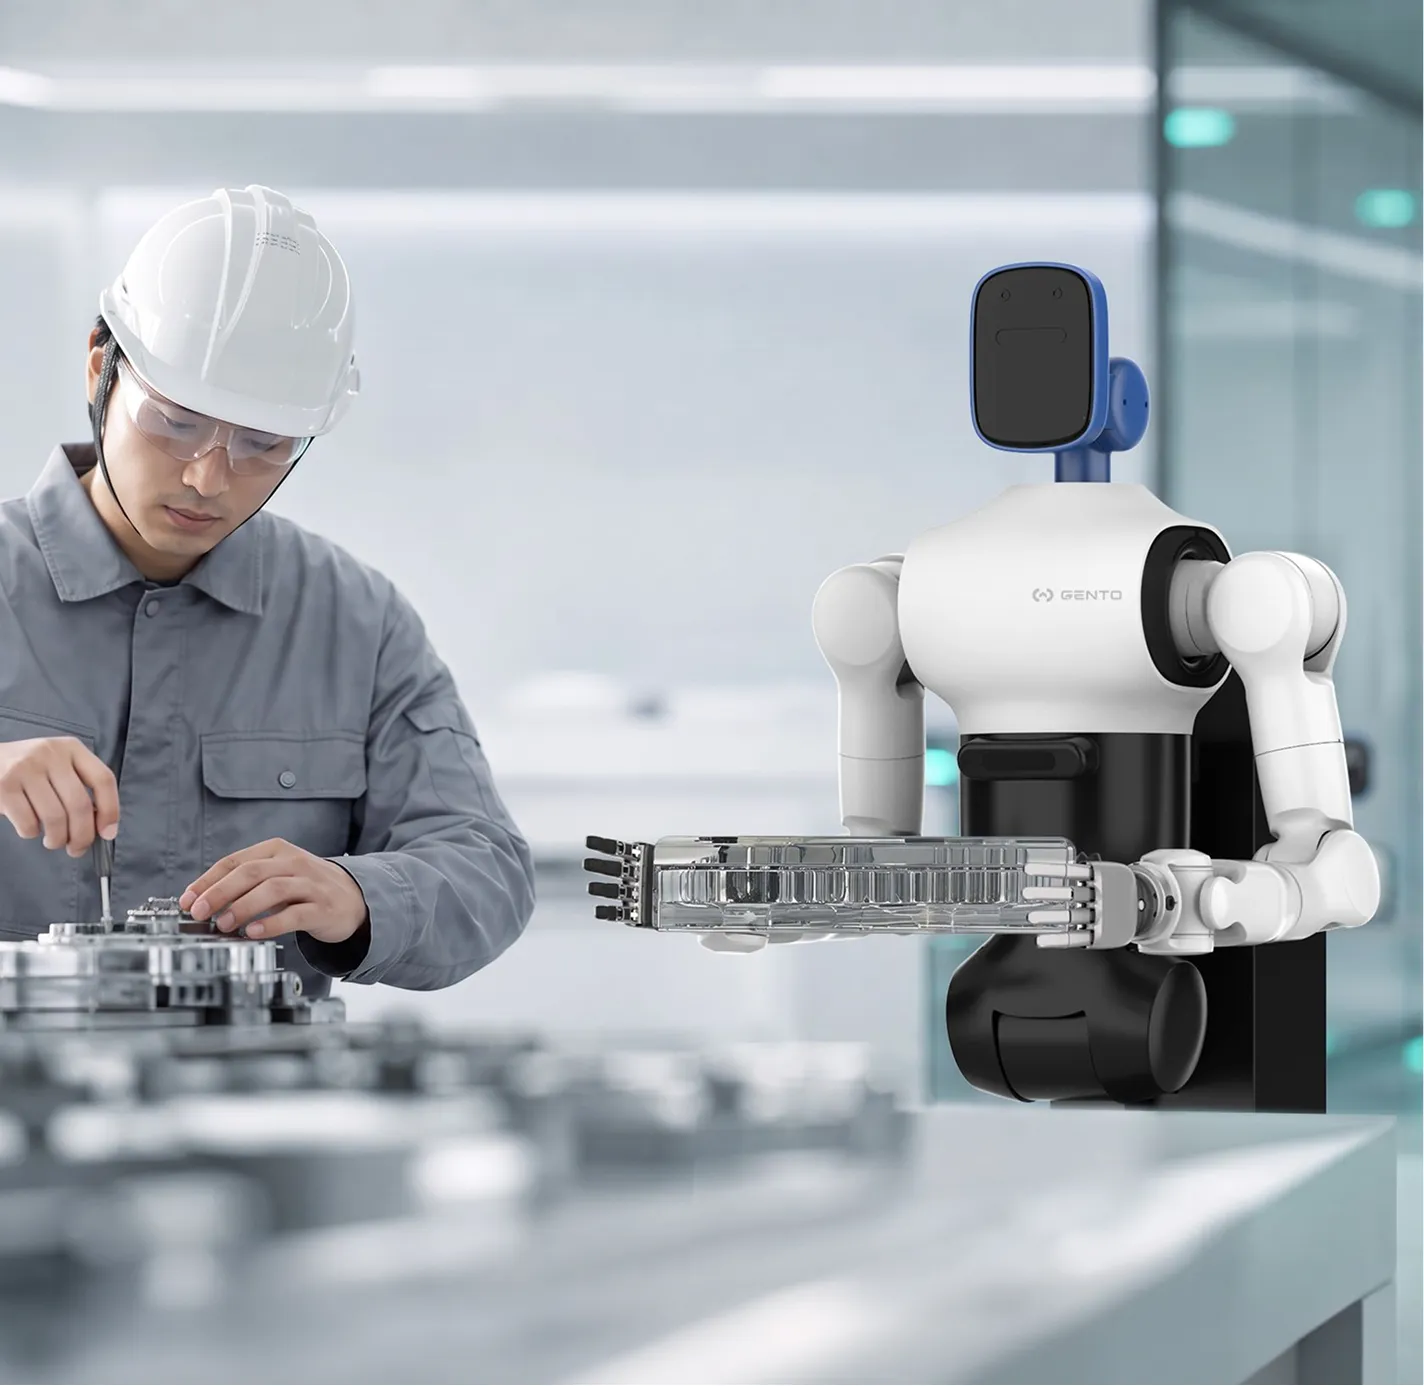
Controllable Compliance, Not "Rigid‑to‑Rigid"
Platform Safety (Device Level)
Active compliant response upon external collision or abnormal force to prevent platform damage.
Personnel Safety (HRI & Collaboration Level)
Automatic force relief during human‑robot contact or accidental collision to reduce impact risks.
Environmental Safety (Scenario Level)
Flexible response when contacting surroundings, avoiding rigid damage to equipment and the surrounding environment.
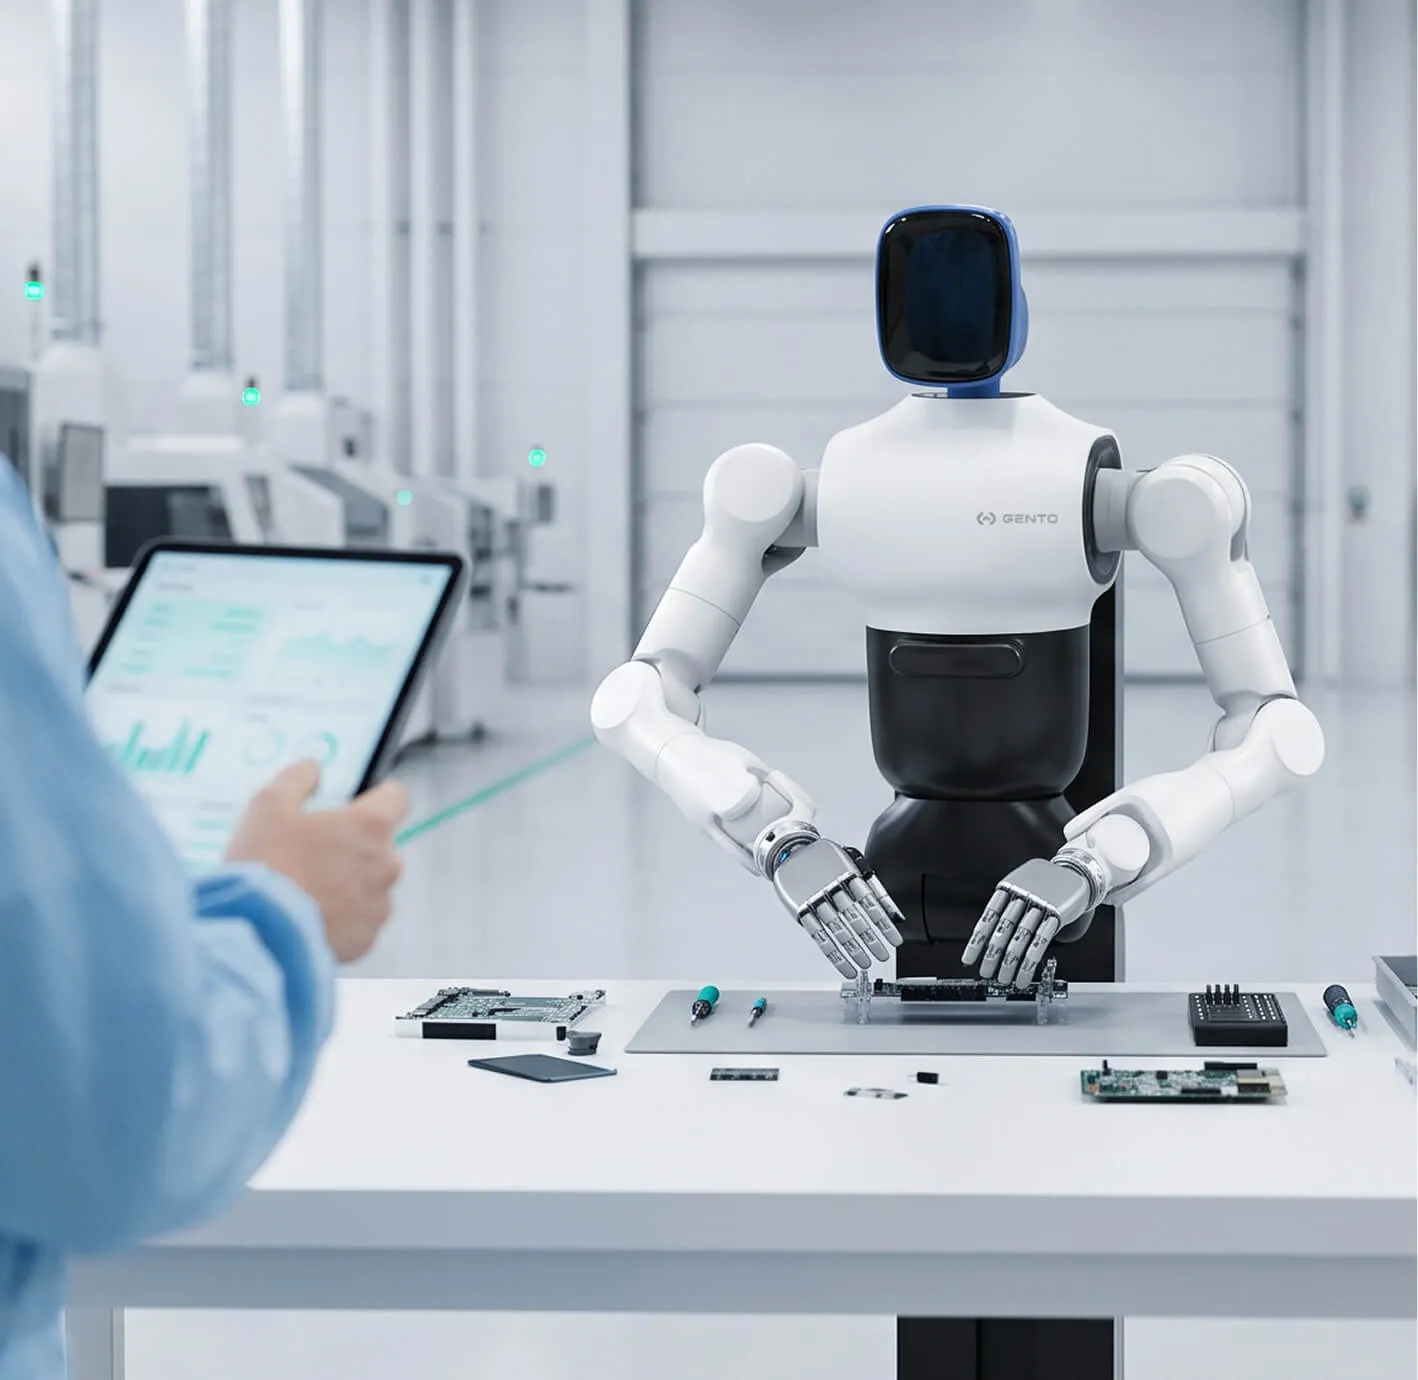
Motion Control Stack Ready, Focus on Algorithm Innovation
Platform-level control and motion planning capabilities are fully implemented,Users can bypass complex low-level control and directly focus on model and algorithm development
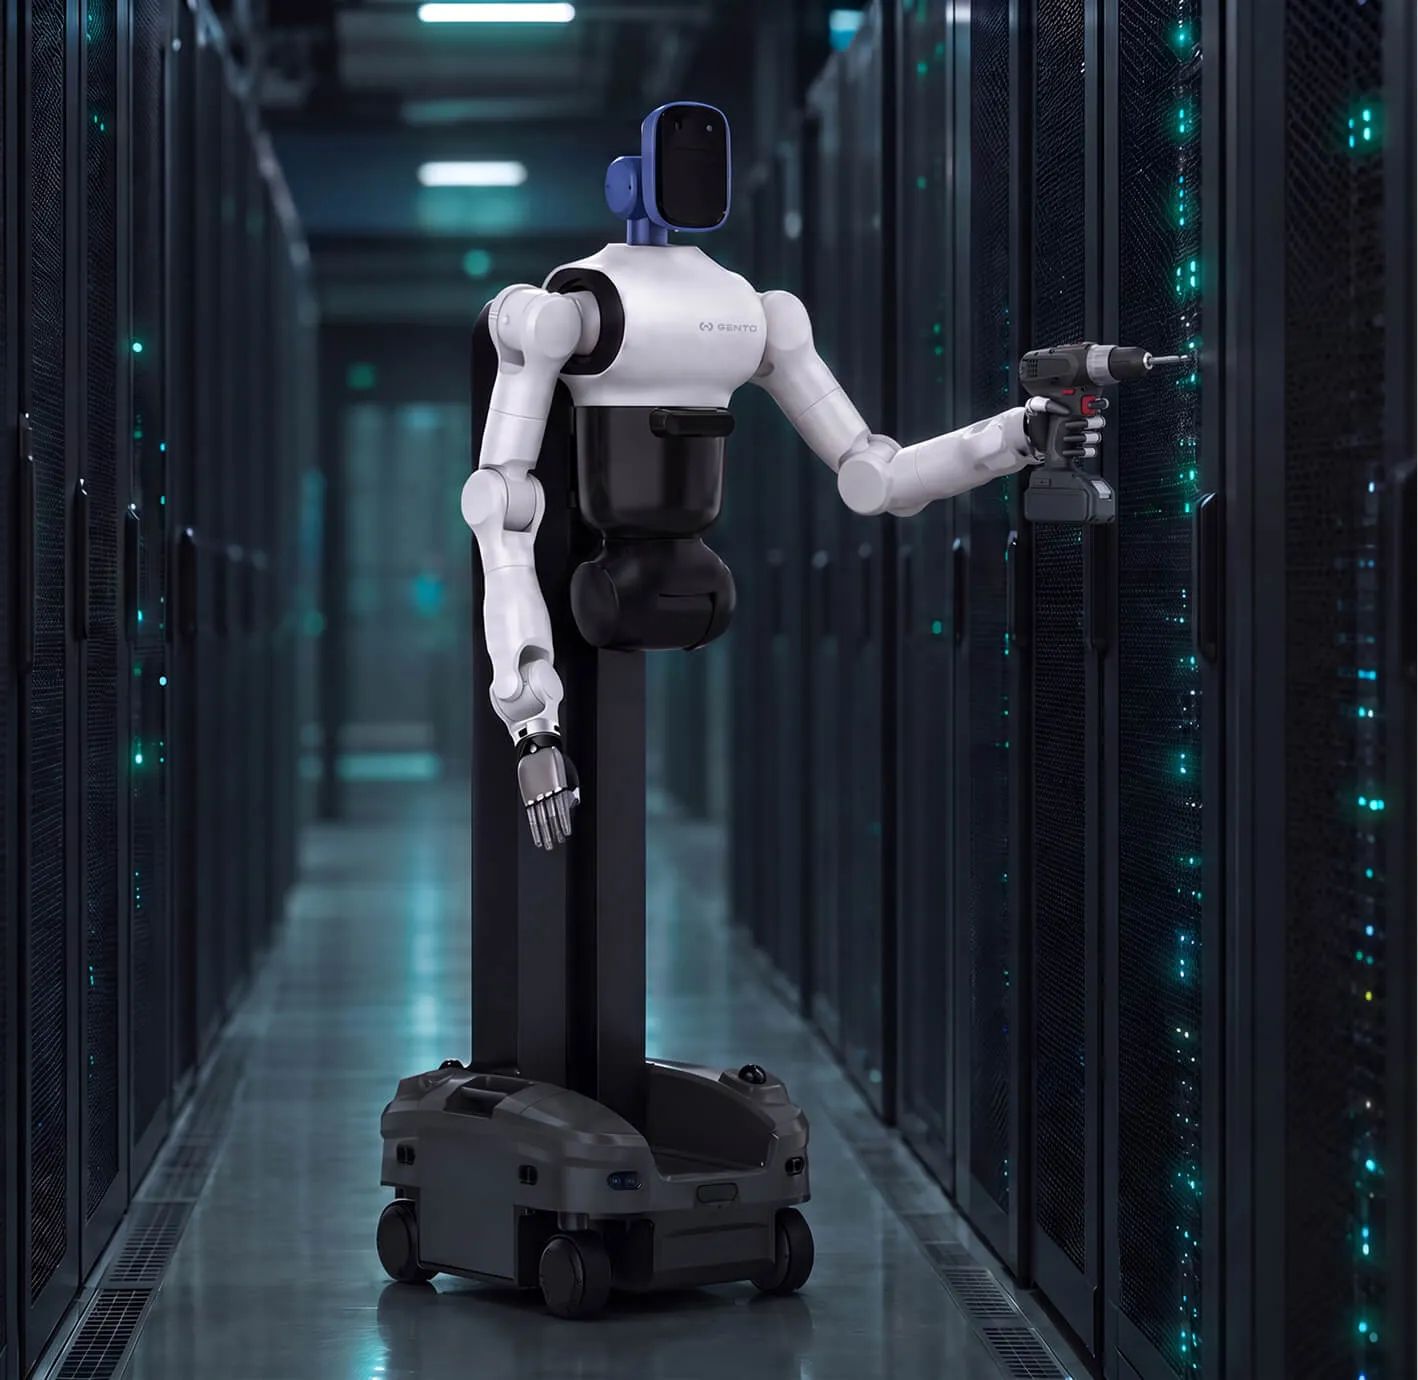
Industrial‑Grade Reliability
System‑level design for 7×24‑hour continuous‑operation scenarios ;
Low hardware heat generation, long‑term stability of critical components ;
Low sensor thermal drift, ensuring consistency and repeatability for long‑term training and data acquisition
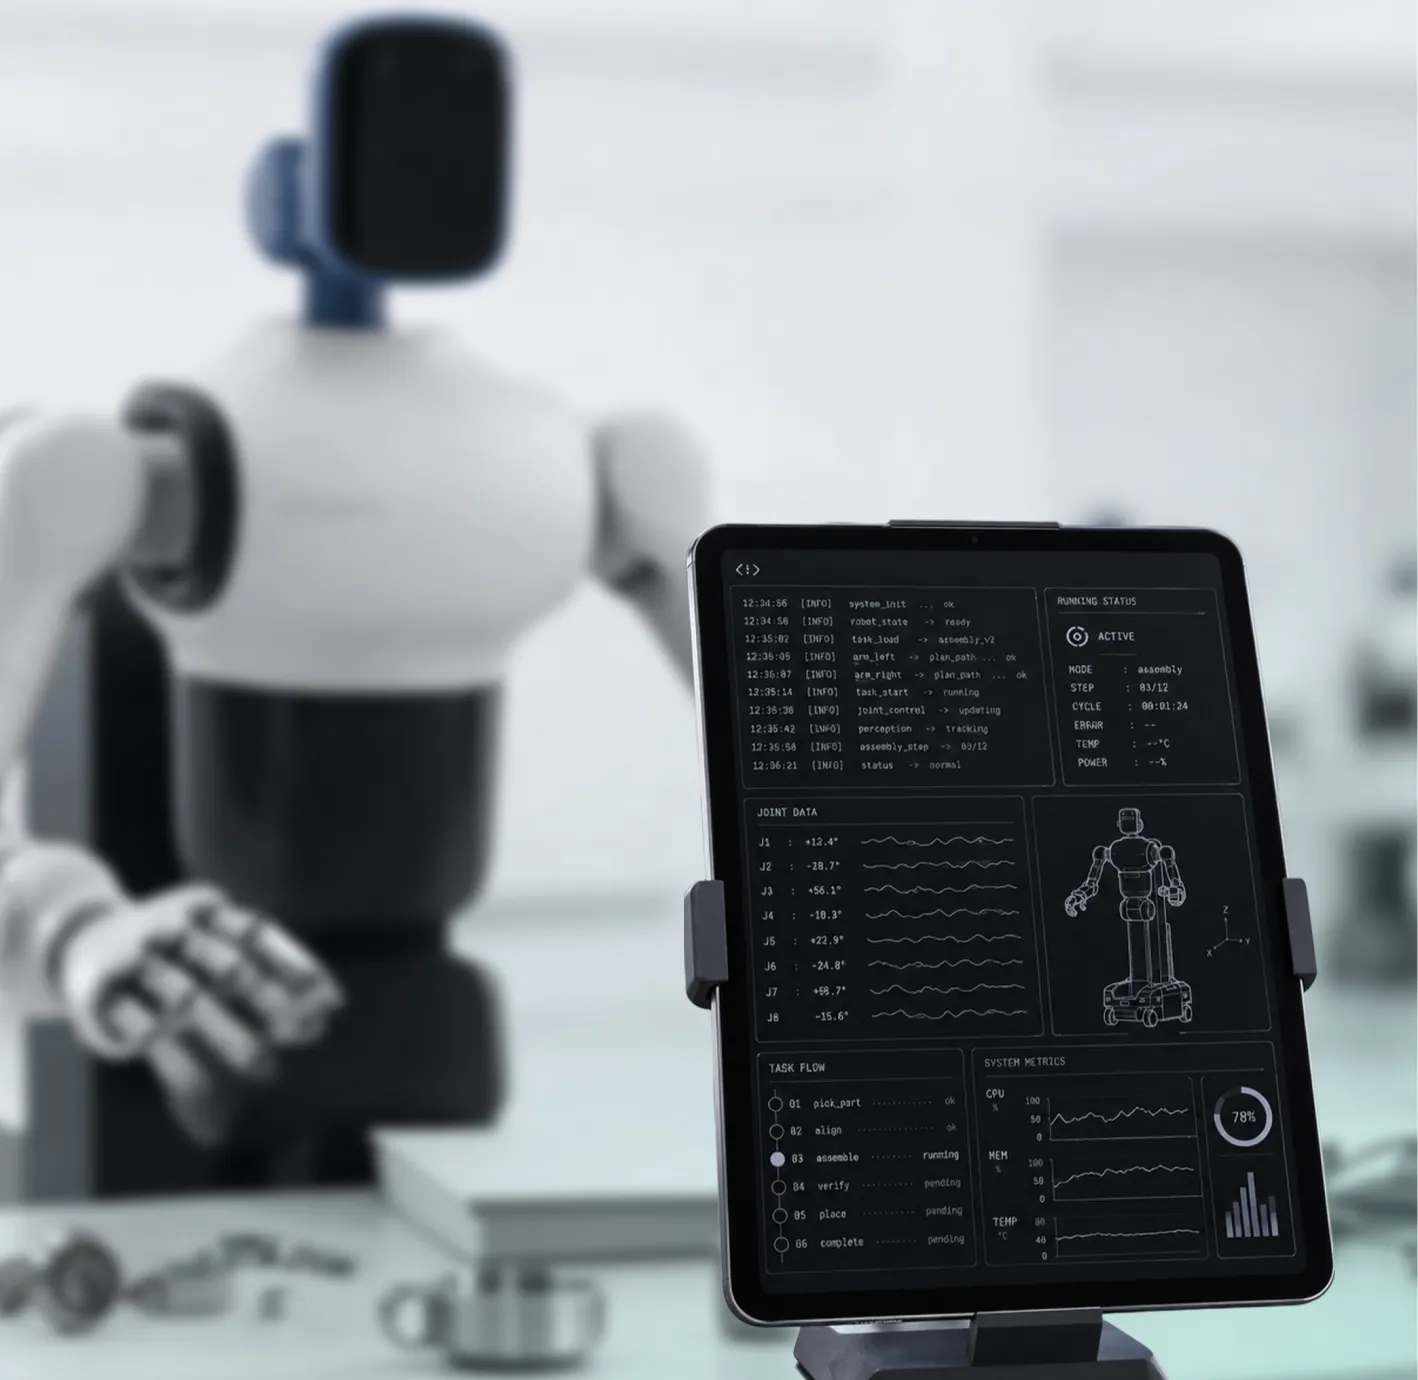
Complete Data Acquisition and Management
Rich on-body data
multi-dimensional force information including position, velocity, torque, joint shaft force, end-effector force, etc.
Synchronized environmental data
supports multiple peripherals such as cameras and tactile sensors, enabling synchronized multi-angle, multimodal environmental data acquisition
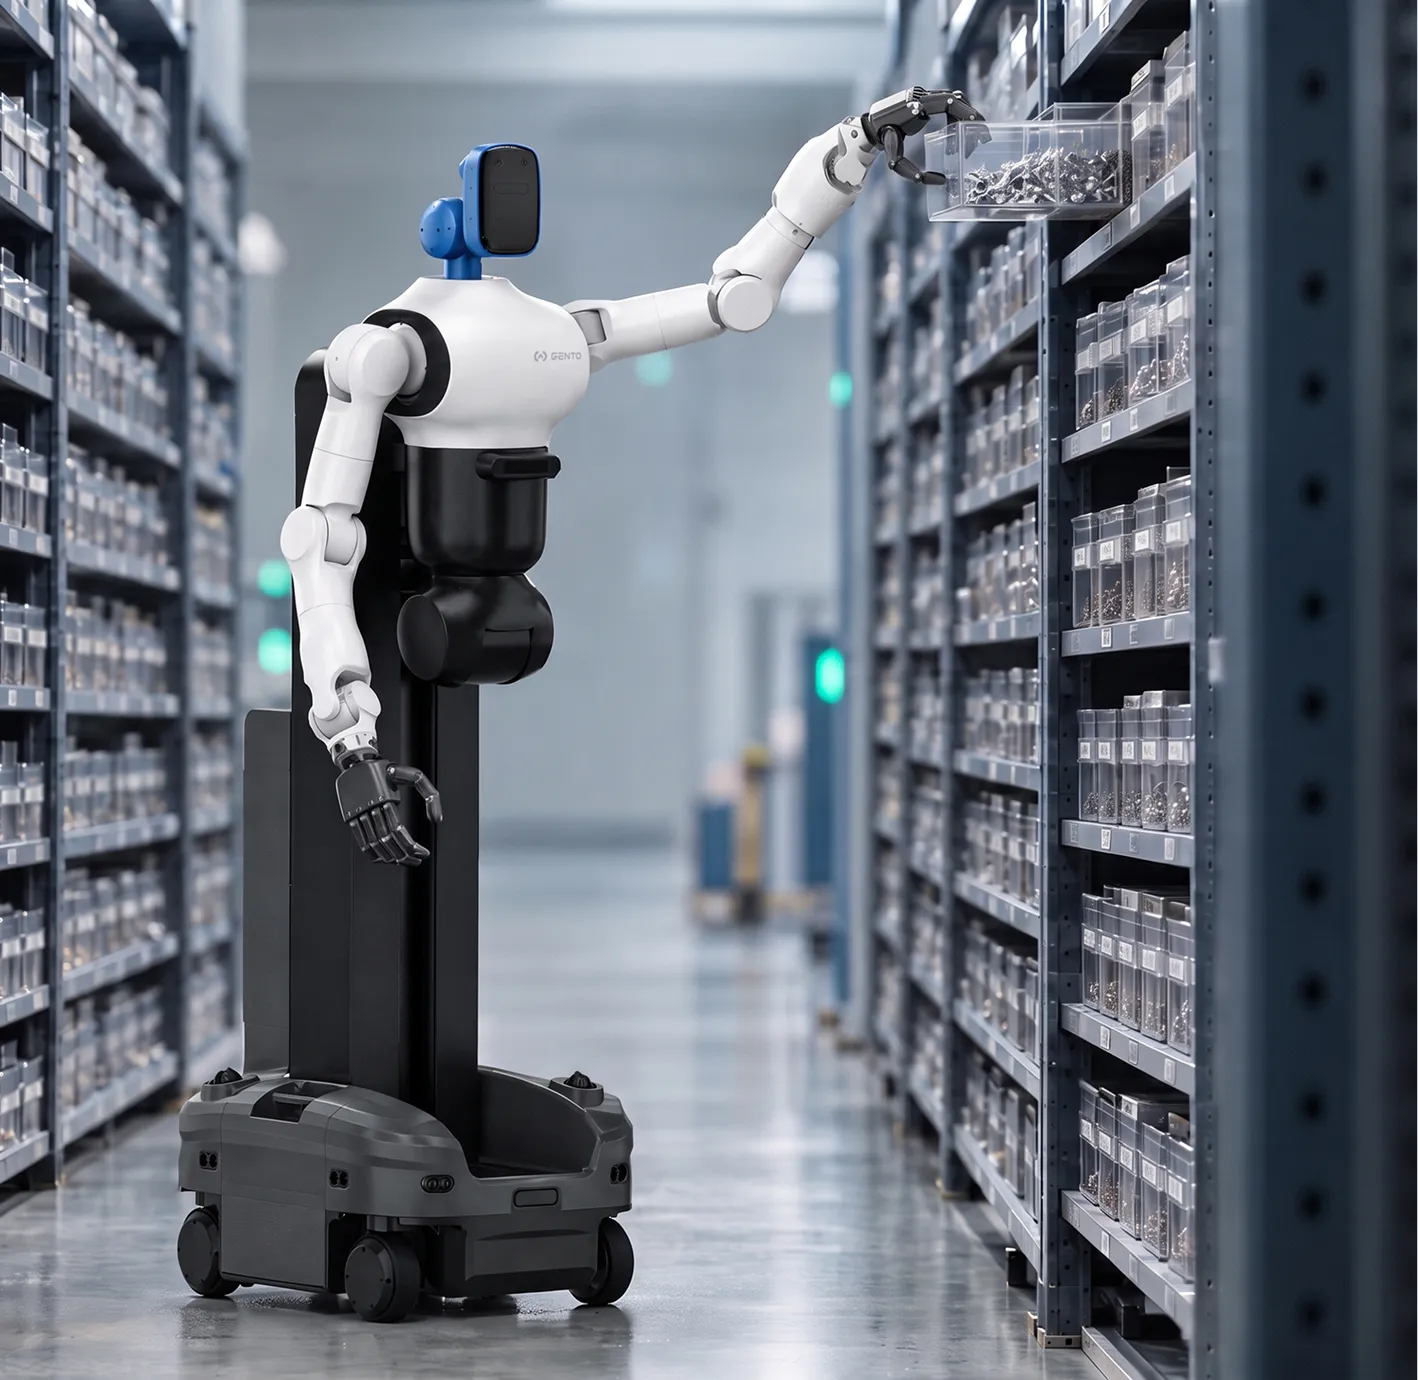
Hardware Structural Advantages
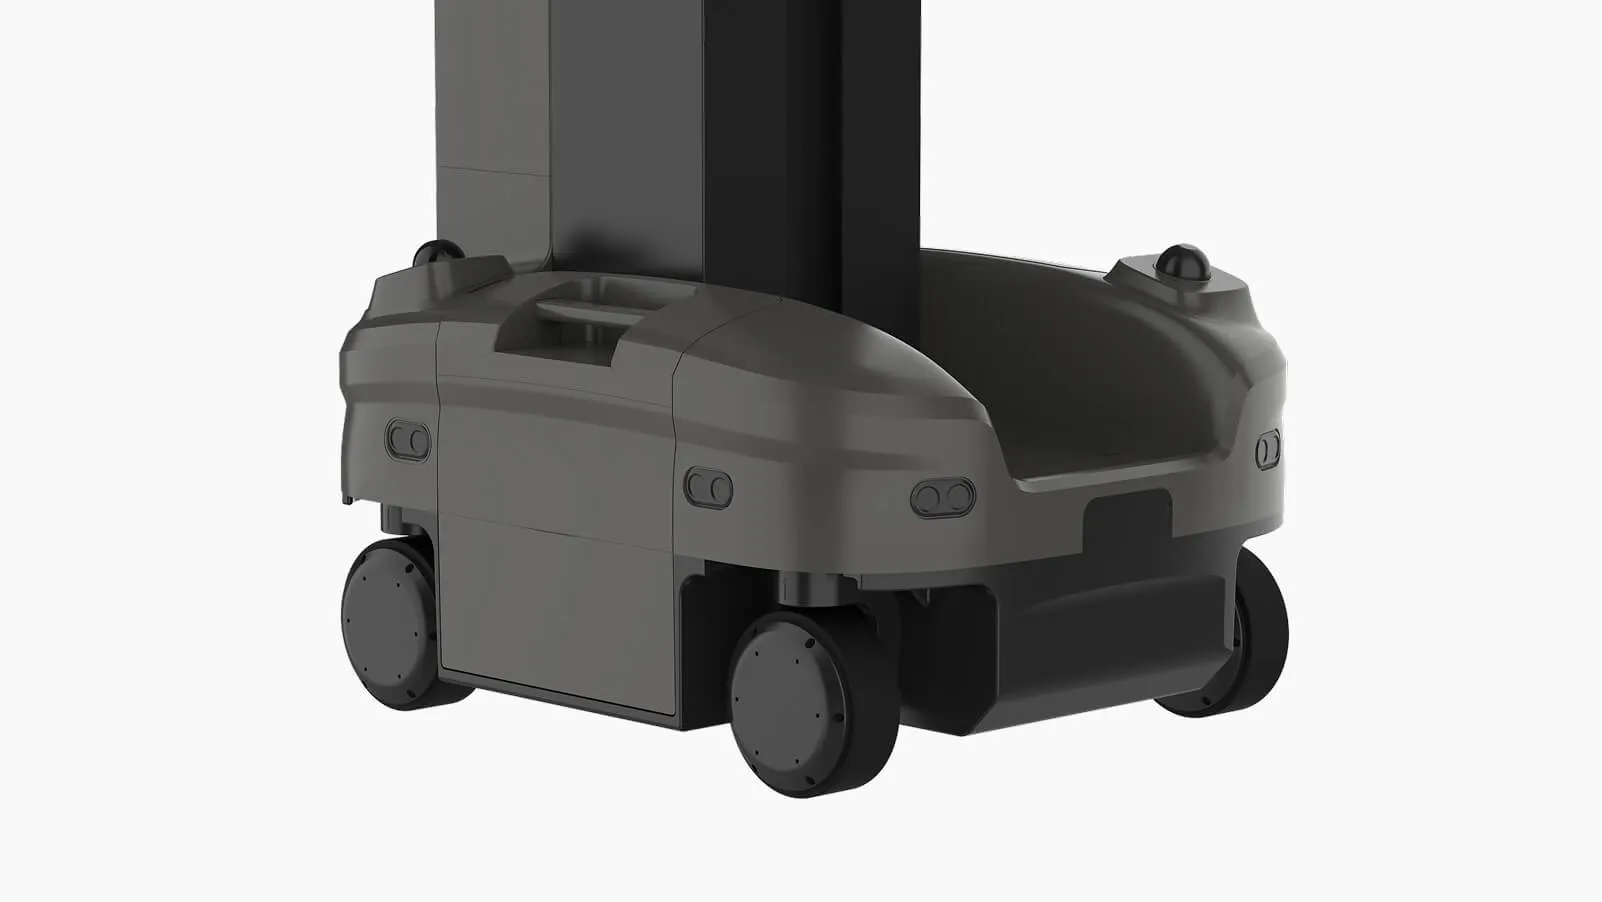
Wheeled chassis
balances mobility efficiency and overall stability; low center-of-gravity design enhances anti-tipping capability and dynamic stability
Lifting mechanism
continuous height adjustment to meet the adaptation needs of multi-scenario tasks for spatial height and working postures
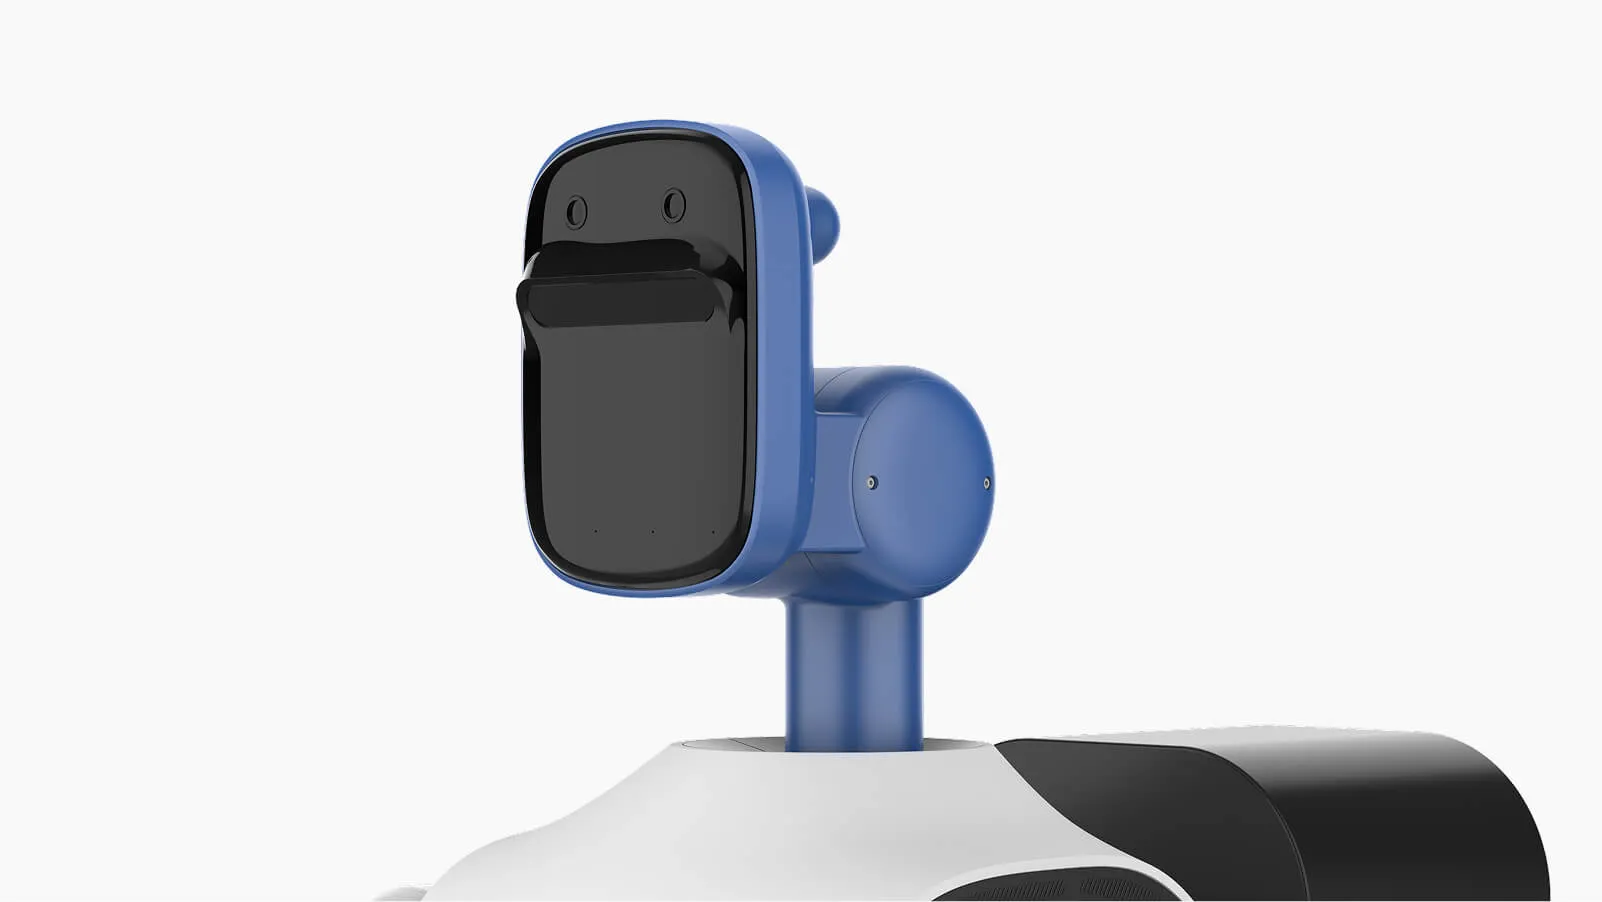
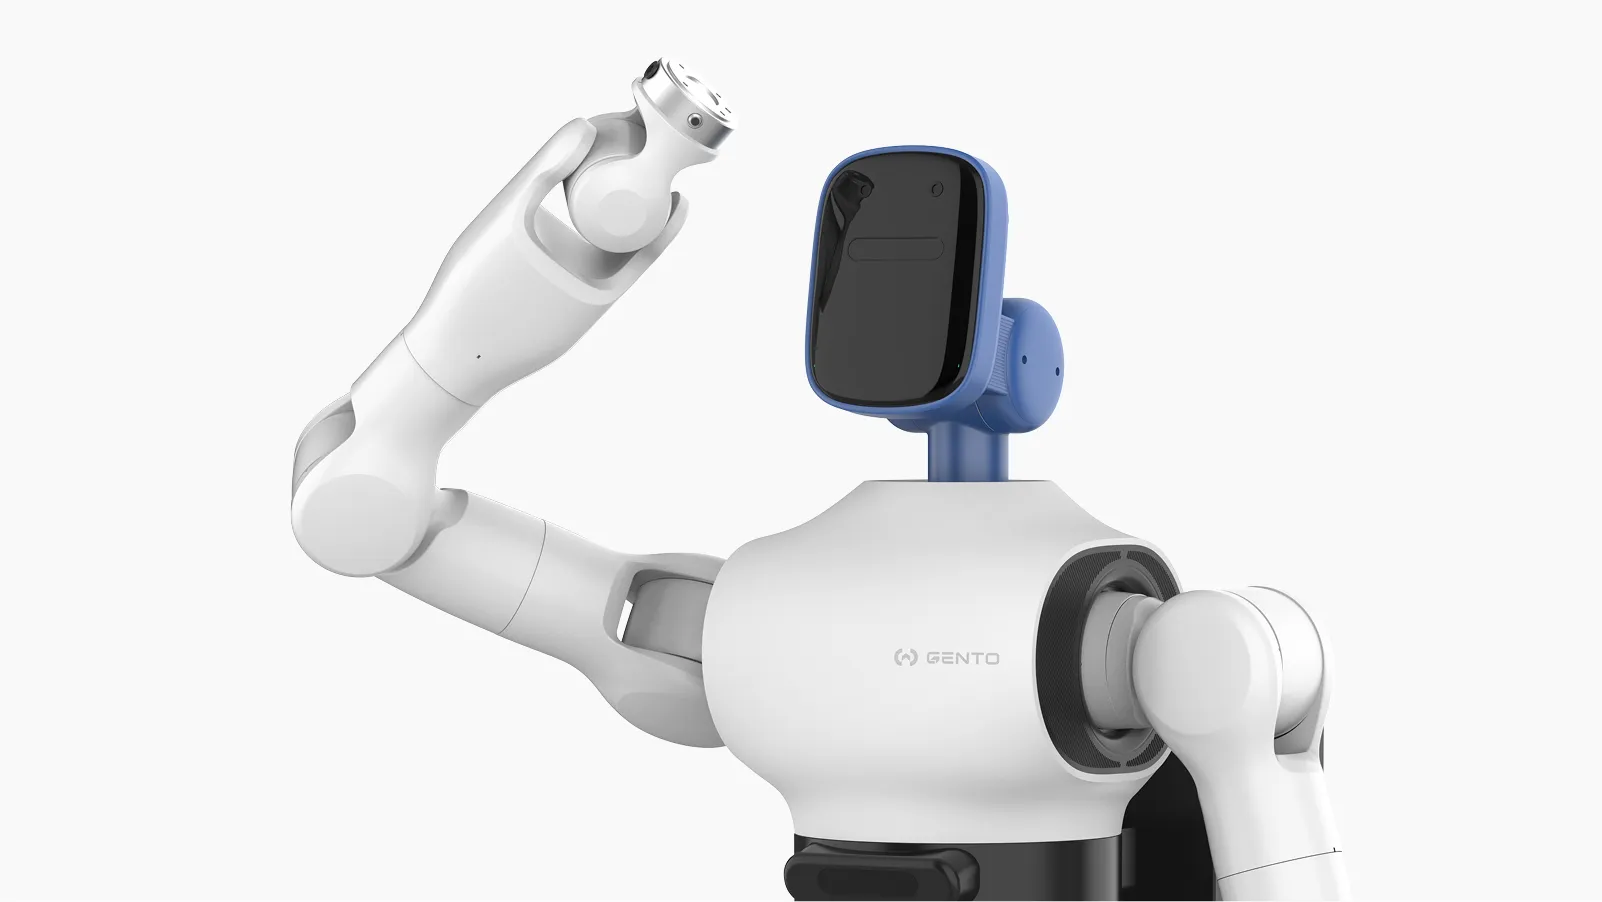
Affective interaction
distinctive expressive LED light-language system paired with visual recognition gives the robot a more approachable, human-centric presence
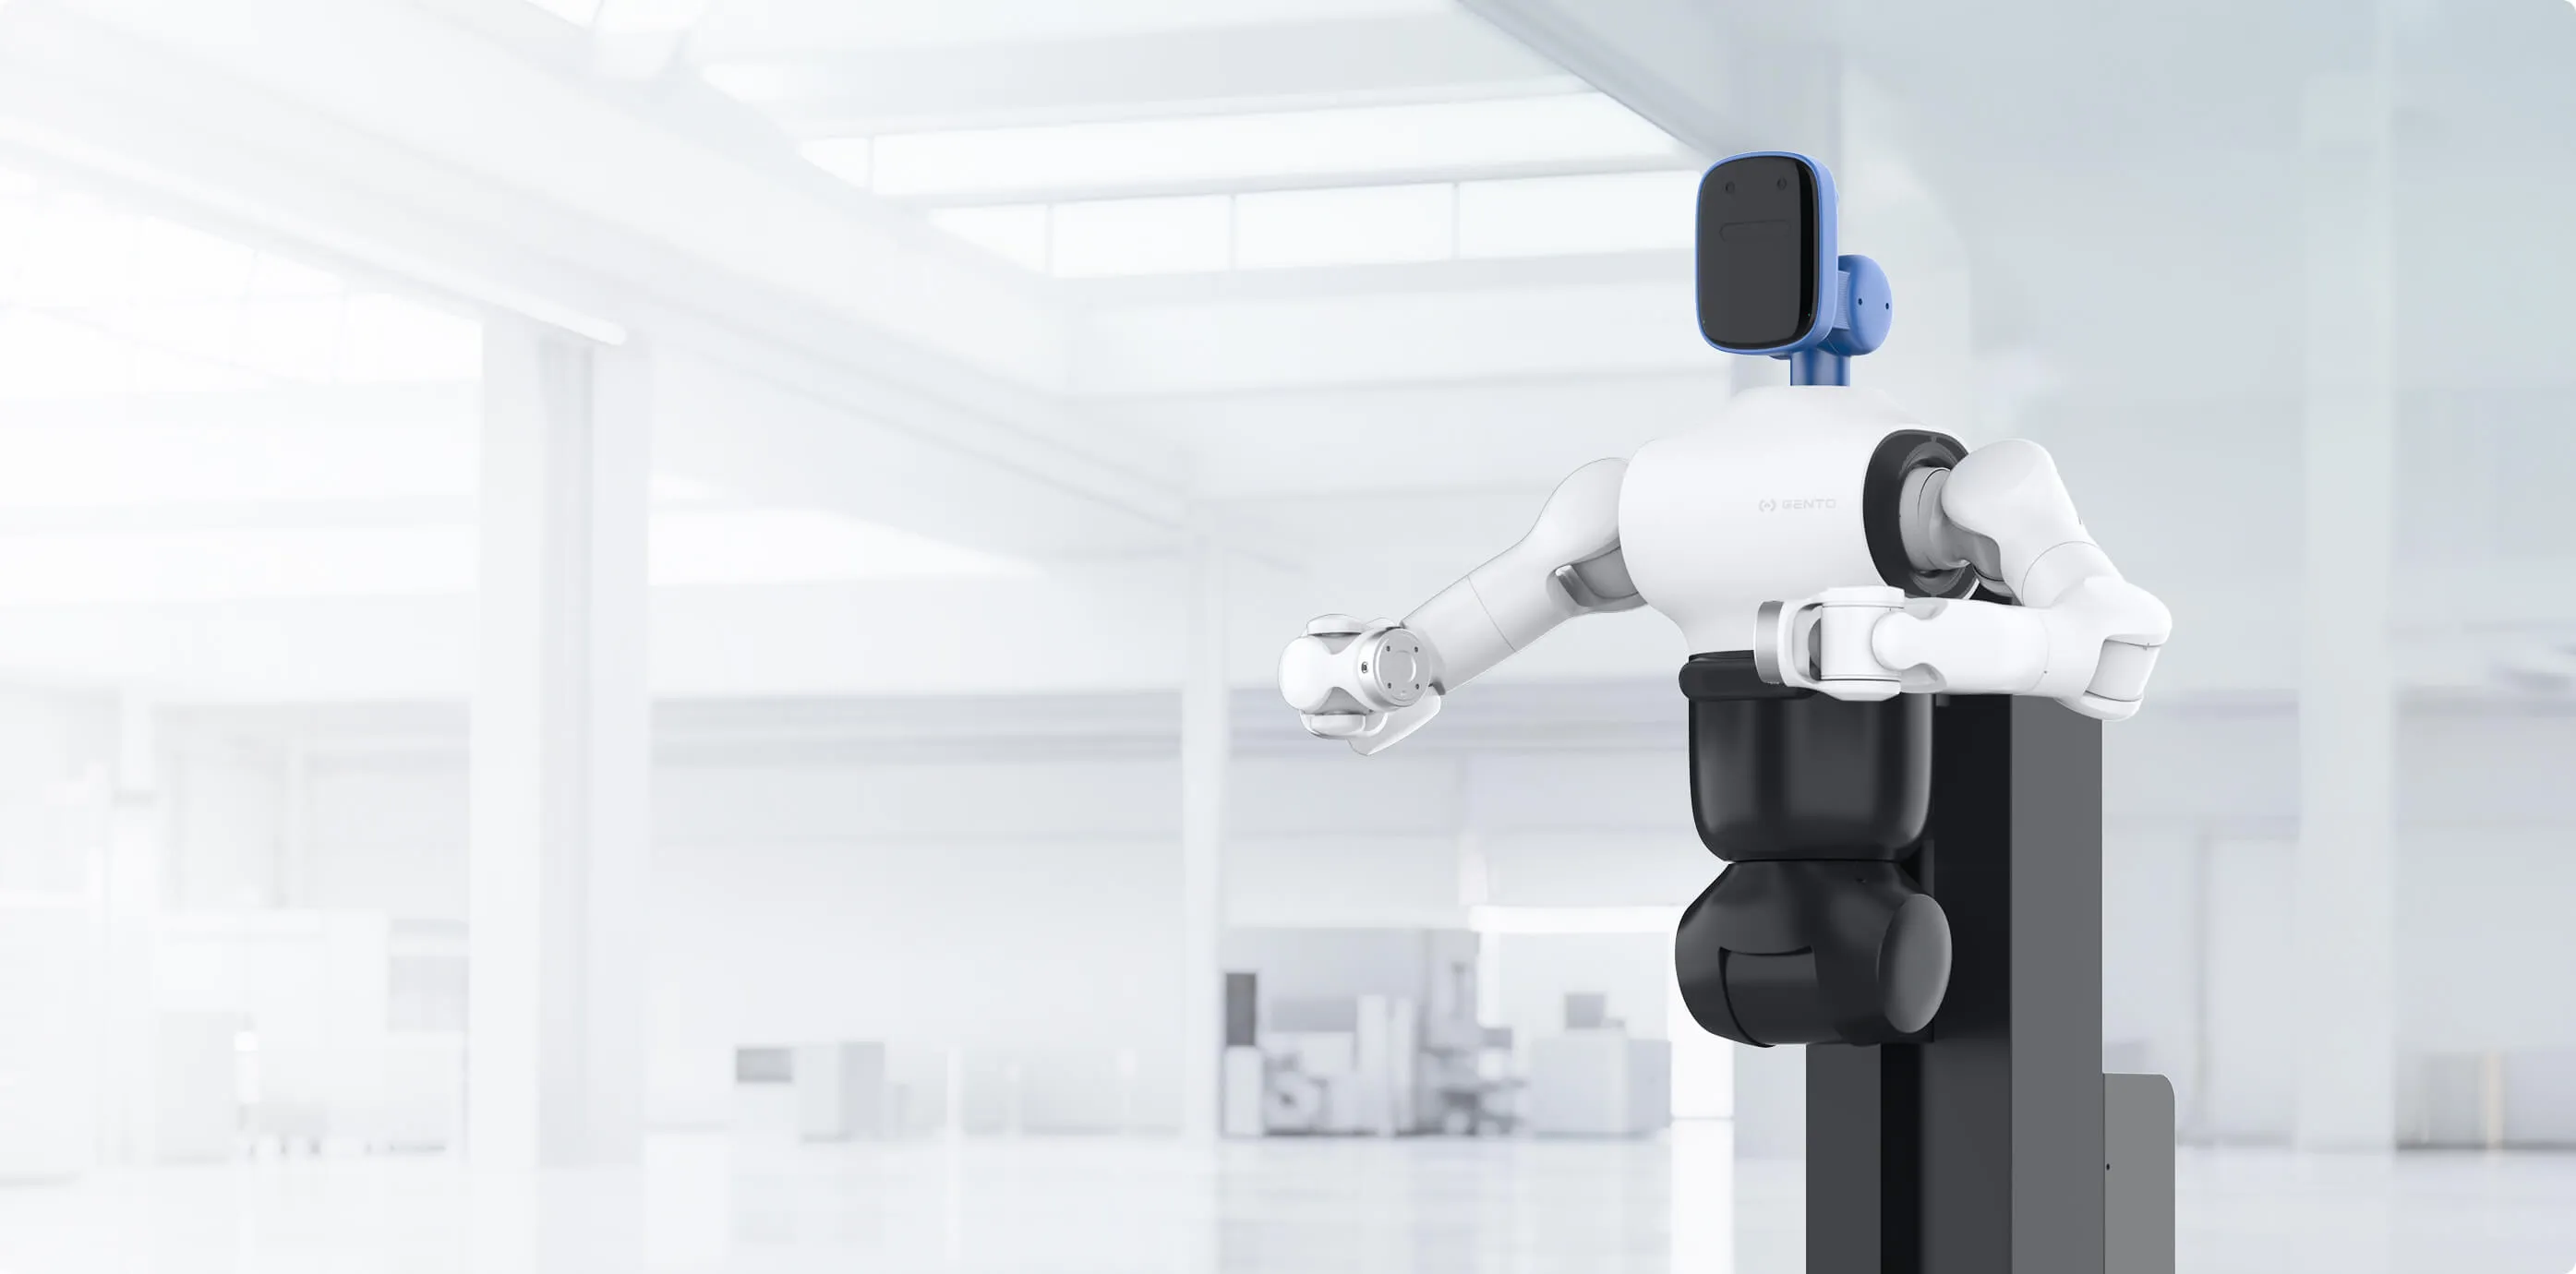
Full-Body Force Control, Safe Interaction, and Industrial-Grade Reliability
-
23 DoFTotal degrees of freedom
(excluding grippers) -
7‑DoF × 2Force‑controlled dual arms
-
1010 x 577 x 1509 mmOverall dimensions
(folded state) -
900 mmLifting range
Hardware Modules for All-Weather Robot Operation
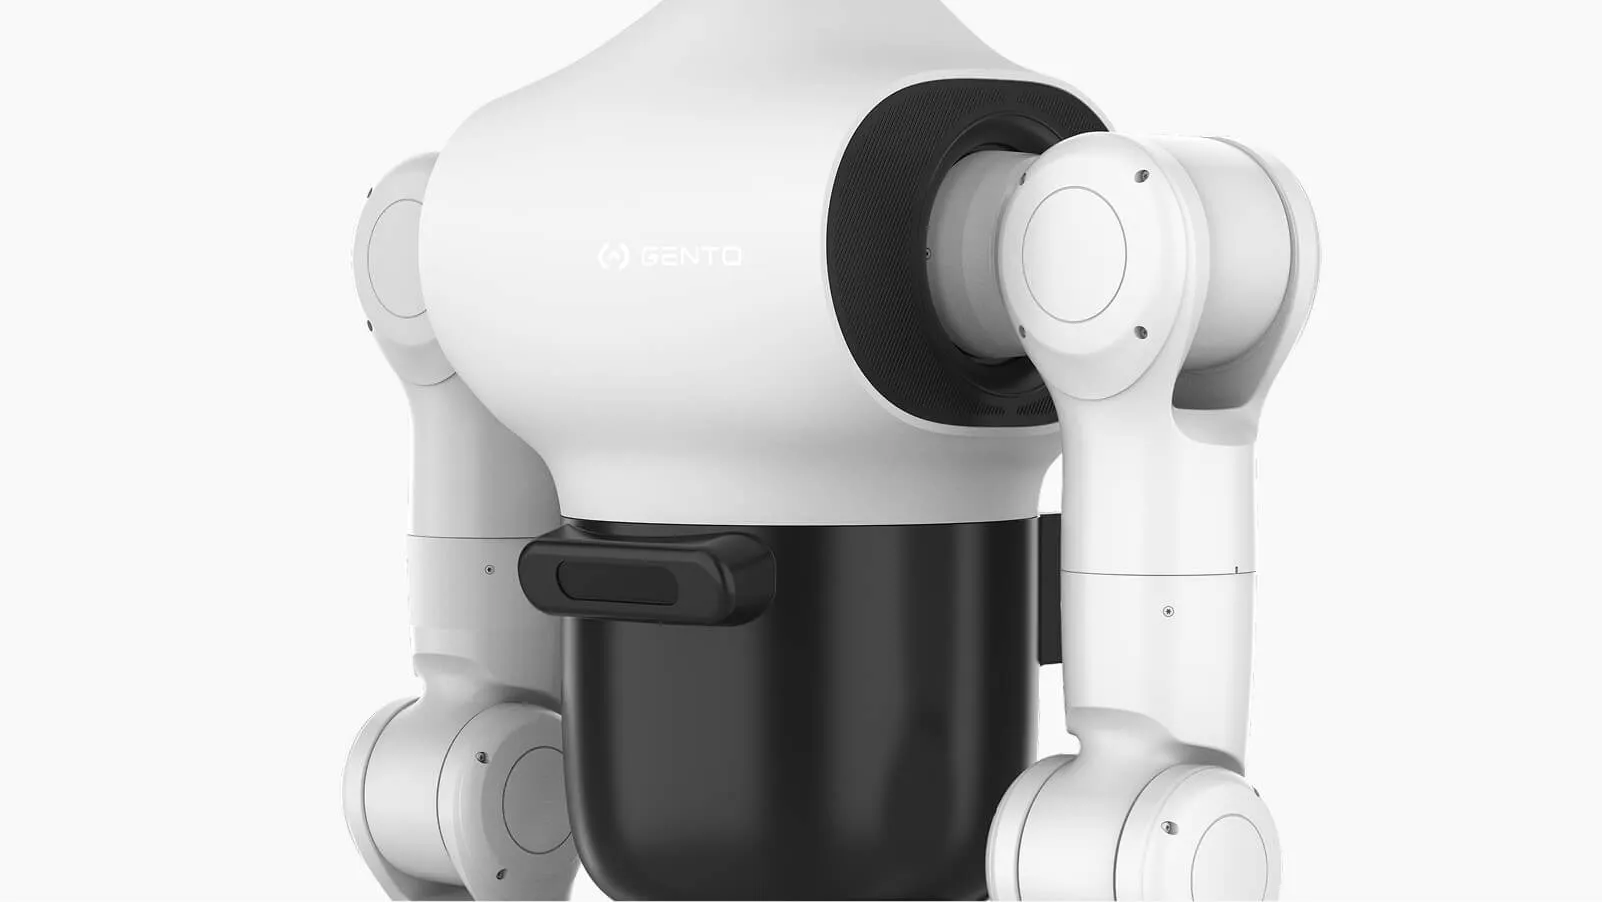
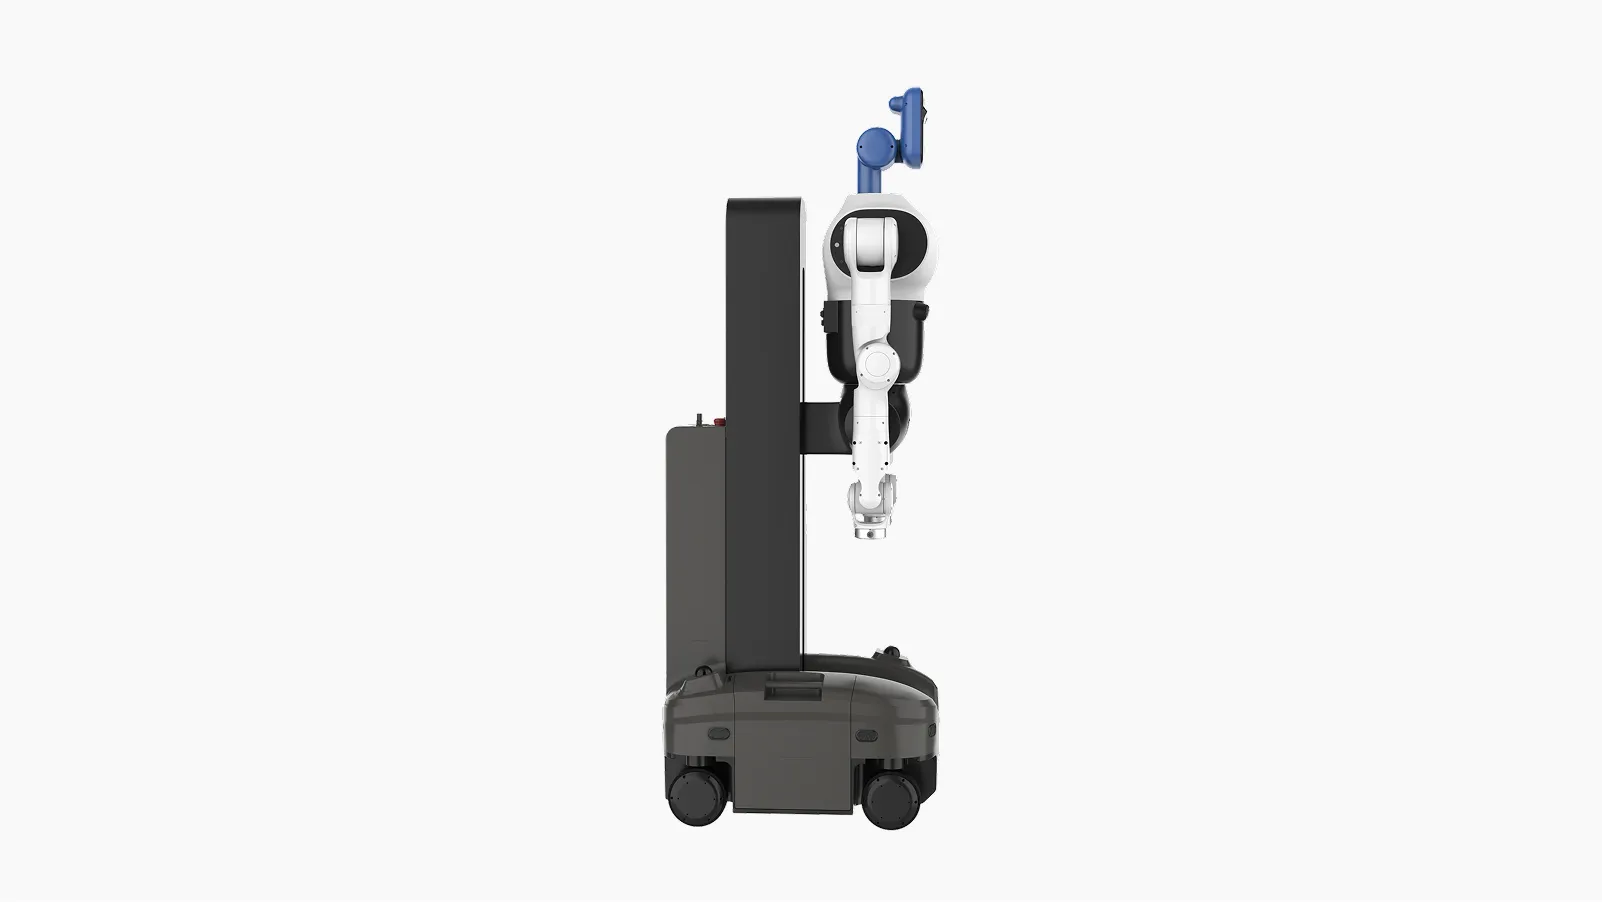
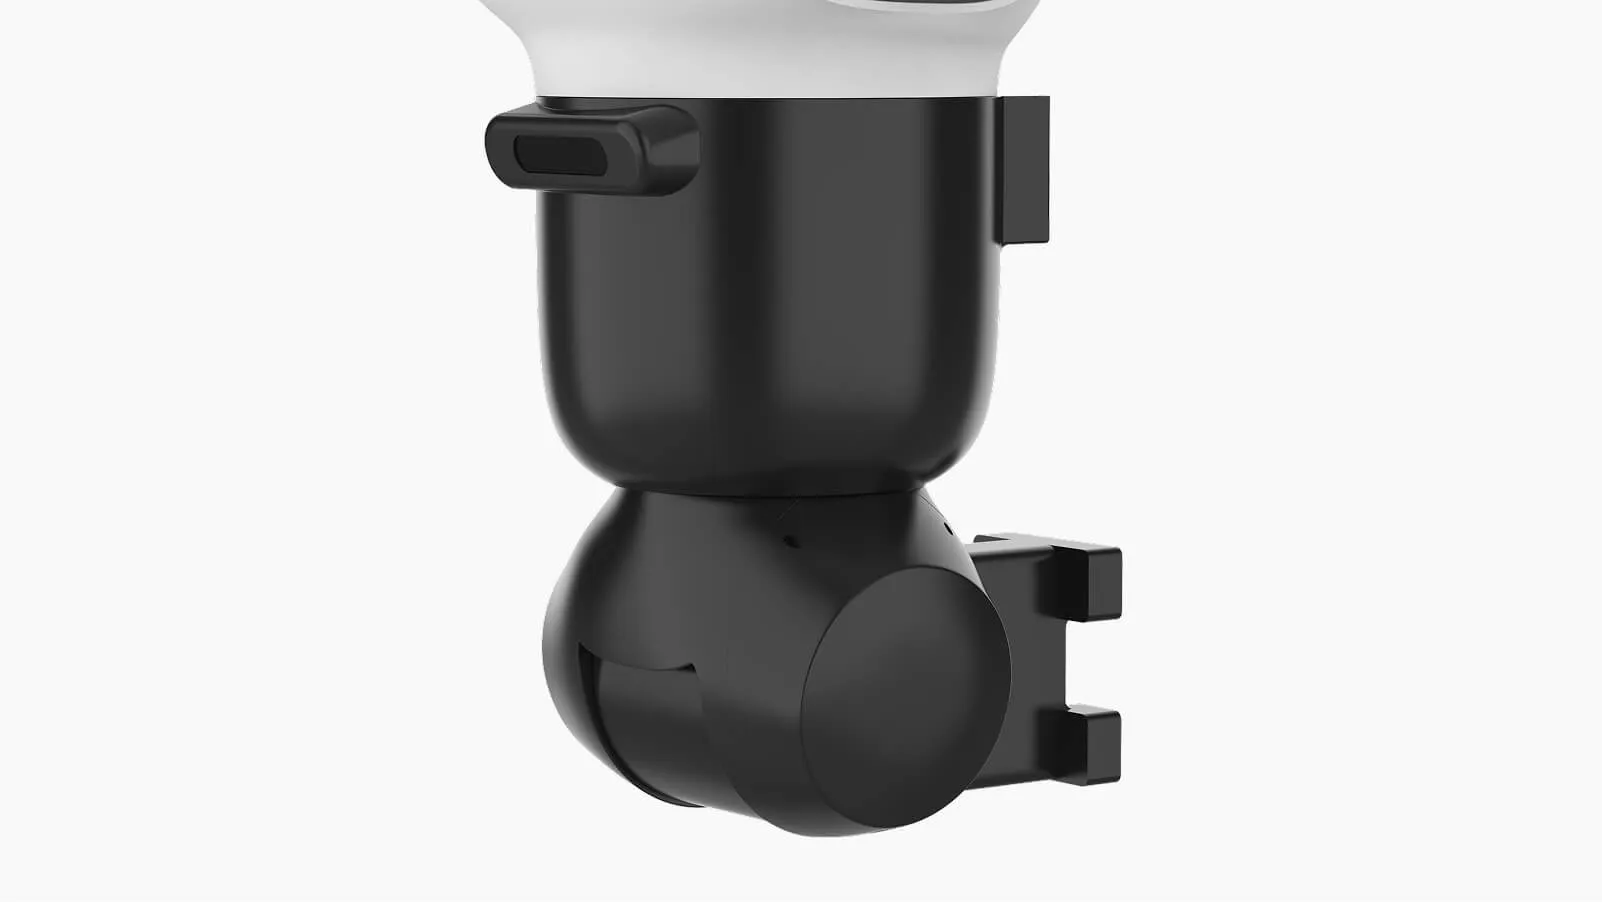
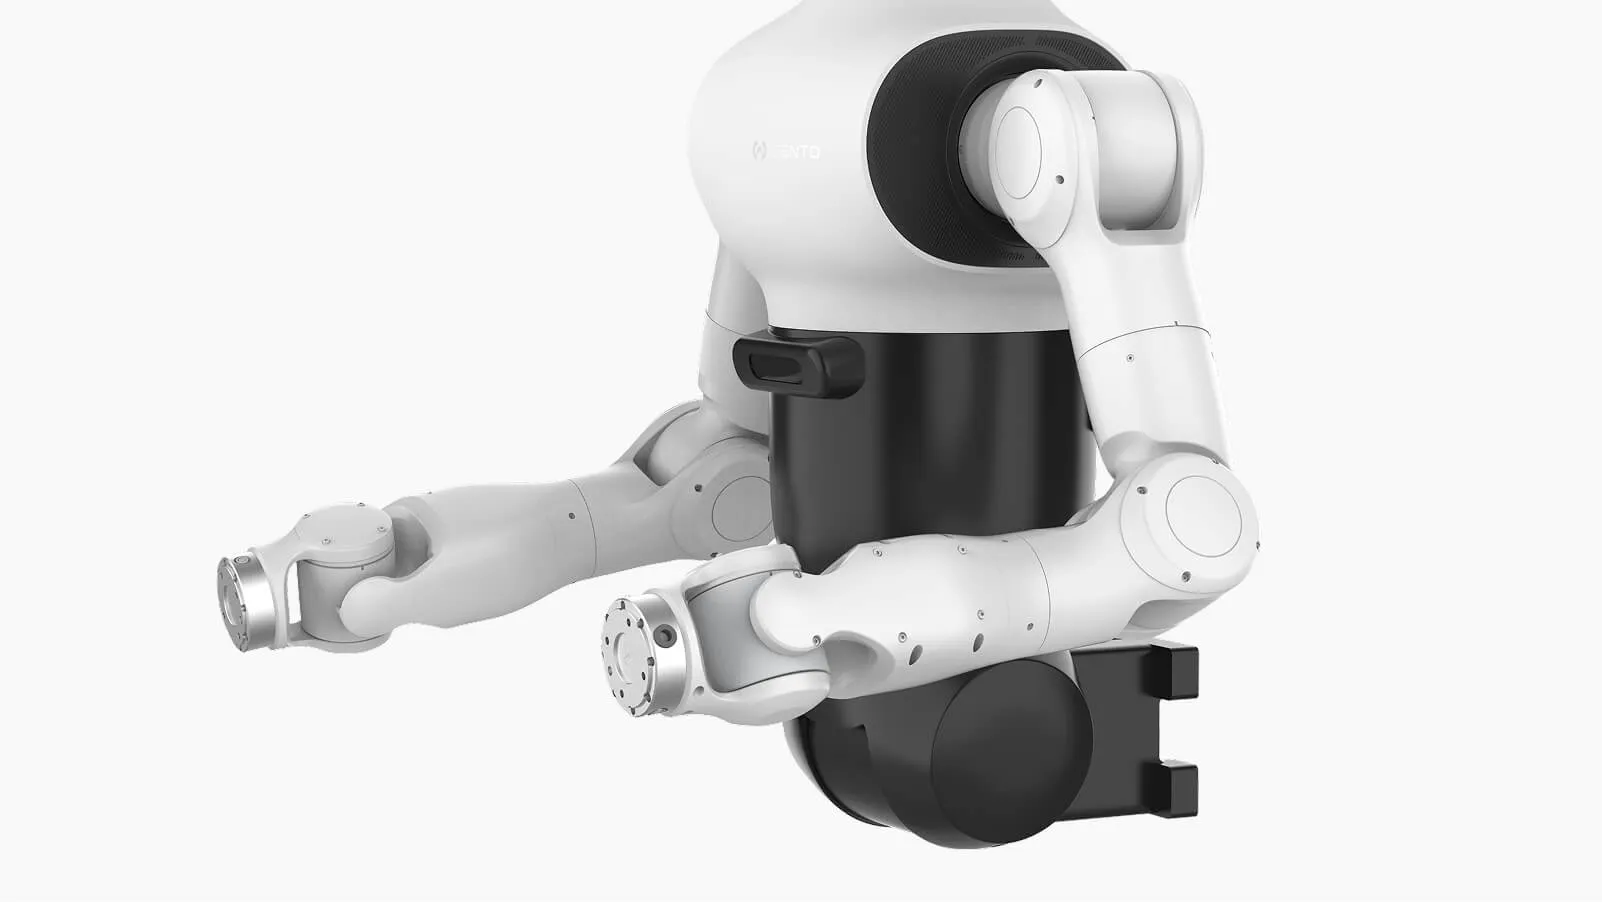
Bringing precise power to every scenario
Gento Skye Specifications
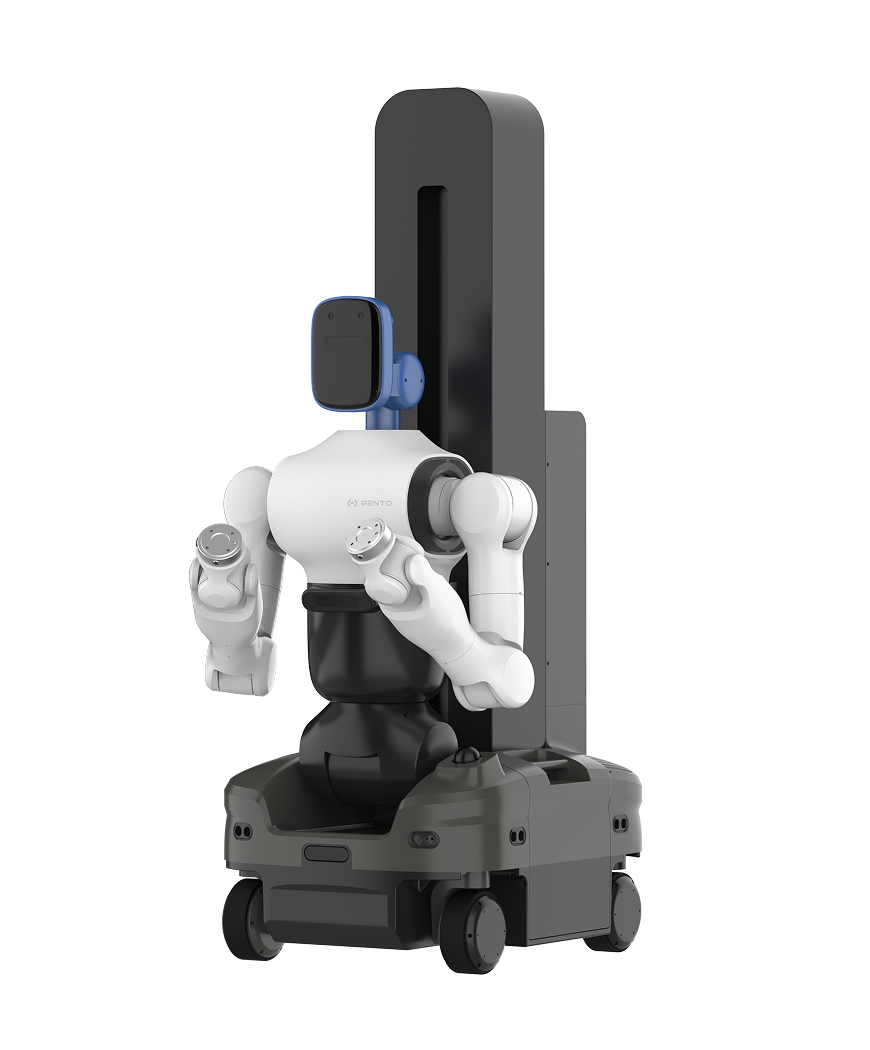
Whole Machine Basic Parameters
Model
Gento Skye
Overall Dimensions (Folded State)
1010 x 577 x 1509 mm
Total weight
≈ 220 kg
Battery Life
4h – 6h
Overall Degrees of Freedom (DoF)
22 DoF (excluding gripper)
Communication Interface
Wi‑Fi / Ethernet
Mobile Chassis
Four‑wheel drive with four steering wheels; omnidirectional motion
Head Parameters
Head Parameters
2 DoF (Pan / Tilt)
Range of Motion
Rotation: ±90°; Pitch: ±30°
Maximum Speed
J1~J2: 180°/s
Communication Protocol
1 kHz EtherCAT
Brake Control (Braking Mode)
Each joint equipped with brake
Stereo Speaker
2x Speakers
Camera
RealSense D455C stereo RGB-D ×1 + Senyun S56C stereo camera ×1
Microphone
4‑mic array
Resolution
1280×720 @30fps and 2560×1984 @30fps
Let "It" be your good helper
More Products
-
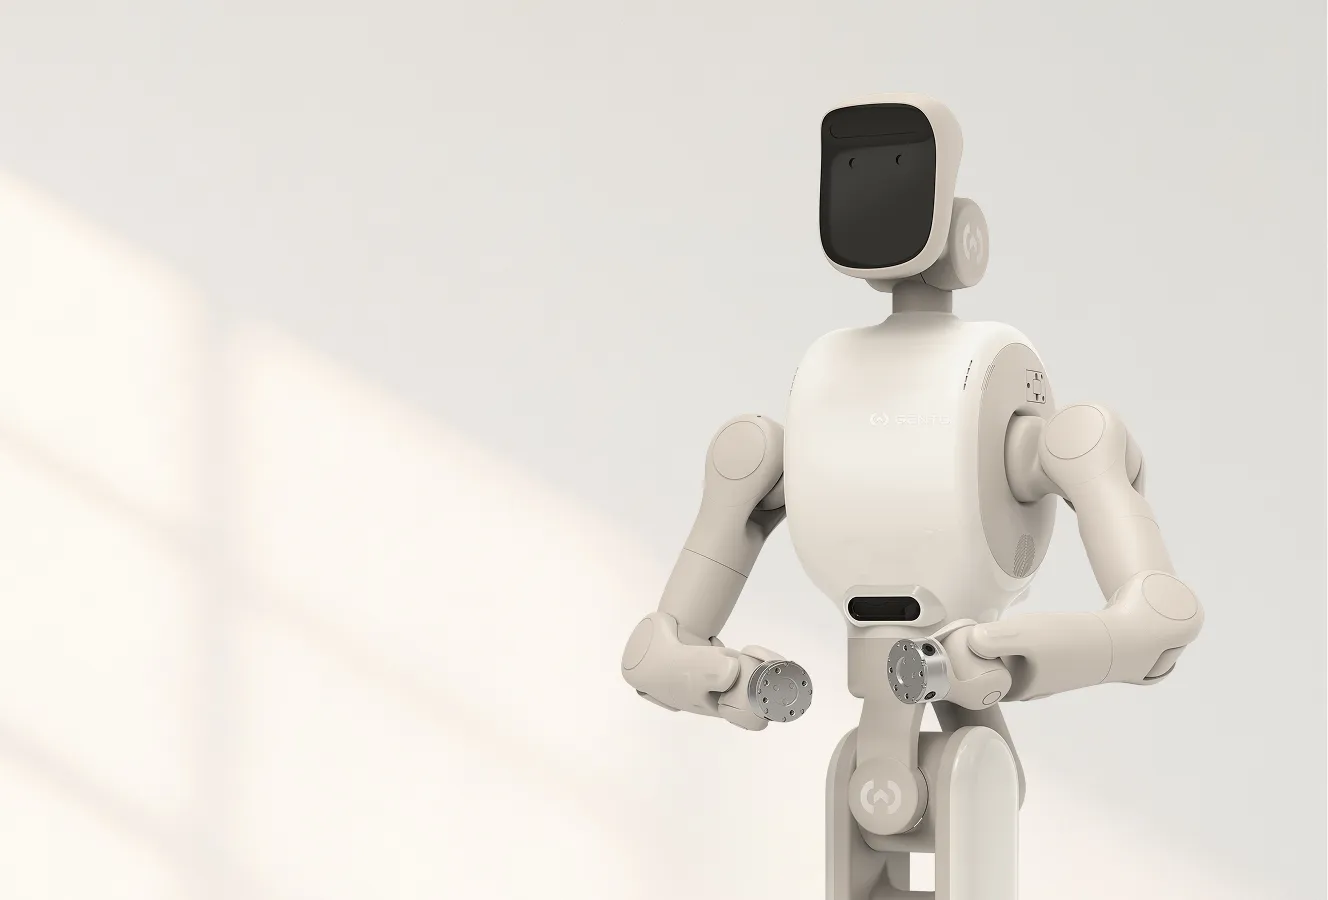
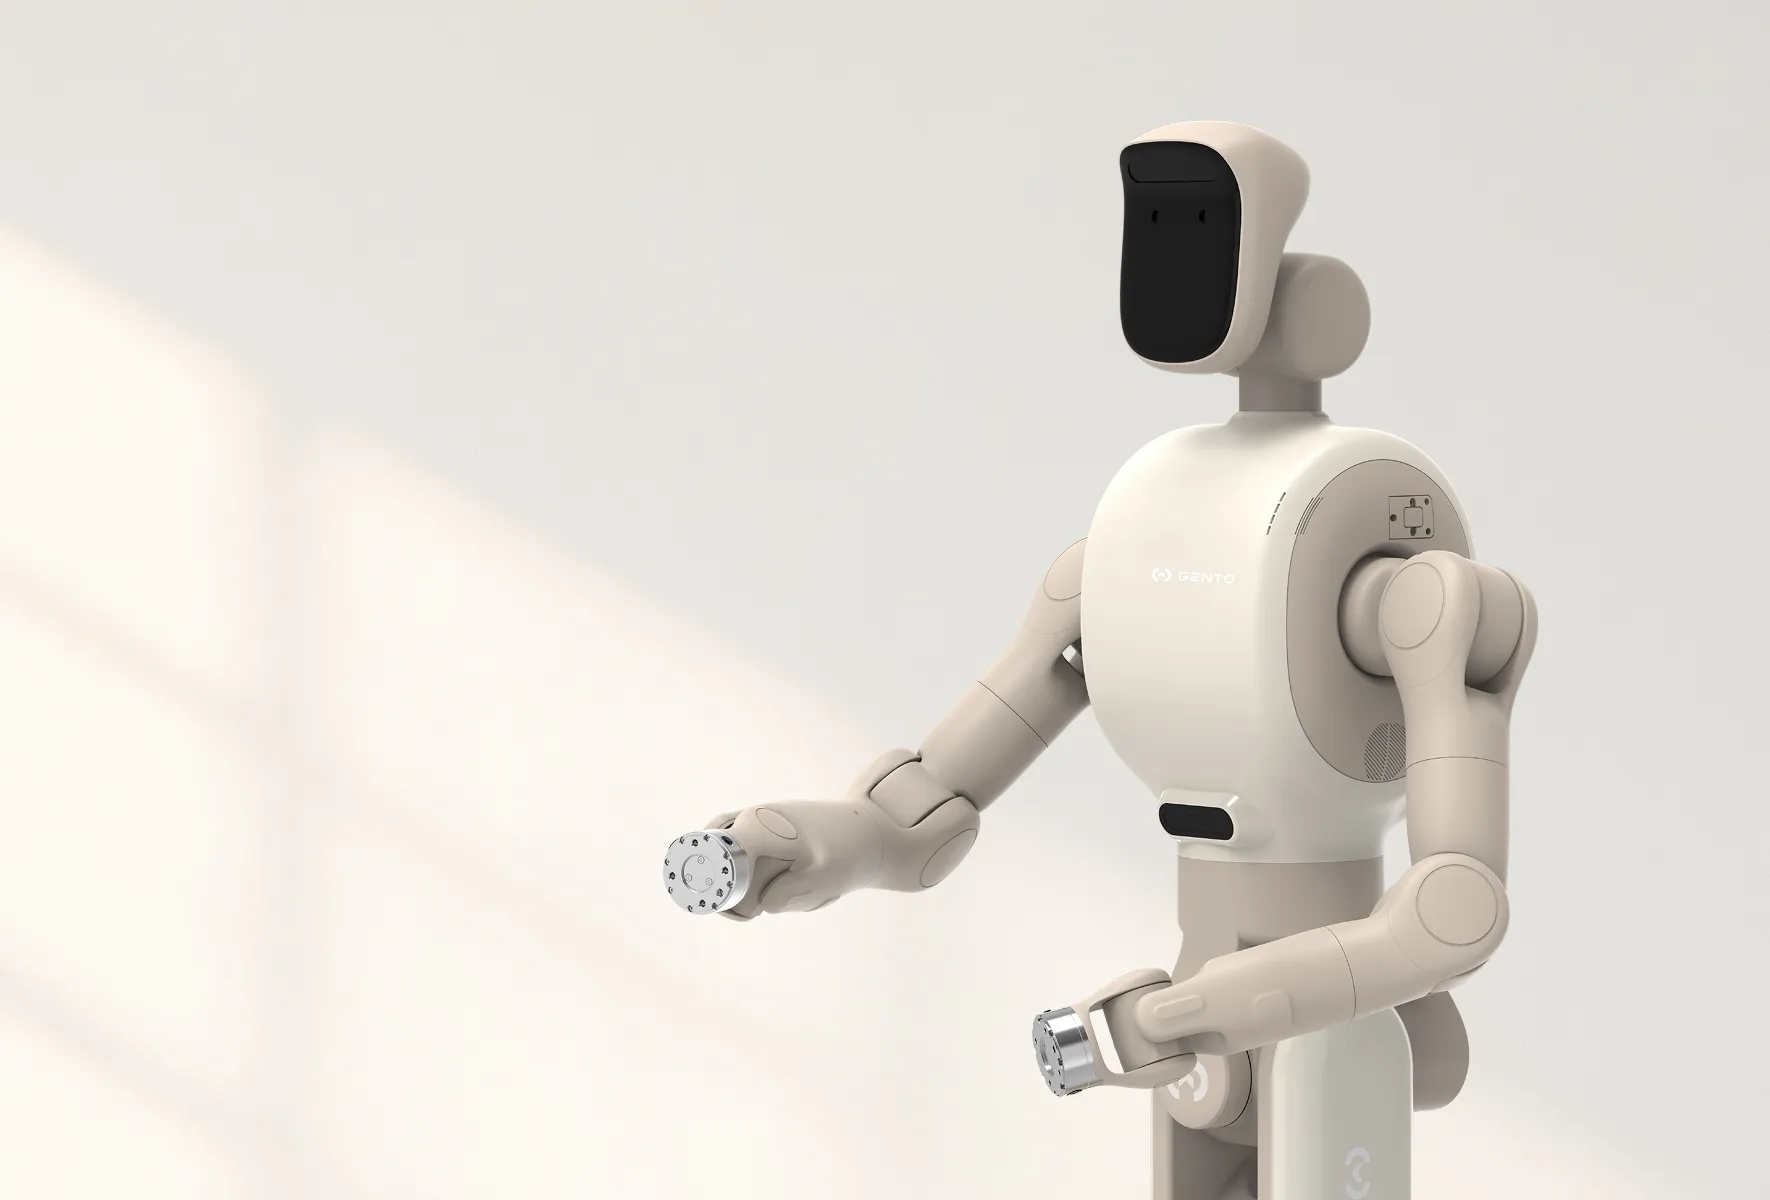 Wheeled Foldable Robot
Gento Luna
A wheeled foldable robot integrating high mobility, strong operability and high computing power -
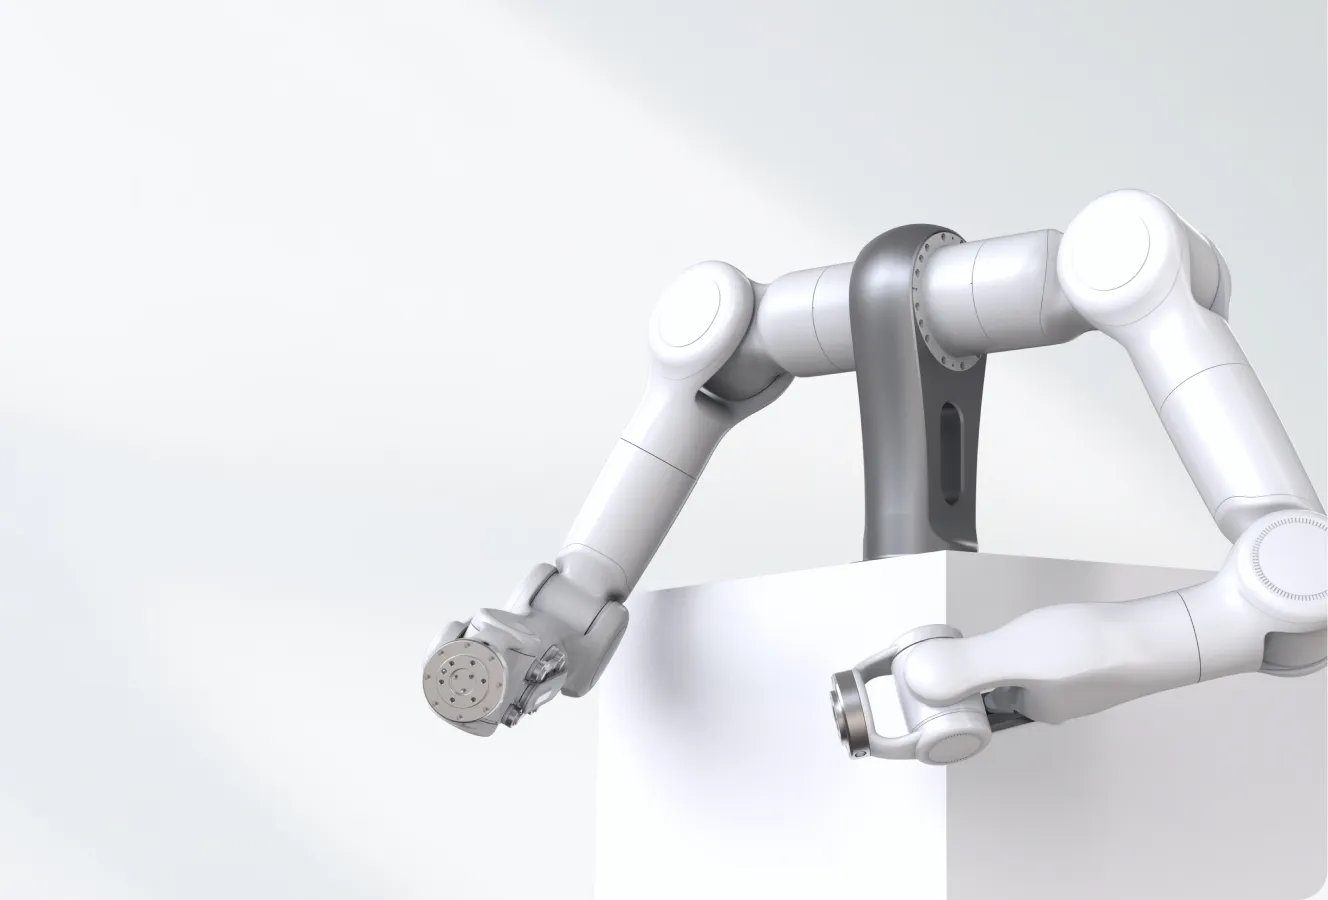
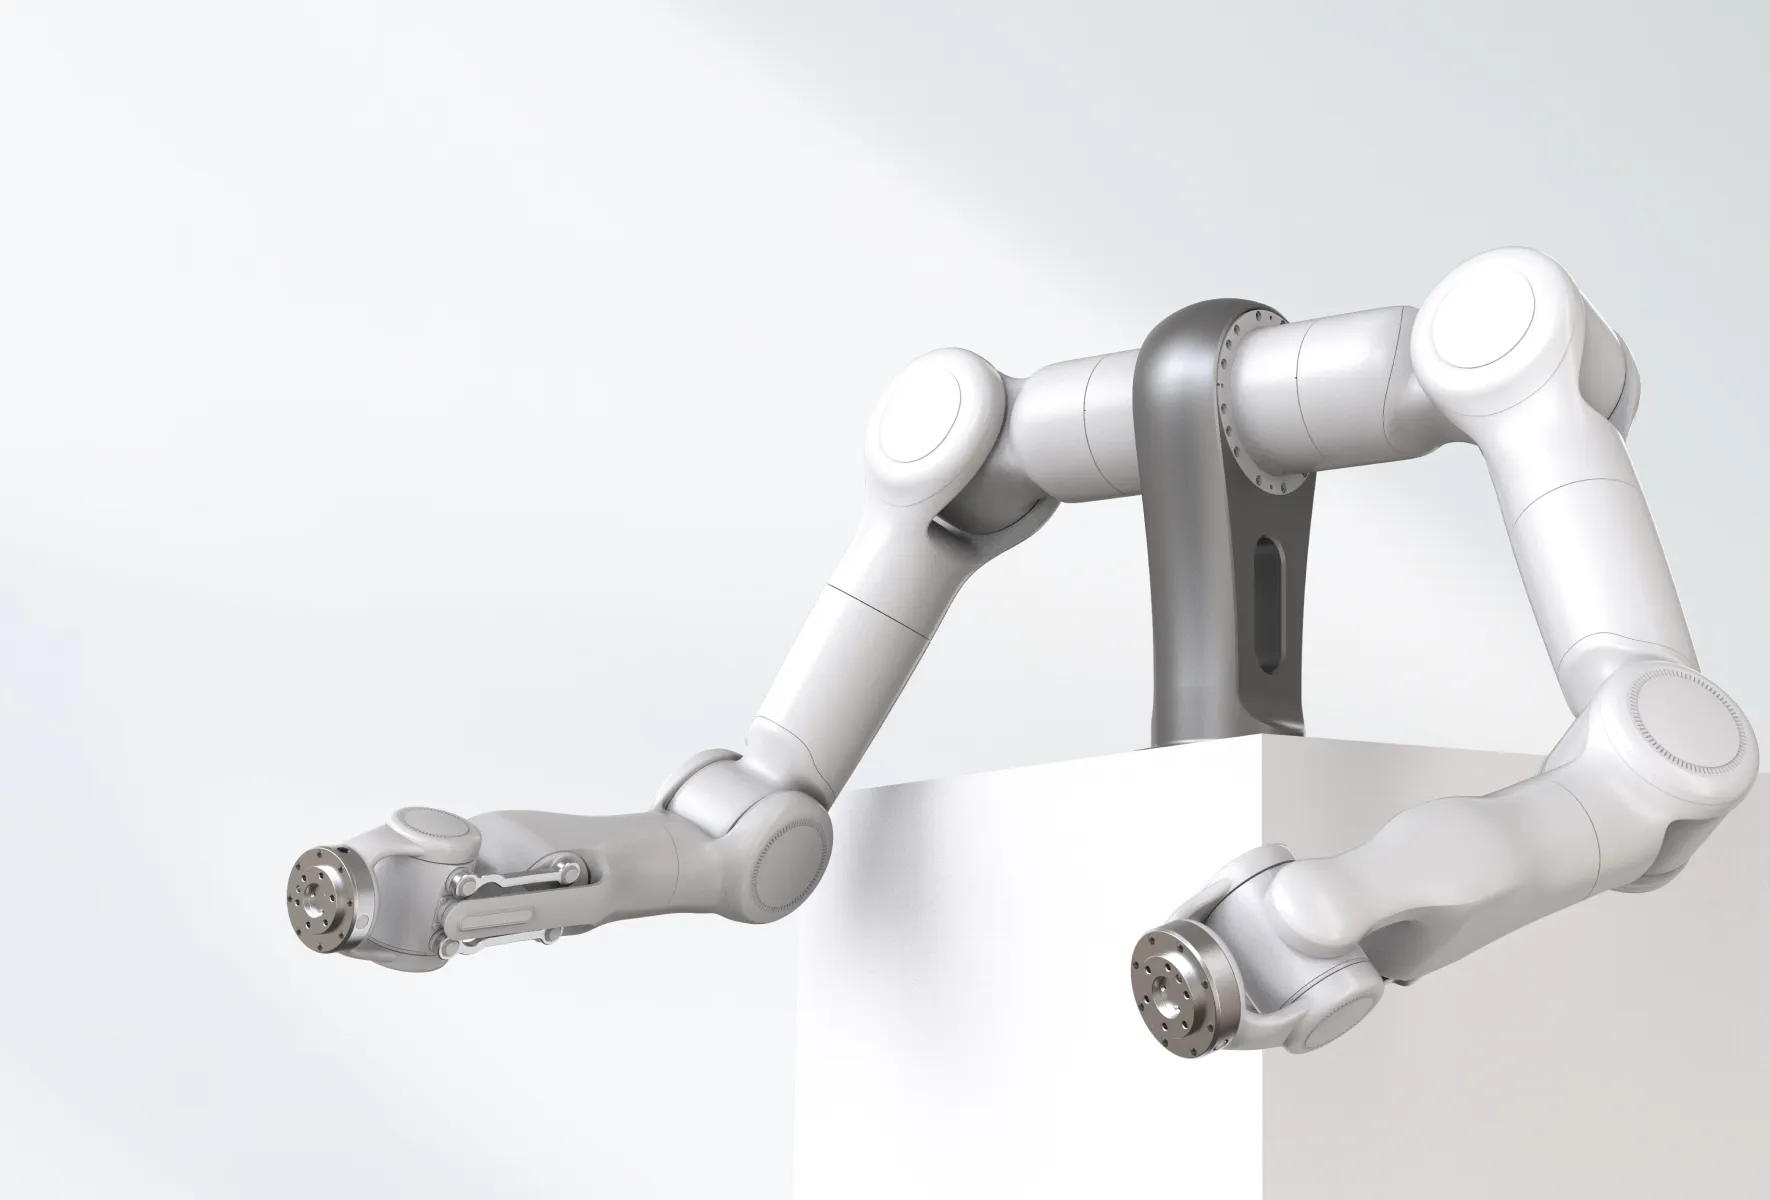 Force-Controlled Humanoid Dual Arms
Marvin
Full force-controlled humanoid arms — anthropomorphic configuration, lightweight, compliant force control, industrial reliability.